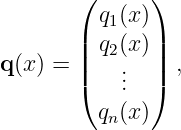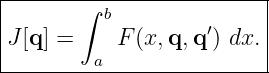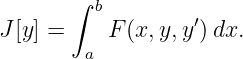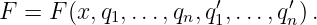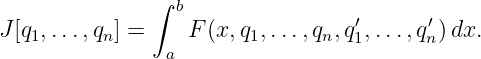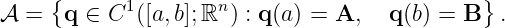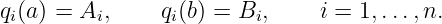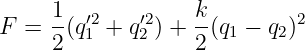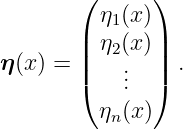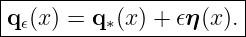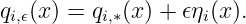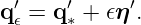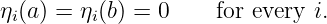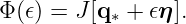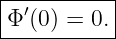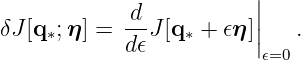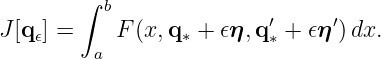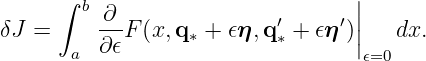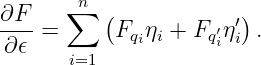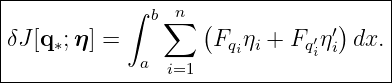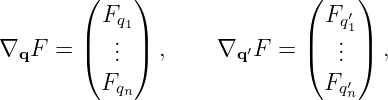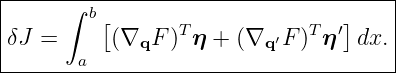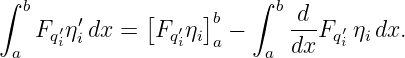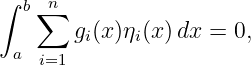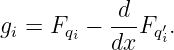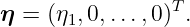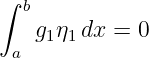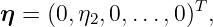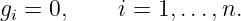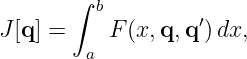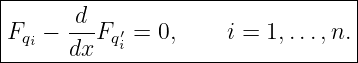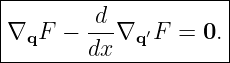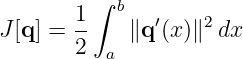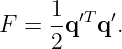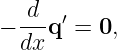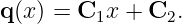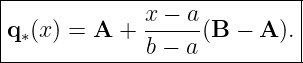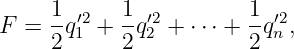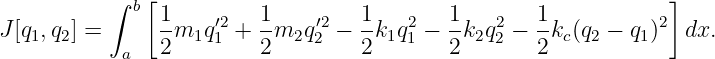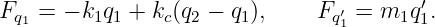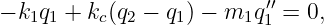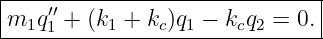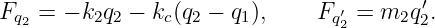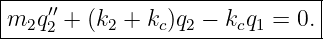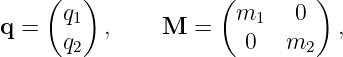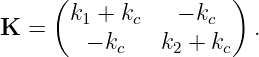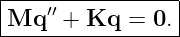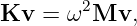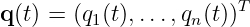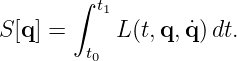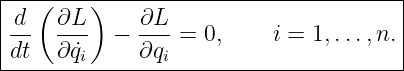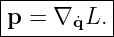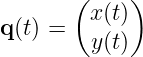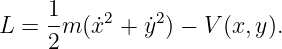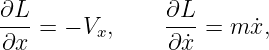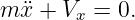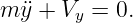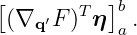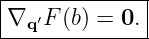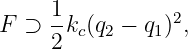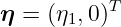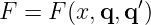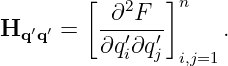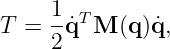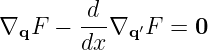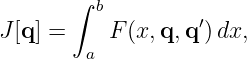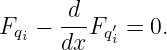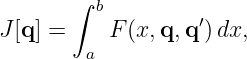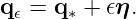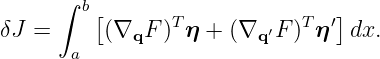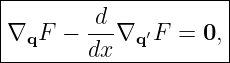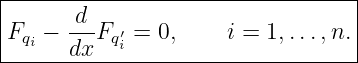Calculus of Variations: Several Dependent Variables and Vector Functionals
The scalar calculus of variations developed in CV01–CV06 studies a single unknown function
y(x). Many physical systems, however, have several coordinates evolving together. A
double pendulum needs more than one angle, a spacecraft attitude model has several
generalized coordinates, and even a simple pair of coupled masses requires two displacement
functions.
The natural variational unknown is then a vector-valued function
and the scalar functional becomes
The functional still returns one real number, but it now evaluates an entire vector path. The
corresponding stationarity condition is not one differential equation but a coupled system of
Euler–Lagrange equations, one for each component of q [1, 2, 3].
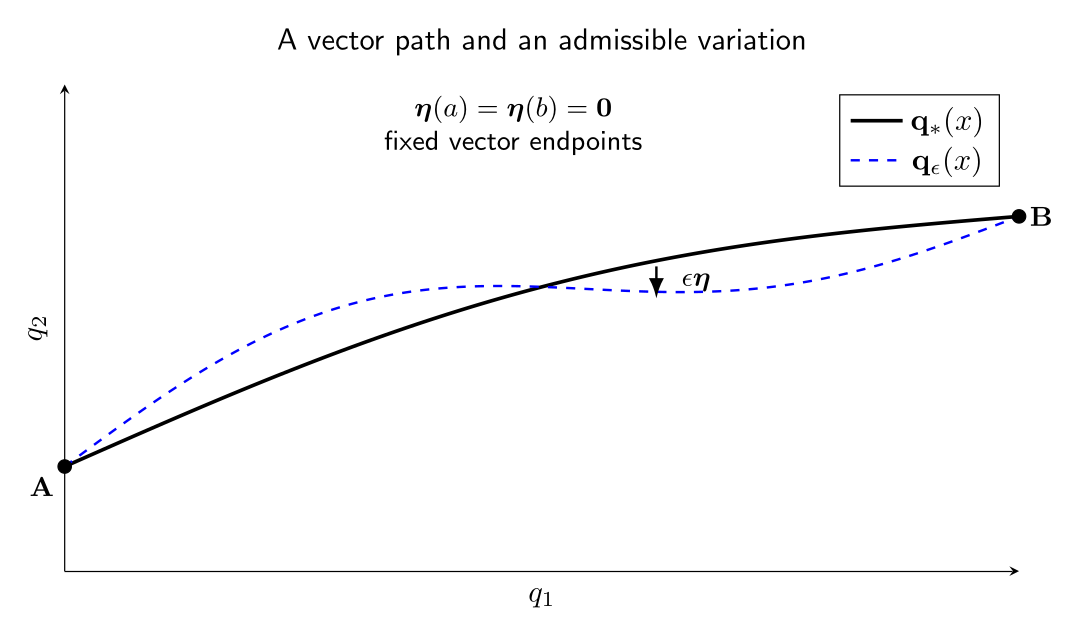
Figure. A vector-valued candidate path q∗(x) and a nearby varied path
q𝜖(x) = q∗(x) + 𝜖η(x). The variation η has one component for each dependent variable.
1 Learning objectives
After completing CV07, the reader should be able to
- formulate a first-order variational problem with several dependent variables;
- construct a vector variation q𝜖 = q + 𝜖η;
- derive the vector first-variation formula;
- integrate by parts component by component;
- use independent test-function components to obtain the coupled Euler–Lagrange
equations;
- express the result in component, vector, and matrix notation;
- recognize generalized momenta in multi-degree-of-freedom mechanics;
- derive the equations of a coupled quadratic system;
- interpret vector endpoint conditions; and
- distinguish coupling of equations from coupling of variations.
2 From one dependent variable to many
For one unknown function, the standard first-order functional is
For n unknown functions, write
The integrand can depend on every coordinate and every derivative:
The functional is therefore
The notation J[q] is shorter, but it is essential to remember that J still maps an admissible
function or vector of functions to a scalar.
3 The admissible vector class
For fixed vector endpoints, a typical admissible class is
Equivalently, each component satisfies
A vector-valued admissible path is therefore not a new kind of functional object; it is simply an
ordered collection of admissible component functions. What changes is that the integrand can
couple the components.
For example,
cannot be separated into a term involving only q1 plus a term involving only q2. The difference
q1 − q2 couples the two coordinates.
4 Vector variations
Let q∗(x) be a candidate stationary path. Introduce a vector test function
The varied family is
Componentwise,
Differentiating with respect to x gives
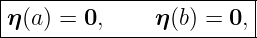
For fixed endpoints,
which means
The key new freedom is that the components of η can be chosen independently. We can perturb
only q1, only q2, or any combination. That independence is what ultimately produces one
Euler–Lagrange equation per component.
5 Scalarizing the vector problem
As in CV02, define the ordinary one-variable function
If q∗ is stationary, then for every admissible vector direction η,
The first variation is
This is still a directional derivative of the functional. The only change is that the direction is
vector-valued.
6 Deriving the vector first variation
Write
Assuming the regularity needed to differentiate under the integral sign,
The multivariable chain rule gives
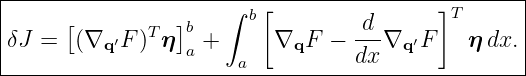
Therefore
Using gradient notation,
so the same result is
The transpose simply represents the Euclidean dot product.
7 Integration by parts component by component
For each component,
Summing from i = 1 to n,
| δJ | = 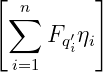 ab | (26)
|
| + ∫
ab ∑
i=1n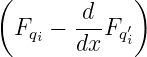 ηi dx. | (27) |
In vector notation,
For fixed endpoints, η(a) = η(b) = 0, so the boundary term vanishes.
8 Why one vector integral gives n equations
After the boundary term is removed, stationarity requires
where
Now choose a variation having only its first component nonzero:
Then
for every admissible scalar test function η1. The Fundamental Lemma gives
Repeat with
and obtain g2 = 0. Continuing through all components gives
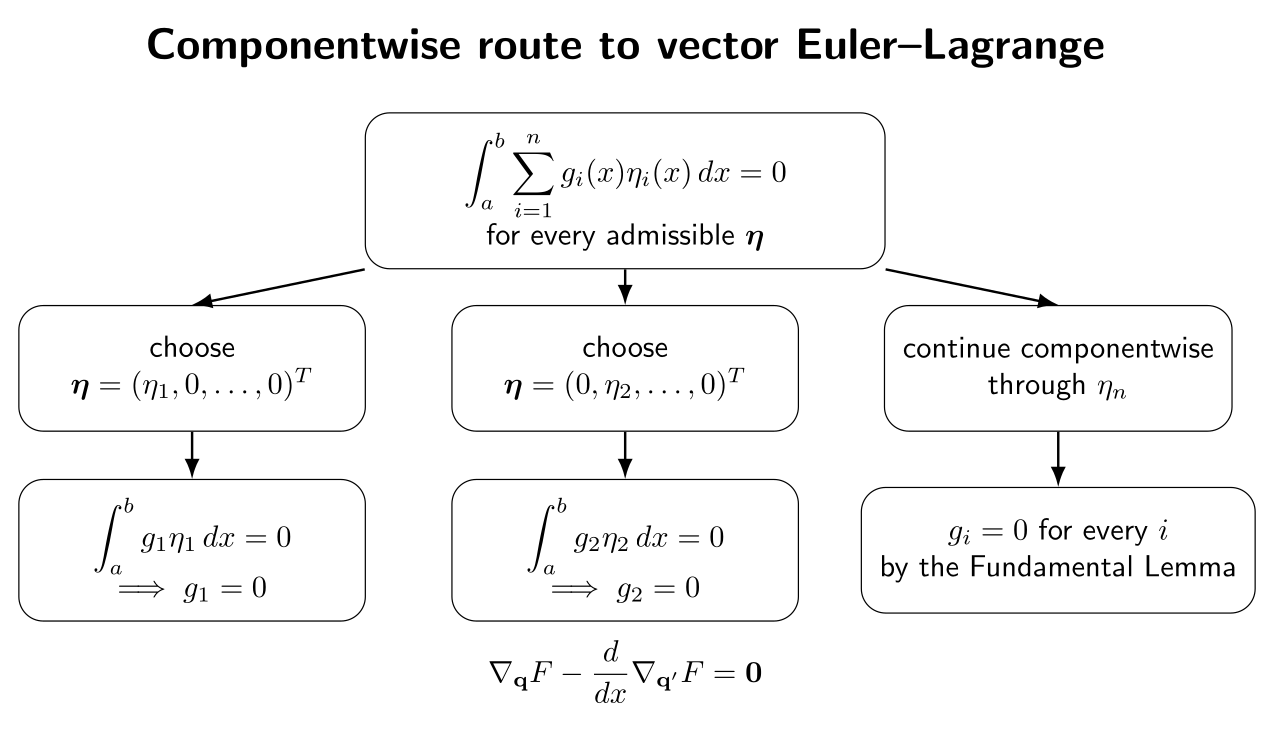
Figure. The vector Fundamental-Lemma step. Because each component of the test
function can be selected independently, the single scalar stationarity condition yields one
Euler–Lagrange equation for every dependent variable.
9 The vector Euler–Lagrange theorem
theorem. Let
where F is sufficiently smooth and q∗ ∈ C2([a,b]; ℝn) is a stationary curve with fixed endpoints.
Then each component satisfies
Equivalently,
This vector equation is shorthand for n scalar differential equations. It does not mean that the
equations are independent. If F couples the coordinates, the resulting equations are coupled as
well.
10 Example 1: vector Dirichlet energy and a straight path
Consider
with fixed vector endpoints
The integrand is
Hence
The vector Euler–Lagrange equation becomes
or
Integrating twice,
Using the two vector endpoint conditions gives
This is the affine parameterization of the straight segment from A to B.
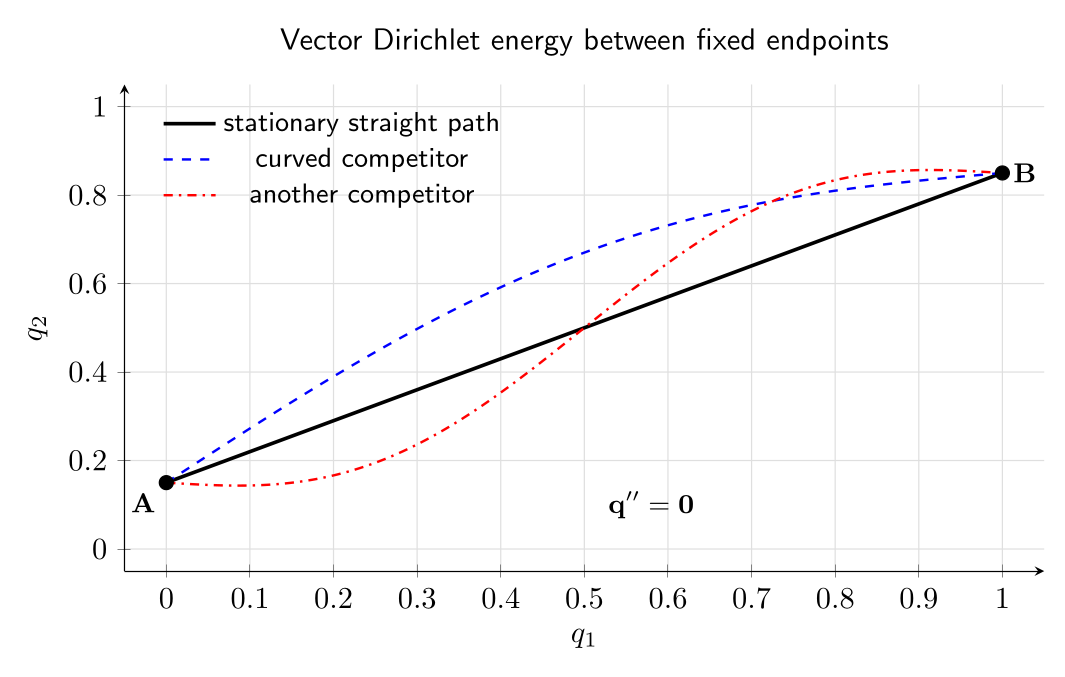
Figure. Several vector-valued paths joining the same endpoints in the plane. The
stationary path for the quadratic vector Dirichlet energy is the straight segment,
corresponding to q′′ = 0.
10.1 Why this is more than two separate scalar problems
For this particular integrand,
so the components decouple. Each equation is simply
That is a special case. The next example shows genuine coupling.
11 Example 2: a coupled quadratic variational problem
Consider two dependent variables and
Here m1,m2 > 0 and k1,k2,kc ≥ 0. The kc term couples the coordinates. For q1,
Therefore
or
For q2,
Hence
The pair forms a coupled differential system.
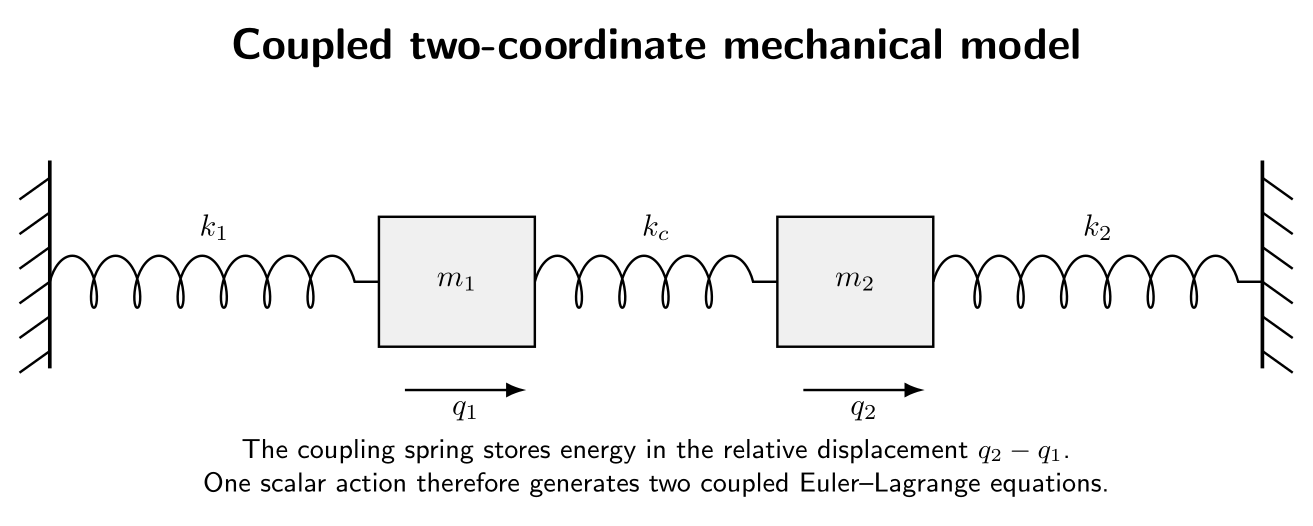
Figure. A mechanical interpretation of the coupled quadratic functional. The middle
spring depends on the relative displacement q2 − q1, so varying either coordinate changes
the coupling energy and therefore both Euler–Lagrange equations.
12 Matrix form of the coupled system
Define
and
Then the two Euler–Lagrange equations become
This is the standard matrix form of a linear multi-degree-of-freedom system. Its normal modes
arise from the generalized eigenvalue problem
which belongs to vibration theory rather than to the derivation of the Euler–Lagrange equations
themselves. The important variational lesson is that a single scalar action produces the full coupled
matrix equation.
13 General multi-degree-of-freedom mechanics
In mechanics, replace x by time t and let
be generalized coordinates. Hamilton’s principle uses the action
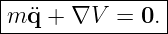
Applying the vector Euler–Lagrange result gives
These are Lagrange’s equations of the second kind [4, 5]. CV14 will develop Hamilton’s principle
as a mechanics topic in its own right; CV07 is establishing the vector variational machinery needed
for that step.
14 Generalized momentum becomes a vector
Define the generalized momentum components
Collecting them gives
The Euler–Lagrange equations can then be written
If a coordinate qj is cyclic, then
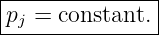
so its conjugate momentum satisfies
Thus the scalar cyclic-coordinate result from CV06 extends componentwise to multi-coordinate
systems.
15 Example 3: planar particle in a potential
Let
and take
For x,
so
Similarly,
Together,
Since force is F = −∇V , this is
The familiar vector form of Newton’s second law therefore emerges directly from a vector
variational principle.
16 Vector endpoint conditions
The integration-by-parts boundary term for a vector functional is
For fixed vector endpoints, every component of η vanishes and there is no natural boundary
condition.
If instead the terminal vector q(b) is completely free while b is fixed, then η(b) is arbitrary.
Stationarity requires
Componentwise,
More complicated partial endpoint freedom is handled by allowing only the corresponding
components or tangent directions of η to vary. This is the vector extension of the natural-boundary
and transversality ideas from CV05.
17 Coupling of equations versus independence of variations
Two statements that sound contradictory are both true:
- the components qi may be strongly coupled through F;
- the variation components ηi may still be chosen independently when the admissible
class places no constraint coupling them.
The first statement concerns the physical or mathematical model. The second concerns the
allowable perturbations used to test stationarity.
For the coupled oscillator,
so the final equations are coupled. Nevertheless, choosing
is legitimate under unconstrained fixed-endpoint variations, and it isolates the first Euler–Lagrange
equation in the proof.
If the admissible class itself imposes a relation such as
then the variations are no longer independent. That is a constrained variational problem and is
postponed to CV09 and CV15.
18 Several cyclic coordinates
Suppose
is independent of a subset of the coordinates, for example
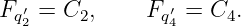
Then the corresponding Euler–Lagrange equations give
Each cyclic coordinate produces its own first integral. This is one reason symmetry becomes
especially powerful in multi-degree-of-freedom systems: a single model can possess several
conserved generalized momenta.
19 The Hessian with respect to derivatives
For one dependent variable, the regularity of the Euler–Lagrange equation is connected
with
For several dependent variables, the analogous object is the matrix
If this matrix is nonsingular, the vector Euler–Lagrange equations can often be solved locally for
the highest derivatives q′′. In mechanics, for a standard kinetic energy
this Hessian is closely related to the mass matrix. Singular Hessians occur in constrained or
gauge-type systems and require additional theory.
CV07 uses only the classical regular case; the matrix viewpoint is introduced now so that the later
mechanics and optimal-control entries have a natural language.
20 Necessary conditions are still only necessary
The vector Euler–Lagrange equations are stationarity conditions. A solution of
need not minimize the functional. It may be a maximum, saddle, or other stationary path. The
second variation becomes a quadratic form in the vector variation η, and its classification involves
matrix-valued coefficients. That analysis begins in CV11.
Existence is likewise separate. A formal solution of the coupled boundary value problem does not
by itself prove that a minimizer exists in the chosen admissible function space.
21 Common mistakes
- Mistake: treating J[q] as vector-valued. The path is vector-valued, but the functional
considered here still returns one scalar.
- Mistake: writing only one Euler–Lagrange equation for several dependent variables.
There is one equation for each independent component.
- Mistake: assuming coupled equations imply the test functions cannot be chosen
componentwise. Coupling in F does not by itself restrict the admissible variations.
- Mistake: differentiating Fqi′ only partially with respect to x. The derivative dFqi′∕dx
is a total derivative along the path.
- Mistake: confusing ∇qF with a spatial gradient in physical space. It is the gradient
of F with respect to its coordinate arguments qi.
- Mistake: forgetting that constraints can destroy componentwise independence of the
variations.
- Mistake: interpreting every stationary vector path as a minimum.
22 A practical vector Euler–Lagrange checklist
Given
use the following workflow:
- List the dependent variables q1,…,qn.
- State the admissible class and all endpoint or coupling constraints.
- Introduce q𝜖 = q + 𝜖η.
- Determine which components of η are independent.
- Compute Fqi and Fqi′ for every component.
- Form
- Collect the equations into vector or matrix form if useful.
- Apply fixed, natural, or transversality endpoint conditions.
- Inspect cyclic coordinates for first integrals from CV06.
- Keep stationarity separate from minimum classification and existence.
23 Summary
For the vector functional
an admissible vector variation is
The first variation is
After componentwise integration by parts and the Fundamental Lemma,
or equivalently
A single scalar functional can therefore generate an entire coupled system of differential equations.
In mechanics this becomes the multi-coordinate form of Lagrange’s equations, while in geometry it
governs vector-valued stationary paths. CV07E1 will practice coupled systems, and CV07E2 will
apply the vector formulation to trajectory problems. CV08 next extends the variational machinery
to functionals containing higher derivatives.
References
[1] I. M. Gelfand and S. V. Fomin, Calculus of Variations, Dover Publications, 2000.
[2] Bruce van Brunt, The Calculus of Variations, Springer, 2004.
[3] Robert Weinstock, Calculus of Variations with Applications to Physics and
Engineering, Dover Publications, 1974.
[4] Cornelius Lanczos, The Variational Principles of Mechanics, 4th ed., Dover
Publications, 1986.
[5] Herbert Goldstein, Charles Poole, and John Safko, Classical Mechanics, 3rd ed.,
Addison Wesley, 2002.