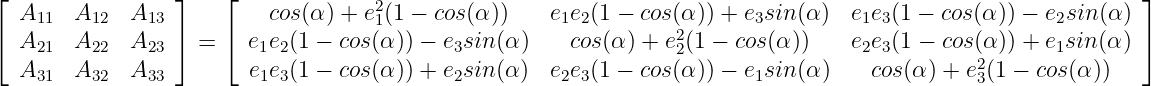Physics Library
 An open source physics library
Encyclopedia | Forums | Docs | Random  

axis angle of rotation to direction cosine matrix

(Definition)

For now, without proof you can get the direction cosine matrix (DCM) from the axis angle of rotation by

⌊ A11   A12  A13 ⌋    ⌊   cos(α ) + e2(1 − cos(α))   e1e2(1 − cos(α)) + e3sin (α)  e1e3(1 − cos (α )) − e2sin (α ) ⌋
⌈                ⌉    ⌈             1                            2                                            ⌉
  A21   A22  A23   =    e1e2(1 − cos(α)) − e3sin(α)    cos(α) + e2(1 − cos(α))    e2e3(1 − cos(2α)) + e1sin (α )
  A31   A32  A33        e1e3(1 − cos(α)) + e2sin(α)  e2e3(1 − cos(α)) − e1sin (α)    cos(α) + e3(1 − cos(α))
(1)


"axis angle of rotation to direction cosine matrix" is owned by bloftin.
(view preamble)
View style:
See Also: axis angle of rotation, axis angle of rotation to quaternions


Cross-references: axis angle of rotation, direction cosine matrix

This is version 4 of axis angle of rotation to direction cosine matrix, born on 2005-08-28, modified 2008-09-24.
Object id is 88, canonical name is AxisAngleOfRotationToDirectionCosineMatrix.
Accessed 3296 times total.

Classification:
Physics Classification: 45.40.-f (Dynamics and kinematics of rigid bodies)

Pending Errata and Addenda

None.

Discussion

No messages.

Interact