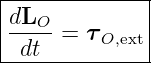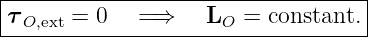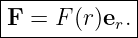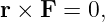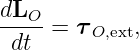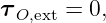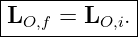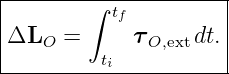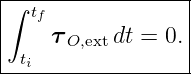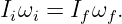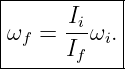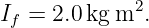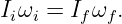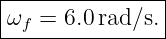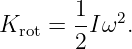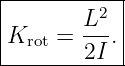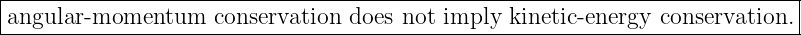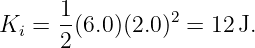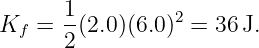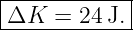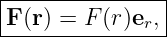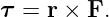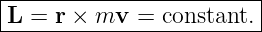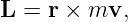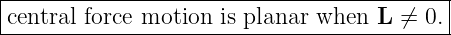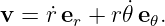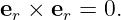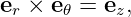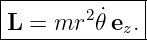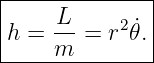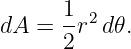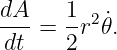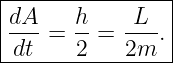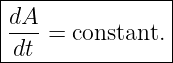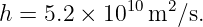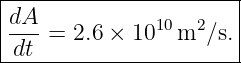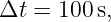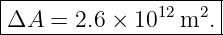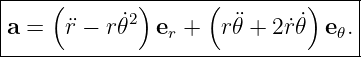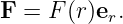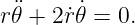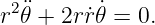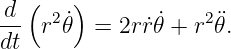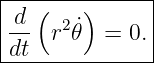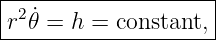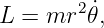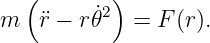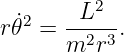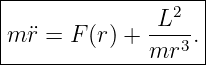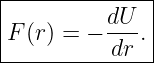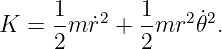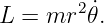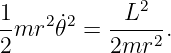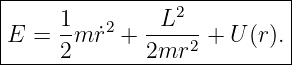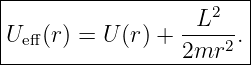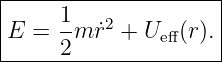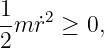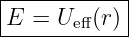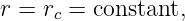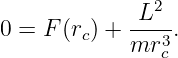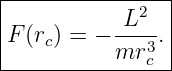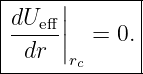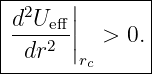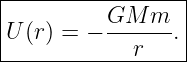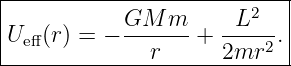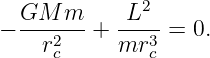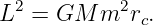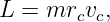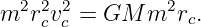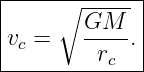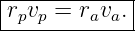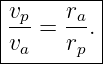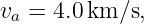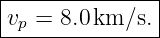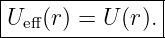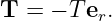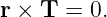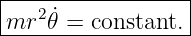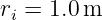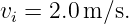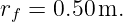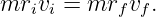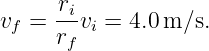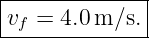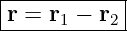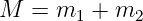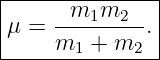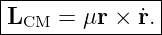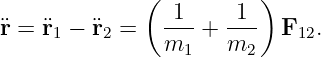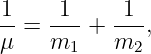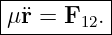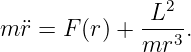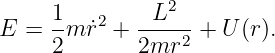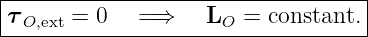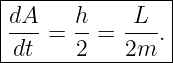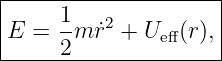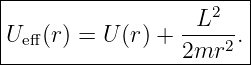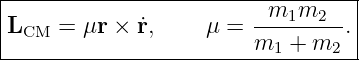Conservation of Angular Momentum and Central Force Motion
The previous article established the angular-momentum equation
for a particle system when internal torques cancel and O is a fixed point in an inertial
frame.
The immediate consequence is one of the fundamental conservation laws of mechanics:
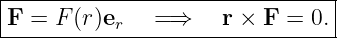
For a central force, the force is directed along the radius vector:
Therefore
so angular momentum about the force center is conserved.
This single fact leads to several major results:
- central force motion is planar,
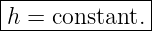
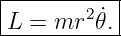
- mr2𝜃 is constant,
- equal areas are swept in equal times,
- radial and angular motion can be separated,
- the radial dynamics can be represented with an effective potential.
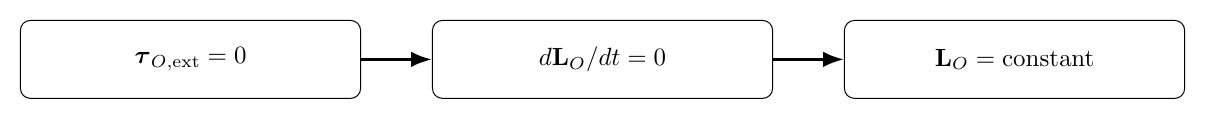
Figure 1. Zero net external torque about a chosen inertial origin implies constant total angular
momentum about that origin.
1 The conservation law
Starting from
if
then
Integrating,
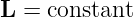
Because angular momentum is a vector, conservation means that both its magnitude and direction
remain constant.
2 Conservation about a chosen point
Angular momentum and torque must be computed about the same point.
A system may have zero torque about one point but nonzero torque about another.
Therefore the statement
is incomplete unless the reference point or axis is understood.
For a central force, the natural reference point is the force center.
For a rotating isolated system, the center of mass is often the most useful reference
point.
3 Angular impulse form
The finite-time relation is
Thus exact angular-momentum conservation over an interval requires zero net external angular
impulse:
The external torque does not have to vanish at every instant if its total angular impulse over the
interval is zero.
4 Redistribution of mass in an isolated rotating system
Angular momentum can remain constant while angular velocity changes.
For fixed-axis rotation about a principal axis,
If external torque is negligible,
Therefore
Reducing the moment of inertia increases angular speed.
Increasing the moment of inertia decreases angular speed.
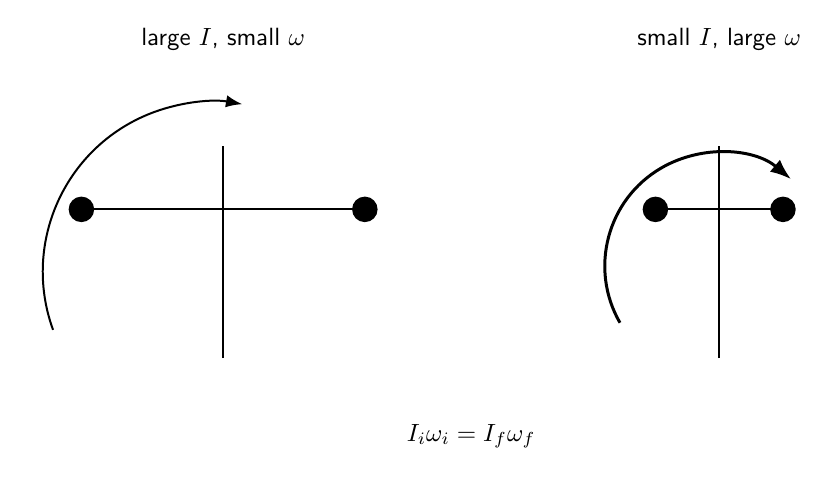
Figure 2. With negligible external torque, pulling mass inward decreases I and increases ω so that
L = Iω remains constant.
5 Example 1: contracting rotating system
A rotating system initially has
| Ii | = 6.0 kg m2, | (15)
|
| ωi | = 2.0 rad∕s. | (16) |
It changes configuration so that
With negligible external torque,
Thus
| ωf | =  ωi | (19)
|
| =  (2.0) | (20)
|
| = 6.0 rad∕s. | (21) |
Therefore
6 Angular momentum conservation does not imply kinetic-energy conservation
For fixed-axis rotation,
Using
we can write
If L is conserved while I decreases, the rotational kinetic energy increases.
The additional energy can come from internal work, such as muscular work in a person pulling
masses inward.
Thus:
7 Example 2: energy change during contraction
Use the system from Example 1.
Initial rotational kinetic energy:
Final rotational kinetic energy:
Therefore
Angular momentum is conserved, but kinetic energy increases because internal work is done while
changing the mass distribution.
8 Central forces
A force is central if it has the form
where
The force can point inward or outward, but it must lie along the line joining the particle to the
force center.
Examples include:
- Newtonian gravity from a fixed spherical source,
- electrostatic force between point charges,
- an ideal isotropic spring force F = −kr.
9 Central force implies zero torque
Torque about the force center is
For a central force,
Therefore
Hence
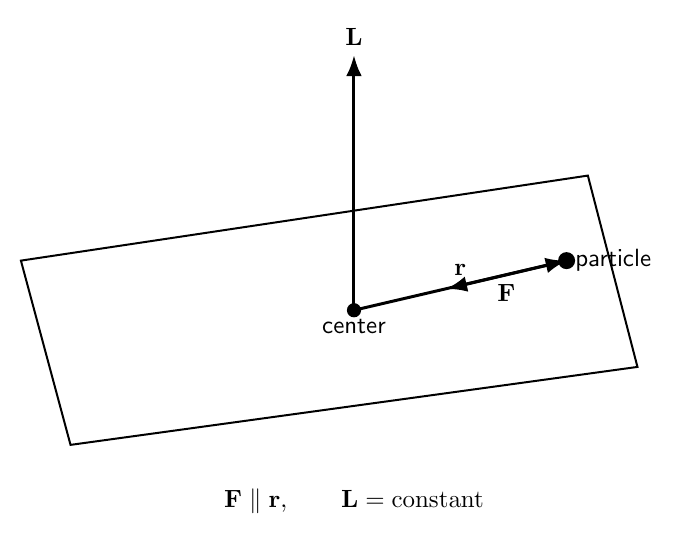
Figure 3. A central force lies along r, so its torque about the force center is zero. The conserved
angular-momentum vector is perpendicular to the orbital plane.
10 Central force motion is planar
Because
the vectors r and v are perpendicular to L.
If L is constant in direction, the motion remains in the plane perpendicular to L.
Thus:
If
the motion is purely radial and lies along a line through the force center.
11 Angular momentum in plane polar coordinates
For planar motion,
and
Then
| L | = mr × v | (41)
|
| = m × 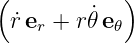 . | (42) |
The radial term vanishes:
Since
we obtain
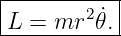
Thus the angular-momentum magnitude is
12 Specific angular momentum
Divide by particle mass:
The quantity h is called the specific angular momentum.
Its SI units are
For central force motion,
This notation is especially common in orbital mechanics.
13 Areal velocity and Kepler’s equal-areas law
During a small angular displacement d𝜃, the radius vector sweeps area
Divide by dt:
Using
we obtain
If angular momentum is conserved, areal velocity is constant:
Therefore equal areas are swept in equal times.
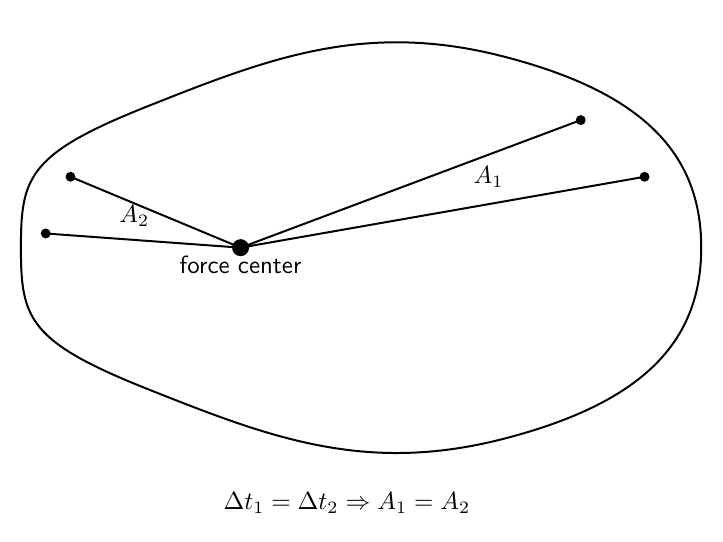
Figure 4. Conservation of angular momentum implies constant areal velocity. Equal time intervals
correspond to equal swept areas even when the particle speed changes.
14 Example 3: areal velocity
A satellite has specific angular momentum
Its areal velocity is
Therefore
In a time interval
the swept area is
15 Polar-coordinate equations of motion
The acceleration in Plane polar coordinates is
For a central force,
Therefore the tangential force component is zero:
Newton’s second law gives
m | = F(r), | (63)
|
m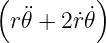 | = 0. | (64) |
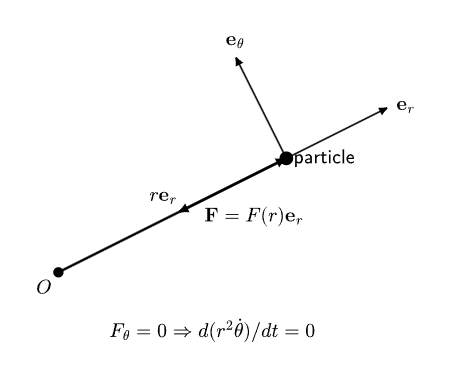
Figure 5. Central force motion separates naturally into radial and transverse directions. The
transverse equation is equivalent to angular-momentum conservation.
16 Deriving angular-momentum conservation from the transverse equation
The transverse equation is
Multiply by r:
Recognize the derivative
Thus
Therefore
which is exactly conservation of specific angular momentum.
17 Reducing the radial equation
From
we have
The radial equation is
Substitute the angular-momentum relation:
Therefore
The second term behaves like an outward radial contribution associated with the angular
motion.
It is not an additional fundamental force. It appears because the radial coordinate is being used to
describe motion with conserved angular momentum.
18 Conservative central forces
If the central force is conservative,
The kinetic energy is
Use
Then
Thus the total energy is
19 Effective potential
Define the effective potential
Then the energy equation becomes
This looks like a one-dimensional energy equation for radial motion.
The term
is often called the angular-momentum barrier or centrifugal barrier.
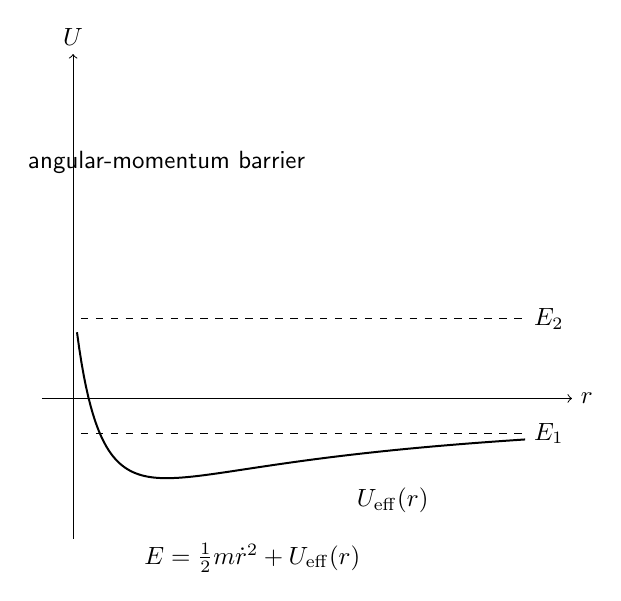
Figure 6. A conservative central force problem can be represented as one-dimensional radial
motion in an effective potential Ueff = U + L2∕(2mr2).
20 Turning points and apses
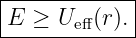
Because
the allowed radial region satisfies
A radial turning point occurs when
Therefore
at a radial turning point.
In orbital motion, radial turning points are called apses.
For a bound orbit:
- the minimum radius is periapsis,
- the maximum radius is apoapsis.
21 Circular orbit condition
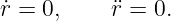
For a circular orbit,
so
The radial equation becomes
Thus
Equivalently, a circular orbit occurs at a stationary point of the effective potential:
A stable circular orbit corresponds locally to a minimum:
22 Newtonian gravity example
For a particle of mass m moving around a fixed mass M,
The effective potential is
The attractive gravitational term dominates at large enough radius, while the angular-momentum
barrier becomes increasingly important at small radius when L≠0.
For a circular orbit,
Therefore
Since
we obtain
Thus
23 Apsis speed relation
At periapsis and apoapsis,
The velocity is therefore purely transverse.
Angular momentum gives
Thus for two apses,
Therefore
The object moves faster at smaller radius.
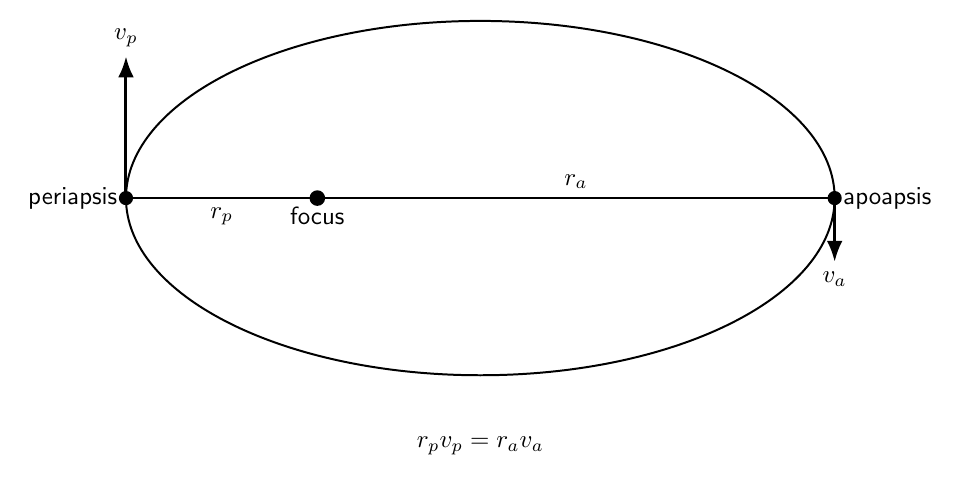
Figure 8. At periapsis and apoapsis the velocity is transverse, so conservation of angular
momentum gives rpvp = rava.
24 Example 4: speed change between apses
Suppose an orbit has
| rp | = 7.0 × 10⁶ m, | (104)
|
| ra | = 1.4 × 10⁷ m. | (105) |
If the apoapsis speed is
then
| vp | =  va | (107)
|
| = 2(4.0) | (108)
|
| = 8.0 km∕s. | (109) |
Thus
25 Radial motion as a special case
If
then
Away from r = 0,
The motion remains on a fixed radial line.
The effective potential reduces to the ordinary potential:
Thus the angular-momentum barrier is absent for purely radial motion.
26 Puck pulled through a central hole
Consider a puck moving on a frictionless horizontal table while a string passes through a small hole
at the origin.
The string tension is radial:
Therefore the torque about the hole is zero:
Hence
If the string is pulled inward and r decreases, the angular speed increases.
Unlike an isolated skater example, an external agent pulling the string can do work, so the puck’s
kinetic energy need not remain constant.
27 Example 5: puck radius change
A puck moves at radius
with tangential speed
It is slowly pulled inward until
At the instant considered, assume the motion is again purely transverse.
Angular momentum gives
Thus
Therefore
The kinetic energy increases by a factor of four because the external pulling agent does
work.
28 Two-body central force systems
Consider two particles with masses m1 and m2 interacting only through equal-and-opposite central
forces.
Define
as the relative position.
Let
and define the reduced mass
In the center-of-mass frame,
| ρ1 | =  r, | (127)
|
| ρ2 | = − r. | (128) |
The internal angular momentum about the center of mass becomes
Thus the two-body problem can be represented by a single effective particle of mass μ moving in
the relative coordinate.
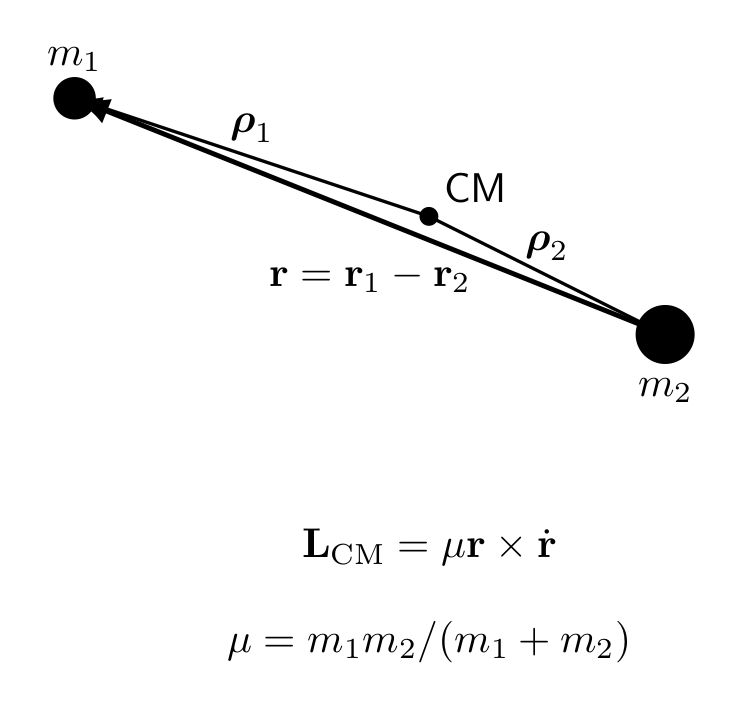
Figure 7. A two-body central force system separates into center-of-mass translation and relative
motion. The relative motion behaves like a particle of reduced mass μ.
29 Relative equation of motion
Let F12 be the force on particle 1 due to particle 2.
Then
| m1r1 | = F12, | (130)
|
| m2r2 | = −F12. | (131) |
Subtract:
Since
we obtain
This result is developed more fully in M04-09.
30 Conservation law versus symmetry
Angular momentum is conserved whenever the appropriate external torque vanishes.
For a central force, this occurs because the force has rotational symmetry about the center: there is
no preferred direction in space, only a dependence on radius.
At a more advanced level, rotational symmetry and angular-momentum conservation are connected
by Noether’s theorem.
The present Newtonian derivation reaches the conservation law directly through torque.
31 Common mistakes
- Conserving angular momentum without stating the point or axis about which torque
is zero.
- Assuming angular-momentum conservation implies kinetic-energy conservation.
- Using Iiωi = Ifωf when a significant external torque acts.
- Treating the effective angular-momentum term L2∕(mr3) as a new fundamental force.
- Forgetting that central force motion is planar because the direction of L is constant.
- Forgetting the factor 1∕2 in the areal-velocity relation.
- Using rv = constant at arbitrary points of an orbit when the velocity is not
perpendicular to r.
- At arbitrary points, replacing L = mrv sin 𝜃 with L = mrv.
- Confusing specific angular momentum h = L∕m with ordinary angular momentum.
- Forgetting that Ueff includes both the physical potential U(r) and the
angular-momentum barrier.
- Setting a circular-orbit condition using F = 0 instead of balancing the radial dynamics.
- Assuming an external radial force cannot do work. A radial force does no torque about
the center, but it can do work when radial displacement occurs.
- Applying single-particle mass m instead of reduced mass μ when using the relative
coordinate for a genuine two-body problem.
32 Practice exercises
- A rotating system changes its moment of inertia from 8 kg m2 to 2 kg m2 with negligible
external torque. If ωi = 1.5 rad∕s, find ωf.
- For the preceding problem, compare the initial and final rotational kinetic energies.
- Prove that a central force produces zero torque about the force center.
- Starting from plane polar velocity, derive L = mr2𝜃.
- Define specific angular momentum and derive h = r2𝜃.
- Derive the equal-areas relation dA∕dt = L∕(2m).
- Starting from the transverse polar equation, derive d(r2𝜃)∕dt = 0.
- Use angular-momentum conservation to eliminate 𝜃 from the radial equation and
derive
- For a conservative central force, derive
- Explain the physical meaning of the effective potential and the angular-momentum
barrier.
- Derive the circular-orbit condition from dUeff∕dr = 0.
- For Newtonian gravity, derive vc =
 .
- At two apses of a bound orbit, derive rpvp = rava.
- A puck is pulled from radius 1.2 m to 0.40 m. If its initial transverse speed is 1.5 m∕s and
torque about the hole is zero, find the final transverse speed.
- Derive LCM = μr ×r for a two-body system.
33 Summary
Angular momentum is conserved when net external torque about the chosen reference point
vanishes:
For a central force,
Thus central force motion has conserved angular momentum:
The specific angular momentum is
The areal velocity is
For a conservative central force,
with
For two-body central force motion,
M04-09 develops the two-body reduction and relative-coordinate dynamics in detail.
References
References
[1] J. R. Taylor, Classical Mechanics, University Science Books, 2005.
[2] D. Kleppner and R. Kolenkow, An Introduction to Mechanics, 2nd ed., Cambridge
University Press, 2014.
[3] H. Goldstein, C. Poole, and J. Safko, Classical Mechanics, 3rd ed., Addison-Wesley,
2002.
[4] K. R. Symon, Mechanics, 3rd ed., Addison-Wesley, 1971.
[5] OpenStax, University Physics, Volume 1, Rice University, 2016.