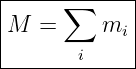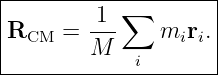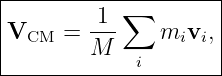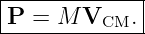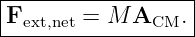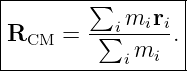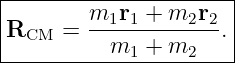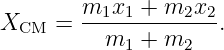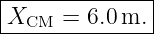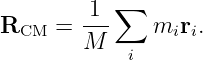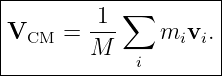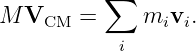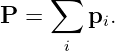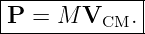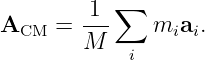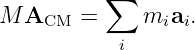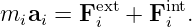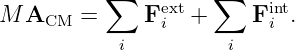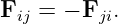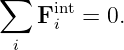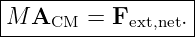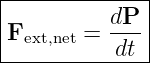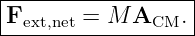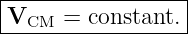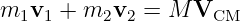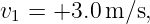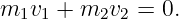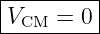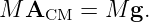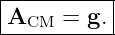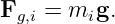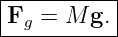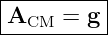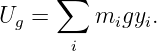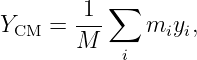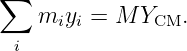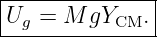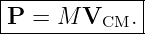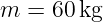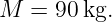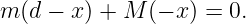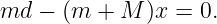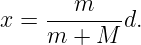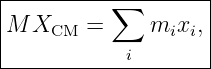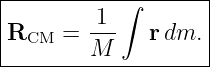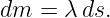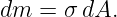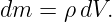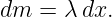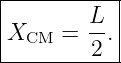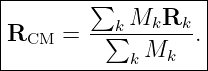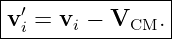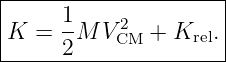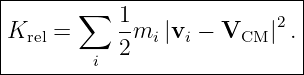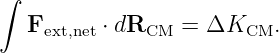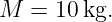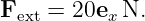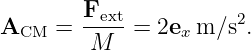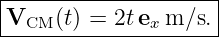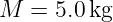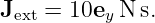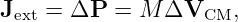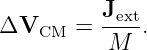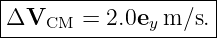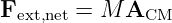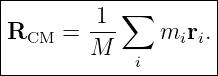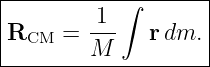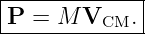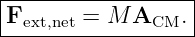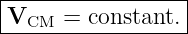Center of Mass Motion and System Dynamics
A many-particle system can contain complicated internal motion, yet one special point often moves
according to a remarkably simple equation.
That point is the center of mass.
For particles with masses mi at positions ri, define the total mass
and the center of mass position
For a fixed-mass system, differentiating gives
and therefore
Differentiating once more,
Thus the center of mass moves as though the entire system mass were concentrated there and
acted on by the net external force, as far as translational motion is concerned.
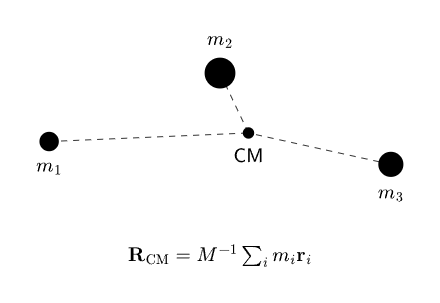
Figure 1. The center of mass is the mass-weighted average position of all particles in the system.
1 Discrete-particle definition
For N particles,
In Cartesian components,
| XCM | =  ∑
imixi, | (7)
|
| Y CM | =  ∑
imiyi, | (8)
|
| ZCM | =  ∑
imizi. | (9) |
Each coordinate is a mass-weighted average.
Particles with greater mass contribute more strongly to the center of mass location.
2 Two-particle center of mass
For two particles,
In one dimension,
If
the center of mass lies closer to particle 2.
3 Example 1: two particles on a line
Let
| m1 | = 2.0 kg, | x1 | = 0, | (13)
|
| m2 | = 3.0 kg, | x2 | = 10 m. | (14) |
Then
| XCM | = 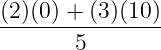 | (15)
|
| = 6.0 m. | (16) |
Thus
The center of mass lies closer to the 3.0 kg particle.
4 The center of mass need not lie inside matter
The center of mass is a weighted geometric point, not necessarily a material point.
Examples include:
- a ring, whose center of mass lies at its empty geometric center,
- a hollow sphere,
- two separated particles,
- a curved wire,
- a rigid body with a cavity.
The center of mass can lie in empty space.
5 Center of mass velocity
For constant particle masses,
Differentiate:
Therefore
Multiply by M:
The right side is the total momentum:
Hence
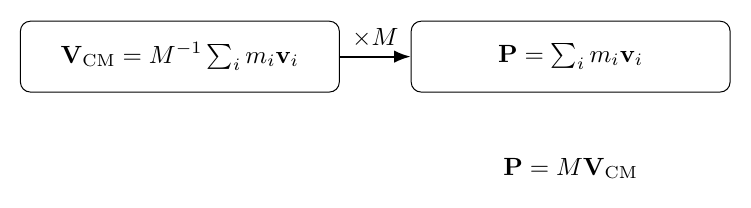
Figure 2. Total system momentum equals total mass times center of mass velocity. Internal
motions can change while this relation remains exact.
6 Center of mass acceleration
Differentiate the velocity:
Multiply by M:
Using Newton’s second law for each particle,
Thus
For ordinary Newtonian internal-force pairs,
Therefore the internal forces cancel in the total:
Hence
7 System dynamics equation
The center of mass equation can be written in two equivalent forms:
and, for fixed total mass,
This is the system analogue of
It describes the translational motion of the system as a whole.
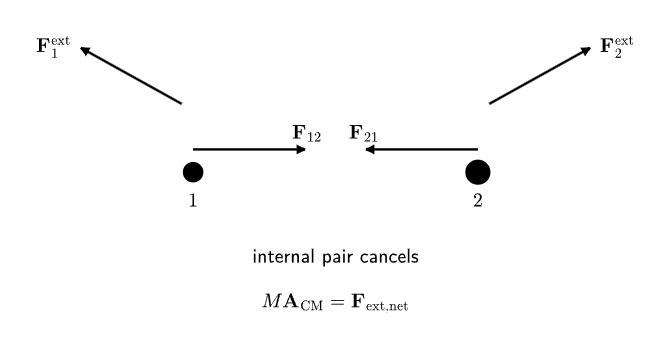
Figure 3. Internal force pairs cancel from the total translational equation. Only the net external
force accelerates the center of mass.
8 Internal forces cannot accelerate the center of mass
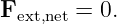
Suppose a system is isolated:
Then
Therefore
Internal forces can:
But they cannot change the center of mass velocity of an isolated fixed-mass system.
9 Internal rearrangement and center of mass motion
Consider two masses connected by an internal spring.
When the spring expands or contracts, both masses accelerate.
Their individual velocities change, yet
remains constant if no external force acts.
Thus the masses can move relative to the center of mass while the center of mass moves
uniformly.
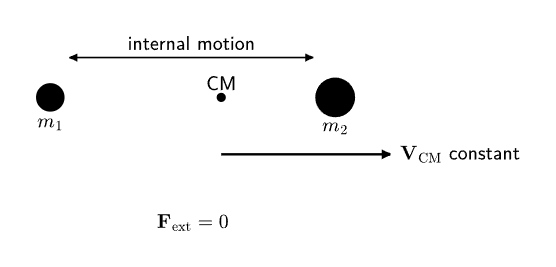
Figure 4. Internal motion can change particle positions relative to the center of mass without
changing the center of mass velocity of an isolated system.
10 Example 2: recoil and the center of mass
Two skaters initially stand at rest on frictionless ice.
Let
| m1 | = 50 kg, | (39)
|
| m2 | = 75 kg. | (40) |
Initially,
They push apart.
If skater 1 moves at
then
Thus
| v2 | = − v1 | (44)
|
| = − (3.0) | (45)
|
| = −2.0 m∕s. | (46) |
The skaters separate, but
throughout.
11 Explosion and center of mass trajectory
Suppose a projectile follows a parabolic trajectory under gravity and then explodes internally into
fragments.
Neglect air resistance.
The explosion produces large internal forces, but the only external force remains gravity.
Therefore
Hence
The center of mass continues along the same parabolic trajectory that the unexploded object
would have followed.
The fragments spread apart around that trajectory.
12 Uniform gravity and the center of mass
For particles in a uniform gravitational field,
The total gravitational force is
| Fg | = ∑
imig | (51)
|
| =  g. | (52) |
Thus
The center of mass therefore accelerates as
if gravity is the only external force.
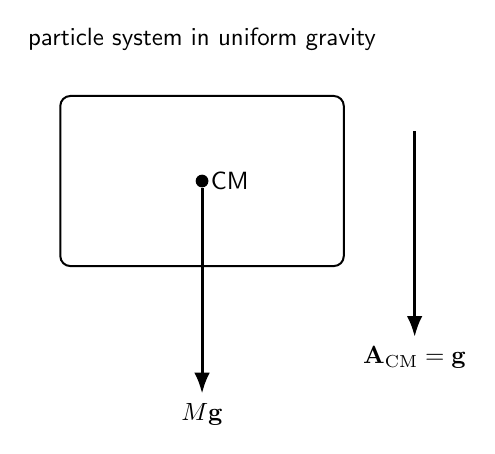
Figure 5. In a uniform gravitational field, the translational motion of a particle system is
equivalent to a mass M acted on by Mg at the center of mass level.
13 Gravitational potential energy in a uniform field
The total gravitational potential energy is
Using
we obtain
Therefore
This is another example of the center of mass capturing the translational behavior of a
system.
14 The center of mass and rigid body translation
For a rigid body, the center of mass is fixed relative to the body’s material geometry.
The rigid body can:
- translate,
- rotate about its center of mass,
- translate and rotate simultaneously.
Its total linear momentum is still
Rotation about the center of mass does not change the total linear momentum.
This separation between center of mass translation and motion relative to the center of mass is
fundamental to rigid body mechanics.
15 Example 3: person walking on a free cart
A person of mass
stands on a cart of mass
The cart can roll freely on a horizontal frictionless track.
The person walks
to the right relative to the cart.
Let the cart move a distance x to the left relative to the ground.
Then the person’s displacement relative to the ground is
With no horizontal external force, the center of mass position remains fixed:
Thus
Therefore
Numerically,
| x | =  (3.0) | (67)
|
| = 1.2 m. | (68) |
Thus the cart moves
to the left.
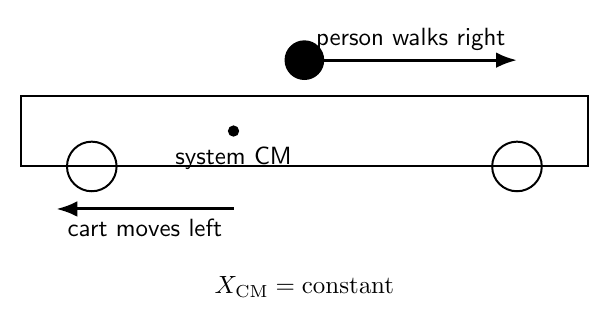
Figure 6. With no external horizontal force, a person walking across a free cart causes the cart to
recoil so that the horizontal center of mass remains fixed.
16 Why the person-cart problem is not a momentum-only problem
Momentum conservation implies
at every instant if the system starts from rest and no horizontal external force acts.
However, the requested quantity is usually a displacement.
The position form of the center of mass relation,
is therefore more direct.
Momentum conservation and fixed center of mass position are two related descriptions of the same
isolated translational dynamics.
17 Continuous mass distributions
For a continuous body,
becomes an integral:
In Cartesian coordinates,
| XCM | =  ∫
xdm, | (74)
|
| Y CM | =  ∫
y dm, | (75)
|
| ZCM | =  ∫
z dm. | (76) |
The mass element can be written using an appropriate density.
For a line,
For a surface,
For a volume,
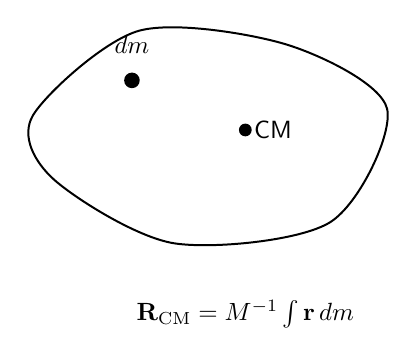
Figure 7. For a continuous mass distribution, the discrete mass-weighted sum becomes the
integral RCM = M−1 ∫
rdm.
18 Example 4: uniform rod
A uniform rod has length L and linear density
Place the rod along the x axis from
to
Then
The center of mass is
| XCM | =  ∫
0Lxdm | (84)
|
| =  ∫
0Lxλdx | (85)
|
| =   0L | (86)
|
| =   . | (87) |
Therefore
Symmetry predicts the same result immediately.
19 Symmetry as a center of mass tool
If a mass distribution has a symmetry plane, the center of mass lies in that plane.
If it has a symmetry axis, the center of mass lies on that axis.
Examples:
- uniform rod: midpoint,
- uniform disk: geometric center,
- uniform sphere: geometric center,
- uniform rectangular block: geometric center.
Symmetry can eliminate one or more integrals.
20 Composite systems
A complicated object can often be divided into simpler pieces.
If piece k has mass Mk and center of mass Rk, then the complete center of mass is
Each piece can therefore be treated as if its mass were concentrated at its own center of mass for
the purpose of locating the overall center of mass.
21 Cavities and negative-mass bookkeeping
A cavity can be handled mathematically by superposition.
One may:
- begin with the complete solid body,
- represent the removed region as a piece with negative mass,
- compute the combined mass-weighted position.
The negative mass is only a bookkeeping device. It does not represent physical negative
matter.
22 Center of mass frame
Define the center of mass frame as the inertial frame moving with velocity
relative to the laboratory frame.
For particle i,
Then
| ∑
imivi′ | = ∑
imi(vi − VCM) | (92)
|
| = P − MVCM | (93)
|
| = 0. | (94) |
Thus
in the center of mass frame.
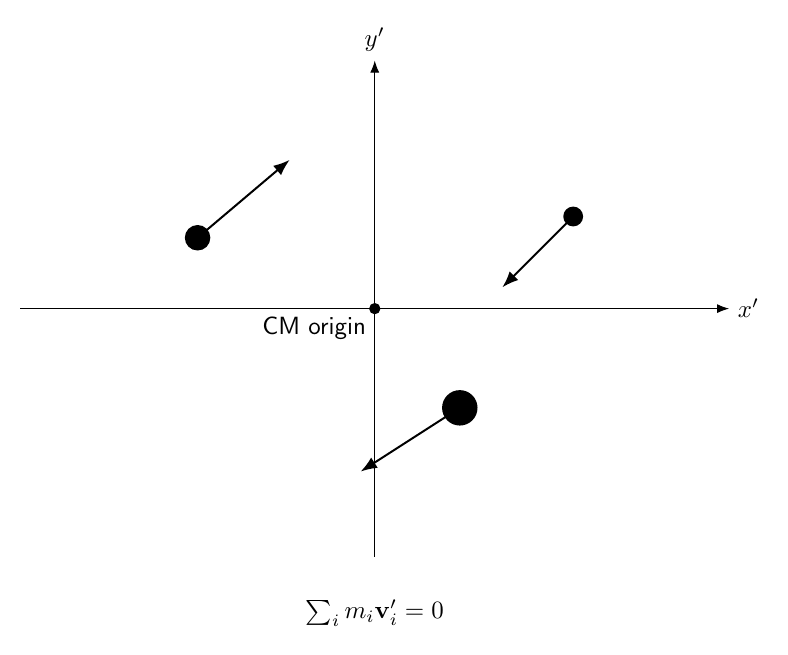
Figure 8. In the center of mass frame, the total momentum is zero even though individual
particles may move relative to the center of mass.
23 Kinetic-energy decomposition
The particle-system kinetic energy can be decomposed into center of mass and relative
parts:
The relative part is
This relation was developed in M03-08.
It shows that system kinetic energy naturally separates into:
- translation of the center of mass,
- internal or relative motion about the center of mass.
24 External work versus center of mass motion
The center of mass equation determines
through
This center of mass pseudowork is not generally the same as the total actual external work on a
multi-particle system.
Actual external work can also change:
Thus system dynamics and system energy bookkeeping answer related but distinct questions.
25 Example 5: constant external force on a system
A system has total mass
The net external force is constant:
Then
If the center of mass starts at rest,
The individual particles can have complicated internal motions, but those motions do not alter this
center of mass acceleration.
26 Example 6: external impulse and center of mass velocity
A system of total mass
receives external impulse
Since
we obtain
Thus
27 System boundary remains essential
The center of mass equations apply to the chosen system.
If a person and cart are both inside the system boundary, their mutual forces are internal.
If only the cart is chosen as the system, the person’s force on the cart is external.
The same physical interaction can therefore be internal or external depending on the system
definition.
A correct system boundary is part of the physics, not merely bookkeeping.
28 Fixed-mass limitation
The simple form
used here assumes a fixed set of particles with constant total mass.
If mass crosses the system boundary, momentum is transported with that mass.
Then an open-system momentum balance is required.
Rockets, leaking containers, and jets therefore need additional terms beyond the fixed-mass center
of mass equation.
That is the subject of M04-06.
29 Common mistakes
- Using an ordinary arithmetic average instead of a mass-weighted average.
- Assuming the center of mass must lie inside the material.
- Forgetting that P = MVCM is a vector equation.
- Allowing internal forces to accelerate the center of mass of an isolated fixed-mass
system.
- Confusing motion relative to the center of mass with motion of the center of mass.
- Forgetting that an explosion can change fragment velocities without changing the
center of mass trajectory.
- Treating the center of mass as a physical particle that must coincide with material.
- Forgetting that gravity gives Fg = Mg only when the field is effectively uniform over
the system.
- Using laboratory-frame velocities in some terms and center of mass-frame velocities in
others.
- Confusing actual external work with center of mass pseudowork.
- Applying fixed-mass formulas directly to an open variable-mass system.
- Using “rigid body” motion to imply that the center of mass cannot translate and rotate
simultaneously with the body.
30 Practice exercises
- Two particles of masses 2 kg and 5 kg are located at x = 1 m and x = 8 m. Find XCM.
- Three particles have masses m, 2m, and 3m at positions (0, 0), (3, 0), and (0, 4). Find
the center of mass coordinates.
- Derive P = MVCM from the discrete center of mass definition.
- Derive Fext,net = MACM for a fixed-mass particle system.
- Explain why internal forces can change individual particle momenta while leaving total
momentum unchanged.
- Two skaters push apart from rest. Show directly that their center of mass position
remains fixed.
- A projectile explodes in flight. Explain why its center of mass follows the original
ballistic trajectory when air resistance is neglected.
- Prove that the total gravitational potential energy in a uniform field is MgY CM.
- A 50 kg person walks 4.0 m relative to a 100 kg free cart. Find the cart displacement
relative to the ground.
- Derive the center of mass of a uniform rod using integration.
- Find the center of mass of two uniform rods treated as composite pieces with known
individual centers of mass.
- Show that total momentum is zero in the center of mass frame.
- Explain why a rotating rigid body can have zero center of mass velocity but nonzero
kinetic energy.
- A 12 kg system experiences a constant external force 36ex N. Find its center of mass
acceleration.
- A 4 kg system receives impulse (−6ex + 8ey) N s. Find the change in center of mass
velocity.
31 Summary
The center of mass of a discrete system is
For a continuous distribution,
For a fixed-mass system,
The translational system dynamics are governed by
If the net external force vanishes,
Internal forces can change relative motion but cannot accelerate the center of mass of an isolated
fixed-mass system.
In the center of mass frame,
These results provide the foundation for the next topic: systems in which mass crosses the chosen
boundary.
References
References
[1] J. R. Taylor, Classical Mechanics, University Science Books, 2005.
[2] D. Kleppner and R. Kolenkow, An Introduction to Mechanics, 2nd ed., Cambridge
University Press, 2014.
[3] K. R. Symon, Mechanics, 3rd ed., Addison-Wesley, 1971.
[4] H. D. Young and R. A. Freedman, University Physics with Modern Physics, 15th ed.,
Pearson, 2020.
[5] OpenStax, University Physics, Volume 1, Rice University, 2016.