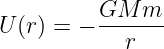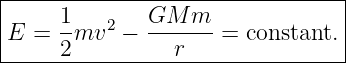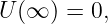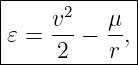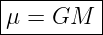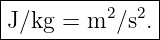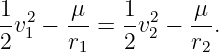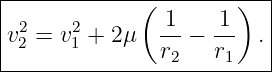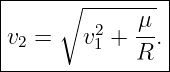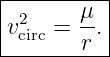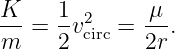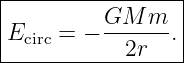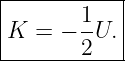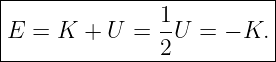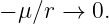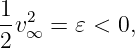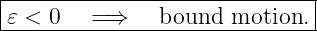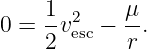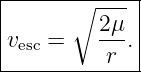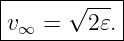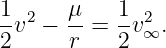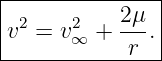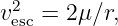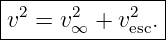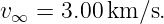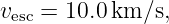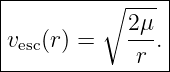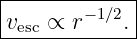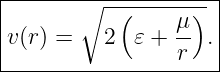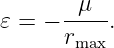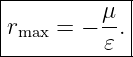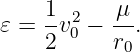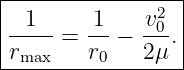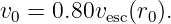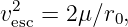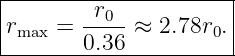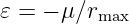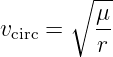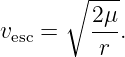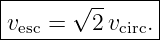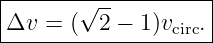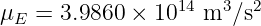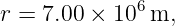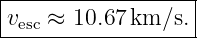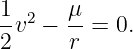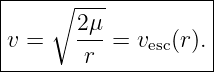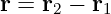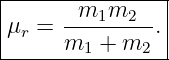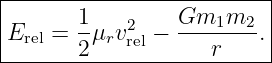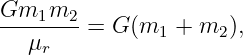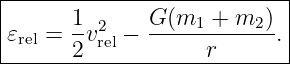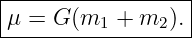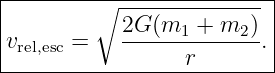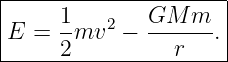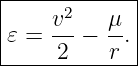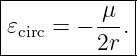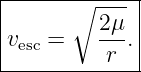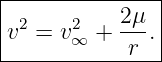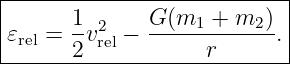Orbital Energy, Escape Speed, and Bound versus Unbound Motion
M07-04 introduced the gravitational potential energy
for a test mass
moving outside a spherical source mass
If no nongravitational work is done, the total mechanical energy is conserved:
The sign of this conserved energy immediately classifies gravitational motion.
With the usual reference
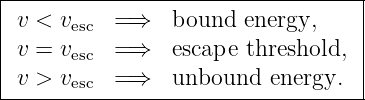
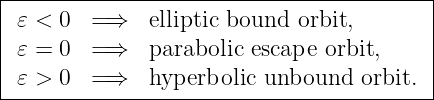
corresponds to bound motion,
is the escape threshold, and
corresponds to unbound motion.
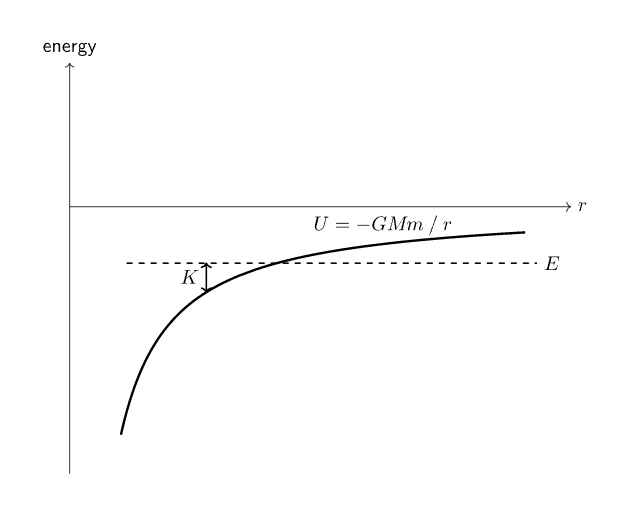
Figure 1. Gravitational motion can be interpreted using the potential U = −GMm∕r and a
horizontal total-energy level. The kinetic energy at any radius is the vertical difference K = E −U.
1 Specific orbital energy
The total energy scales with the orbiting test mass.
Divide by
to define the specific orbital energy:
Then
where
is the gravitational parameter of the central body in the one-body approximation.
The units of
are
Specific energy is especially useful because it removes the test mass from the orbital
dynamics.
2 Energy conservation between two radii
At two locations on the same trajectory,
Therefore
This equation is valid whenever gravity is the only force doing work.
It does not require circular motion.
3 Example 1: falling inward
Suppose an object moves from
to
and has initial speed
Then
| v22 | = v
12 + 2μ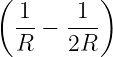 | (20)
|
| = v12 +  . | (21) |
Thus
The speed increases because gravitational potential energy becomes kinetic energy.
4 Circular orbit energy
For a circular orbit of radius
M07-01 gave
The specific kinetic energy is
The specific potential energy is
Therefore the total specific energy is
The total orbital energy is
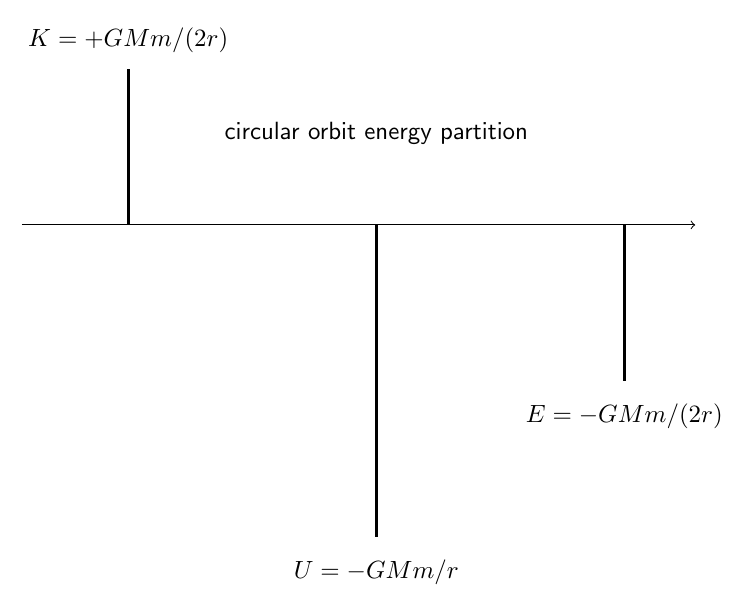
Figure 2. In a circular orbit, the kinetic energy is +GMm∕(2r), the potential energy is −GMm∕r,
and the total energy is −GMm∕(2r).
5 A useful circular-orbit relation
For a circular orbit,
Therefore
These relations apply to the inverse-square circular orbit.
They should not be assumed for an arbitrary instantaneous point on a noncircular trajectory.
6 Bound motion
Suppose
At infinity,
Energy conservation would require
which is impossible for a real speed.
Therefore a negative-energy trajectory cannot reach infinity.
It is gravitationally bound:
In the ideal inverse-square two-body problem, noncollision bound orbits are ellipses, with the circle
as a special case.
The conic-orbit derivation will appear later in the M07 sequence.
7 Escape threshold
At the threshold of escape, the body reaches infinity with zero remaining speed.
Thus
and
At radius
Therefore
This result was introduced in M07-04. Here its role as the energy boundary between bound and
unbound motion is central.
8 Unbound motion
If
the object can reach infinity and retain nonzero speed.
At infinity,
Define the hyperbolic excess speed
Then
The name comes from the hyperbolic orbit that appears in the ideal inverse-square scattering
problem.
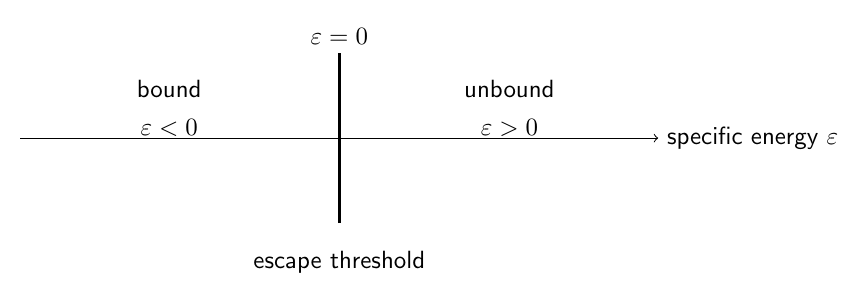
Figure 3. The zero of total energy separates bound from unbound gravitational motion. Negative
energy is bound, zero energy is the escape threshold, and positive energy leaves a nonzero speed
at infinity.
9 Local speed for an unbound trajectory
For positive specific energy,
Hence
Since
This is a very useful relation for unbound trajectories.
10 Example 2: unbound arrival speed
Suppose a body approaches a planet with
At a radius where the local escape speed is
its speed is
| v | = 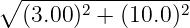 km∕s | (51)
|
| = 10.44 km∕s. | (52) |
Gravity increases the speed above the asymptotic value.
11 Escape speed versus radius
The escape speed decreases with radius:
Thus
Doubling the radius reduces escape speed by
Quadrupling the radius reduces escape speed by
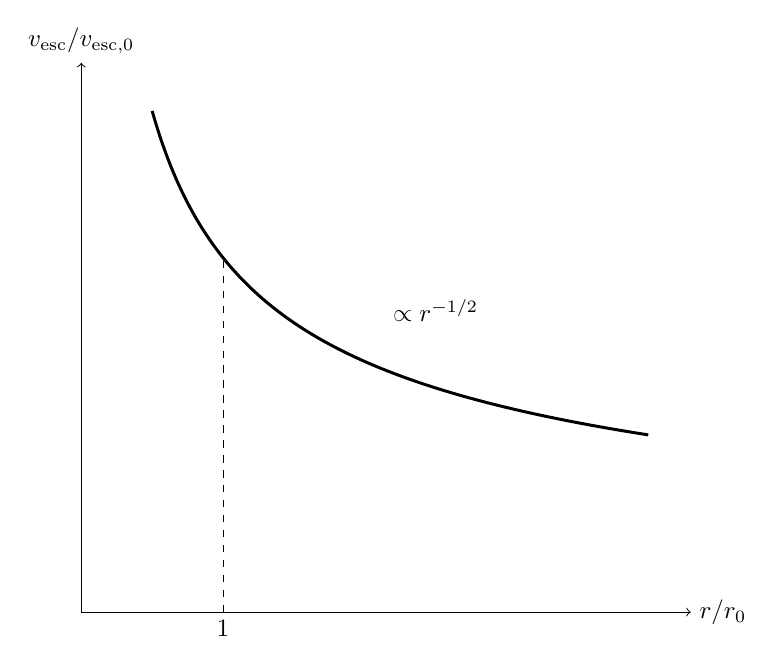
Figure 4. Escape speed decreases as r−1∕2. The curve is normalized to the escape speed at a
reference radius r0.
12 Energy classification at one location
At a given radius
compare the instantaneous speed with local escape speed.
If
then
If
then
If
then
Thus
The trajectory shape still depends on the velocity direction and angular momentum.
Energy alone classifies bound versus unbound behavior.
13 Speed-radius curves for fixed energy
Solve the specific-energy equation for speed:
For
this reduces to escape speed.
For
the speed approaches
at infinity.
For
the expression cannot remain real to arbitrarily large
That is another way to see the existence of a finite outer turning radius for purely radial bound
motion.
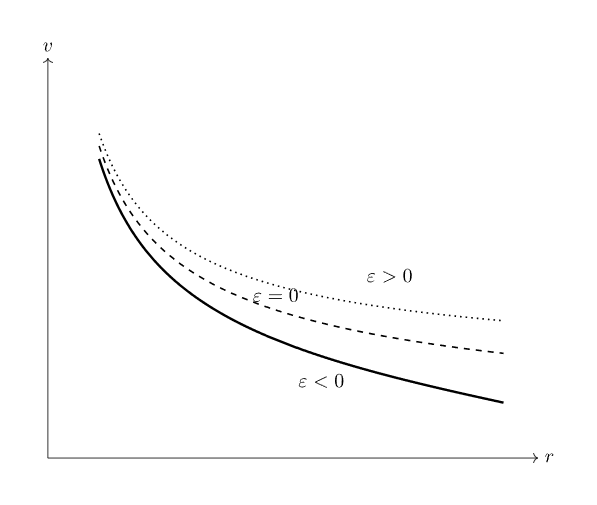
Figure 5. Speed as a function of radius for representative negative, zero, and positive specific
energies. The zero-energy curve is the escape-speed curve.
14 Radial motion and turning points
Now consider purely radial motion.
At an outer turning point,
Then
Therefore a radial trajectory with
has
If the initial radius and speed are
then
Thus
15 Example 3: radial launch below escape speed
Let
Since
| 𝜀 | =  (0.80)2  −  | (80)
|
| = −0.36 . | (81) |
Therefore
The object rises to a finite radius and then falls back in the ideal radial problem.
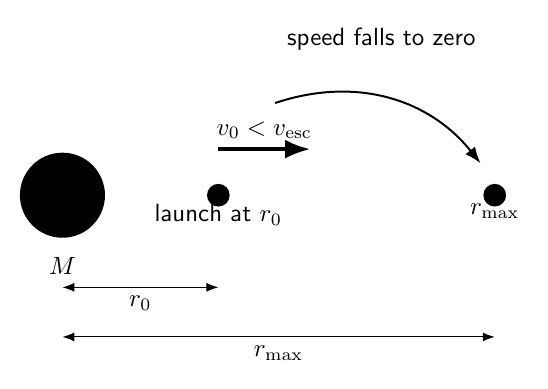
Figure 6. A purely radial launch below escape speed has negative energy and reaches a finite
outer turning radius where its speed becomes zero.
16 Why radial turning points are a special case
For nonzero angular momentum, a turning point in radius does not imply that the total speed is
zero.
At periapsis or apoapsis, the radial velocity is zero but the tangential velocity is generally
nonzero.
Therefore the simple relation
applies only to purely radial motion.
M07-06 will introduce the effective potential that incorporates angular momentum and treats
general radial turning points correctly.
17 Circular orbit versus escape at the same radius
At radius
and
Therefore
If an object is initially in a circular orbit and receives an instantaneous prograde speed change
at that same point, the ideal speed increment required to reach the escape threshold
is
This statement assumes the impulse changes only the velocity instantaneously and neglects other
bodies and nongravitational forces.
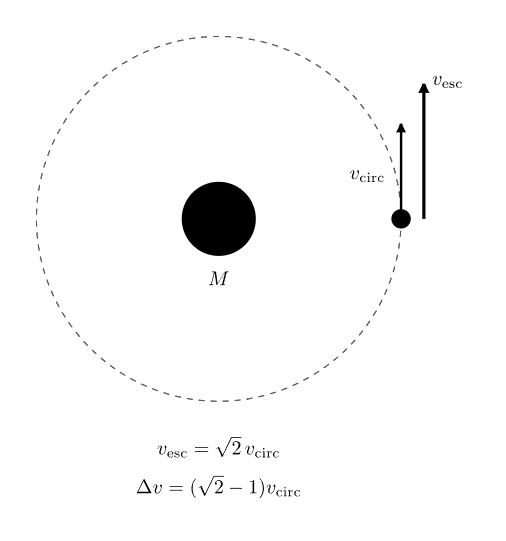
Figure 7. At a fixed radius, escape speed is  times circular speed. Raising a circular-orbit speed
to the local escape value moves the total energy to the E = 0 threshold.
18 Example 4: circular orbit energy near Earth
Using
at
the circular speed is
| vcirc | =  | (91)
|
| ≈ 7.55 km∕s. | (92) |
The escape speed at the same radius is
The specific circular energy is
| 𝜀circ | = − | (94)
|
| ≈−2.85 × 10⁷ J∕kg. | (95) |
19 Energy of an object falling from rest at infinity
Suppose an object starts at infinity with negligible speed.
Then
At radius
Therefore
Thus the speed acquired by falling from rest at infinity equals the local escape speed.
This follows from time-reversal symmetry of the conservative trajectory.
20 Bound does not mean circular
A negative-energy orbit need not be circular.
The object may move through a range of radii with both radial and tangential velocity.
Energy determines whether infinity is energetically accessible.
Angular momentum determines additional geometric features of the trajectory.
The full orbit therefore requires both:
- energy,
- angular momentum.
21 Unbound does not mean purely radial
Likewise, positive energy does not imply radial escape.
An unbound trajectory may pass around the central mass and depart in a different
direction.
In the ideal inverse-square problem, positive-energy noncollision trajectories are hyperbolas.
The energy sign gives the broad classification, while angular momentum fixes the impact geometry
and periapsis distance.
22 Exact two-body energy
So far we have used the one-body approximation in which
is treated as fixed.
For two finite masses
and
define the relative position
and relative speed
Define the reduced mass
Then the relative mechanical energy is
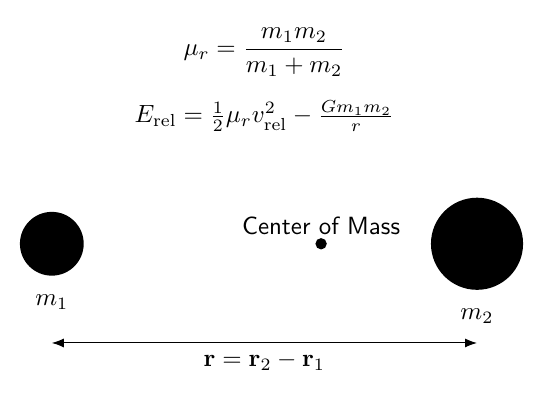
Figure 8. The exact two-body problem separates into center of mass motion plus relative motion.
The relative coordinate behaves like a particle of reduced mass moving in an inverse-square
gravitational interaction.
23 Exact specific relative energy
Divide
by
Since
the specific relative energy is
Thus the exact two-body gravitational parameter is
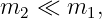
When
this reduces to
24 Exact two-body escape speed
The relative escape threshold satisfies
Therefore
The familiar
formula is the large-central-mass approximation to this exact relative result.
25 Energy sign and conic classification
For the ideal Newtonian inverse-square two-body problem,
A circle is a special ellipse.
This classification will be derived geometrically from the orbit equation later.
At this stage, the energy argument already establishes the bound versus unbound distinction.
26 Common mistakes
- Forgetting the negative gravitational potential-energy term in the orbital energy.
- Confusing total energy E with specific energy 𝜀 = E∕m.
- Using GM∕r2 where the energy formula requires GM∕r.
- Assuming negative energy means circular motion.
- Assuming positive energy means radial motion.
- Forgetting that the zero-energy case is the escape threshold.
- Treating escape speed as a constant independent of radius.
- Forgetting that vesc =
 vcirc only compares speeds at the same radius.
- Using a radial turning-point formula for an orbit with nonzero angular momentum.
- Assuming the total speed is zero at apoapsis.
- Forgetting that v∞ is the speed remaining at infinite separation.
- Using v2 = v
∞2 + v
esc2 for a negative-energy trajectory.
- Confusing the gravitational parameter μ with the reduced mass μr.
- Using μ = GM for an exact two-body problem when both masses are dynamically
important.
- Forgetting that energy classification alone does not determine the complete orbit
geometry.
27 Practice exercises
- Derive the specific orbital-energy equation from total mechanical energy.
- Derive the two-radius speed relation from energy conservation.
- Derive the circular-orbit total and specific energies.
- Show that a negative-energy trajectory cannot reach infinity.
- Derive escape speed by imposing 𝜀 = 0.
- Show that positive specific energy equals v∞2∕2.
- Derive v2 = v
∞2 + v
esc2.
- Show that escape speed scales as r−1∕2.
- For purely radial bound motion, derive rmax = −μ∕𝜀.
- Reproduce the v0 = 0.80vesc radial-turning-point example.
- Derive the speed increment (
 − 1)vcirc from circular orbit to local escape threshold.
- Reproduce the circular speed, escape speed, and specific energy at r = 7.00 × 10⁶ m
around Earth.
- Show that falling from rest at infinity produces the local escape speed.
- Derive the exact two-body relative energy using reduced mass.
- Derive the exact relative escape speed
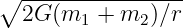 .
28 Summary
For motion in a fixed spherical gravitational field,
The specific orbital energy is
For a circular orbit,
The energy sign classifies the motion:
The local escape speed is
For unbound motion,
For exact relative two-body motion,
Energy determines whether a gravitational trajectory is bound or unbound. Angular momentum,
introduced into the radial energy equation in M07-06, determines the allowed radial motion and
turning points in the general case.
References
References
[1] PhysicsLibrary, M07-04, Gravitational Potential Energy and Gravitational Potential.
[2] PhysicsLibrary, M07-01, Newton’s Law of Universal Gravitation.
[3] PhysicsLibrary, M04-08, Conservation of Angular Momentum and Central Force
Motion.
[4] J. R. Taylor, Classical Mechanics, University Science Books, 2005.
[5] D. Kleppner and R. Kolenkow, An Introduction to Mechanics, 2nd ed., Cambridge
University Press, 2014.