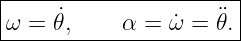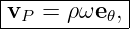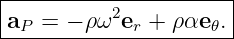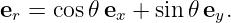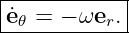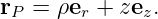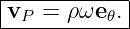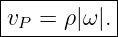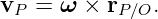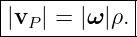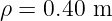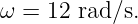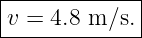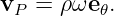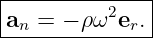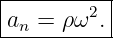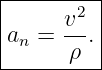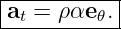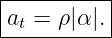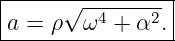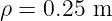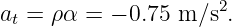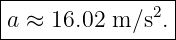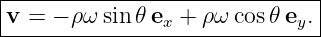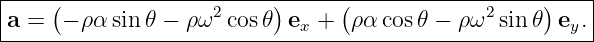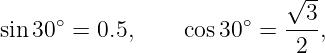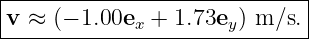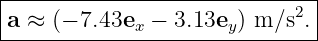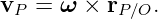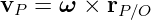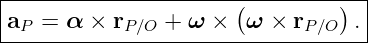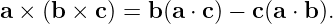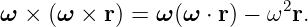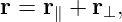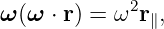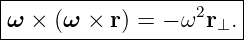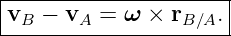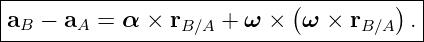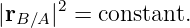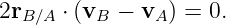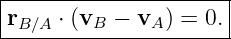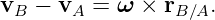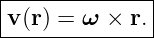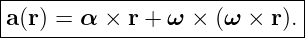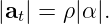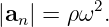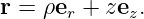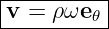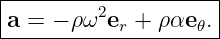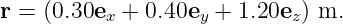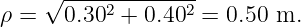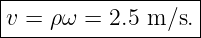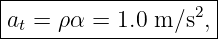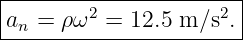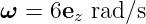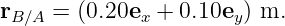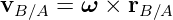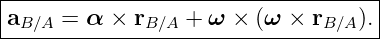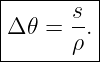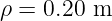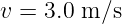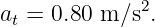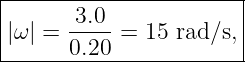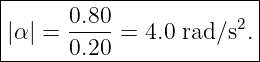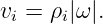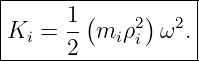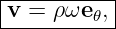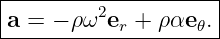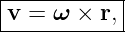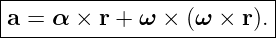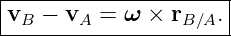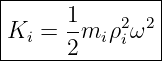Fixed-Axis Rotation and Particle Kinematics
A rigid body in fixed-axis rotation provides one of the clearest examples of how a single angular
motion generates different linear motions throughout an extended body.
Let the fixed rotation axis be the z axis. A material point P remains at a constant
perpendicular distance ρ from the axis and moves on a circle as the body rotates through angle
𝜃(t).
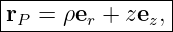
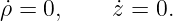
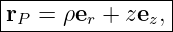
For that point,
where ρ and z are constant for a material point in fixed-axis rotation.
The entire time dependence is carried by the rotating cylindrical basis vectors er and
e𝜃.
The angular variables are
The particle velocity is
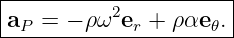
and the particle acceleration is
Thus every material point has:
- tangential velocity proportional to distance from the axis,
- inward normal acceleration proportional to ω2,
- tangential acceleration proportional to α.
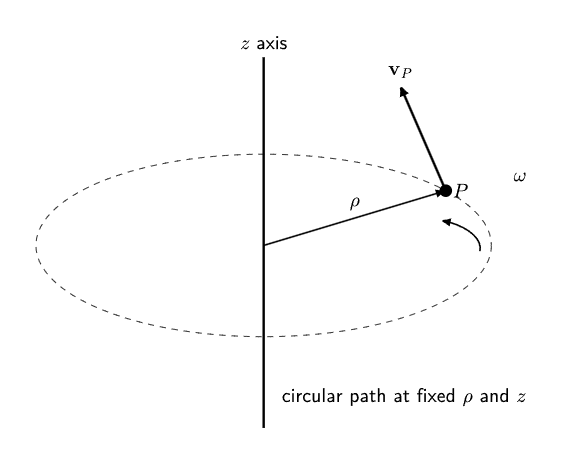
Figure 1. A material point in fixed-axis rotation moves on a circle whose radius is its
perpendicular distance ρ from the rotation axis.
1 Geometry of fixed-axis rotation
Choose a point O on the fixed axis and let
be the perpendicular displacement from the axis to point P.
For an axis along ez,
The distance
is constant for a material point of a rigid body.
The height
along the axis is also constant.
Therefore a material point traces a circle in a plane perpendicular to the axis.
2 Cylindrical basis vectors
In the plane perpendicular to the axis, define
| er | = cos 𝜃 ex + sin 𝜃 ey, | (9)
|
| e𝜃 | = − sin 𝜃 ex + cos 𝜃 ey. | (10) |
The radial vector er points outward from the axis.
The transverse vector e𝜃 points in the direction of increasing 𝜃.
These basis vectors rotate with the body.
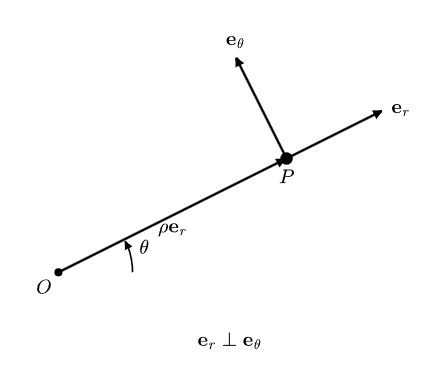
Figure 2. The cylindrical basis vectors er and e𝜃 rotate with the material point. The axial basis
vector ez remains fixed.
3 Time derivatives of the rotating basis
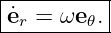
Differentiate
Because ex and ey are fixed in the inertial frame,
| er | = − sin 𝜃 𝜃ex + cos 𝜃 𝜃ey | (12)
|
| = 𝜃e𝜃. | (13) |
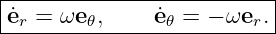
Therefore
Similarly,
These two derivative identities generate the particle velocity and acceleration formulas.
4 Derivation of particle velocity
The position of a material point is
For fixed-axis rigid body motion,
Differentiate:
| vP | = rP | (18)
|
| = ρer | (19)
|
| = ρωe𝜃. | (20) |
Thus
The velocity is tangent to the circular path.
Its magnitude is
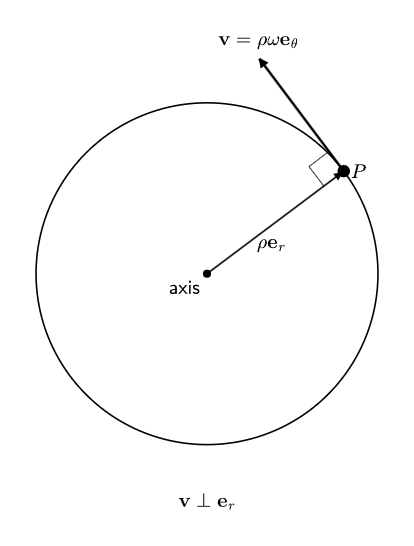
Figure 3. The instantaneous velocity of a point in fixed-axis rotation is tangent to the circular
path and perpendicular to the radial direction.
5 Vector form of particle velocity
For a fixed axis with angular-velocity vector
we have
The component of rP∕O parallel to the axis contributes nothing to the cross product.
Therefore only the perpendicular distance matters:
This is why the correct radius in fixed-axis rotation is the perpendicular distance to the axis, not
necessarily the distance to the coordinate origin.
6 Example 1: particle velocity on a rotating shaft assembly
A point lies
from a fixed shaft axis. At an instant,
Its speed is
| v | = ρω | (28)
|
| = (0.40)(12) | (29)
|
| = 4.8 m∕s. | (30) |
Thus
A second point at twice the radius would have twice the speed even though it has exactly the same
angular velocity.
7 Derivation of particle acceleration
Start with
Differentiate:
| aP | = ρωe𝜃 + ρωe𝜃 | (33)
|
| = ραe𝜃 − ρω2e
r. | (34) |
Therefore
The two terms have distinct physical roles.
8 Normal acceleration
The radial component is
Its magnitude is
It points toward the axis.
Since
we recover the familiar circular-motion form
9 Tangential acceleration
The transverse component is
Its magnitude is
Tangential acceleration changes the magnitude of the tangential velocity.
Normal acceleration changes its direction.
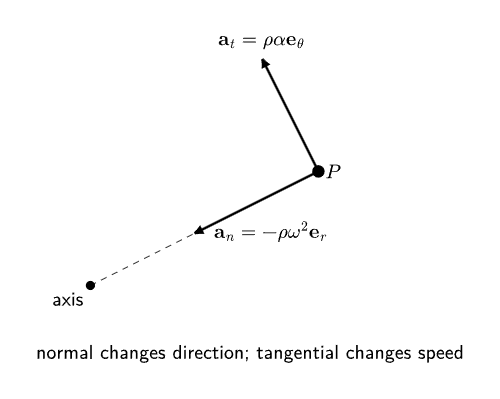
Figure 4. Particle acceleration separates into inward normal acceleration −ρω2er and tangential
acceleration ραe𝜃.
10 Acceleration magnitude and direction
Because er and e𝜃 are perpendicular,
If α = 0,
and the acceleration is purely inward.
If ω = 0 but α≠0 at one instant,
and the acceleration is purely tangential at that instant.
11 Example 2: acceleration components
A point lies at
on a rotating body. At an instant,
| ω | = 8.0 rad∕s, | (46)
|
| α | = −3.0 rad∕s2. | (47) |
The normal acceleration magnitude is
| an | = ρω2 | (48)
|
| = (0.25)(64) | (49)
|
| = 16 m∕s2. | (50) |
The signed tangential component is
The total magnitude is
| a | = 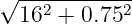 | (52)
|
| ≈ 16.02 m∕s2. | (53) |
Thus
The Normal term dominates strongly because of the square on ω.
12 Cartesian description of a rotating particle
For a point at radius ρ,
| x | = ρ cos 𝜃, | (55)
|
| y | = ρ sin 𝜃. | (56) |
Differentiate:
| ẋ | = −ρω sin 𝜃, | (57)
|
| ẏ | = ρω cos 𝜃. | (58) |
Therefore
Differentiate again:
| ẍ | = −ρα sin 𝜃 − ρω2 cos 𝜃, | (60)
|
| ÿ | = ρα cos 𝜃 − ρω2 sin 𝜃. | (61) |
Thus
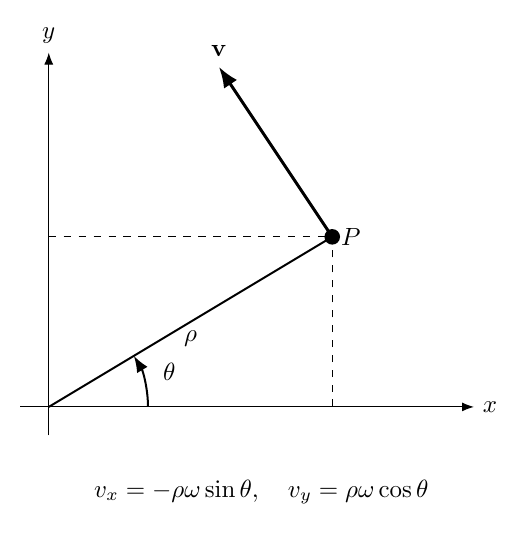
Figure 5. The same rotating-particle velocity and acceleration can be resolved into fixed Cartesian
components.
13 Example 3: Cartesian particle kinematics
Let
| ρ | = 0.50 m, | (63)
|
| 𝜃 | = 30∘, | (64)
|
| ω | = 4.0 rad∕s, | (65)
|
| α | = 2.0 rad∕s2. | (66) |
Using
we obtain
| vx | = −(0.50)(4)(0.5) = −1.0 m∕s, | (68)
|
| vy | = (0.50)(4) ≈ 1.73 m∕s. | (69) |
Therefore
The acceleration components are
| ax | = −(0.50)(2)(0.5) − (0.50)(16) | (71)
|
| ≈−7.43 m∕s2, | (72)
|
| ay | = (0.50)(2) − (0.50)(16)(0.5) | (73)
|
| ≈−3.13 m∕s2. | (74) |
Thus
14 Fixed-axis kinematics from cross products
M05-02 introduced
Differentiate while O remains fixed in the inertial frame:
| aP | =  × rP∕O + ω ×  | (77)
|
| = α× rP∕O + ω × vP . | (78) |
Substituting
gives
The first term is tangential.
The second term points toward the axis.
15 Using the vector triple product
Use
Then
Decompose
where r∥ is parallel to the axis and r⊥ is perpendicular to it.
Because
we obtain
This makes the inward direction explicit.
16 Two particles on the same rigid body
Let A and B be two points on the same rigid body.
For fixed-axis rotation,
Similarly,
These equations relate any two material points without first referring both to the axis.
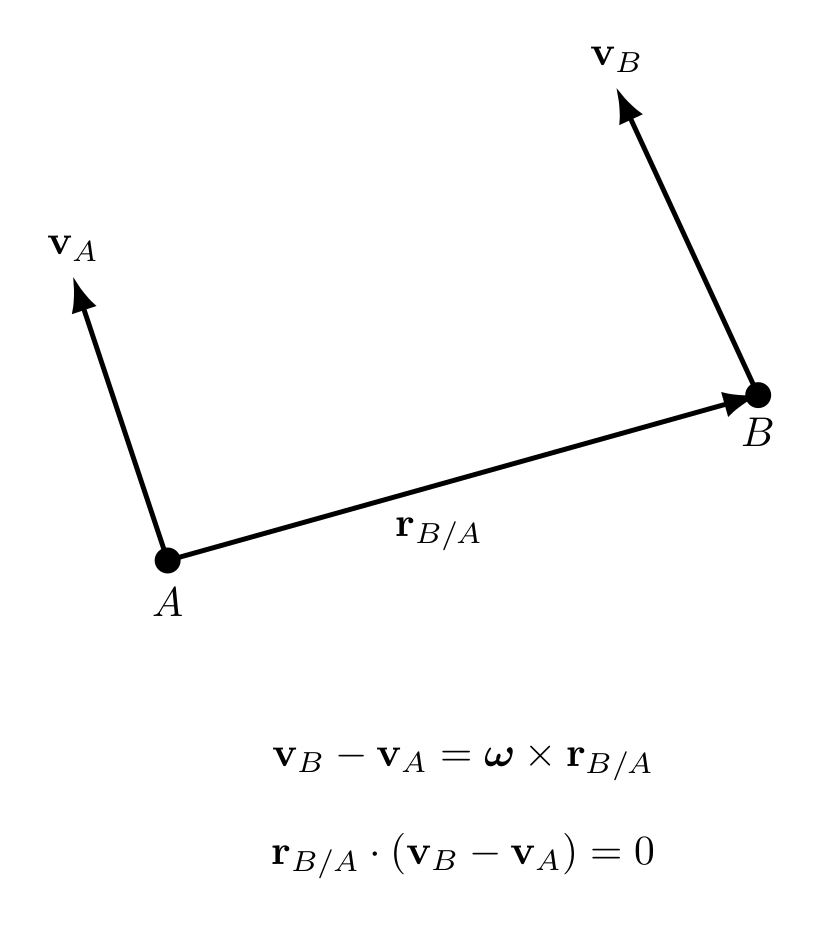
Figure 6. Relative velocity and acceleration between two points on the same rigid body are
determined by the shared angular velocity and angular acceleration.
17 Rigidity check from relative velocity
The distance between two material points remains fixed:
Differentiate:
Therefore
The relative velocity of two points on a rigid body is perpendicular to the line joining
them.
This is exactly consistent with
18 Velocity field of a rotating rigid body
At any instant, the entire fixed-axis velocity field is determined by
For each material point,
This field has several properties:
- velocity vanishes on the rotation axis,
- speed grows linearly with perpendicular radius,
- velocity is tangent to circles around the axis,
- neighboring points have velocities that differ linearly with separation.
19 Acceleration field of a rotating rigid body
At the same instant,
The tangential part grows linearly with radius:
The normal part also grows linearly with radius at fixed ω:
Thus points farther from the axis experience proportionally larger linear accelerations.
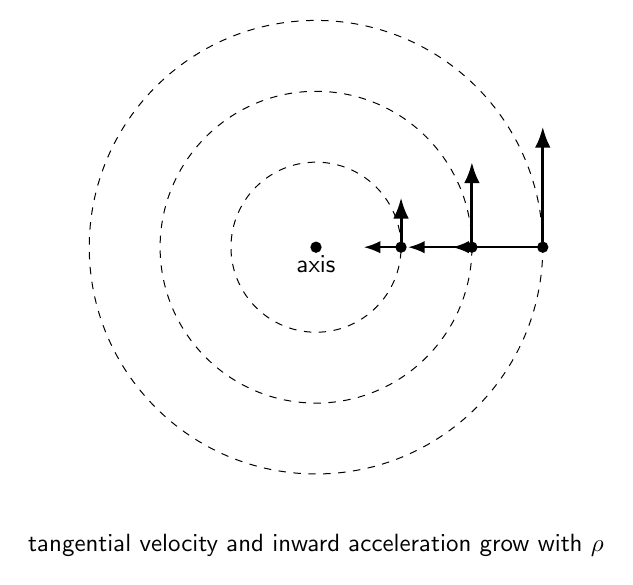
Figure 7. Fixed-axis rotation generates spatial velocity and acceleration fields whose magnitudes
increase with perpendicular distance from the axis.
20 Three-dimensional point positions
A point need not lie in the plane z = 0.
Let
The axial coordinate z remains constant.
Because
the axial component does not contribute to
Therefore
regardless of the value of z.
Likewise,
The kinematics depend only on perpendicular distance from the axis.
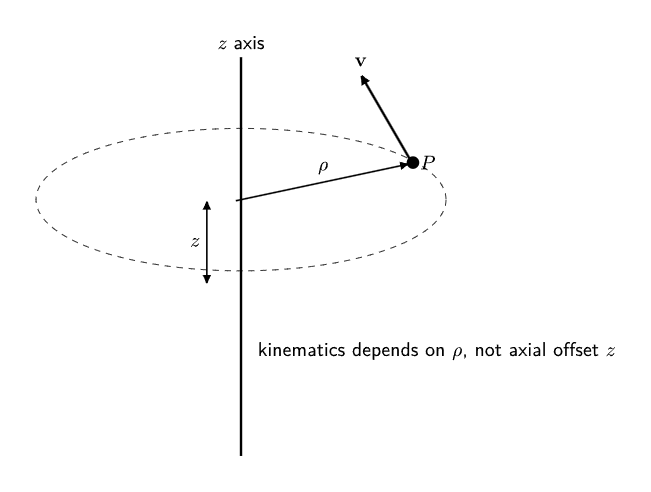
Figure 8. A point can be displaced along the rotation axis without changing its fixed-axis speed or
acceleration magnitudes. Only the perpendicular radius ρ enters.
21 Example 4: a point offset along the axis
A material point has Cartesian coordinates
The body rotates about the z axis with
| ω | = 5ez rad∕s, | (103)
|
| α | = 2ez rad∕s2. | (104) |
The perpendicular radius is
Therefore
The tangential acceleration magnitude is
and the normal acceleration magnitude is
The 1.20 m axial offset does not change these magnitudes.
22 Example 5: relative velocity between two points
Let
and
Then
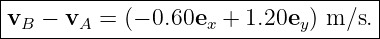
| vB − vA | = 6ez × (0.20ex + 0.10ey) | (111)
|
| = 1.20ey − 0.60ex. | (112) |
Thus
Check rigidity:
| rB∕A ⋅ (vB − vA) | = (0.20)(−0.60) + (0.10)(1.20) | (114)
|
| = 0. | (115) |
The relative velocity is perpendicular to the separation vector, as required.
23 Kinematics of a rotating line segment
Consider two material points A and B connected by a rigid line segment.
If the segment rotates about a fixed axis, then the direction of
changes while its magnitude remains constant.
The relative velocity
is perpendicular to the segment.
The relative acceleration has two parts:
The first changes the relative tangential speed.
The second bends the relative velocity direction inward.
24 Angular displacement from linear displacement
If a material point moves through tangential arc length s at fixed radius ρ,
Likewise, if its tangential speed is known,
for ρ≠0.
If tangential acceleration is known,
These inverse relations let a measured particle motion reveal the angular motion of the entire rigid
body.
25 Example 6: recovering body angular motion from a particle
A marked point on a rotating wheel lies
from the axis. At an instant its tangential speed is
and its tangential acceleration magnitude is
Then
and
The directions or signs require the observed directions of motion and acceleration.
26 Connection to particle kinetic energy
For one material particle of mass mi at perpendicular radius ρi,
Its kinetic energy is therefore
| Ki | =  mivi2 | (128)
|
| =  miρi2ω2. | (129) |
Thus
Summing this expression over all particles naturally introduces the moment of inertia.
That is the subject of M05-04.
27 Common mistakes
- Using distance from the origin instead of perpendicular distance to the rotation axis.
- Treating er and e𝜃 as fixed basis vectors when differentiating.
- Forgetting er = ωe𝜃.
- Forgetting e𝜃 = −ωer.
- Saying velocity points radially outward rather than tangent to the path.
- Omitting the normal acceleration term when angular speed is constant.
- Omitting the tangential acceleration term when angular speed changes.
- Using an = ρω instead of an = ρω2.
- Assuming points at different radii have the same linear speed because they have the
same angular speed.
- Forgetting that axial position z does not affect fixed-axis speed or acceleration
magnitude.
- Mixing signed tangential acceleration ρα with the nonnegative magnitude ρ|α|.
- Forgetting that ω × (ω × r) points toward the rotation axis.
- Applying fixed-axis formulas when the axis itself translates or changes direction.
- Confusing particle kinematics with force or torque dynamics.
28 Practice exercises
- Starting from er = cos 𝜃ex + sin 𝜃ey, derive er = ωe𝜃.
- Derive e𝜃 = −ωer.
- Starting from r = ρer + zez with constant ρ and z, derive the fixed-axis velocity.
- Differentiate the velocity to derive the radial and tangential acceleration terms.
- A point at ρ = 0.35 m rotates with ω = 9 rad∕s. Find its speed and normal
acceleration.
- If the same point has α = −2 rad∕s2, find its tangential acceleration and total
acceleration magnitude.
- Derive the Cartesian velocity components for fixed-axis rotation.
- Derive the Cartesian acceleration components for fixed-axis rotation.
- Show that the vector formula v = ω × r reduces to v = ρ|ω|.
- Use the vector triple-product identity to prove that the double-cross-product
acceleration points toward the axis.
- Derive the relative velocity relation between two points on the same rigid body.
- Show that rB∕A ⋅ (vB − vA) = 0.
- A point is located at (0.4, 0.3, 2.0) m relative to a z-axis rotation. Find its
perpendicular radius.
- If ω = 5 rad∕s and α = 1.5 rad∕s2 for the preceding point, find its speed and both
acceleration magnitudes.
- Explain how the particle kinetic-energy expression leads naturally to the definition of
moment of inertia.
29 Summary
For fixed-axis rotation,
with constant ρ and z for each material point.
The rotating basis satisfies
Therefore
and
Equivalently,
and
For two points on the same rigid body,
The particle kinetic-energy relation
provides the direct bridge to M05-04 and the moment of inertia.
References
References
[1] J. R. Taylor, Classical Mechanics, University Science Books, 2005.
[2] D. Kleppner and R. Kolenkow, An Introduction to Mechanics, 2nd ed., Cambridge
University Press, 2014.
[3] K. R. Symon, Mechanics, 3rd ed., Addison-Wesley, 1971.
[4] OpenStax, University Physics, Volume 1, Rice University, 2016.