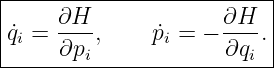
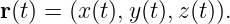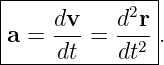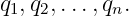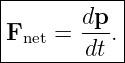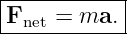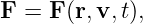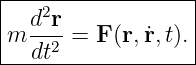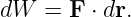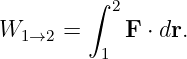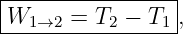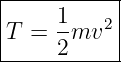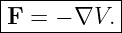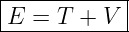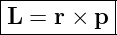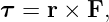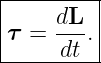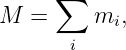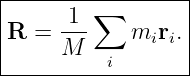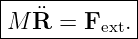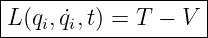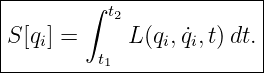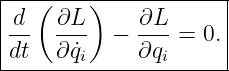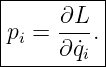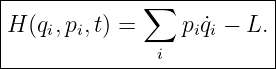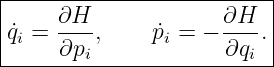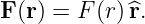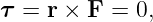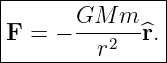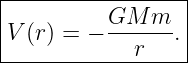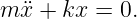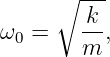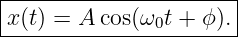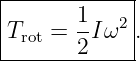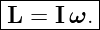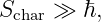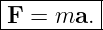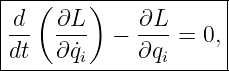Classical Mechanics: Scope, Principles, and Formulations
Classical mechanics is the branch of physics that describes the motion of material systems and
the forces or interactions that determine that motion when quantum effects and, in its usual
Newtonian form, relativistic effects can be neglected. It includes the motion of particles, systems of
particles, rigid bodies, oscillators, and many continuous mechanical systems, and it provides the
conceptual and mathematical foundation for much of engineering, astronomy, astrodynamics,
control, and applied physics [1, 2, 3].
The word classical does not mean obsolete. Classical mechanics remains the correct working theory
for an enormous range of macroscopic systems. It is best understood as an approximation valid in a
particular physical regime, just as geometrical optics is an approximation to wave optics. When
velocities are small compared with the speed of light and quantum effects are negligible
on the scales of interest, classical mechanics can describe motion with extraordinary
accuracy.
Classical mechanics is narrower than classical physics. Classical physics can also include
non-quantum theories such as classical Electromagnetism and Thermodynamics; classical
mechanics specifically concerns mechanical motion, constraints, forces, energy, and related
dynamical structures.
This article is a summary of the subject itself. A separate PhysicsLibrary entry may treat the
history of classical mechanics in detail; only enough history is included here to orient the main
ideas and formalisms.
1 What classical mechanics studies
Mechanics begins with a simple question:
Given the state of a mechanical system and the laws governing its interactions,
how does the system move?
The system may be as simple as one particle moving along a line or as complicated as a spacecraft
with translational and rotational dynamics, a collection of mutually gravitating bodies, or a
nonlinear oscillator exhibiting chaos.
A useful division of the subject is shown below.
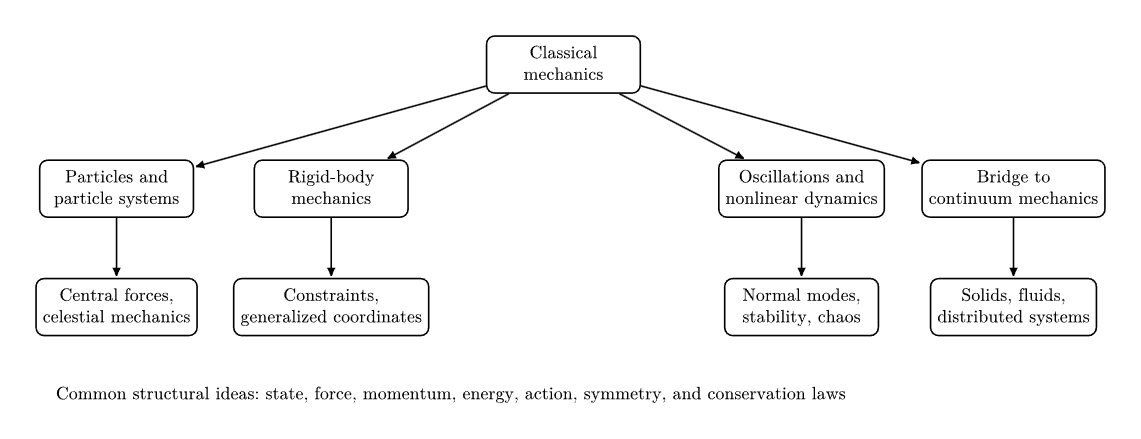
Figure 1. Classical mechanics contains several kinds of mechanical systems and several
mathematically equivalent formulations. The choice of model and formulation depends on the
physical problem.
Common topics include
- kinematics: describing position, velocity, acceleration, orientation, and angular velocity;
- statics: determining conditions for mechanical equilibrium;
- dynamics: determining motion from forces, torques, constraints, or an action principle;
- conservation laws for momentum, angular momentum, and energy;
- oscillations and Normal modes;
- motion under central forces, including orbital mechanics;
- rigid-body translation and rotation;
- constrained motion and generalized coordinates;
- nonlinear dynamics, stability, and chaos.
Classical mechanics is not a single set of equations. Newtonian, Lagrangian, and hamiltonian
mechanics are different but closely related formulations of the same classical dynamics.
2 Mechanical models and degrees of freedom
The first step in a mechanics problem is choosing the model. A real object may be represented as a
point particle, a system of particles, a rigid body, or a deformable continuum depending on which
details matter.
A particle moving freely in three-dimensional space has three positional degrees of freedom,
Its velocity and acceleration are
Constraints reduce the number of independent coordinates. A bead constrained to a wire may have
only one degree of freedom even though the wire lies in three-dimensional space. A rigid body
moving freely in space has six degrees of freedom: three for translation and three for
orientation.
Coordinates that independently describe the configuration are called generalized coordinates and
are usually written
The number n is the number of degrees of freedom.
3 Newtonian mechanics
Newtonian mechanics organizes dynamics around forces and momentum. For a particle of
momentum p,
For constant mass m,
so Newton’s second law becomes
This equation is a differential equation for the particle trajectory. Given the force as a function of
position, velocity, and time,
we obtain
Initial position and velocity then determine a particular motion when the initial-value problem is
well posed.
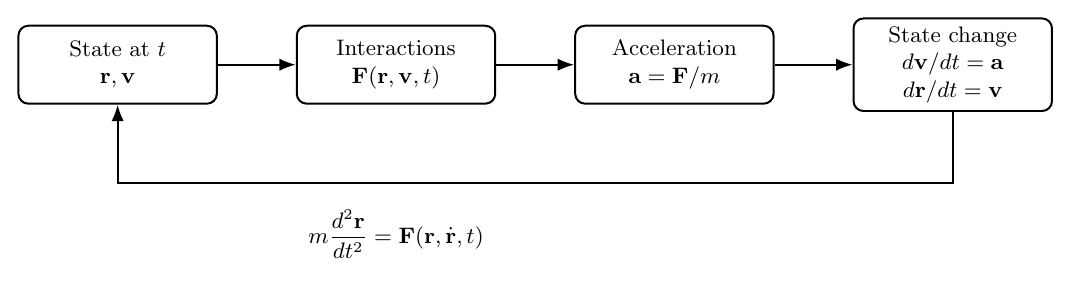
Figure 2. Newtonian dynamics maps the state of a particle and the applied forces into an
acceleration, which changes velocity and position with time.
Newton’s laws also identify inertial frames, in which a force-free particle moves with constant
velocity. Accelerating or rotating reference frames can still be used, but additional inertial terms
appear in the equations of motion.
4 Work, kinetic energy, and potential energy
For a particle displaced by dr under force F, the differential work is
The work done between two points is
For constant mass, Newton’s second law gives the work–energy theorem,
where
is the kinetic energy.
If the force is conservative, it can be written in terms of a potential energy V ,
Then the mechanical energy
is constant when the potential has no explicit time dependence.
Energy methods are often simpler than direct force integration because they replace vector
equations with scalar relations and expose conservation properties immediately.
5 Momentum and angular momentum
For a particle,
and
are the linear and angular momenta about the chosen origin.
The net torque is
and for a particle
Thus zero net external force implies conservation of total linear momentum, while zero net external
torque implies conservation of total angular momentum.
These laws become especially powerful for systems of many particles. If the total mass
is
the center of mass is
Under the usual cancellation of internal forces,
This is why an extended collection of matter can often be treated as a single particle when only its
translational motion is required.
6 Lagrangian mechanics
Newton’s force-vector formulation is direct, but constraints and curvilinear coordinates can make it
cumbersome. Lagrangian mechanics reorganizes the problem around generalized coordinates and
the scalar Lagrangian
for the common case of conservative mechanical systems.
Define the action
Hamilton’s principle states that the physical path makes the first variation of the action
vanish,
The resulting Euler–Lagrange equations are
These equations contain the same classical dynamics as Newton’s laws but often eliminate
constraint forces automatically. They also generalize naturally to complicated coordinate systems
and provide the bridge from mechanics to the calculus of variations, field theory, and modern
theoretical physics [1, 2].
7 Hamiltonian mechanics
The generalized momentum conjugate to qi is
The Hamiltonian is defined by the Legendre transform
For many familiar mechanical systems, H is the total mechanical energy, although this
identification is not universally valid.
Hamilton’s equations are
They replace n second-order equations with 2n coupled first-order equations in phase
space.
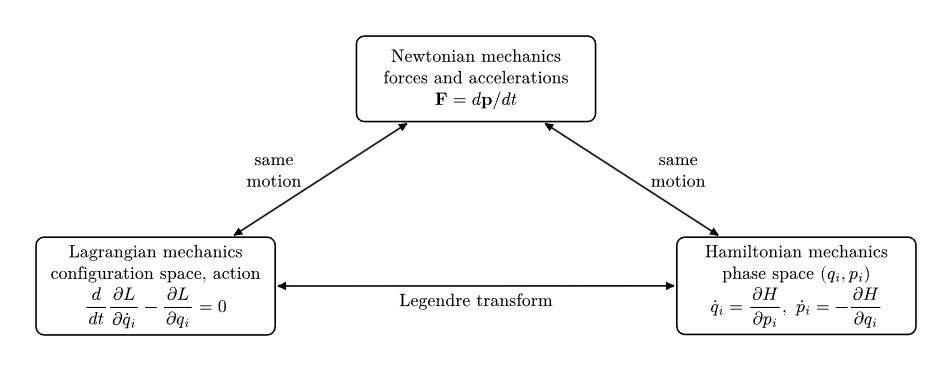
Figure 3. Newtonian, Lagrangian, and Hamiltonian mechanics are alternative formulations of the
same underlying classical dynamics. Different formulations emphasize forces, action and
generalized coordinates, or phase space and canonical variables.
Hamiltonian mechanics is especially important for canonical transformations, perturbation theory,
statistical mechanics, dynamical systems, and the conceptual transition to quantum mechanics
[2, 4].
8 Conservation laws and symmetry
Conservation laws are not isolated tricks; they reflect structure in the mechanical description.
In elementary Newtonian language:
In Lagrangian mechanics these connections are formalized by Noether’s theorem. If the action is
invariant under a continuous transformation, a corresponding conserved quantity exists. This
provides a deeper reason why momentum, angular momentum, and energy occur so persistently
across mechanics.
9 Central-force motion and orbital mechanics
A central force has the form
Because the torque about the force center is zero,
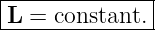
so angular momentum is conserved:
The motion therefore remains in a plane perpendicular to L.
Newtonian gravity is the central force
Its associated potential energy is
This one force law leads to Keplerian orbital motion, escape trajectories, orbital energy and
angular momentum relations, and much of celestial mechanics and astrodynamics.
10 Oscillations and normal modes
A second canonical problem is the harmonic oscillator. For
Newton’s equation gives
Defining
the motion is
The harmonic oscillator is important far beyond springs. Small deviations from a stable
equilibrium often produce approximately quadratic potential energy, so many systems
reduce locally to harmonic motion. Coupled oscillators lead to normal modes, which in
turn provide a bridge to waves, molecular vibration, structures, circuits, and quantum
mechanics.
11 Rigid-body mechanics
A rigid body is an extended mechanical system whose internal distances are assumed constant. Its
motion can be decomposed into translation of the center of mass and rotation about the center of
mass.
For rotation about a fixed principal axis,
and
In general three-dimensional rotation, angular momentum and angular velocity are related by the
inertia tensor,
The rigid-body equations are fundamental to spacecraft attitude dynamics, vehicle dynamics,
gyroscopes, robotics, and rotating machinery.
12 Nonlinear dynamics and chaos
Classical mechanics is deterministic in the sense that a well-posed initial state determines a
trajectory through the equations of motion. Deterministic does not mean that every motion is
simple or practically predictable.
Nonlinear classical systems can exhibit sensitive dependence on initial conditions. Nearby
trajectories may separate rapidly, producing chaotic motion even though the governing equations
themselves contain no random forcing. Important examples arise in the restricted three-body
problem, driven pendulums, coupled oscillators, and many-body systems.
Chaos is therefore part of classical mechanics, not a failure of it. It illustrates that exact
deterministic laws can still produce limited long-term predictability.
13 Where classical mechanics is valid
Classical mechanics is an approximation to more general physical theories. Two important limits
are relativistic and quantum.
Newtonian mechanics is normally appropriate when characteristic speeds satisfy
When speeds become an appreciable fraction of the speed of light, special relativity replaces
Newtonian kinematics and momentum-energy relations.
Classical mechanics is also appropriate when quantum interference, quantization, uncertainty, spin,
and other quantum effects are negligible for the observables of interest. A useful qualitative
indicator is that the characteristic action scale is large compared with Planck’s reduced
constant,
although the classical limit can be subtler and depends on state preparation, decoherence, and the
quantity being measured.
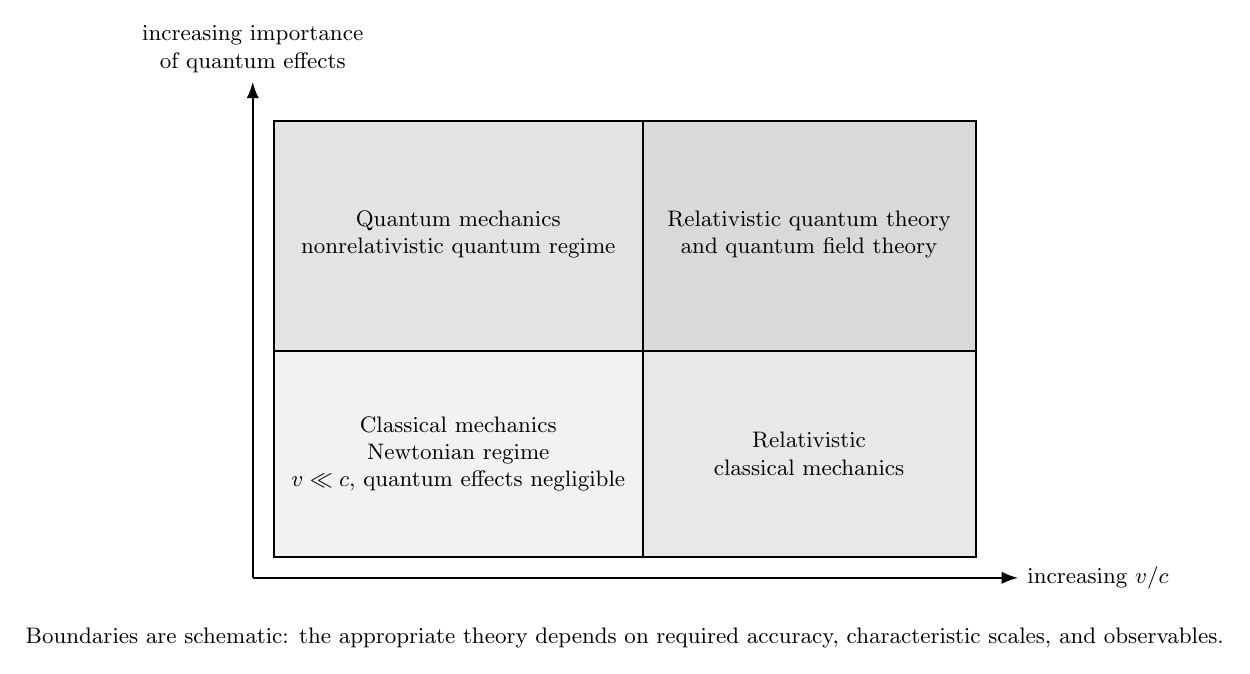
Figure 4. Classical mechanics occupies the regime where relativistic and quantum corrections are
negligible for the required accuracy. Relativistic mechanics is needed as v∕c becomes significant,
while quantum mechanics is required when quantum effects cannot be ignored.
General relativity is required when spacetime curvature and strong-field gravity must be modeled
accurately. These more general theories do not make classical mechanics useless; they explain why
it works as a limiting approximation in its proper domain.
14 Brief historical orientation
The foundations of classical mechanics were assembled over several centuries. Work by Galileo and
Kepler helped establish quantitative laws of motion and planetary behavior. Newton’s
seventeenth-century synthesis connected terrestrial and celestial mechanics through laws of motion
and universal gravitation. Euler and Lagrange later reformulated mechanics using generalized
coordinates and variational methods, while Hamilton developed the canonical formulation that
now bears his name. In the nineteenth century and beyond, mechanics expanded into
rigid-body dynamics, continuum mechanics, stability theory, and nonlinear dynamics
[1, 2].
That short chronology is enough for the present article. The motivations, original sources,
historical controversies, and development of the subject deserve a separate history entry.
15 Relationship to other areas of physics
Classical mechanics sits near the center of the physics curriculum because its ideas recur elsewhere:
- celestial mechanics and astrodynamics apply particle and rigid-body dynamics
to natural and artificial bodies in space;
- continuum mechanics extends mechanical balance laws to distributed matter such
as solids and fluids;
- statistical mechanics applies mechanics probabilistically to systems with enormous
numbers of degrees of freedom;
- electromagnetism supplies forces and torques on charged particles and material
bodies;
- control theory builds dynamical models from mechanical state equations;
- quantum mechanics inherits Hamiltonians, canonical variables, and action principles
from classical mechanics;
- relativity modifies the kinematics and dynamics while preserving many structural
ideas such as action principles and conservation laws.
Thus classical mechanics is both a practical theory of motion and a language that reappears
throughout modern physics.
16 Summary
Classical mechanics studies the motion of material systems in the regime where classical
approximations are adequate. A mechanical system is described by a set of degrees of freedom and
equations that govern their evolution.
In Newtonian mechanics,
and for constant mass,
In Lagrangian mechanics,
while Hamiltonian mechanics uses
These are not competing theories of ordinary classical motion. They are complementary
formulations that emphasize different structures and become convenient for different classes of
problems.
Classical mechanics remains indispensable because it provides accurate models for a vast range of
macroscopic phenomena and because its concepts—state, momentum, energy, action,
symmetry, stability, and phase space—form part of the mathematical foundation of physics
itself.
References
References
[1] J. R. Taylor, Classical Mechanics, University Science Books, 2005.
[2] H. Goldstein, C. Poole, and J. Safko, Classical Mechanics, 3rd ed., Addison Wesley,
2002.
[3] L. D. Landau and E. M. Lifshitz, Mechanics, 3rd ed., Butterworth-Heinemann, 1976.
[4] V. I. Arnold, Mathematical Methods of Classical Mechanics, 2nd ed., Springer, 1989.
[5] J. B. Marion and S. T. Thornton, Classical Dynamics of Particles and Systems, 4th
ed., Saunders College Publishing, 1995.
[6] Wikipedia contributors, “Classical mechanics,” Wikipedia, The Free Encyclopedia,
accessed September 25, 2026.