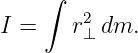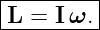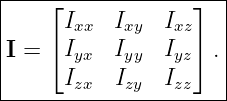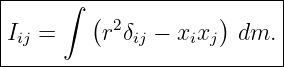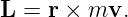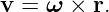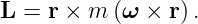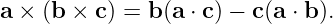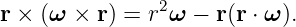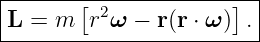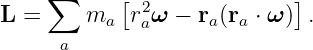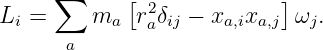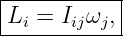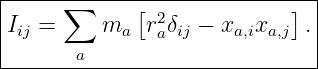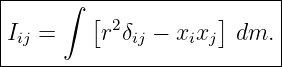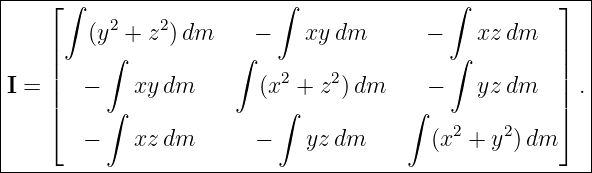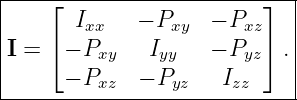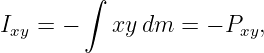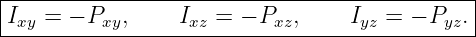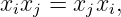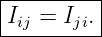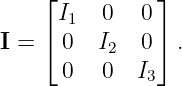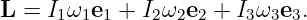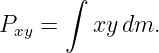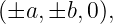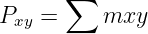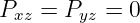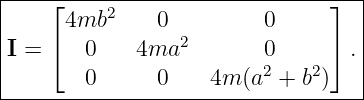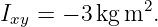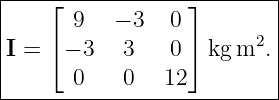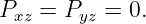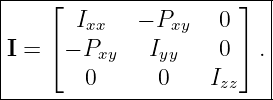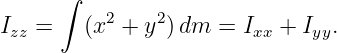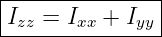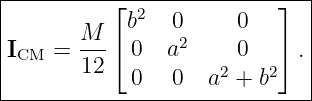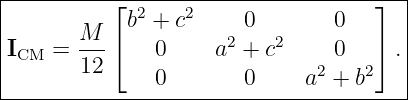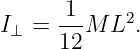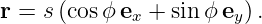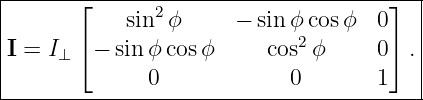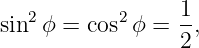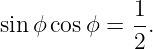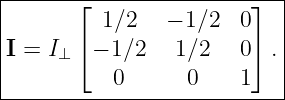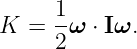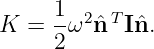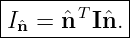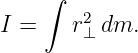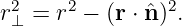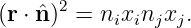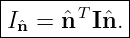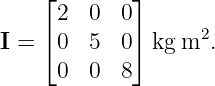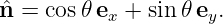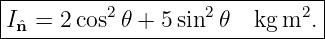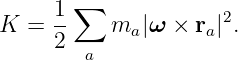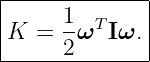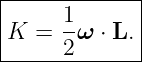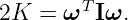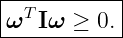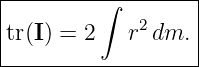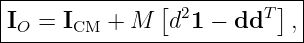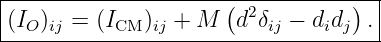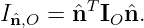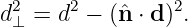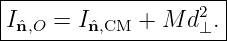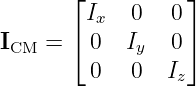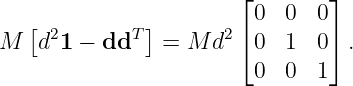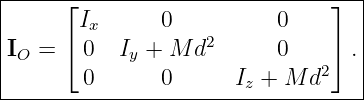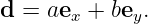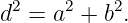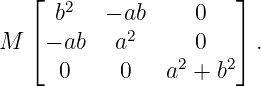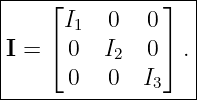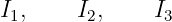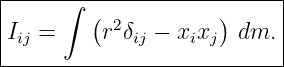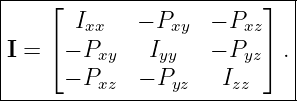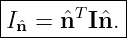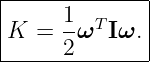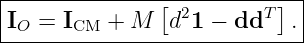The Inertia Tensor and Products of Inertia
For rotation about one fixed axis, a scalar moment of inertia is sufficient:
In general three-dimensional rotation, however, one scalar is not enough.
The angular velocity
can point in any direction, and the angular momentum
need not be parallel to it.
The mass distribution must therefore be described by a second-order tensor:
The matrix representation of the inertia tensor in Cartesian coordinates is
For a mass distribution,
This article derives that expression, explains the products of inertia, and connects the tensor back
to the familiar scalar moment of inertia.
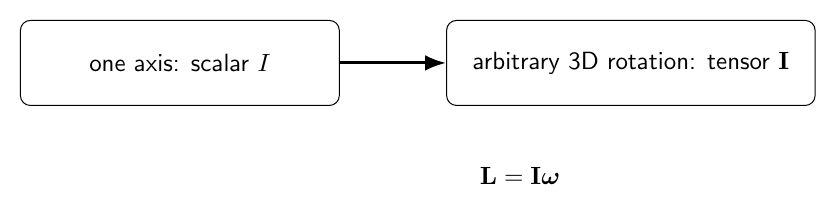
Figure 1. A scalar moment of inertia describes rotation about one specified axis. The inertia
tensor describes the rotational mass distribution for arbitrary angular-velocity directions.
1 Why a tensor is needed
For a point mass,
For rigid body rotation about an origin,
Therefore
Use the vector triple-product identity
Then
Thus a particle contributes
This dependence on the direction of ω is more complicated than multiplication by one
scalar.
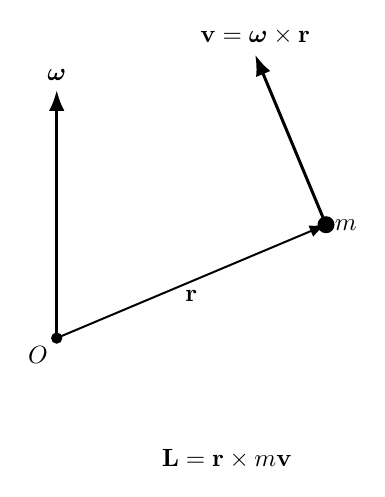
Figure 2. For a particle in rigid body rotation, the velocity is ω × r. The resulting angular
momentum contains both the magnitude and direction of the particle position relative to the
rotation origin.
2 Derivation for a system of particles
For particles indexed by a,
Write the Cartesian components:
Using the summation convention,
where
For a continuous body,
3 Matrix form
In Cartesian coordinates,
The diagonal entries are familiar scalar moments:
| Ixx = ∫
(y2 + z2) dm, | | (19)
|
| Iyy = ∫
(x2 + z2) dm, | | (20)
|
| Izz = ∫
(x2 + y2) dm. | | (21) |
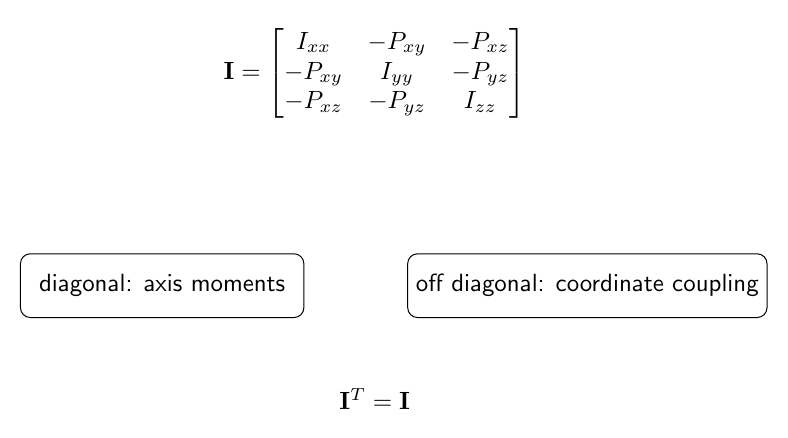
Figure 3. The diagonal inertia-tensor entries are ordinary moments of inertia about the coordinate
axes. The off-diagonal entries encode products of coordinates and couple angular-velocity
components to angular-momentum components.
4 Products of inertia and sign convention
The off-diagonal integrals involve coordinate products.
Define the geometric products of inertia
| Pxy = ∫
xy dm, | | (22)
|
| Pxz = ∫
xz dm, | | (23)
|
| Pyz = ∫
yz dm. | | (24) |
With this convention, the inertia tensor is
Physics texts also commonly denote the actual tensor component itself by
with analogous definitions for Ixz and Iyz.
Therefore:
The sign convention must always be checked when comparing references.
In this article:
- Pxy means the unsigned coordinate-product integral ∫
xy dm,
- Ixy means the off-diagonal tensor component −∫
xy dm.
5 The inertia tensor is symmetric
Because
Thus
Only six independent components exist:
This symmetry will be crucial when principal axes are introduced in M05-10.
6 Angular momentum components
From
| Lx | = Ixxωx + Ixyωy + Ixzωz, | (33)
|
| Ly | = Ixyωx + Iyyωy + Iyzωz, | (34)
|
| Lz | = Ixzωx + Iyzωy + Izzωz. | (35) |
Therefore an angular velocity along one coordinate direction can generate angular momentum
components along other directions if the products of inertia are nonzero.
7 When angular momentum is not parallel to angular velocity
Suppose the inertia tensor is diagonal:
Then
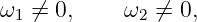
If
and both
the direction of L generally differs from the direction of ω.
Thus even zero products of inertia do not guarantee
for every angular velocity.
Parallelism occurs when ω lies along a principal axis or within a degenerate equal-inertia
subspace.
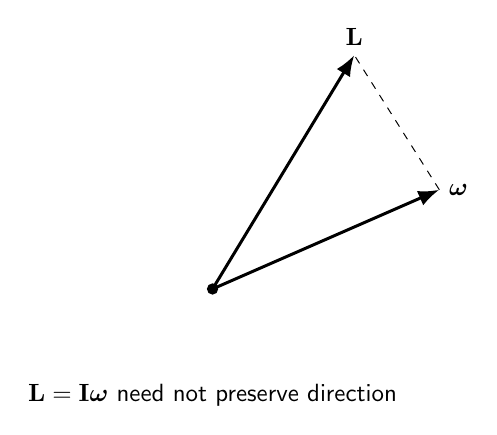
Figure 6. In three-dimensional rotation, angular momentum need not point along angular velocity.
The inertia tensor stretches different angular-velocity components by different amounts.
8 Symmetry and vanishing products of inertia
Products of inertia are especially sensitive to symmetry.
Consider
If the mass distribution is symmetric under
then every mass element at (x,y,z) is paired with an equal mass element at (−x,y,z).
Their contributions to xy cancel.
Therefore
for symmetry about the yz plane.
Similarly:
- symmetry under y →−y also makes Pxy = 0,
- symmetry under x →−x or z →−z makes Pxz = 0,
- symmetry under y →−y or z →−z makes Pyz = 0.
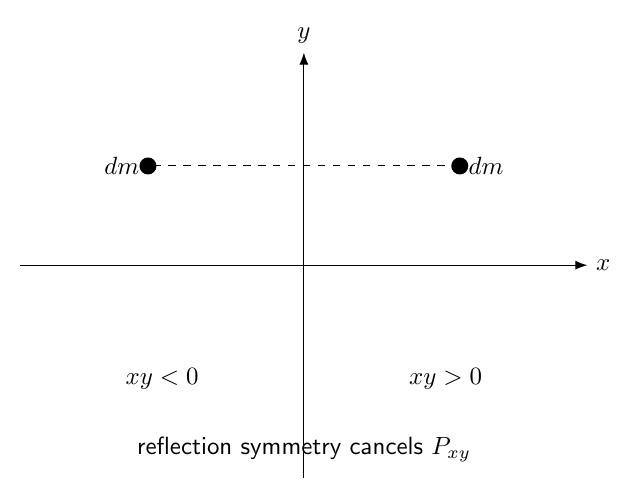
Figure 4. Products of inertia vanish when symmetry pairs positive and negative
coordinate-product contributions. For example, reflection symmetry across the yz plane cancels
the integral of xy.
9 Example 1: four point masses in a rectangle
Four equal point masses m lie at
with all sign combinations present.
The diagonal moments are
| Ixx | = ∑
my2 = 4mb2, | (45)
|
| Iyy | = ∑
mx2 = 4ma2, | (46)
|
| Izz | = ∑
m(x2 + y2) = 4m(a2 + b2). | (47) |
The product
contains equal positive and negative terms:
Also,
because
Thus
10 Example 2: two asymmetric point masses
Let two point masses have:
| m1 | = 2 kg, | r1 | = (1, 2, 0) m, | (53)
|
| m2 | = 1 kg, | r2 | = (−1, 1, 0) m. | (54) |
Then
| Ixx | = 2(22) + 1(12) = 9 kg m2, | (55)
|
| Iyy | = 2(12) + 1((−1)2) = 3 kg m2, | (56)
|
| Izz | = Ixx + Iyy = 12 kg m2. | (57) |
The geometric product is
| Pxy | = 2(1)(2) + 1(−1)(1) | (58)
|
| = 3 kg m2. | (59) |
Therefore
The tensor is
11 Planar lamina
For a thin lamina in the xy plane,
Therefore
The tensor becomes
Also,
Thus the perpendicular-axis theorem appears naturally as a component identity of the inertia
tensor:
for a planar lamina.
12 Uniform rectangular plate
A rectangular plate of mass M has side lengths a along x and b along y, centered at the
origin.
By reflection symmetry,
The moments are
| Ixx | =  Mb2, | (68)
|
| Iyy | =  Ma2, | (69)
|
| Izz | =  M(a2 + b2). | (70) |
Therefore
13 Uniform rectangular box
For a uniform rectangular box centered at the origin with side lengths:
- a along x,
- b along y,
- c along z,
symmetry makes all products of inertia vanish.
The inertia tensor is
These coordinate directions are principal axes.
The full meaning of that statement is developed in M05-10.
14 Rotated slender rod and nonzero product of inertia
Consider a slender uniform rod of length L and mass M, centered at the origin in the xy
plane.
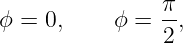
Let the rod make angle ϕ with the x axis.
Define
A point on the rod can be written
The tensor components become
| Ixx | = I⊥ sin 2ϕ, | (75)
|
| Iyy | = I⊥ cos 2ϕ, | (76)
|
| Ixy | = −I⊥ sin ϕ cos ϕ, | (77)
|
| Izz | = I⊥. | (78) |
Thus
Unless
or another symmetry-aligned orientation is chosen, the product of inertia is nonzero.
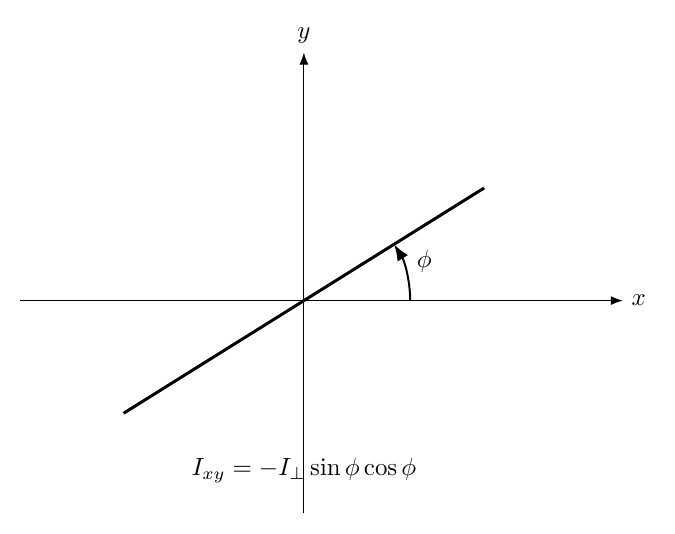
Figure 5. A slender rod aligned with a rotated direction generally has a nonzero xy product of
inertia when described in the original x,y coordinate axes.
15 Example 3: rod at forty-five degrees
Let
Then
and
Thus
The off-diagonal terms are not a defect.
They simply indicate that the chosen coordinate axes are not aligned with the rod’s principal
directions.
16 Moment of inertia about an arbitrary axis
Let
be a unit vector defining an axis through the tensor origin.
If
then the rotational kinetic energy is
Therefore
Define the scalar moment about the axis:
This is the tensor form of
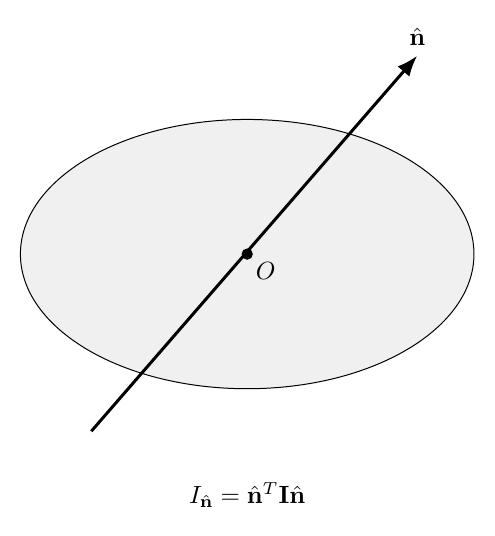
Figure 7. The scalar moment of inertia about any unit axis n is obtained from the quadratic form
In = nT In.
17 Direct proof of the arbitrary-axis formula
The squared perpendicular distance from r to the axis
is
Therefore
| In | = ∫
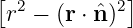 dm. | (93) |
In component form,
Thus
| In | = ni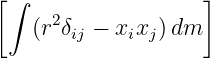 nj | (95)
|
| = niIijnj. | (96) |
Hence
18 Example 4: arbitrary axis for a diagonal tensor
Suppose
Let the unit axis lie in the xy plane:
Then
| In | = 2 cos 2𝜃 + 5 sin 2𝜃. | (100) |
Therefore
At
the result is
At
it is
19 Rotational kinetic energy
For a system of particles,
The tensor form is
Equivalently,
This relation remains valid even when
20 Positive character of the inertia tensor
For any angular velocity,
Since kinetic energy cannot be negative,
Thus the inertia tensor is positive semidefinite.
For a genuinely three-dimensional body with nonzero mass away from every possible axis through
the origin, it is positive definite.
For idealized lower-dimensional objects, one eigenvalue can be zero.
For example, an ideal slender rod has zero moment of inertia about its own longitudinal axis if its
thickness is neglected.
21 Trace of the inertia tensor
Add the diagonal components:
| tr(I) | = Ixx + Iyy + Izz | (112)
|
| = ∫
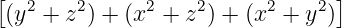 dm. | (113) |
Therefore
The trace is unchanged by a rotation of coordinate axes.
It equals the sum of the principal moments and provides a useful consistency check.
22 Changing coordinate axes
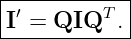
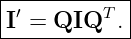
Suppose coordinate components transform under an orthogonal matrix Q:
Then
and
Because
the tensor components in the rotated coordinates satisfy
The physical mass distribution has not changed.
Only its matrix representation has changed.
23 Products of inertia depend on the coordinate axes
A body can have
in one coordinate system and a nonzero product in another rotated system.
Therefore a nonzero product of inertia does not mean anything is physically wrong or
unbalanced.
It indicates that the coordinate axes are not aligned with directions that diagonalize the inertia
tensor.
M05-10 finds those directions systematically.
24 Tensor parallel-axis theorem
M05-05 introduced the scalar parallel-axis theorem.
The three-dimensional tensor generalization is
where:
- ICM is the inertia tensor about the center of mass,
- O is the new origin,
- d is the vector from the new origin to the center of mass,
- 1 is the identity matrix.
In components,
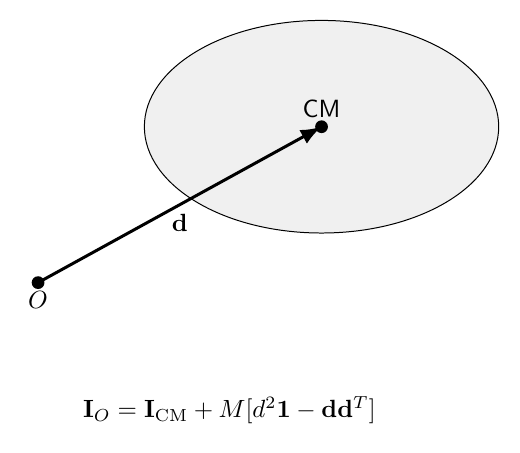
Figure 8. The tensor parallel-axis theorem shifts the inertia tensor from the center of mass to a
new origin by adding M[d21 − ddT ].
25 Recovering the scalar parallel-axis theorem
Let the desired axis have unit direction
Use
Then
| In,O | = In,CM + M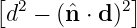 . | (125) |
The bracket is the squared perpendicular separation of the two parallel axes:
Therefore
This exactly reproduces the scalar parallel-axis theorem.
26 Example 5: tensor shift along the x direction
Suppose
and the new origin is displaced from the center of mass by distance d along the x direction.
Then
The shift matrix is
Thus
The moment about the x axis is unchanged because shifting the origin along the axis does not
change perpendicular distances to that axis.
27 Example 6: tensor shift in two coordinate directions
Let
Then
The shift term is
Notice that shifting the reference origin can create nonzero off-diagonal tensor components even
when the center of mass tensor is diagonal.
28 Products of inertia and balance
A nonzero product of inertia should not be confused automatically with static or dynamic
imbalance.
Balance depends on both:
- the center of mass location,
- the orientation of the inertia tensor relative to the intended rotation axis.
For a rotor intended to spin about a fixed shaft, desirable design often places:
- the center of mass on the shaft,
- a principal axis along the shaft.
The second requirement concerns products of inertia and principal directions.
29 Connection to principal axes
Because the inertia tensor is real and symmetric, it has orthogonal eigenvectors.
Those eigenvectors are the principal axes.
In coordinates aligned with them,
The eigenvalues
are the principal moments of inertia.
For rotation exactly about a principal axis,
M05-10 develops this eigenvalue problem in detail.
30 Common mistakes
- Treating moment of inertia as one scalar in arbitrary three-dimensional rotation.
- Assuming L is always parallel to ω.
- Forgetting the minus sign between Pxy = ∫
xy dm and the tensor component Ixy =
−Pxy.
- Comparing formulas from different references without checking their product-of-inertia
sign convention.
- Assuming all products of inertia are automatically zero.
- Failing to use symmetry to eliminate odd coordinate-product integrals.
- Assuming a diagonal tensor guarantees L ∥ ω for every ω.
- Confusing a diagonal coordinate representation with a spherical inertia tensor having
equal diagonal entries.
- Using In without normalizing the axis vector.
- Forgetting that inertia-tensor components depend on both the origin and orientation
of the coordinate axes.
- Applying the scalar parallel-axis theorem independently to matrix entries without using
the tensor shift formula.
- Forgetting that an origin shift can create off-diagonal terms.
- Treating nonzero products of inertia as proof of center of mass offset.
- Confusing the inertia tensor with the stress tensor or area moment tensor.
- Forgetting that the inertia tensor is symmetric.
31 Practice exercises
- Starting from L = r × m(ω × r), derive the particle inertia tensor.
- Extend the particle result to a discrete system and then to a continuous body.
- Write the inertia tensor explicitly in Cartesian coordinates and identify all three
products of inertia.
- Explain the distinction between Pxy = ∫
xy dm and the tensor component Ixy used in
this article.
- Prove that the inertia tensor is symmetric.
- Show that symmetry under x →−x forces Pxy = Pxz = 0.
- Compute the inertia tensor of four equal masses at (±a,±b, 0).
- Compute the tensor of the two-mass asymmetric example in this article and verify
Izz = Ixx + Iyy.
- Derive the inertia tensor of a slender rod lying at angle ϕ in the xy plane.
- Evaluate the rotated-rod tensor at ϕ = 45∘.
- Prove that the scalar moment about an arbitrary unit axis is In = nT In.
- Derive K =
 ωT Iω.
- Show that tr(I) = 2 ∫
r2 dm.
- Derive the tensor parallel-axis theorem and recover the scalar theorem from it.
- Explain why principal axes correspond to eigenvectors of the inertia tensor.
32 Summary
The angular momentum of a rigid body rotating about a chosen origin is
The inertia tensor is
Its Cartesian form is
The tensor is symmetric:
The scalar moment about an arbitrary unit axis is
Rotational kinetic energy is
Under a coordinate rotation,
Under an origin shift from the center of mass,
M05-10 uses the symmetry of I to identify principal axes and principal moments of
inertia.
References
References
[1] J. R. Taylor, Classical Mechanics, University Science Books, 2005.
[2] H. Goldstein, C. Poole, and J. Safko, Classical Mechanics, 3rd ed., Addison-Wesley,
2002.
[3] L. D. Landau and E. M. Lifshitz, Mechanics, 3rd ed., Butterworth-Heinemann, 1976.
[4] K. R. Symon, Mechanics, 3rd ed., Addison-Wesley, 1971.