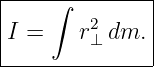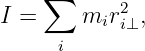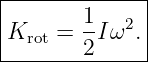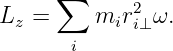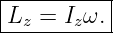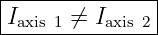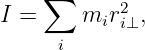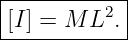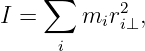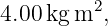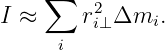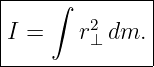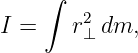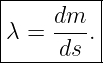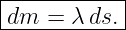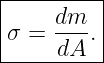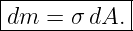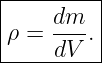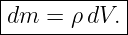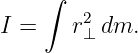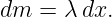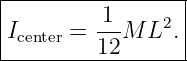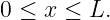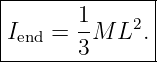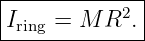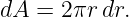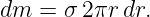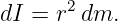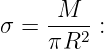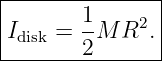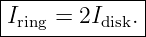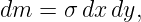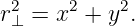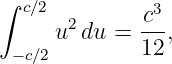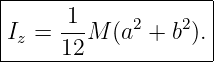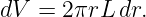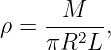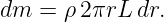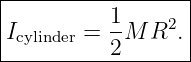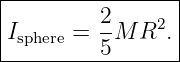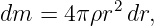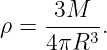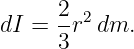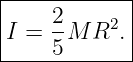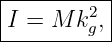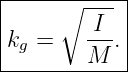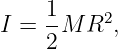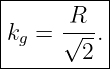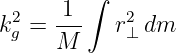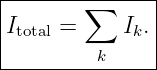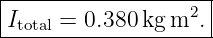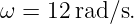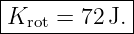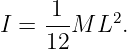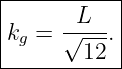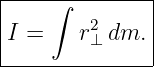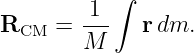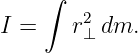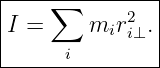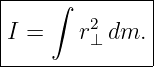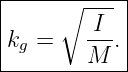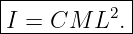Moment of Inertia of Discrete and Continuous Bodies
For translational motion, mass measures resistance to acceleration.
For rotation about a specified axis, the corresponding mass-distribution quantity is the moment of
inertia.
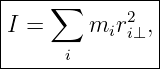
For a collection of particles rotating about a fixed axis,
where ri⊥ is the perpendicular distance from particle i to the rotation axis.
For a continuous body, the sum becomes an integral:
The square on the distance is crucial. Moving mass farther from the axis increases the moment of
inertia strongly.
Moment of inertia therefore depends on:
- total mass,
- shape,
- distribution of mass,
- location and direction of the chosen axis.
It is not a property of a body alone. It is a property of a body about a specified axis.
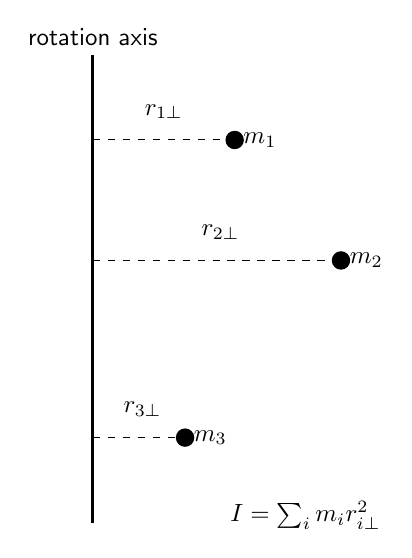
Figure 1. For discrete masses, each contribution to the moment of inertia is miri⊥2, where ri⊥ is
the perpendicular distance to the chosen axis.
1 Why the distance is squared
Consider a point mass m rotating with angular speed ω at perpendicular radius r⊥.
Its speed is
Its kinetic energy is
| K | =  mv2 | (4)
|
| =  m  2 | (5)
|
| =  mr⊥2ω2. | (6) |
For many particles in the same rigid body rotation,
| K | = ∑
i miri⊥2ω2 | (7)
|
| =  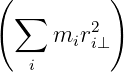 ω2. | (8) |
This motivates the definition
so that
The squared distance is therefore a direct consequence of the relation
2 Axial angular momentum connection
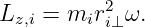
For a particle rotating about the z axis,
Summing over all particles,
Thus
The same mass-distribution quantity therefore appears in both rotational kinetic energy and axial
angular momentum.
3 Moment of inertia depends on the axis
Suppose the same body is rotated about two different axes.
The particle distances ri⊥ generally change.
Therefore
in general.
Even if the axis direction is unchanged, translating the axis to a different location usually changes
I.
This axis dependence is developed systematically in M05-05 using the parallel-axis theorem.
4 Units and dimensions
From
the SI unit is
The dimensions are
Moment of inertia is not a torque, energy, or angular momentum.
5 Mass near the axis versus mass far from the axis
Because
doubling a particle’s radius multiplies its contribution to I by four.
Tripling the radius multiplies the contribution by nine.
For equal masses:
A relatively small amount of mass far from the axis can contribute more rotational inertia than a
larger amount of mass close to the axis.
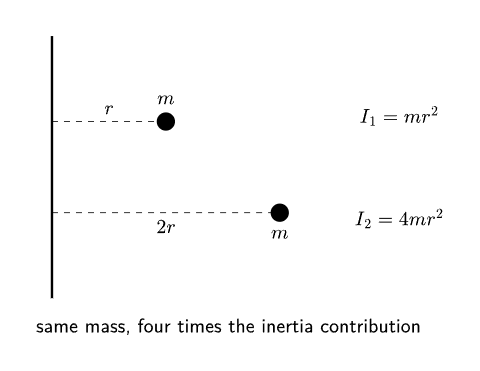
Figure 2. Equal masses contribute very differently depending on radius. A mass at 2r contributes
four times as much moment of inertia as the same mass at r.
6 Example 1: three point masses
Three point masses rotate about the z axis:
| m1 | = 2 kg, | r1 | = 0.50 m, | (21)
|
| m2 | = 3 kg, | r2 | = 1.00 m, | (22)
|
| m3 | = 1 kg, | r3 | = 2.00 m. | (23) |
Then
| Iz | = m1r12 + m
2r22 + m
3r32 | (24)
|
| = 2(0.50)2 + 3(1.00)2 + 1(2.00)2 | (25)
|
| = 0.50 + 3.00 + 4.00. | (26) |
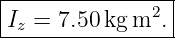
Therefore
Although m3 is the smallest mass, it contributes
more than either of the other particles, because it is farthest from the axis.
7 From a discrete sum to a continuous integral
A continuous body can be imagined as divided into many small mass elements
The approximate moment of inertia is
Take the limit as each element becomes infinitesimal:
This is the fundamental definition for continuous mass distributions.
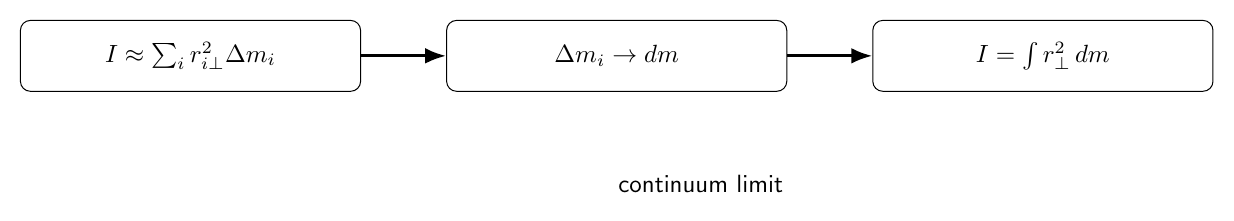
Figure 3. A continuous body is divided into small mass elements. In the continuum limit, the
discrete sum becomes I = ∫
r⊥2 dm.
8 Choosing the correct mass element
To evaluate
the mass element dm must be expressed in terms of the chosen geometric coordinates.
The appropriate density depends on the dimensional character of the idealized body.
8.1 Linear mass density
For a thin wire or rod,
Therefore
For uniform linear density,
8.2 Surface mass density
For a thin plate or lamina,
Therefore
For uniform surface density,
8.3 Volume mass density
For a three-dimensional body,
Therefore
For uniform volume density,
9 General integration workflow
A reliable moment-of-inertia calculation follows the sequence:
- Specify the rotation axis.
- Choose coordinates adapted to the geometry.
- Write r⊥, the perpendicular distance from the mass element to the axis.
- Express dm using λ, σ, or ρ.
- Set the integration limits.
- Evaluate
- Check units and limiting behavior.
The geometry of r⊥ is often the most important step.
10 Uniform thin rod about its center
Consider a thin rod of length L and mass M lying along the x axis from
to
Let the rotation axis pass through the rod’s center and be perpendicular to the rod.
The linear density is
A small element has mass
Its perpendicular distance to the axis is
Therefore
| I | = ∫
−L∕2L∕2x2 dm | (48)
|
| =  ∫
−L∕2L∕2x2 dx | (49)
|
| =   −L∕2L∕2. | (50) |
Thus
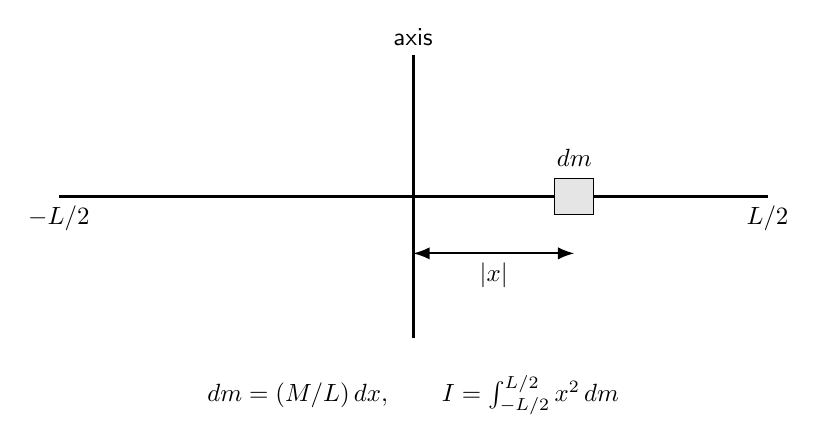
Figure 4. For a uniform thin rod rotated about a perpendicular axis through its center,
dm = (M∕L)dx and r⊥ = |x|.
11 Uniform thin rod about one end
Now place the perpendicular rotation axis through one end of the same rod.
Choose
Then
| Iend | =  ∫
0Lx2 dx | (53)
|
| =   . | (54) |
Therefore
The same rod has a larger moment of inertia about its end because more of its mass lies farther
from the axis.
In M05-05 this result will be recovered immediately using the parallel-axis theorem.
12 Thin ring about its symmetry axis
Consider a thin ring of radius R and total mass M.
Every mass element lies at the same perpendicular distance:
Therefore
| I | = ∫
R2 dm | (57)
|
| = R2 ∫
dm | (58)
|
| = MR2. | (59) |
Thus
No detailed integration is needed because the distance from every mass element to the axis is
constant.
13 Uniform disk about its symmetry axis
Consider a thin uniform disk of radius R and mass M.
Its surface density is
Divide the disk into thin circular rings of radius r and width dr.
The ring area is
Thus
The contribution to moment of inertia is
Therefore
| I | = ∫
0Rr2σ 2πr dr | (65)
|
| = 2πσ ∫
0Rr3 dr | (66)
|
| = 2πσ . | (67) |
Substitute
The same result holds for a uniform solid cylinder about its symmetry axis because each cross
section perpendicular to the axis has the same radial mass distribution.
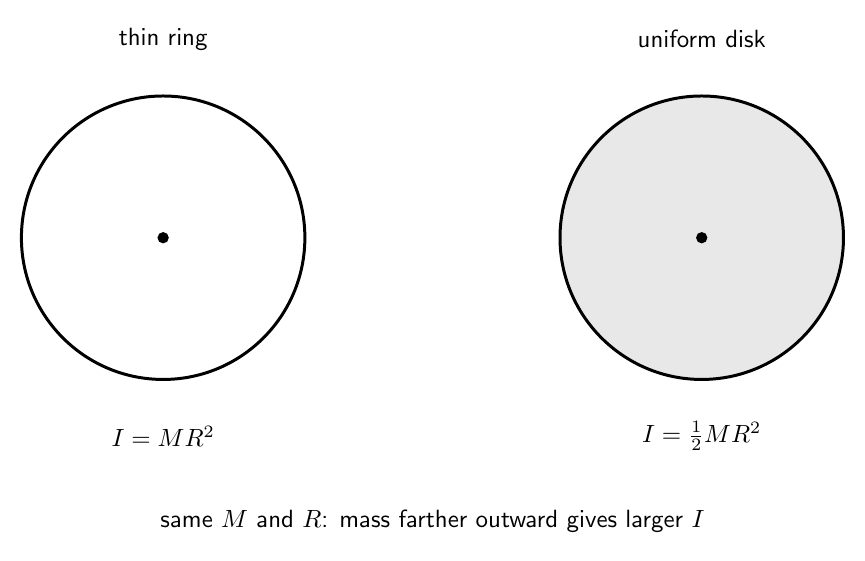
Figure 5. A thin ring places all its mass at radius R, giving I = MR2. A uniform disk distributes
mass from r = 0 to R, giving the smaller value I =  MR2.
14 Why the ring has larger inertia than the disk
For equal mass and equal outer radius,
| Iring | = MR2, | (70)
|
| Idisk | =  MR2. | (71) |
Therefore
The ring places all of its mass at the maximum radius.
The disk places much of its mass closer to the axis, where the r2 weighting is smaller.
15 Uniform rectangular plate about a perpendicular central axis
Consider a thin rectangular plate of mass M, side lengths a and b, centered at the origin in the xy
plane.
Let the rotation axis be the z axis through the center.
The surface density is
For an element
the squared perpendicular distance is
Thus
| Iz | = σ ∫
−a∕2a∕2 ∫
−b∕2b∕2(x2 + y2) dy dx. | (76) |
Separate the integrals:
| Iz | = σ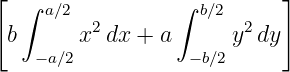 . | (77) |
Using
we obtain
| Iz | = σ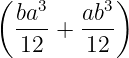 | (79)
|
| =   (a2 + b2). | (80) |
Therefore
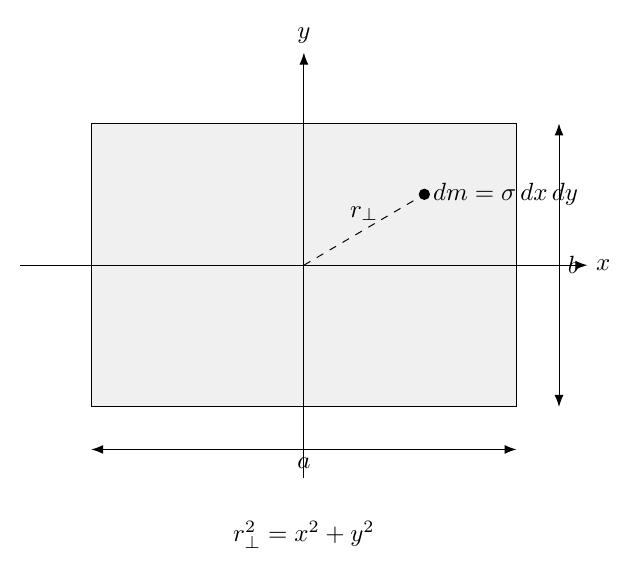
Figure 6. For a rectangular plate about the perpendicular axis through its center, r⊥2 = x2 + y2
and the area integral separates naturally.
16 Uniform solid cylinder
For a uniform solid cylinder of radius R, length L, and mass M, rotated about its symmetry axis,
use cylindrical coordinates.
A thin cylindrical shell of radius r, thickness dr, and length L has volume
With uniform volume density
Then
| I | = ∫
0Rr2 dm | (85)
|
| = 2πρL∫
0Rr3 dr. | (86) |
Therefore
The cylinder length cancels because distance to the symmetry axis depends only on
radius.
17 Uniform solid sphere about a diameter
For a uniform solid sphere of radius R and mass M, the moment of inertia about any diameter
is
One direct derivation uses thin spherical shells.
A thin shell of radius r and thickness dr has mass
where
A thin spherical shell has moment of inertia
Therefore
| I | = ∫
0R r2 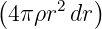 | (92)
|
| =  ∫
0Rr4 dr | (93)
|
| =  . | (94) |
Substituting the density gives
The shell result itself can be derived from a surface integral. It is quoted here to keep the
solid-sphere calculation focused on the radial assembly of shells.
18 Reference values
For commonly encountered uniform bodies:
These formulas should not be memorized without understanding the axis and mass distribution
that define them.
19 Radius of gyration
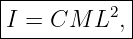
Any moment of inertia can be written as
where kg is the radius of gyration.
Thus
The radius of gyration is the radius at which the entire mass could be concentrated as a point mass
while preserving the same moment of inertia about the chosen axis.
For a uniform disk,
so
For a thin ring,
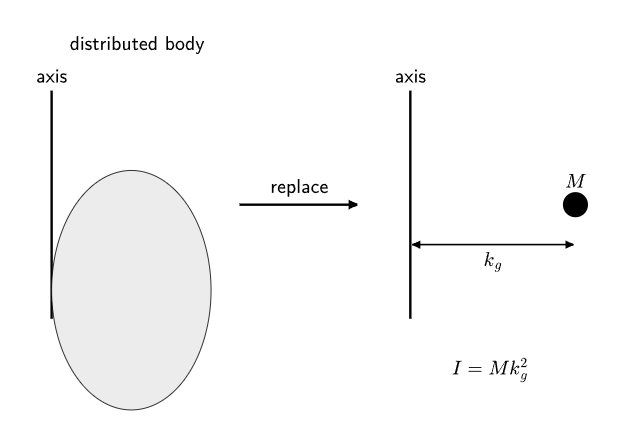
Figure 7. The radius of gyration kg replaces a distributed body by an equivalent point-mass
radius for the purpose of matching the same moment of inertia.
20 Physical interpretation of radius of gyration
The relation
shows that kg is a root-mean-square distance from the rotation axis.
It is not the average radius.
It weights larger radii more strongly because the squared distance is averaged.
21 Scaling of moment of inertia
Suppose two geometrically similar uniform bodies have the same shape but different characteristic
size L.
Their moments of inertia have the form
where C is a dimensionless shape factor.
For example:
| Cring | = 1, | (103)
|
| Cdisk | =  , | (104)
|
| Csphere | =  . | (105) |
If mass is held fixed and all linear dimensions are doubled,
If density is held fixed instead, mass itself scales with volume:
Then
for geometrically similar three-dimensional bodies of fixed density.
22 Composite bodies
If a body consists of several nonoverlapping pieces about the same axis,
Every component inertia must be evaluated about the same final axis.
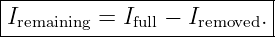
A missing region or cavity can be handled by treating the removed material as a negative mass
distribution:
This method is especially useful once M05-05 provides the parallel-axis theorem for components
whose own natural center axes do not coincide with the final rotation axis.
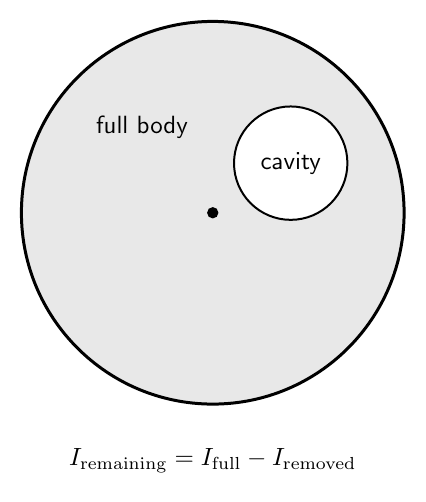
Figure 8. Moments of inertia add for material pieces about the same axis. A cavity can be treated
as a negative contribution from the removed mass distribution.
23 Example 2: ring plus disk about a common axis
A thin ring and a uniform disk rotate together about a common symmetry axis.
Let
| Mr | = 2.0 kg, | Rr | = 0.40 m, | (111)
|
| Md | = 3.0 kg, | Rd | = 0.20 m. | (112) |
The ring inertia is
| Ir | = MrRr2 | (113)
|
| = 2.0(0.40)2 | (114)
|
| = 0.320 kg m2. | (115) |
The disk inertia is
| Id | =  MdRd2 | (116)
|
| =  (3.0)(0.20)2 | (117)
|
| = 0.060 kg m2. | (118) |
Therefore
24 Example 3: rotational kinetic energy
A uniform disk has
| M | = 8.0 kg, | (120)
|
| R | = 0.50 m, | (121) |
and rotates about its symmetry axis at
Its moment of inertia is
| I | =  MR2 | (123)
|
| =  (8.0)(0.50)2 | (124)
|
| = 1.0 kg m2. | (125) |
Thus
| Krot | =  Iω2 | (126)
|
| =  (1.0)(12)2 | (127)
|
| = 72 J. | (128) |
Therefore
25 Example 4: radius of gyration of a rod
For a uniform thin rod about a perpendicular central axis,
Thus
| kg | =  | (131)
|
| =  | (132)
|
| =  . | (133) |
Therefore
26 Moment of inertia is not the area moment of inertia
Engineering uses another quantity often called a second moment of area or area moment of
inertia:
That quantity is important in beam bending and structural mechanics.
The mass moment of inertia used in rigid body dynamics is instead
The concepts are mathematically similar but physically different and have different
units.
27 Moment of inertia and the center of mass
The center of mass uses the first power of position:
Moment of inertia uses squared perpendicular distance:
Thus the center of mass tells where the mass is balanced, while moment of inertia tells how
strongly the mass is spread away from an axis.
Two bodies can have the same mass and the same center of mass but very different moments of
inertia.
28 Common mistakes
- Quoting a moment-of-inertia formula without specifying the axis.
- Using distance from the origin instead of perpendicular distance to the rotation axis.
- Forgetting the square on r⊥.
- Treating moment of inertia as depending only on total mass.
- Using the same I for different parallel or differently oriented axes.
- Confusing moment of inertia with torque or angular momentum.
- Using dm = λdx when the density is not uniform without accounting for λ(x).
- Using surface density for a three-dimensional body or volume density for an ideal thin
lamina.
- Forgetting the Jacobian or geometric factor in dA or dV , such as dA = 2πr dr for a
ring element of a disk.
- Assuming the ring and disk have the same I because they have the same M and R.
- Confusing radius of gyration with mean radius.
- Adding component moments of inertia evaluated about different axes.
- Confusing mass moment of inertia with the area moment of inertia used in structural
mechanics.
- Using the parallel-axis theorem before checking whether the axes are actually parallel.
That theorem is developed in M05-05.
29 Practice exercises
- Four point masses each of mass m lie at the corners of a square of side a. Find the
moment of inertia about an axis perpendicular to the square through its center.
- Three point masses have (m,r⊥) pairs (1 kg, 1 m), (2 kg, 2 m), and (3 kg, 0.5 m). Find
I.
- Derive the moment of inertia of a uniform thin rod about a perpendicular axis through
its center.
- Derive the moment of inertia of the same rod about a perpendicular axis through one
end directly from integration.
- Derive I = MR2 for a thin ring about its symmetry axis.
- Derive I =
 MR2 for a uniform disk using concentric ring elements.
- Explain physically why the ring has twice the inertia of a disk with the same M and
R.
- Derive the moment of inertia of a rectangular plate about a perpendicular axis through
its center.
- A solid cylinder has M = 5 kg and R = 0.30 m. Find its moment of inertia about its
symmetry axis.
- A solid sphere has M = 4 kg and R = 0.20 m. Find its moment of inertia about a
diameter.
- Find the radius of gyration of a thin ring, uniform disk, and solid sphere about their
standard symmetry axes.
- A composite rotor consists of a disk and a coaxial ring. Find its total moment of inertia
in terms of the component masses and radii.
- For geometrically similar three-dimensional bodies of fixed density, show that I ∝ L5.
- Explain how two bodies can have the same mass and center of mass but different
moments of inertia.
- A body has I = 6 kg m2 and M = 24 kg. Find its radius of gyration.
30 Summary
For discrete masses,
For a continuous body,
The appropriate mass elements are
| dm = λds | for a line distribution, | (141)
|
| dm = σ dA | for a surface distribution, | (142)
|
| dm = ρdV | for a volume distribution. | (143) |
Moment of inertia enters fixed-axis rotational energy and angular momentum:
Krot =  Iω2, | | (144)
|
| Lz = Izω. | | (145) |
The radius of gyration is
For geometrically similar bodies,
The next article, M05-05, develops the parallel-axis and perpendicular-axis theorems, which allow
many new moments of inertia to be obtained from known central-axis results.
References
References
[1] J. R. Taylor, Classical Mechanics, University Science Books, 2005.
[2] D. Kleppner and R. Kolenkow, An Introduction to Mechanics, 2nd ed., Cambridge
University Press, 2014.
[3] K. R. Symon, Mechanics, 3rd ed., Addison-Wesley, 1971.
[4] OpenStax, University Physics, Volume 1, Rice University, 2016.