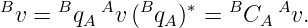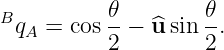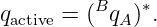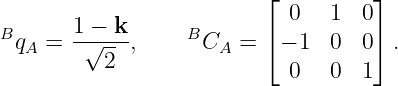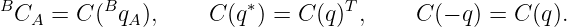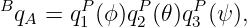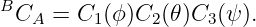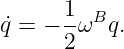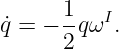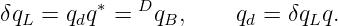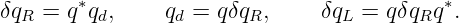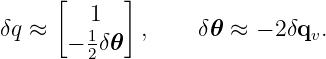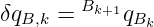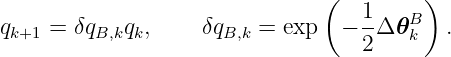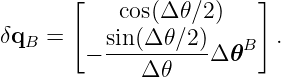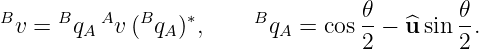Quaternion Series Overview and Article Guide
The PhysicsLibrary quaternion collection is organized as an engineering and physics learning path
rather than as a purely algebraic development. It begins with notation and convention
discipline, establishes the quaternion algebra needed for computation, develops three
dimensional orientation and frame to frame coordinate transformations, and then proceeds to
angular rate kinematics, relative attitude, estimation errors, and inertial measurement unit
propagation.
The collection is intended for students and practitioners in mechanics, rigid body dynamics,
spacecraft attitude determination and control, inertial navigation, robotics, simulation, and
related fields. The deeper algebraic structure of quaternions remains important, but
the first objective is to make quaternion formulas unambiguous and usable in physical
applications.
The quaternion and Euler Angle series share one geometric convention: passive coordinate
transformations are the primary attitude maps, and named rotation sequences are interpreted
intrinsically, meaning that successive rotations are about axes of the current, already-rotated
frame.
1 Article sequence
|
|
| ID | Article |
|
|
| Q00 | Quaternions for Physics and Engineering: Orientation, Notation, and
Conventions |
|
|
| Q01 | Quaternion Definition and Basic Algebra |
|
|
| Q01 | Quaternion Definition and Basic Algebra: Examples, Exercises, and
Solution |
|
|
| Q02 | Quaternion Product in Scalar Vector Form |
|
|
| Q02E | Quaternion Product in Scalar Vector Form: Examples, Exercises,
and Solutions |
|
|
| Q03 | Quaternion Conjugate |
|
|
| Q03E | Quaternion Conjugate: Examples, Exercises, and Solutions |
|
|
| Q04 | Quaternion Norm |
|
|
| Q04E | Quaternion Norm: Examples, Exercises, and Solutions |
|
|
| Q05 | Quaternion Inverse |
|
|
| Q05E | Quaternion Inverse: Examples, Exercises, and Solutions |
|
|
| Q06 | Axis Angle Representation and Unit Quaternion |
|
|
| Q06E | Axis Angle Representation and Unit Quaternion: Examples,
Exercises, and Solutions |
|
|
| Q07 | Rotating Vectors with Quaternions |
|
|
| Q07E | Rotating Vectors with Quaternions: Examples, Exercises, and
Solutions |
|
|
| Q08 | Composition of Rotations and Quaternion Order |
|
|
| Q08E | Composition of Rotations and Quaternion Order: Examples,
Exercises, and Solutions |
|
|
| Q09 | Quaternions and Direction Cosine Matrices |
|
|
| Q09E | Quaternions and Direction Cosine Matrices: Examples, Exercises,
and Solutions |
|
|
| Q10 | Quaternions and Euler Angles |
|
|
| Q10E | Quaternions and Euler Angles: Examples, Exercises, and Solutions |
|
|
| Q11 | Quaternion Kinematics and Angular Velocity |
|
|
| Q11E | Quaternion Kinematics and Angular Velocity: Examples, Exercises,
and Solutions |
|
|
| Q12 | Relative Attitude and Error Quaternions |
|
|
| Q12E | Relative Attitude and Error Quaternions: Examples, Exercises, and
Solutions |
|
|
| Q13 | Numerical Quaternion Propagation and IMU Attitude State
Integration |
|
|
| Q13E | Numerical Quaternion Propagation and IMU Attitude State
Integration: Examples, Exercises, and Solutions |
|
|
| Q14 | Quaternion Exercises for Physics and Engineering |
|
|
2 PhysicsLibrary quaternion convention
Unless an article explicitly states otherwise, PhysicsLibrary uses Hamilton multiplication, scalar
first mathematical notation, right handed orthonormal frames, positive frame rotation according to
the right hand screw rule, passive frame to frame coordinate transformations, and intrinsic moving
axis interpretation for named Euler sequences.
The canonical attitude quaternion is written Bq
A. It maps coordinates from frame A into frame B,
in the same direction as the passive direction cosine matrix BC
A:
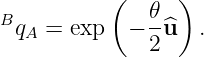
If frame B is obtained from frame A by a positive right handed rotation of the axes through angle
𝜃 about unit axis u, then the passive axis angle quaternion is
The minus sign is the passive counterpart of the familiar positive angle active rotor. For
example, a positive 90∘ frame rotation about +z gives Bq
A =  ∕2 − (
 ∕2)k, and
a fixed physical vector with coordinates [1, 0, 0]T in A has coordinates [0,−1, 0]T in
B.
The inverse map is Aq
B = (Bq
A)∗. Hamilton multiplication then chains passive quaternion maps in
the same written order as passive DCMs:
This common frame direction is a central design choice of the revised PhysicsLibrary orientation
series.
The detailed convention discussion belongs in Quaternions for Physics and Engineering:
Orientation, Notation, and Conventions.
3 Passive convention and older literature
The current PhysicsLibrary quaternion series uses the passive frame convention declared above
throughout the convention sensitive engineering articles.
Many books, papers, software libraries, and older PhysicsLibrary entries use the inverse active
viewpoint. Under Hamilton multiplication, the active rotor for the same positive geometric rotation
is the conjugate of the PhysicsLibrary passive frame quaternion:
Consequently, formulas taken from an active source may differ by a quaternion conjugate, DCM
transpose, vector sign, or multiplication side even when the underlying physical orientation is the
same.
Hamilton’s algebra itself does not change. The articles on definition, product, conjugate, norm, and
inverse are therefore algebraically stable across the convention change. Convention sensitive articles
explicitly use the passive frame map for axis angle orientation, vector coordinate transformation,
composition, quaternion DCM conversion, quaternion Euler conversion, kinematics, relative
attitude, error quaternions, and IMU propagation.
A useful diagnostic is the positive 90∘ frame rotation about +z:
A fixed physical vector with A coordinates [1, 0, 0]T therefore has B coordinates [0,−1, 0]T .
4 How the articles fit together
The material naturally falls into three stages.
1. Conventions and algebra
Begin with Quaternions for Physics and Engineering: Orientation, Notation, and Conventions,
then read quaternion definition and basic algebra, quaternion product in Scalar Vector Form,
Quaternion Conjugate, quaternion norm, and quaternion inverse.
These entries establish the Hamilton basis rule ij = k, scalar/vector decomposition, the Hamilton
product, conjugation, norm, and the identity q−1 = q∗∕∥q∥2. For a unit quaternion,
q−1 = q∗.
Storage order is treated separately from algebra. A program may store [qw,qx,qy,qz] or
[qx,qy,qz,qw] while still using the same Hamilton multiplication.
2. Frame transformations and attitude representations
Continue with Axis Angle Representation and Unit Quaternion, rotating vectors with quaternions,
composition of rotations and quaternion order, quaternions and direction cosine matrices, and
quaternions and Euler angles.
The axis angle article develops the fundamental passive parameterization and its quaternion
exponential,
The rotating vectors article derives the passive quaternion sandwich and its Rodrigues equivalent.
The composition article shows why finite transformations do not commute and why explicit frame
labels determine factor order more reliably than verbal mnemonics.
The DCM article establishes
For intrinsic 3-2-1 yaw, pitch, roll, with ψ yaw, 𝜃 pitch, and ϕ roll,
Quaternion and DCM sequence products therefore have the same written factor order.
3. Kinematics, estimation, and IMU propagation
Finish the main engineering path with quaternion kinematics and angular velocity, relative attitude
and error quaternions, and numerical quaternion propagation and IMU attitude state
integration.
Let
map inertial coordinates into body coordinates. If ωB is the angular velocity of B relative to I,
resolved in the body frame and embedded as a pure quaternion, then
If the same physical angular velocity is resolved in the inertial frame,
For relative attitude, let q = Bq
I be the actual attitude and qd = Dq
I the desired attitude. The left
multiplicative error is the direct actual to desired passive frame map:
A right multiplicative error may instead be defined by
For a small positive passive frame error,
For sampled body rate propagation, first correct the measured rate or delta angle for estimated
gyroscope bias. The passive body increment
left multiplies the current inertial to body state:
For Δ𝜃 = ∥Δ𝜃B∥≠0,
The numerical propagation article develops bias correction, exact exponential increments,
numerical integration, normalization, sign continuity, coning, time centered attitude
use, and the relationship between attitude propagation and body to navigation vector
transformation.
5 Self study companions
Beginning with Q06, each convention sensitive engineering article has a separate companion in
which all exercises are stated first and complete worked solutions follow afterward.
The companion sequence is:
- Axis Angle Representation and Unit Quaternion: Examples, Exercises, and Solutions;
- Rotating Vectors with Quaternions: Examples, Exercises, and Solutions;
- Composition of Rotations and Quaternion Order: Examples, Exercises, and Solutions;
- Quaternions and Direction Cosine Matrices: Examples, Exercises, and Solutions;
- Quaternions and Euler Angles: Examples, Exercises, and Solutions;
- Quaternion Kinematics and Angular Velocity: Examples, Exercises, and Solutions;
- Relative Attitude and Error Quaternions: Examples, Exercises, and Solutions;
- Numerical Quaternion Propagation and IMU Attitude State Integration: Examples,
Exercises, and Solutions.
Each companion uses the same passive frame convention as its parent article. A worked example is
therefore also a convention test: its signs, multiplication side, DCM transpose, and frame labels
must agree with the parent derivation.
6 Recommended reading paths
First engineering introduction
A compact first route is:
- Quaternions for Physics and Engineering: Orientation, Notation, and Conventions;
- Quaternion Definition and Basic Algebra;
- Quaternion Conjugate, Quaternion Norm, and Quaternion Inverse;
- Axis Angle Representation and Unit Quaternion;
- Rotating Vectors with Quaternions;
- Quaternions and Direction Cosine Matrices.
This path establishes enough algebra and geometry to construct and apply passive attitude
quaternions without immediately requiring rigid body kinematics.
Spacecraft attitude, robotics, and rigid body simulation
After the transformation articles, continue with Quaternions and Euler Angles, Quaternion
Kinematics and Angular Velocity, and Relative Attitude and Error Quaternions.
Inertial navigation and IMU propagation
For strapdown applications, emphasize Axis Angle Representation and Unit Quaternion, Rotating
Vectors with Quaternions, Quaternions and Direction Cosine Matrices, Quaternion Kinematics and
Angular Velocity, Relative Attitude and Error Quaternions, and Numerical Quaternion
Propagation and IMU Attitude State Integration.
The kinematics article supplies the continuous passive rate equation, the relative attitude article
supplies the local multiplicative error concept, and the numerical article applies both to sampled
gyroscope measurements and IMU delta angles.
7 Core formula map
The main formulas of the engineering sequence can be summarized compactly as
| q | = qw + qxi + qyj + qzk, | |
|
| q−1 | = q∗∕∥q∥2, | |
|
| Bq
A | = cos(𝜃∕2) −u sin(𝜃∕2), | |
|
| Bv | = Bq
A Av (Bq
A)∗, | |
|
| Cq
A | = Cq
B Bq
A, | |
|
| BC
A | = C(Bq
A), | |
|
| Bq
A | = q1P (ϕ)q
2P (𝜃)q
3P (ψ) for intrinsic 3-2-1, | |
|
| q | = − ωBq = −  qωI for q = Bq
I, | |
|
| δqL | = qdq∗, δq
R = q∗q
d, | |
|
| δq | ≈ [1,− δ𝜃T ]T , | |
|
| δqB,k | = exp(− Δ𝜃kB), | |
|
| qk+1 | = δqB,kqk. | | |
This map is a guide, not a substitute for the individual derivations.
8 Conceptual relationships
Several relationships recur throughout the series.
- Quaternion algebra and quaternion attitude convention are different layers.
Hamilton multiplication remains unchanged when the application convention is
changed from active vector rotation to passive coordinate transformation.
- Storage order is not multiplication convention. Scalar-first and scalar last arrays
can represent the same Hamilton quaternion.
- The PhysicsLibrary attitude quaternion is a passive coordinate map. The
physical vector is held fixed while its components are transformed between reference
frames.
- Quaternion and DCM frame directions are deliberately aligned. Both Bq
A
and BC
A map A coordinates into B coordinates.
- Intrinsic describes a sequence construction. For a named Euler sequence,
successive elementary rotations are about axes of the moving frame.
- Positive passive and active axis angle quaternions are conjugates. For the
same positive geometric angle, the passive frame quaternion has the opposite vector
part sign from the positive active rotor.
- Euler Angles are local coordinates. They remain valuable for interpretation but
have coordinate singularities; quaternions and DCMs provide globally nonsingular
orientation propagation.
- A global quaternion and a local three component error are complementary.
The nominal state may remain a unit quaternion while an estimator linearizes a small
relative frame transformation.
- IMU propagation is repeated frame composition. Each gyro sample produces
a small passive body frame increment whose sign, multiplication order, and bias
correction must agree with the declared attitude state.
9 Series wide verification cases
Convention sensitive formulas should be checked against a common battery of simple
cases:
- identity orientation;
- positive 90∘ frame rotations about +x, +y, and +z;
- inverse transformation by quaternion conjugation and DCM transpose;
- q versus −q;
- two noncommuting successive rotations;
- quaternion to DCM to quaternion round trip;
- intrinsic 3-2-1 quaternion and DCM agreement;
- zero angular rate and constant single axis angular rate;
- left versus right multiplicative attitude error;
- the passive small error sign δ𝜃 ≈−2δqv;
- body resolved IMU increments left multiplying the inertial to body attitude state.
These checks are intentionally repetitive across the series. A convention error that survives
symbolic manipulation is often exposed immediately by one of the 90∘ coordinate tests.
10 Where deeper mathematics fits
The engineering sequence intentionally reaches applications before pursuing the deeper algebra. A
later mathematical branch can develop division algebras, the geometry of the unit three sphere,
SU(2), the double covering of SO(3), Lie groups and Lie algebras, and exponential and logarithmic
maps.
Those subjects explain why the engineering formulas have the structure they do, but they are not
prerequisites for beginning quaternion attitude work.
11 Summary
The PhysicsLibrary quaternion series proceeds from convention discipline and Hamilton algebra to
passive frame transformations, direction cosine matrices, intrinsic Euler angles, angular rate
kinematics, attitude errors, and sampled IMU propagation.
Its convention can be remembered from four statements:
A reader who follows the collection should be able not only to quote quaternion formulas, but also
to determine what a formula means, identify its convention, derive multiplication order from frame
labels, test a transformation with a simple coordinate example, and use the result consistently in a
physical or numerical application.
License
This article is an original synthesis prepared for PhysicsLibrary and intended for release under CC
BY-SA 4.0.