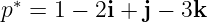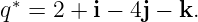|
|
|
|||||||
the conjugate is
In scalar vector notation,
Conjugation is an involution:
It is real linear:
Most importantly, conjugation reverses product order:
The product of a quaternion with its conjugate is real:
For a unit quaternion,
For the PhysicsLibrary passive attitude convention,
2 Exercises
3 Solutions
Solution 1: basic conjugationThe quaternion is
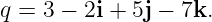 Conjugation leaves the scalar coefficient unchanged and changes the sign of the vector part:
The scalar first component columns are
The scalar component is unchanged.
Solution 2: real and pure special casesFor the real quaternion
 the vector part is zero, so
For the pure quaternion
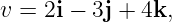 the scalar part is zero. Therefore
Thus real quaternions are fixed by conjugation, while pure quaternions change sign.
Solution 3: conjugation as an involutionWrite
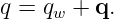 Then
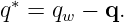 Conjugate again:
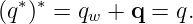 Therefore
For
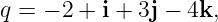 we have
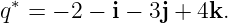 Conjugating again gives
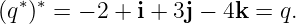
Solution 4: conjugate of a sum and real scalar multipleFirst,
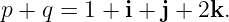 Therefore
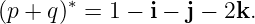 Separately,
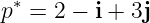 and
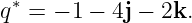 Hence
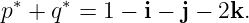 Thus
Also,
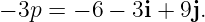 Therefore
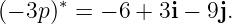 Meanwhile,
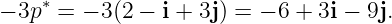 Thus
Solution 5: product reversal using basis quaternionsHamilton multiplication gives
 Therefore
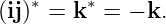 Now
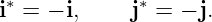 Hence
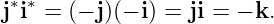 Thus
If the factor order were not reversed, one would obtain
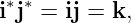 which has the wrong sign.
Solution 6: product reversal for general numerical quaternionsLet
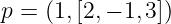 and
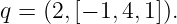 Using the Hamilton product,
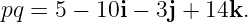 Therefore
Now
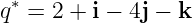 and
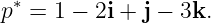 Multiplying in the reversed order gives
Hence
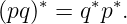
Solution 7: why
|
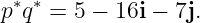 | (24) |
But from Solution 6,
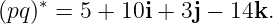
These are not equal.
The conjugation rule reverses factor order because quaternion multiplication is not generally commutative.
For
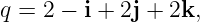
the conjugate is
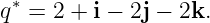
The scalar part of qq∗ is
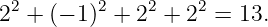
The vector part cancels.
Therefore
 | (25) |
Similarly,
 | (26) |
Both products are the same real quaternion.
 in scalar vector form
Let
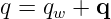
and
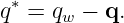
Use the Hamilton scalar vector product.
The scalar part is
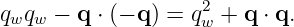
The vector part is
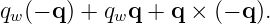
The first two terms cancel, and
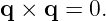
Therefore the vector part vanishes.
Thus
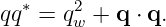 | (27) |
For
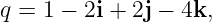
the sum of the squared components is
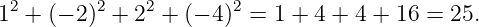
Therefore
 | (28) |
This is the squared Euclidean norm of the four component column:
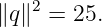 | (29) |
Hence

Associativity permits us to write
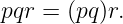
Take the conjugate:
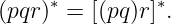
Using product reversal once,
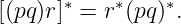
Use it again:
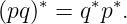
Therefore
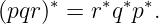 | (30) |
Likewise,
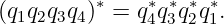 | (31) |
Conjugation reverses the entire factor sequence.
For pure quaternions,
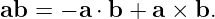
The dot product term is real and is unchanged by conjugation.
The cross product term is pure and changes sign.
Therefore
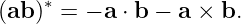 | (32) |
Now reverse the pure factors:
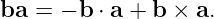
Because
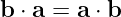
and
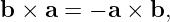
we obtain
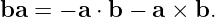
Hence
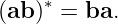 | (33) |
The forward passive frame quaternion is
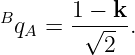
Its conjugate is
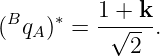
For a unit attitude quaternion,
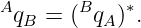
Therefore
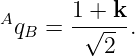 | (34) |
The conjugate reverses the passive coordinate map: it maps B coordinates back into A coordinates.
Start from
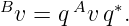
Left multiply by q∗:
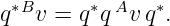
Because q is unit,

Thus
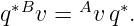
Right multiply by q:
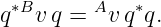
Again,

Therefore
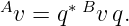 | (35) |
The reverse coordinate transformation uses the conjugate quaternion in the opposite sandwich order.
 versus
 is not the same as
 versus

Given
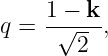
the conjugate is
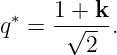 | (36) |
The negative quaternion is
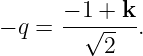 | (37) |
The pair q and q∗ generally represents opposite passive frame maps:
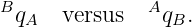
They are inverse transformations.
By contrast, q and −q represent the same physical orientation and the same passive frame map.
Thus conjugation changes map direction, while an overall sign change does not change orientation.
PhysicsLibrary assigns a positive 90∘ frame rotation about +z the passive A → B quaternion
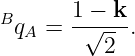
The software reports
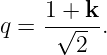
This is exactly the conjugate of the PhysicsLibrary A → B map.
Therefore it more naturally corresponds to
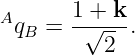 | (38) |
To convert it to the PhysicsLibrary A → B passive map, take the conjugate:
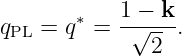
The core identities reinforced by this companion are
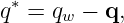 | (39) |
 | (40) |
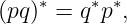 | (41) |
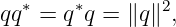 | (42) |
and, for unit passive attitude quaternions,
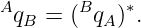 | (43) |
Conjugation is therefore both an algebraic operation and, for unit attitude quaternions, the operation that reverses a frame to frame coordinate map.
The exercises and solutions in this companion are newly written or expanded for PhysicsLibrary from the algebra developed in Quaternion Conjugate.
Hamilton is the foundational source for quaternion conjugation. Joly and Kelland–Tait provide classical systematic treatments of conjugates, products, and norms. Sommer and coauthors provide a modern engineering discussion of quaternion convention management and passive frame transformations.
[1] W. R. Hamilton, Elements of Quaternions, 2nd ed., edited by C. J. Joly, Longmans, Green, and Co., 1899. Public domain historical source. Internet Archive scan
[2] C. J. Joly, A Manual of Quaternions, Macmillan and Co., London, 1905. Public domain historical source. Internet Archive search
[3] P. Kelland and P. G. Tait, Introduction to Quaternions, with Numerous Examples, 2nd ed., Macmillan and Co., London, 1882. Public domain historical source. Internet Archive search
[4] H. Sommer, I. Gilitschenski, M. Bloesch, S. Weiss, R. Siegwart, and J. Nieto, “Why and How to Avoid the Flipped Quaternion Multiplication,” Aerospace, vol. 5, no. 3, article 72, 2018. Published under CC BY 4.0. Publisher article
Unless otherwise noted, this PhysicsLibrary entry is intended for release under the Creative Commons Attribution ShareAlike 4.0 International license.
| Keywords: | quaternion, conjugate, Hamilton product, scalar part, vector part, anti-automorphism, noncommutative algebra, exercises, worked solutions |
| Physics Classification: | 02.10.Hh (Rings and algebras) |
| 02.10.Ud (Linear algebra) |
None.
No messages.

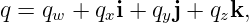
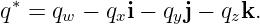


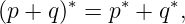
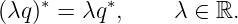
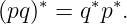
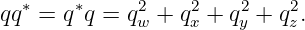

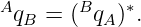
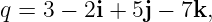

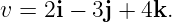


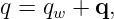

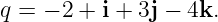
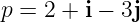
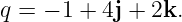
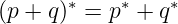
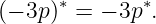


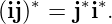
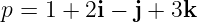
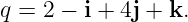


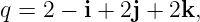


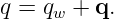
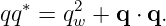
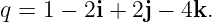
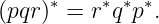
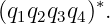
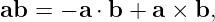
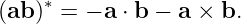

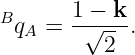


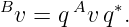
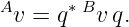


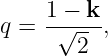
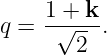
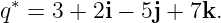
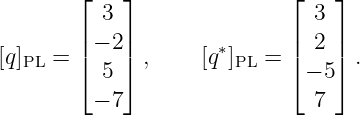
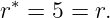
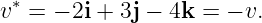

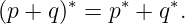
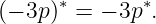
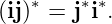
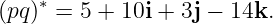
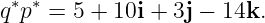
 is generally wrong