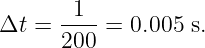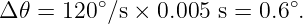|
|
|
|||||||
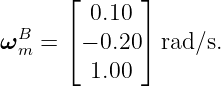
Hamilton multiplication and scalar first display order are used. For body resolved gyroscope angular velocity,
A positive body frame delta angle
 produces the passive incremental quaternion
Because the increment maps the old body frame into the new body frame, it multiplies on the left:
For a small passive frame error,
2 Exercises
3 Solutions
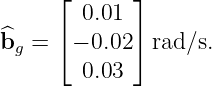
Solution 1: bias correction and delta angleThe corrected rate is
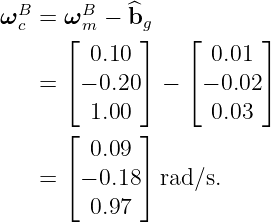 Therefore
The delta angle is
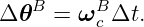 Thus
Solution 2: exact incremental quaternionThe increment magnitude is
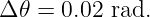 The positive physical frame axis is +z. Under the PhysicsLibrary passive convention,
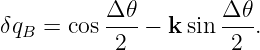 Hence
Numerically,
The negative vector component is the passive sign for a positive frame rotation.
Solution 3: small angle incrementFor a small passive body frame increment,
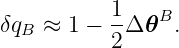 Therefore
Its norm is
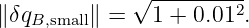 Thus
The first order increment is therefore not exactly unit until normalized.
Solution 4: one exact propagation stepThe initial attitude is
 Body resolved increments left multiply:
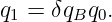 Since q0 = 1,
Therefore
Solution 5: nonidentity attitude and a body incrementThe first order passive increment is
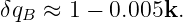 The correct body increment update is
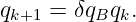 Therefore
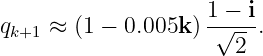 Expand:
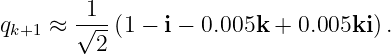 Since
 we obtain
If this first order increment is used numerically, the result should be normalized.
Solution 6: wrong multiplication sideFor
 body resolved angular velocity satisfies
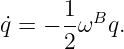 The finite body increment maps
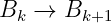 and therefore appears on the left of the existing
 map. Thus the correct update is
Right multiplication would correspond to expressing the increment on the reference side under this passive convention.
Solution 7: forward Euler propagationForward Euler gives
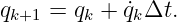 Substitute
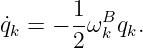 Then
With
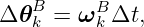 this can also be written
Solution 8: forward Euler norm driftLet
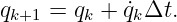 For the exact quaternion differential equation,
 because the derivative is tangent to the unit quaternion three sphere. Thus
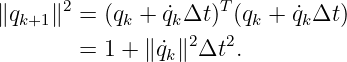 For nonzero angular rate,
The error is second order per step, so repeated unnormalized Euler propagation drifts from unit norm.
Solution 9: gyroscope bias accumulationTen minutes is
 A constant bias of
 therefore accumulates approximately
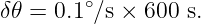 Hence
This illustrates why gyroscope bias estimation and correction are essential.
Solution 10: two hundred hertz constant
|
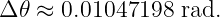 | (23) |
The half angle is approximately
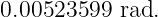
For a positive body frame rotation about +y, the passive increment is
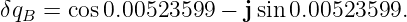 | (24) |
Numerically,
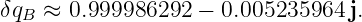 | (25) |
The first order passive increments are
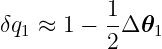
and
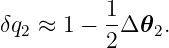
Because the first increment occurs before the second, body frame multiplication gives
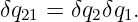
Expand:
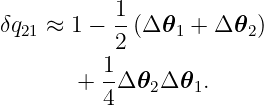
For pure vector quaternions,
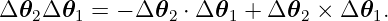
The vector contribution is therefore
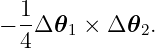
Match this with the passive form
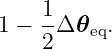
The resulting equivalent physical rotation vector is
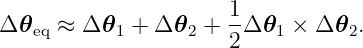 | (26) |
The physical coning cross term has the same positive cross product form, although the quaternion vector part itself carries the passive negative sign.
The cross product is
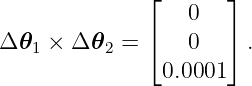
Therefore the leading coning contribution is
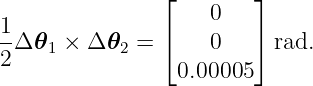 | (27) |
Normalization restores

It does not reconstruct higher order rotational information omitted by a forward Euler step.
The exact exponential update follows the correct finite rotation on the unit quaternion manifold for a constant sample rotation vector.
Normalized Euler first takes a tangent line approximation and then projects that approximate point back onto the unit sphere.
The projected point is generally close to, but not identical with, the exact exponential result.
One commonly applies
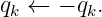 | (28) |
Because q and −q represent the same physical orientation, this operation does not alter attitude.
It simply chooses the representative closer to the preceding quaternion. This improves continuity for plotting, interpolation, finite differencing, and optimization.
The nominal quaternion is a global attitude representation with four stored components constrained by

Therefore it has three independent degrees of freedom.
A local passive multiplicative error can be written
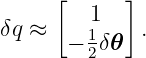
The three vector components of

are therefore sufficient to represent the local orientation perturbation.
An estimator can consequently propagate the nominal attitude as a full unit quaternion while carrying only three attitude error variables in the linearized covariance state.
A typical passive quaternion strapdown propagation order is:
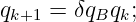
For

the body to inertial specific force transformation is
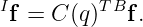
A delta angle output is already the sensor’s estimate of integrated angular motion over the sample.
Converting it to an average rate by dividing by Δt and then multiplying by Δt again adds unnecessary operations.
More importantly, the device may have formed the delta angle using internal high rate samples and may already include coning or other compensation.
Reducing that output to a single average rate can hide how the device formed the integrated quantity and can invite accidental duplicate processing.
Therefore the sensor supplied delta angle is normally the more natural input to the finite quaternion update, subject to the device documentation and bias correction model.
In direct IMU propagation,
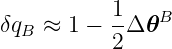
is an approximation to the actual physical rotation occurring during one sample.
Its usefulness depends on the sample rotation being sufficiently small.
In a multiplicative error state filter,
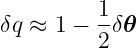
has a different role.
The nominal attitude remains a full unit quaternion representing the global orientation, while the three component vector δ𝜃 represents only a local estimation error around that nominal attitude.
The nominal vehicle attitude may therefore be arbitrarily large even though the error state is intentionally kept small.
| Quantity | PhysicsLibrary passive result |
| Attitude state | q = Bq I |
| Body rate kinematics | q = − ωBq |
| Positive body increment | δqB = exp(−Δ𝜃B∕2) |
| Body increment update | qk+1 = δqBqk |
| Small body increment | δqB ≈ [1,−Δ𝜃B∕2]T |
| Passive error state | δq ≈ [1,−δ𝜃∕2]T |
| Sign continuity | qk ←−qk when qkT q k−1 < 0 |
This companion follows the eighteen problem progression of the earlier PhysicsLibrary example article but rewrites every convention sensitive formula and worked result for the passive inertial to body convention.
Sommer and coauthors provide a modern discussion of quaternion convention management. Solà provides a detailed treatment of quaternion kinematics and error state filtering. Titterton and Weston provide a broad engineering treatment of strapdown inertial navigation. Savage develops classical strapdown attitude integration and coning compensation.
[1] H. Sommer, I. Gilitschenski, M. Bloesch, S. Weiss, R. Siegwart, and J. Nieto, “Why and How to Avoid the Flipped Quaternion Multiplication,” Aerospace, vol. 5, no. 3, article 72, 2018. Published under CC BY 4.0. Publisher article
[2] J. Solà, “Quaternion Kinematics for the Error State Kalman Filter,” arXiv:1711.02508, 2017. arXiv preprint
[3] D. H. Titterton and J. L. Weston, Strapdown Inertial Navigation Technology, 2nd ed., The Institution of Engineering and Technology, 2004/2005. Engineering reference. IET book page
[4] P. G. Savage, “Strapdown Inertial Navigation Integration Algorithm Design Part 1: Attitude Algorithms,” Journal of Guidance, Control, and Dynamics, vol. 21, no. 1, pp. 19–28, 1998. DOI record
Unless otherwise noted, this PhysicsLibrary entry is intended for release under the Creative Commons Attribution ShareAlike 4.0 International license.
| Physics Classification: | 45.40.-f (Dynamics and kinematics of rigid bodies) |
| 02.40.Yy (Geometric mechanics ) | |
| 06.30.Gv (Velocity, acceleration, and rotation) |
None.
No messages.


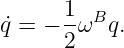
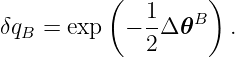
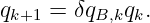
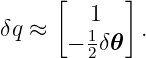
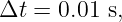
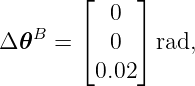
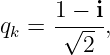
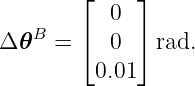
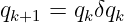

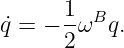


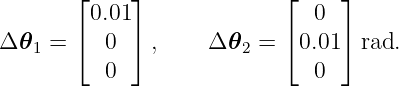
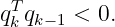
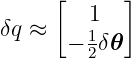
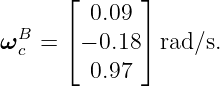
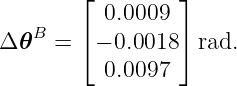
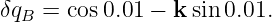
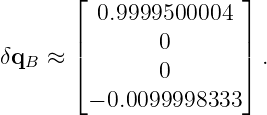
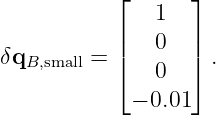
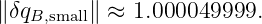

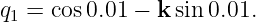
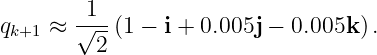
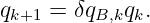
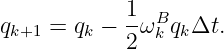
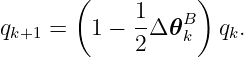
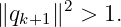

 rotation