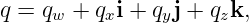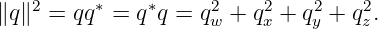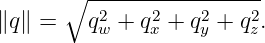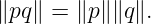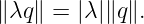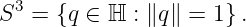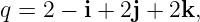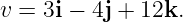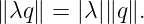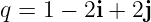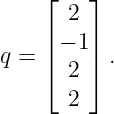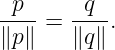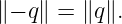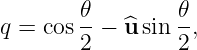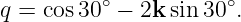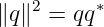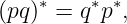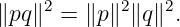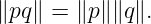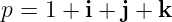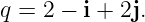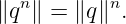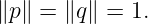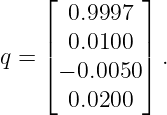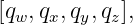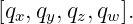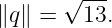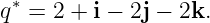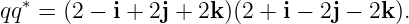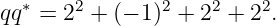|
|
|
|||||||
the conjugate is
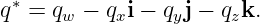 The squared norm is
Therefore
A unit quaternion satisfies
For nonzero q, its normalized quaternion is
The quaternion norm is multiplicative:
For a real scalar λ,
The set of unit quaternions is the unit three sphere
2 Exercises
3 Solutions
Solution 1: direct norm calculationFor
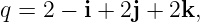 the squared norm is
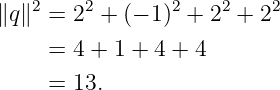 Therefore
and
Solution 2: norm from
|
 | (15) |
This agrees with
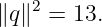
For

the norm is
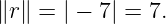 | (16) |
For
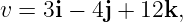
we have
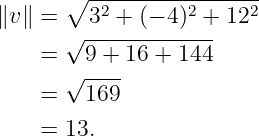
Therefore
 | (17) |
A pure quaternion has zero scalar component, so its quaternion norm is exactly the ordinary Euclidean magnitude of its three vector components.
The squared norm is
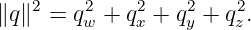
Every squared real number is nonnegative, so

Taking the principal square root gives
 | (18) |
If

then every component vanishes, so clearly

Conversely, if

then
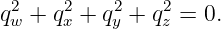
A sum of nonnegative real numbers can equal zero only when every term is zero. Thus
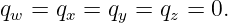
Hence
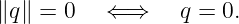 | (19) |
Let
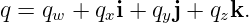
Then
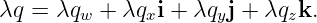
Therefore
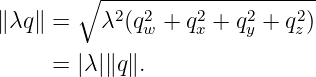
Thus
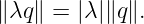 | (20) |
For
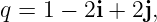
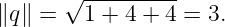
With λ = −3,
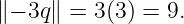
Directly,
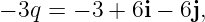
whose norm is
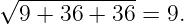
For
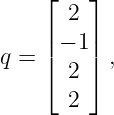
the norm is
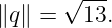
Therefore
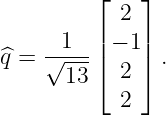 | (21) |
Its squared norm is
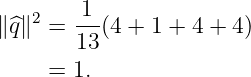
Thus
 | (22) |
Let

By the scaling law,
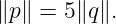
Therefore
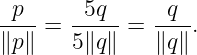
Hence
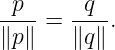 | (23) |
If

then
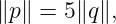
so
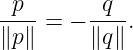
Thus a negative real scale produces the negative normalized quaternion.
For unit attitude quaternions, that negative quaternion represents the same physical orientation, although it is a different point on S3.
 and
 have the same norm
Use the scaling law with λ = −1:
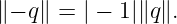
Therefore
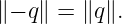 | (24) |
For unit attitude quaternions,
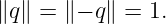
The two antipodal points q and −q on S3 represent the same physical orientation.
Thus equal norm is consistent with the usual double representation of the rotation group.
Let
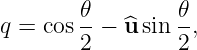
where

The squared norm is
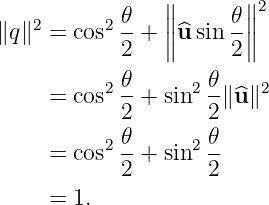
Therefore
 | (25) |
The negative vector sign required by the passive convention has no effect on the norm because the vector components are squared.
We have
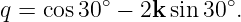
Since
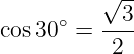
and
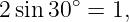
the quaternion is
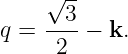
Thus
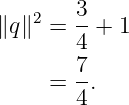
Therefore
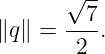 | (26) |
The axis coefficient has magnitude 2 rather than 1, so the pure direction being used is not a unit axis. The trigonometric appearance alone does not guarantee unit norm.
Start with
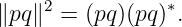
Use product reversal under conjugation:
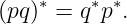
Then
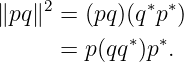
The quantity qq∗ is real:
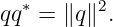
Real scalars commute with every quaternion, so
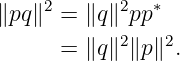
Therefore
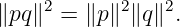 | (27) |
All norms are nonnegative, so taking square roots yields
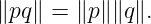 | (28) |
For
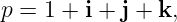
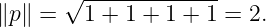
For
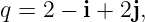
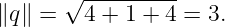
Now compute the Hamilton product.
Write
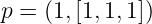
and
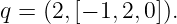
The scalar part is
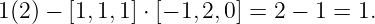
The cross product is
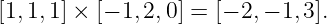
The vector part is
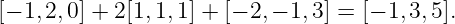
Thus
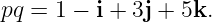 | (29) |
Its norm is
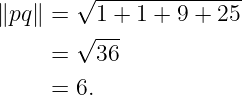
Meanwhile,
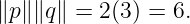
Therefore
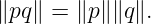 | (30) |
For n = 1,
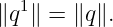
Assume
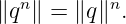
Then by multiplicativity,
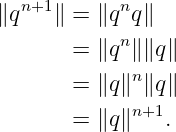
Therefore by induction,
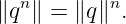 | (31) |
If q is unit,

so
 | (32) |
for every positive integer n.
If
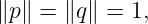
then multiplicativity gives
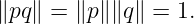
Therefore
 | (33) |
Thus the product of unit quaternions is again a unit quaternion.
This is essential for orientation composition: multiplying two exact unit attitude quaternions produces another exact unit attitude quaternion without leaving S3.
For
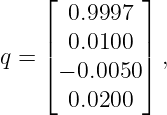
the squared norm is
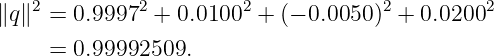
Thus
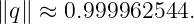 | (34) |
The normalization scale factor is approximately
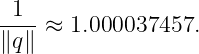
Therefore
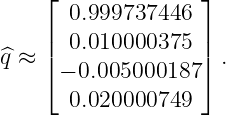 | (35) |
The norm correction magnitude is
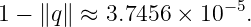
Thus the state was already close to unit, but normalization removes the small radial error.
Package A computes
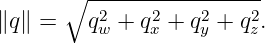
Package B stores the same four numbers in a different order but computes
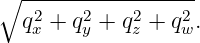
Real addition is commutative, so these are exactly equal.
Thus storage order does not alter quaternion norm.
Likewise, active and passive attitude conventions change how a unit quaternion is interpreted geometrically. They do not change the underlying four real components as an element of ℍ or the Euclidean formula
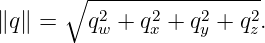
Therefore the definition of quaternion norm is independent of active versus passive attitude semantics.
The central norm identities reinforced by this companion are
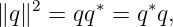 | (36) |
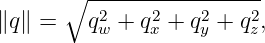 | (37) |
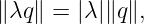 | (38) |
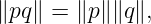 | (39) |
and
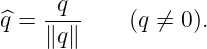 | (40) |
Unit quaternions form S3, and multiplicativity guarantees that products of unit quaternions remain on S3.
The exercises and solutions in this companion are newly written or expanded for PhysicsLibrary from the algebra developed in Quaternion Norm.
Hamilton is the foundational source for quaternion norm related quantities. Joly and Kelland–Tait provide classical systematic treatments. Sommer and coauthors provide a modern engineering discussion of unit quaternions and convention management.
[1] W. R. Hamilton, Elements of Quaternions, 2nd ed., edited by C. J. Joly, Longmans, Green, and Co., 1899. Public domain historical source. Internet Archive scan
[2] C. J. Joly, A Manual of Quaternions, Macmillan and Co., London, 1905. Public domain historical source. Internet Archive search
[3] P. Kelland and P. G. Tait, Introduction to Quaternions, with Numerous Examples, 2nd ed., Macmillan and Co., London, 1882. Public domain historical source. Internet Archive search
[4] H. Sommer, I. Gilitschenski, M. Bloesch, S. Weiss, R. Siegwart, and J. Nieto, “Why and How to Avoid the Flipped Quaternion Multiplication,” Aerospace, vol. 5, no. 3, article 72, 2018. Published under CC BY 4.0. Publisher article
Unless otherwise noted, this PhysicsLibrary entry is intended for release under the Creative Commons Attribution ShareAlike 4.0 International license.
| Keywords: | quaternion, norm, magnitude, tensor, unit quaternion, exercises, worked solutions |
| Physics Classification: | 02.10.Hh (Rings and algebras) |
| 02.10.Ud (Linear algebra) |
None.
No messages.