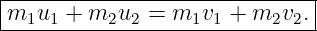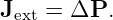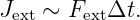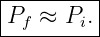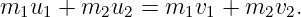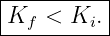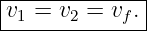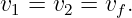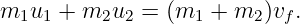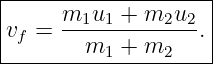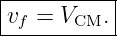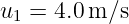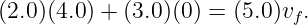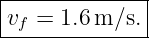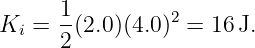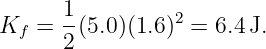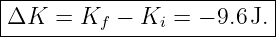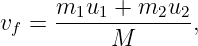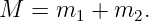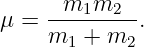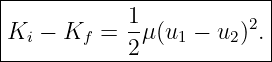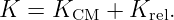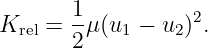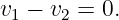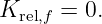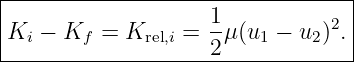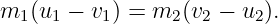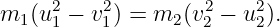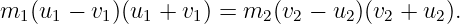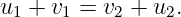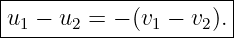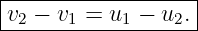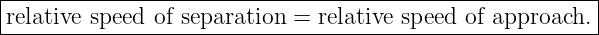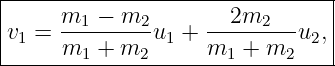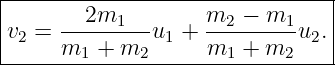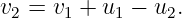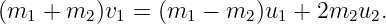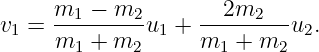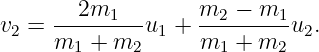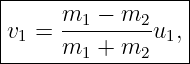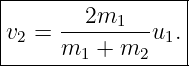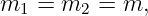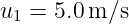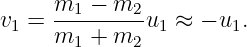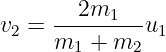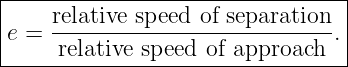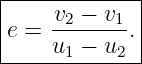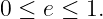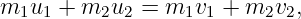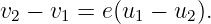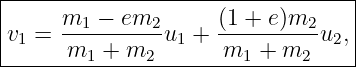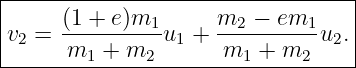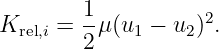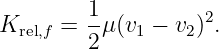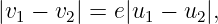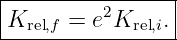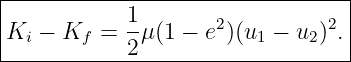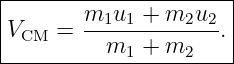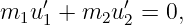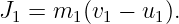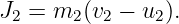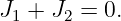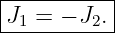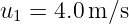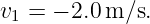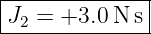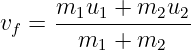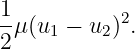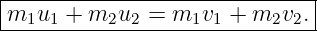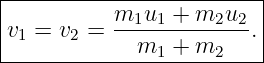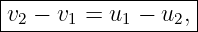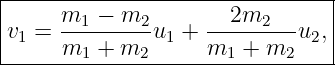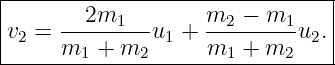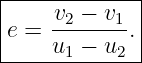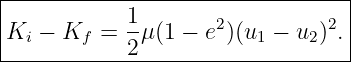Collisions in One Dimension
A collision is a short-duration interaction in which two bodies exert large forces on one another
and exchange momentum and energy.
During a sufficiently short collision, the external impulse on the two-body system is often negligible
compared with the internal collision impulse. Then total linear momentum is approximately
conserved:
Here
| u1, u2 | = velocities before the collision, | (2)
|
| v1, v2 | = velocities after the collision. | (3) |
Momentum conservation alone gives one equation for the two unknown final velocities. A second
physical relation is needed. That second relation depends on the type of collision.
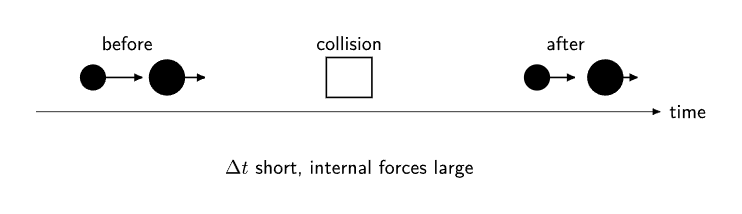
Figure 1. A one-dimensional collision is analyzed by comparing the system state immediately
before and immediately after the short interaction interval.
1 Why momentum is usually conserved during a collision
For the two-object system,
During a short collision interval Δt, slowly varying external forces produce impulses of
order
The internal collision forces can be much larger, but they occur in equal-and-opposite pairs and
cancel from the total momentum balance.
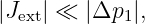
If
then
This approximation applies to many carts, pucks, balls, and impact problems.
2 Sign convention in one dimension
Choose a positive direction before writing any momentum equation.
For example, let rightward be positive.
Then:
- rightward velocity is positive,
- leftward velocity is negative,
- momentum automatically carries the correct sign.
The momentum equation is
No additional directional language is needed once the sign convention is established.
3 Classification by kinetic energy
The main collision classes are distinguished by what happens to total kinetic energy.
3.1 Elastic collision
An elastic collision conserves both total momentum and total kinetic energy:
| m1u1 + m2u2 | = m1v1 + m2v2, | (9)
|
 m1u12 +  m2u22 | =  m1v12 +  m2v22. | (10) |
3.2 Inelastic collision
An inelastic collision conserves total momentum, but translational kinetic energy decreases:
The missing translational kinetic energy is transferred into other forms such as
3.3 Perfectly inelastic collision
A perfectly inelastic collision is the limiting inelastic case in which the objects stick together after
impact:
Momentum is still conserved if external impulse is negligible.
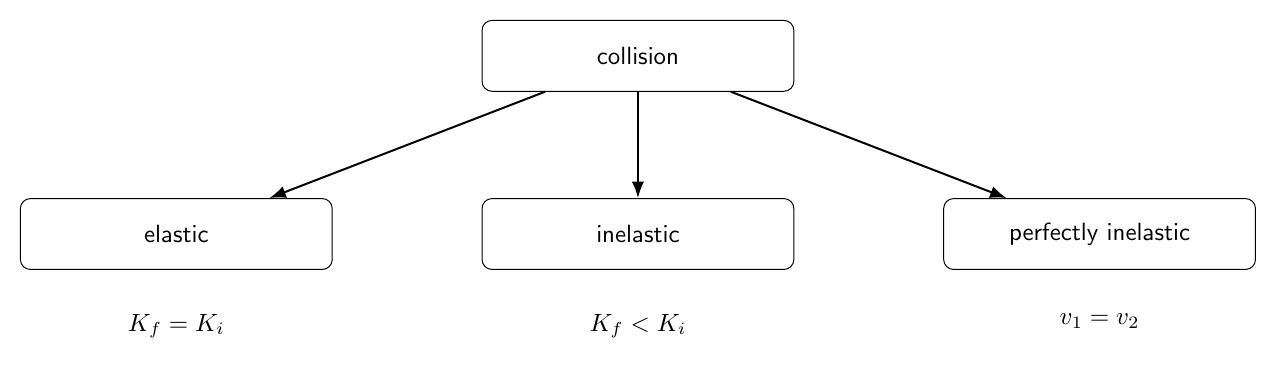
Figure 2. Collision type is determined by the post-impact constraint and by the change in
translational kinetic energy.
4 Perfectly inelastic collision
If two objects stick together,
Momentum conservation gives
Therefore
This is exactly the center of mass velocity before the collision:
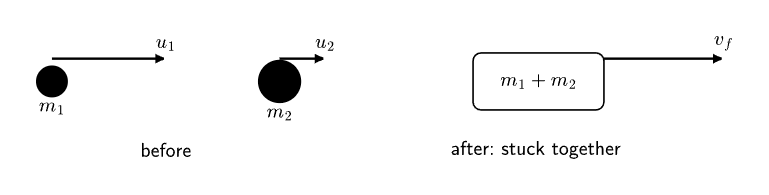
Figure 3. In a perfectly inelastic collision, the bodies stick together and move afterward with the
pre-collision center of mass velocity.
5 Example 1: perfectly inelastic collision
A 2.0 kg cart moving right at
collides with a 3.0 kg cart initially at rest.
The carts stick together.
Momentum conservation gives
Thus
Initial kinetic energy:
Final kinetic energy:
Therefore the translational kinetic-energy decrease is
Momentum is conserved, but kinetic energy is not.
6 Kinetic-energy loss in a perfectly inelastic collision
For a general perfectly inelastic collision,
where
The kinetic-energy loss can be written compactly using the reduced mass
The result is
Thus the dissipated translational kinetic energy depends on the relative approach speed.
7 Derivation of the perfectly inelastic energy loss
The total kinetic energy can be decomposed into
For two particles,
In the perfectly inelastic final state, the two objects have no relative motion:
Therefore
Because momentum conservation keeps KCM unchanged, the entire initial relative kinetic energy is
removed from translational motion:
8 Elastic collisions
For a one-dimensional elastic collision, both momentum and kinetic energy are conserved:
| m1u1 + m2u2 | = m1v1 + m2v2, | (32)
|
| m1u12 + m
2u22 | = m
1v12 + m
2v22. | (33) |
A direct simultaneous solution is possible, but there is a cleaner route.
9 Relative-speed relation for elastic collisions
Start with momentum conservation:
Kinetic-energy conservation can be written
Factor both sides:
Divide by the momentum relation, assuming a nontrivial collision:
Rearrange:
Equivalently,
Thus, in a one-dimensional elastic collision,
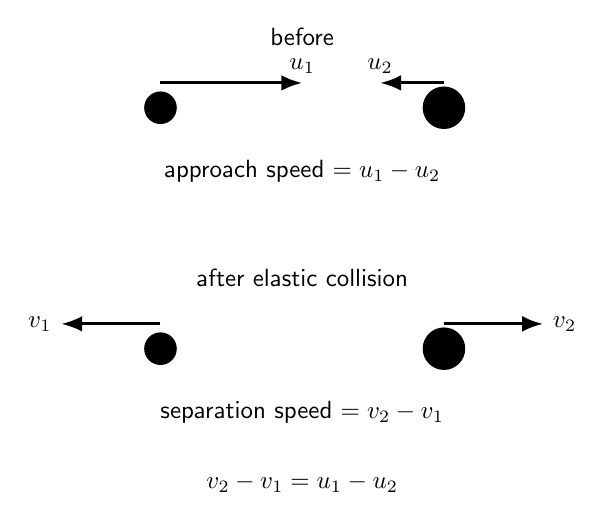
Figure 4. In a one-dimensional elastic collision, the relative speed reverses sign while preserving
its magnitude.
10 General one-dimensional elastic-collision formulas
The two equations
| m1u1 + m2u2 | = m1v1 + m2v2, | (41)
|
| v2 − v1 | = u1 − u2 | (42) |
can be solved for v1 and v2.
The results are
and
These formulas are useful, but they should be understood rather than memorized blindly.
11 Derivation of the elastic formulas
From the relative-speed relation,
Substitute into momentum conservation:
| m1u1 + m2u2 | = m1v1 + m2(v1 + u1 − u2). | (46) |
Collect v1:
Thus
Substituting that result back into the relative-speed relation gives
12 Target initially at rest
A common special case has
Then
and
These formulas reveal several useful limiting cases.
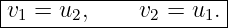
13 Equal masses
If
then
| v1 | = u2, | (54)
|
| v2 | = u1. | (55) |
Thus equal masses exchange velocities in a one-dimensional elastic collision:
If object 2 starts at rest,
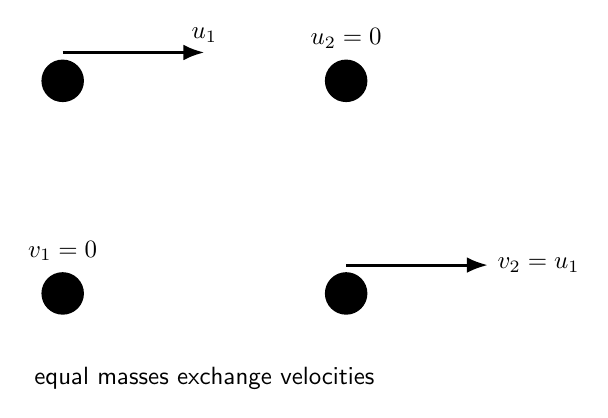
Figure 5. In a one-dimensional elastic collision of equal masses, the bodies exchange velocities.
14 Example 2: equal-mass elastic collision
A 1.0 kg cart moving right at
collides elastically with an identical cart at rest.
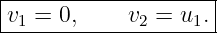
Because the masses are equal,
| v1 | = 0, | (59)
|
| v2 | = 5.0 m∕s. | (60) |
The first cart stops and the second cart carries away the original momentum and kinetic
energy.
This is the idealized behavior seen in devices such as a Newton’s cradle.
15 Light projectile striking a heavy target
Suppose
and the heavy target is initially at rest.
Then
The light projectile rebounds with nearly the same speed.
Meanwhile,
is small.
This resembles a ball elastically bouncing from a massive wall.
16 Heavy projectile striking a light target
If
and u2 = 0, then
while
A light target can leave with nearly twice the heavy projectile’s incoming speed.
This does not violate energy conservation because the light target has much less mass.
17 Coefficient of restitution
Real collisions are often neither perfectly elastic nor perfectly inelastic.
A useful empirical measure is the coefficient of restitution e, defined in one dimension
by
For the sign convention used here,
For ordinary passive impacts,
Important limits are
| e = 1 | elastic collision, | (70)
|
| e = 0 | perfectly inelastic collision. | (71) |
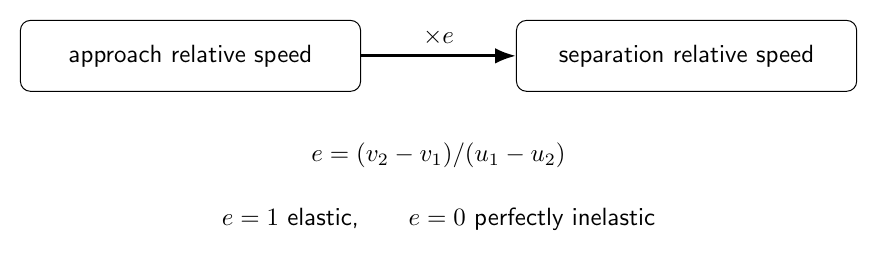
Figure 6. The coefficient of restitution compares relative separation speed after impact with
relative approach speed before impact.
18 General collision formulas using restitution
Combine momentum conservation,
with
Solving gives
and
Setting e = 1 reproduces the elastic formulas.
Setting e = 0 gives the common final velocity of a perfectly inelastic collision.
19 Example 3: partially inelastic collision
Let
| m1 | = 2.0 kg, | u1 | = 6.0 m∕s, | (76)
|
| m2 | = 3.0 kg, | u2 | = 0, | (77) |
with
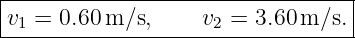
Then
| v1 | = 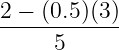 (6) | (79)
|
| = 0.60 m∕s, | (80) |
and
| v2 | =  (6) | (81)
|
| = 3.60 m∕s. | (82) |
Thus
Momentum is conserved, but kinetic energy decreases because e < 1.
20 Kinetic-energy loss and restitution
For a two-body one-dimensional collision with conserved momentum, the center of mass kinetic
energy does not change.
Only the relative kinetic energy can change.
Before collision,
After collision,
Using
we obtain
Therefore the translational kinetic-energy loss is
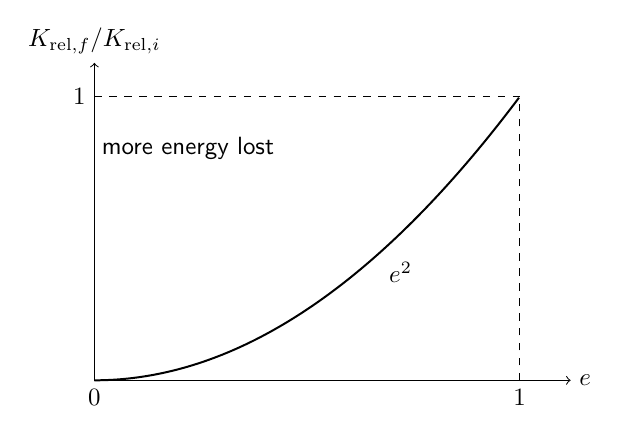
Figure 8. For fixed initial relative motion, the retained relative kinetic energy fraction is e2.
21 Center of mass frame
The center of mass velocity is
Define velocities in the center of mass frame:
| u1′ | = u1 − V CM, | (90)
|
| u2′ | = u2 − V CM. | (91) |
Because
the momenta in the center of mass frame are equal and opposite.
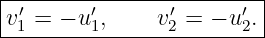
For an elastic one-dimensional collision,
Each object’s center of mass-frame velocity simply reverses direction.
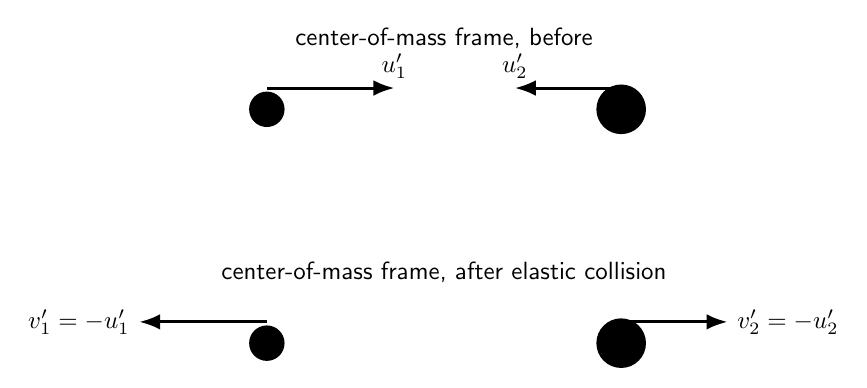
Figure 7. In the center of mass frame, a one-dimensional elastic collision reverses both velocities
while preserving their magnitudes.
22 Why the center of mass frame is useful
In the center of mass frame,
both before and after the collision.
For an elastic collision, total kinetic energy in this frame is also unchanged.
Because the two momenta are opposite, the collision geometry becomes especially simple.
The laboratory-frame solution can be recovered by adding
to each final center of mass-frame velocity.
This viewpoint becomes even more useful in two-dimensional collisions and scattering.
23 Impulse during a collision
For object 1,
For object 2,
If external impulse is negligible,
Therefore
The objects receive equal-and-opposite collision impulses.
This is the time-integrated form of Newton’s third law.
24 Example 4: collision impulse
A 0.50 kg cart changes velocity from
to
Its impulse is
| J1 | = m1(v1 − u1) | (102)
|
| = 0.50(−2.0 − 4.0) | (103)
|
| = −3.0 N s. | (104) |
The other object receives
if external impulse is negligible.
25 Collision formulas versus physical reasoning
Closed-form equations are useful, but several qualitative checks should always be made.
- Momentum must balance with signs.
- In an elastic collision, kinetic energy must also balance.
- In an ordinary inelastic collision, Kf < Ki.
- If the objects stick, their final velocities must be equal.
- For e = 1, relative speed reverses with equal magnitude.
- For e = 0, relative separation speed is zero.
- The center of mass velocity must remain constant if external impulse is negligible.
26 Common mistakes
- Conserving kinetic energy in every collision.
- Forgetting that momentum is signed in one dimension.
- Setting the final velocities equal unless the objects actually stick.
- Using the elastic-collision formulas for an inelastic impact.
- Forgetting that e = 0 means no relative separation speed, not necessarily zero final
speed.
- Mixing velocities from different inertial frames.
- Using speed instead of velocity in the momentum equation.
- Assuming equal-and-opposite impulses imply equal velocity changes for unequal
masses.
- Forgetting to check whether external impulse is negligible during the collision.
- Applying the restitution relation with the wrong order of relative velocities.
- Forgetting that kinetic-energy loss appears in other energy forms rather than
disappearing.
- Memorizing formulas without checking limiting cases.
27 Practice exercises
- A 2.0 kg cart moving at 5.0 m∕s sticks to a 3.0 kg cart at rest. Find the final velocity.
- For the preceding collision, find the initial and final translational kinetic energies and
the kinetic-energy loss.
- Derive
for a perfectly inelastic collision.
- Show that the kinetic-energy loss in a perfectly inelastic collision is
- Derive the one-dimensional elastic relative-speed relation from momentum and kinetic-energy
conservation.
- Derive the general elastic-collision formulas for v1 and v2.
- A 1.0 kg cart moving at 6.0 m∕s collides elastically with an identical stationary cart. Find
both final velocities.
- A 1.0 kg cart moving at 6.0 m∕s collides elastically with a 3.0 kg stationary cart. Find both
final velocities.
- A 3.0 kg cart moving at 6.0 m∕s collides elastically with a 1.0 kg stationary cart. Find both
final velocities.
- For a collision with e = 0.60, m1 = 2.0 kg, m2 = 4.0 kg, u1 = 9.0 m∕s, and u2 = 0, find the
final velocities.
- Show that Krel,f = e2K
rel,i.
- Explain physically why a light object can rebound from a very heavy stationary target with
nearly its original speed.
- Explain physically why equal masses exchange velocities in a one-dimensional elastic
collision.
- Transform an elastic collision into the center of mass frame and show that both velocities
reverse.
- A collision gives object 1 an impulse of −5 N s. What impulse does object 2 receive if
external impulse is negligible?
28 Summary
For a short one-dimensional collision with negligible external impulse,
For a perfectly inelastic collision,
For an elastic collision,
and the final velocities are
The coefficient of restitution is
The translational kinetic-energy loss is
The next article extends collision analysis to two dimensions.
References
References
[1] J. R. Taylor, Classical Mechanics, University Science Books, 2005.
[2] D. Kleppner and R. Kolenkow, An Introduction to Mechanics, 2nd ed., Cambridge
University Press, 2014.
[3] K. R. Symon, Mechanics, 3rd ed., Addison-Wesley, 1971.
[4] H. D. Young and R. A. Freedman, University Physics with Modern Physics, 15th ed.,
Pearson, 2020.
[5] OpenStax, University Physics, Volume 1, Rice University, 2016.