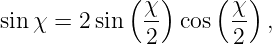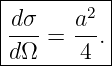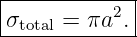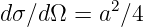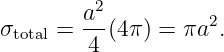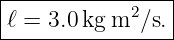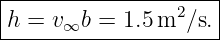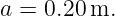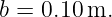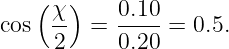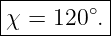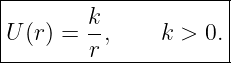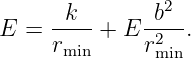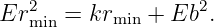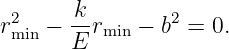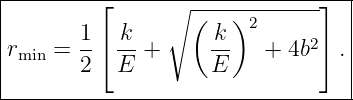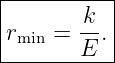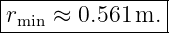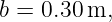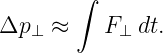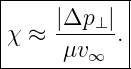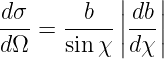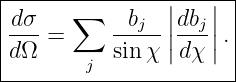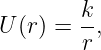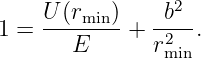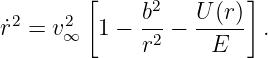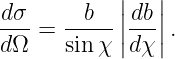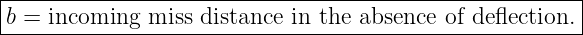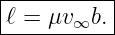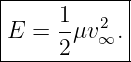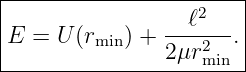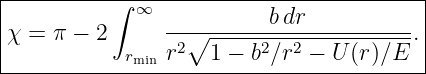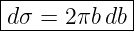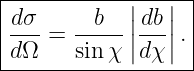Scattering Geometry and Impact Parameter
Scattering is the deflection of one object by an interaction with another.
In Classical Mechanics, a two-body scattering problem can be reduced to the relative motion of an
effective particle of reduced mass
moving in an interaction potential U(r).
Far from the interaction region, the relative trajectory approaches a straight line. The
perpendicular offset of that incoming line from the force center is the impact parameter
b.
If the incoming relative speed is v∞, then the relative angular momentum is
The outgoing asymptote is generally deflected through a scattering angle χ.
Thus a central scattering problem can be summarized by the mapping
The interaction potential determines that map.
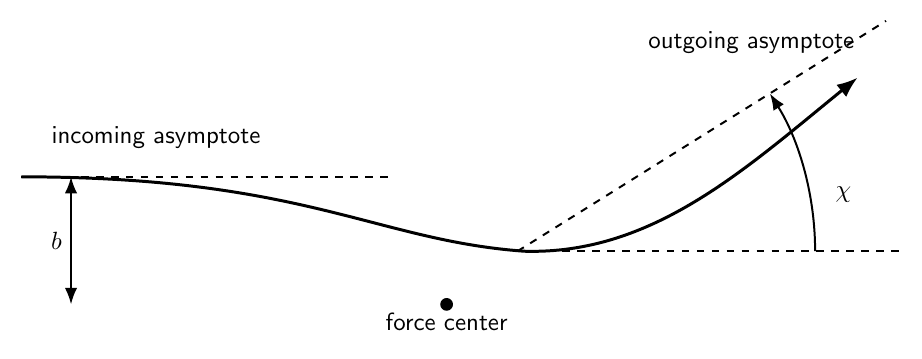
Figure 1. Classical scattering geometry in the relative coordinate. The incoming asymptote is
offset from the force center by the impact parameter b, and the outgoing asymptote is deflected
through angle χ.
1 Laboratory motion versus relative motion
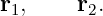
Suppose two particles have positions
Define the relative coordinate
For an isolated pair,
Therefore the scattering geometry can be studied as a one-particle central-force problem in
r.
The center-of-mass translation is dynamically separate.
This is why impact parameter, relative speed, relative angular momentum, and the relative
scattering orbit are natural variables.
2 Asymptotic states
Assume the interaction becomes negligible at large separation:
Before the encounter,
After the encounter,
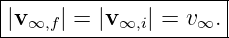
For elastic scattering in a conservative time-independent potential,
The speed is unchanged asymptotically, but the direction can change.
3 Impact parameter
The impact parameter b is the perpendicular distance between:
- the force center,
- the straight incoming asymptote that the relative particle would follow if no interaction
acted.
It is not, in general, the actual closest distance reached during the encounter.
That distinction is essential:
in general.
For repulsive interactions,
can be greater than, equal to, or related nontrivially to b depending on the potential.
4 Impact parameter and angular momentum
Far from the target, choose the incoming relative velocity along the +x direction:
The incoming straight-line asymptote can be written
At large negative x, the relative angular momentum is
Its magnitude is
Equivalently, the specific relative angular momentum is
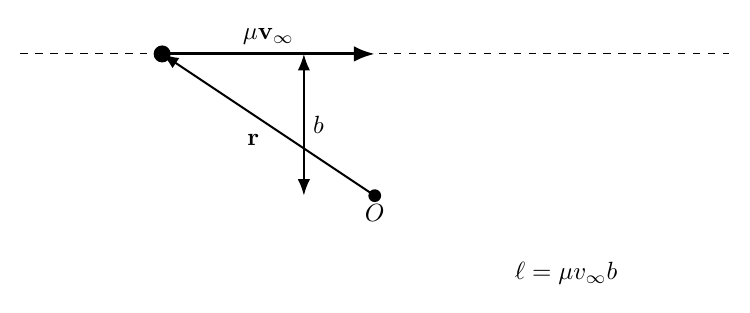
Figure 2. Far from the interaction, the perpendicular lever arm of the incoming relative
momentum is exactly the impact parameter, giving ℓ = μv∞b.
5 Head-on scattering
If
then
The motion is purely radial.
For a repulsive central force, a head-on projectile can reverse direction, giving
for complete backscattering.
For nonzero b, the angular-momentum barrier prevents purely radial motion.
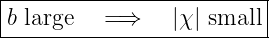
6 Large impact parameter
If b is large compared with the characteristic range of the interaction, the force acts only weakly
along the trajectory.
Then the deflection is typically small:
for ordinary short-range interactions.
This qualitative trend is one of the most useful checks on a scattering result.
7 Energy at infinity
If
then the relative energy is
The relative angular momentum is
Therefore the pair (E,ℓ) is equivalently specified by the asymptotic pair (v∞,b).
This connection lets scattering geometry feed directly into the effective-potential method.
8 Effective potential in a scattering problem
For a conservative central interaction,
where
Substitute
and
The angular-momentum term becomes
Thus
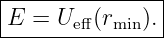
9 Distance of closest approach
At the distance of closest approach,
the radial velocity vanishes:
Therefore
Equivalently,
Using E =  μv∞2 and ℓ = μv
∞b,
This equation determines the turning point of the scattering orbit.
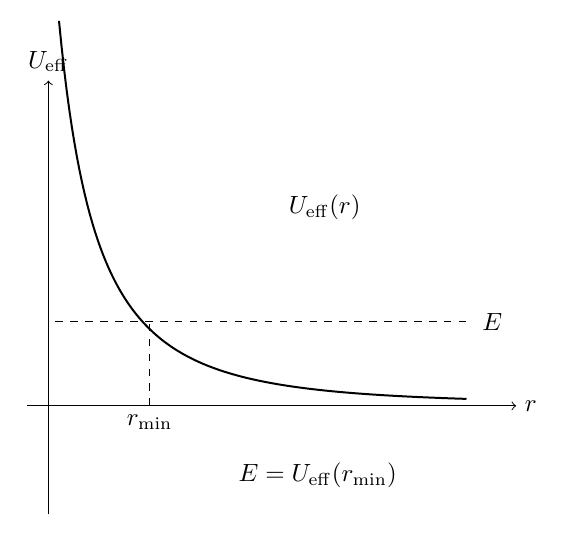
Figure 3. The closest approach occurs at the radial turning point where E = Ueff(rmin). The
angular-momentum barrier depends on the impact parameter through ℓ = μv∞b.
10 No interaction as a consistency check
If
then
Thus
That is exactly the geometry of a straight line passing a point at perpendicular distance
b.
For a nonzero interaction, the actual trajectory bends and rmin generally differs from
b.
11 Radial equation for scattering
From
solve for the radial speed:
Using the asymptotic variables,
Or, dividing by v∞2 and using E =  μv∞2,
12 Angular rate
Angular momentum conservation gives
Therefore
The orbit geometry can be obtained by combining the angular and radial rates.
13 From time evolution to orbit geometry
Use
For the incoming or outgoing branch,
Thus the angular change from closest approach to infinity is
For a symmetric central-force encounter, the total scattering angle is
Therefore
This is the general classical central-force deflection formula.
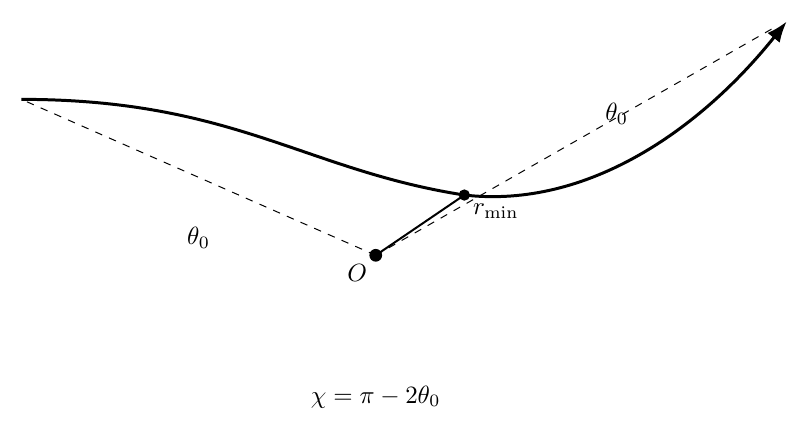
Figure 4. The total deflection is obtained by integrating the angular change from the radial
turning point to infinity and using the symmetry of the central-force orbit.
14 Check the deflection formula when U = 0
For no interaction,
Then
The integral evaluates to
Therefore
A nonexistent force produces no scattering, as required.
15 Signed versus unsigned scattering angles
Different texts use different sign conventions.
One convention treats
as the magnitude of the deflection.
Another assigns opposite signs to bending toward and away from a reference side.
In this article, χ is primarily used as a nonnegative deflection magnitude unless a signed angle is
stated explicitly.
The geometry must be defined before interpreting the sign.
16 Families of trajectories
A beam contains particles with many impact parameters.
Each value of b generally produces a different trajectory and scattering angle:
For an axially symmetric central interaction, the incident beam can be thought of as a family of
concentric rings of impact parameter.
This geometric picture leads directly to the concept of cross section.
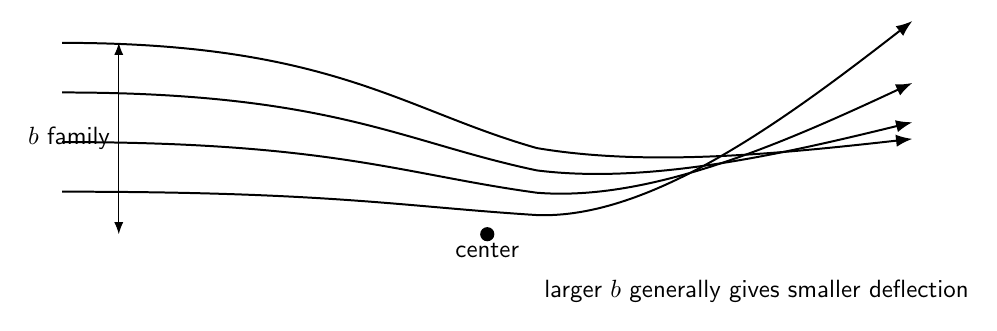
Figure 5. Different impact parameters correspond to different incoming trajectories and, in
general, different scattering angles.
17 Geometric cross section
Suppose an event occurs whenever
The set of incoming trajectories that produce that event occupies a circular area in
impact-parameter space:
This area is called a cross section.
Its dimensions are those of area:
The cross section is not necessarily the literal physical area of an object. It is an effective area
associated with a specified scattering outcome.
18 Annulus of impact parameters
Trajectories with impact parameters between b and b + db occupy an annulus with area
If those trajectories scatter into angles between χ and χ + dχ, then the same set of trajectories can
also be counted by their outgoing solid angle.
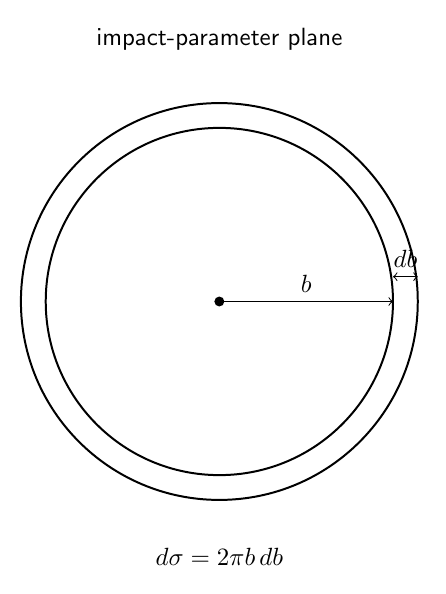
Figure 7. Incoming trajectories between b and b + db occupy an annulus of area dσ = 2πbdb in
impact-parameter space.
19 Solid-angle element
For azimuthally symmetric scattering,
Therefore
Hence
This is the classical differential cross-section formula for a one-to-one impact-parameter-to-angle
map.
It converts scattering geometry into an observable angular distribution.
20 Why the absolute value appears
For many repulsive interactions, larger impact parameters produce smaller deflections:
A cross section must be nonnegative.
Therefore
appears in the differential cross section.
21 Hard-sphere scattering
A useful purely geometric model is scattering from an impenetrable hard sphere of radius
a.
The projectile travels freely until it reaches the surface, then reflects specularly.
For a grazing trajectory,
and
For a head-on trajectory,
and
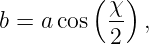
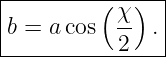
The geometry gives
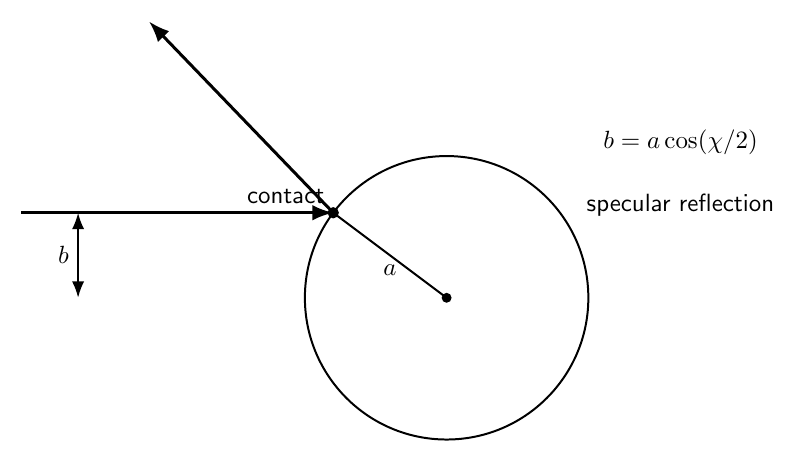
Figure 6. In hard-sphere scattering, specular reflection from the surface gives b = acos(χ∕2).
22 Hard-sphere differential cross section
Differentiate
Then
Using
we obtain
The hard-sphere differential cross section is independent of scattering angle.
23 Hard-sphere total cross section
Any trajectory with
hits the sphere.
Therefore the total geometric cross section is
This is also recovered by integrating
over the full solid angle:
24 Example 1: angular momentum from impact parameter
A relative particle has
| μ | = 2.0 kg, | (80)
|
| v∞ | = 5.0 m∕s, | (81)
|
| b | = 0.30 m. | (82) |
Then
| ℓ | = μv∞b | (83)
|
| = (2.0)(5.0)(0.30) | (84)
|
| = 3.0 kg m2∕s. | (85) |
Thus
The specific angular momentum is
25 Example 2: hard-sphere angle
A hard sphere has radius
A trajectory has
From
Therefore
and
26 Repulsive inverse-radius potential
Consider
At closest approach,
Multiply by rmin2:
Therefore
The physical positive root is
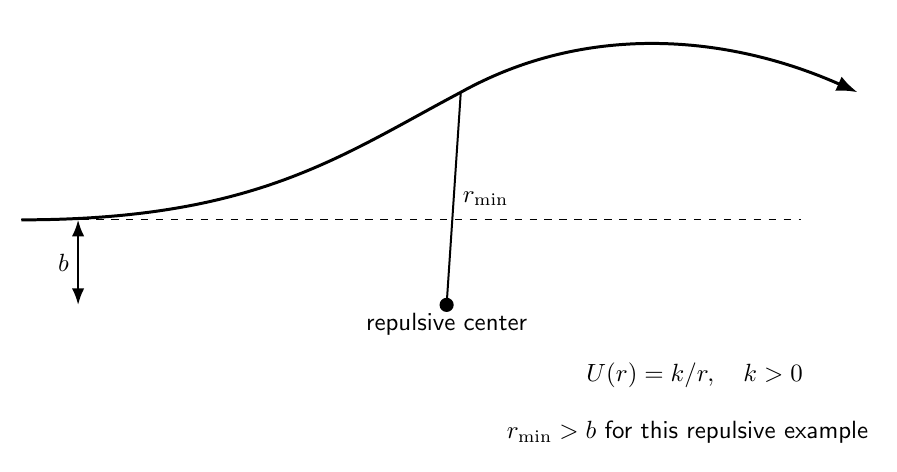
Figure 8. For a repulsive inverse-radius potential, the interaction pushes the turning point
outward relative to the straight-line value.
27 Head-on closest approach for the repulsive inverse-radius potential
For
the turning-point formula becomes
All asymptotic kinetic energy is converted into potential energy at the turning point:
This is the classical distance-of-closest-approach result for a head-on repulsive inverse-square
force.
28 Example 3: repulsive closest approach
Let
 | = 0.40 m, | (102)
|
| b | = 0.30 m. | (103) |
Then
| rmin | =  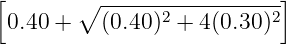 | (104)
|
| =  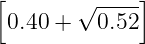 | (105)
|
| ≈ 0.561 m. | (106) |
Thus
The straight-line miss distance was only
but repulsion increases the actual closest separation.
29 Small-angle scattering intuition
When the deflection is small,
the incoming path is nearly straight.
A useful approximation is to estimate the transverse impulse along the unperturbed
trajectory:
For small deflection,
This impulse picture is approximate, but it provides physical intuition:
- stronger force gives larger deflection,
- lower incoming speed gives larger deflection,
- smaller impact parameter usually gives larger deflection.
30 When the map b χ is not one-to-one
The simple differential cross-section formula
assumes one impact parameter corresponds to the chosen scattering angle.
Some potentials can produce several impact parameters that lead to the same χ.
Then the contributions must be added:
This behavior appears in more advanced classical scattering phenomena such as rainbow
scattering.
31 Scattering angle in the center-of-mass frame
The reduced-coordinate calculation naturally produces the center-of-mass-frame scattering
angle.
For two finite masses, the laboratory scattering angle of a particular particle need not equal the
relative or center-of-mass scattering angle.
Transforming between frames requires the velocity relations
| v1 | = VCM +  r, | (114)
|
| v2 | = VCM − r. | (115) |
Thus:
32 Connection to collisions
A collision is a short-range interaction.
Scattering language emphasizes:
- the asymptotic incoming state,
- the asymptotic outgoing state,
- the impact parameter,
- the scattering angle,
- the distribution of outcomes over many trajectories.
The same conservation laws used in collision mechanics remain valid.
Scattering theory reorganizes those laws around trajectory geometry and measurable angular
distributions.
33 Connection to Rutherford scattering
For a repulsive inverse-radius potential,
the deflection integral can be evaluated analytically.
The result leads to a simple relation between b and χ, and then to the celebrated inverse-fourth-power
angular dependence of the Rutherford differential cross section.
That derivation is the subject of M04-11.
34 Common mistakes
- Confusing the impact parameter b with the actual closest approach rmin.
- Forgetting that b is defined from the incoming asymptote, not from the bent trajectory.
- Using either physical mass instead of the reduced mass in the relative scattering
problem.
- Using particle speed instead of relative speed v∞ in ℓ = μv∞b.
- Forgetting that U(∞) = 0 is an energy-reference choice used when writing E =
 μv∞2.
- Conserving speed asymptotically for an inelastic or nonconservative scattering problem.
- Forgetting the angular-momentum barrier in the closest-approach condition.
- Using χ = π − 2𝜃0 without defining the scattering-angle convention.
- Forgetting the absolute value in dσ∕dΩ.
- Treating cross section as necessarily equal to the literal physical area of the target.
- Assuming the simple differential cross-section formula is sufficient when several impact
parameters produce the same scattering angle.
- Confusing center-of-mass-frame scattering angle with the laboratory angle of one
particle.
- Assuming zero torque means zero work. A central force can change speed through
radial work while conserving angular momentum.
35 Practice exercises
- Define the impact parameter geometrically and explain why it is generally not equal
to the distance of closest approach.
- Derive ℓ = μv∞b from the incoming asymptotic trajectory.
- Show that the specific relative angular momentum is h = v∞b.
- Starting from the relative energy equation, derive
- Show that U = 0 implies rmin = b.
- Derive the radial equation
- Derive the central-force deflection integral for χ(b).
- Verify that the deflection integral gives χ = 0 for U = 0.
- Show that trajectories in an impact-parameter annulus have area dσ = 2πbdb.
- Derive
- For a hard sphere, derive b = a cos(χ∕2).
- Show that hard-sphere scattering has dσ∕dΩ = a2∕4.
- Integrate the hard-sphere differential cross section to recover σtotal = πa2.
- For U(r) = k∕r, derive the positive-root expression for rmin.
- Explain why the relative scattering angle and laboratory scattering angle are generally
different for finite masses.
36 Summary
The impact parameter is the perpendicular offset of the incoming asymptote:
For relative speed v∞,
With U(∞) = 0,
The closest approach satisfies
The central-force scattering angle is
Impact-parameter geometry gives
and, for an azimuthally symmetric one-to-one scattering map,
These formulas provide the foundation for the inverse-square scattering calculation in
M04-11.
References
References
[1] J. R. Taylor, Classical Mechanics, University Science Books, 2005.
[2] H. Goldstein, C. Poole, and J. Safko, Classical Mechanics, 3rd ed., Addison-Wesley,
2002.
[3] L. D. Landau and E. M. Lifshitz, Mechanics, 3rd ed., Pergamon Press, 1976.
[4] D. Kleppner and R. Kolenkow, An Introduction to Mechanics, 2nd ed., Cambridge
University Press, 2014.
[5] OpenStax, University Physics, Volume 1, Rice University, 2016.

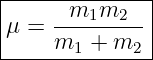
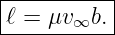
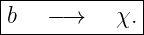
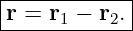
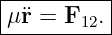
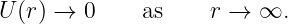

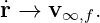


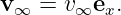

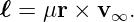
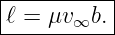
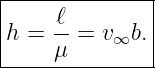


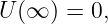
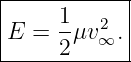
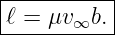
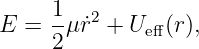
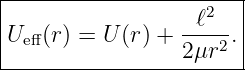

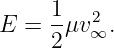


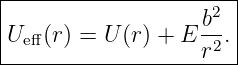


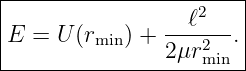
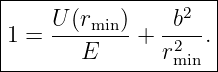


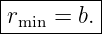
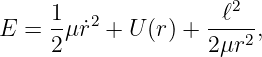
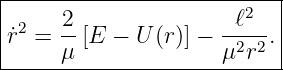
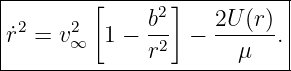
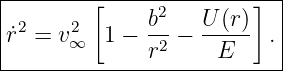

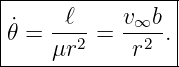

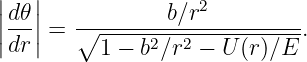
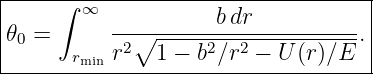
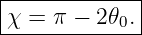
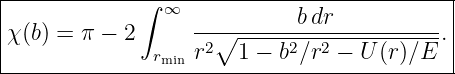

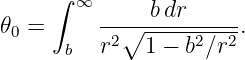

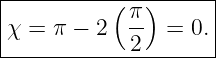

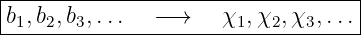
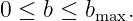
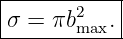
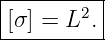
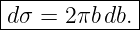
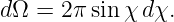
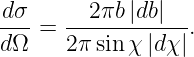
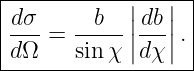


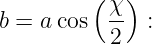
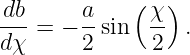

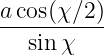
 sin