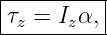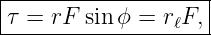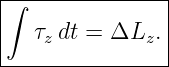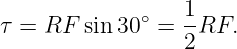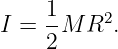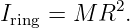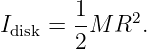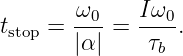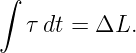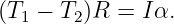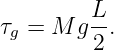|
|
|
|||||||
and
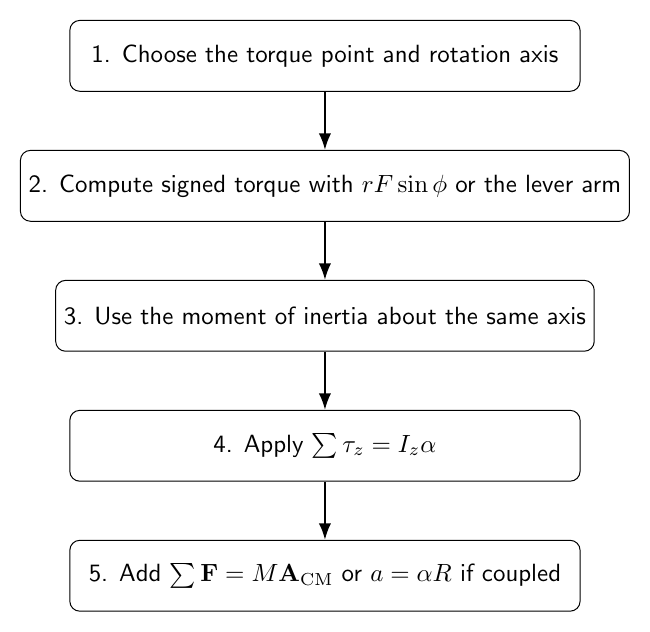
Figure 1. A compact strategy for fixed-axis rotational dynamics: choose the axis, calculate signed torques about that axis, use the matching moment of inertia, then couple to translational equations or kinematics when necessary.
1 High-value GRE facts
Part I: Original GRE-style problems
Problem 1: torque angleA force F is applied at distance R from an axis and makes angle 30∘ with the radius vector. The torque magnitude is
Problem 2: force through axisA force has a line of action passing directly through the rotation axis. Its torque about that axis is
Problem 3: disk angular accelerationA uniform disk of mass M and radius R experiences tangential rim force F. Its angular acceleration is
Problem 4: ring versus diskA ring and disk have equal M and R and experience the same rim torque. The ratio of angular accelerations is
equal to
Problem 5: zero net torqueA rigid body has zero net axial torque and nonzero angular velocity. Its angular velocity is
Problem 6: braking torqueA rotor with moment of inertia I and angular speed ω0 is stopped by constant braking torque magnitude τb. The stopping time is
Problem 7: rotational powerA motor supplies torque τ to a shaft rotating at angular speed ω. The instantaneous mechanical power is
Problem 8: angular impulseThe area under a torque-versus-time graph equals
Problem 9: massive pulley tensionsA massive pulley accelerates clockwise due to two tangential tensions T1 and T2. Which statement is generally correct?
Problem 10: gravity torque on rodA uniform rod of length L and mass M is horizontal and pivoted at one end. The magnitude of gravitational torque about the pivot is
Problem 11: rod angular accelerationFor the rod in Problem 10, Ipivot = ML2∕3. Its initial angular acceleration magnitude is
Problem 12: coupleTwo equal and opposite parallel forces of magnitude F are separated by perpendicular distance d. Their net effect is
Part II: Complete worked solutions
Solution 1
Answer: (B).
Solution 2The lever arm is zero because the force line of action passes through the axis:
Answer: (A).
Solution 3For a disk,
The rim torque is
Therefore
Answer: (B).
Solution 4For the ring,
For the disk,
At equal torque,
Thus
Answer: (D).
Solution 5Zero net torque gives
Therefore the angular velocity remains constant. Answer: (D).
Solution 6The angular deceleration magnitude is
Thus
Answer: (C).
Solution 7For fixed-axis rotation,
Answer: (C).
Solution 8Angular impulse is
Answer: (C).
Solution 9A nonzero angular acceleration of a pulley with nonzero inertia requires
Thus the tensions generally differ. Answer: (B).
Solution 10The rod center of mass lies at L∕2 from the pivot, and gravity is perpendicular to the horizontal rod:
Answer: (C).
Solution 11
Answer: (C).
Solution 12The equal and opposite forces cancel translationally, but their separated lines of action produce a couple:
Answer: (C).
2 GRE checklist
References
References
"GRE Physics Companion: Torque and Fixed-Axis Rotational Dynamics" is owned by bloftin.
This object's parent. Cross-references: rotational work, Vector Identity, relation, scalar, moment arms, center of mass, fixed-axis rotation, rotational kinetic energy, angular momentum, angular displacement, graph, mechanical power, speed, angular velocity, rigid body, mass, radius vector, angular impulse, rotational power, angular acceleration, net torque, tensions, Pulley, force, lever arm, magnitude, kinematics, moment of inertia, torques, fixed-axis rotational dynamics This is version 1 of GRE Physics Companion: Torque and Fixed-Axis Rotational Dynamics, born on 2026-10-17. Object id is 1475, canonical name is GREPhysicsCompanionTorqueAndFixedAxisRotationalDynamics. Accessed 9 times total. Classification:
|
|
|
|
Pending Errata and AddendaNone.
|
DiscussionNo messages.
|
Interact |