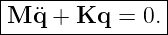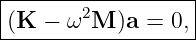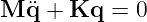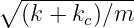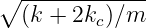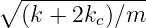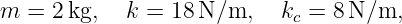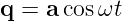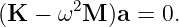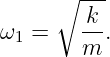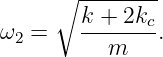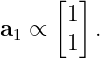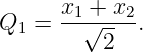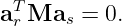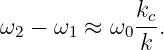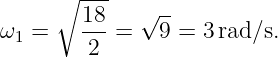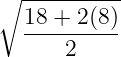Physics Library
 An open source physics library
Encyclopedia | Forums | Docs | Random  

[parent] GRE Physics Companion: Coupled Oscillators and Normal Modes

(Example)

GRE Physics Companion: Coupled Oscillators and Normal Modes

For a conservative linear system,

|---------------|
M--¨q-+-Kq--=-0.-|
(1)

Normal modes satisfy

|-------2----------|
-(K-−--ω-M-)a-=--0,|
(2)

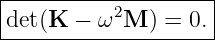
and

|--------------------|
|det(K −  ω2M  ) = 0.|
---------------------
(3)

PIC

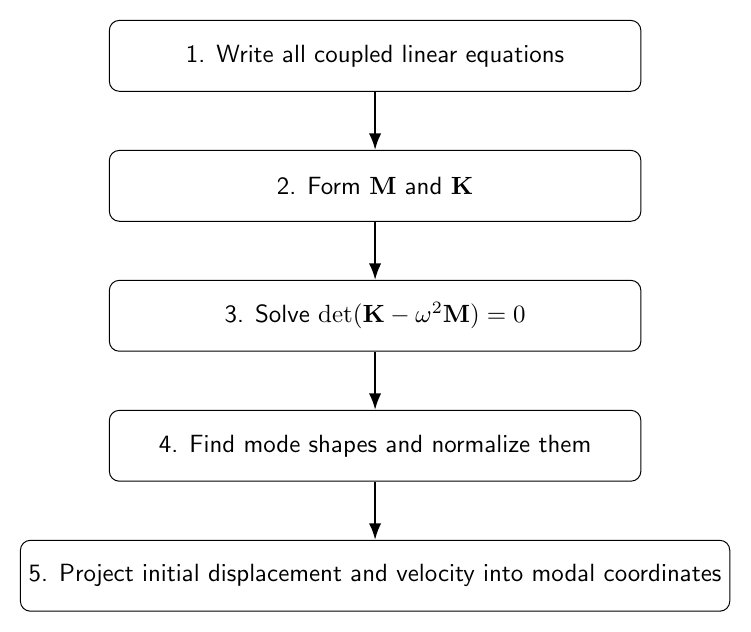
Figure 1. A compact normal-mode strategy: write the coupled equations, form M and K, solve the generalized eigenvalue problem, identify mode shapes, and project initial conditions into modal coordinates.

1 High-value GRE facts

  1. A normal mode has one common angular frequency and fixed amplitude ratios.
  2. Normal frequencies follow from det(K − ω2M) = 0.
  3. Mode shapes are generalized eigenvectors.
  4. For two equal masses with outer springs k and coupling spring kc, ω12 = k∕m and ω22 = (k + 2k c)∕m.
  5. The in-phase mode does not stretch the coupling spring.
  6. The out-of-phase mode has the larger frequency for positive coupling.
  7. General motion is a superposition of normal modes.
  8. Distinct modes are orthogonal with respect to the mass matrix.
  9. zero modes represent motions with no restoring force.
  10. Weak coupling produces closely spaced frequencies and slow beating.

Part I: Original GRE-style problems

Problem 1: normal-mode condition

A normal mode of

M ¨q + Kq  =  0
(4)

satisfies

  1. Ka = 0 only
  2. (K − ω2M)a = 0
  3. Ma = 0
  4. q = 0 only
  5. K + ωM = 0

Problem 2: equal-mass symmetric mode

For two equal masses with wall springs k and coupling spring kc, the in-phase normal frequency is

  1. ∘ -----
  k∕m
  2. ∘k--∕m--
   c
  3. ∘ -----------
  (k + kc)∕m
  4. ∘ ------------
  (k + 2kc)∕m
  5. zero

Problem 3: antisymmetric mode

For the same system, the out-of-phase normal frequency is

  1. ∘ -----
  k∕m
  2. ∘ ------
  kc∕m
  3. ∘ ------------
  (k + 2kc)∕m
  4. ∘ ------
  2k∕m
  5. zero

Problem 4: symmetric mode shape

A mode shape for the lower-frequency equal-mass mode is proportional to

  1. [  ]
 1
 0
  2. [  ]
 0
 1
  3. [  ]
 1
 1
  4. [   ]
  1
 − 1
  5. [  ]
 2
 1

Problem 5: normal coordinates

For equal masses, a convenient symmetric normal coordinate is

  1. (x1 + x2)∕√2--
  2. (x1 − x2)∕√2--
  3. x1x2
  4. x1∕x2
  5. x12 + x 22

Problem 6: mode superposition

An arbitrary small motion of a conservative linear coupled system can generally be written as

  1. one normal mode only
  2. a sum of normal modes
  3. a constant displacement only
  4. one exponential only
  5. a rigid translation only

Problem 7: zero mode

Two equal masses are connected only by one spring and otherwise free. The in-phase translation mode has

  1. ω = 0
  2. ω = ∘  -----
   k∕m
  3. ω = ∘  ------
   2k∕m
  4. infinite frequency
  5. imaginary frequency

Problem 8: mass orthogonality

For distinct normal modes of a symmetric conservative system,

  1. arT Ma s = 0
  2. arT Ka s = 1
  3. ar = as
  4. M = 0
  5. ωr = ωs

Problem 9: weak coupling

If

kc ≪ k,
(5)

the mode splitting is approximately

  1. ω0k∕kc
  2. ω0kc∕k
  3. kc∕m
  4. ∘k--∕m--
   c
  5. zero exactly

Problem 10: numerical frequencies

For

m  = 2 kg,  k =  18N ∕m,   kc = 8 N∕m,
(6)

the lower normal frequency is

  1. 2 rad/s
  2. 3 rad/s
  3. 4 rad/s
  4. √ ---
  17 rad/s
  5. 9 rad/s

Problem 11: same numerical system

For the system in Problem 10, the upper normal frequency is

  1. 3 rad/s
  2. 4 rad/s
  3. √ ---
  17 rad/s
  4. √ ---
  26 rad/s
  5. 17 rad/s

Problem 12: continuum bridge

A long chain of coupled oscillators is important because

  1. all normal frequencies become zero
  2. it approaches the normal-mode description of a continuous wave system
  3. coupling disappears
  4. the mass matrix becomes irrelevant
  5. every mode has the same frequency

Part II: Complete worked solutions

Solution 1

Using

q = a cosωt
(7)

gives

(K −  ω2M )a =  0.
(8)

Answer: (B).

Solution 2

In the in-phase mode,

x1 = x2,
(9)

so the coupling spring is not stretched. Only the wall springs provide restoring force:

      ∘ ---
        k
ω1 =    m-.
(10)

Answer: (A).

Solution 3

In the out-of-phase mode, the coupling spring contributes additional restoring stiffness:

     ∘ --------
        k + 2kc
ω2 =    --m----.
(11)

Answer: (C).

Solution 4

The lower-frequency mode is the in-phase motion:

     [ ]
a  ∝  1  .
 1    1
(12)

Answer: (C).

Solution 5

The symmetric normal coordinate is

      x1 + x2
Q1 =  --√----.
          2
(13)

Answer: (A).

Solution 6

The normal modes form a basis for the linear small-oscillation motion. Therefore a general motion is a superposition of modes. Answer: (B).

Solution 7

Equal translation does not stretch the only spring, so there is no restoring force:

ω  = 0.
(14)

Answer: (A).

Solution 8

For distinct eigenfrequencies of a symmetric conservative system,

aTMas  =  0.
 r
(15)

Answer: (A).

Solution 9

For weak coupling,

             kc
ω2 − ω1 ≈ ω0 k .
(16)

Answer: (B).

Solution 10

      ∘ ---
        18-   √--
ω1 =     2 =   9 =  3rad∕s.
(17)

Answer: (B).

Solution 11

ω2 = ∘ ----------
   18 +-2(8)
       2 (18)
= √ ---
  17 rad∕s. (19)

Answer: (C).

Solution 12

As the number of coupled oscillators becomes large, the discrete mode family approaches the normal modes of a continuous medium and hence wave mechanics. Answer: (B).

2 GRE checklist

  1. Write the coupled equations before guessing mode shapes.
  2. Form M and K and solve the generalized eigenvalue problem.
  3. Find eigenvectors as well as eigenvalues.
  4. Use symmetry to recognize in-phase and out-of-phase modes quickly.
  5. Transform both displacement and velocity initial data into normal coordinates.
  6. Remember that distinct modes are mass orthogonal.
  7. Check for zero modes when the system has an unconstrained symmetry motion.
  8. For weak coupling, use the normal-frequency splitting to estimate beat time.

References

References

[1]   PhysicsLibrary, M06-03, Driven Harmonic Motion and Resonance.

[2]   PhysicsLibrary, M06-02, Damped Harmonic Motion.

[3]   PhysicsLibrary, M06-01, Simple Harmonic Motion.

[4]   A. P. French, Vibrations and Waves, W. W. Norton, 1971.

[5]   J. R. Taylor, Classical Mechanics, University Science Books, 2005.


"GRE Physics Companion: Coupled Oscillators and Normal Modes" is owned by bloftin.
(view preamble)
View style:
Other names:  M06-04G
Keywords:  GRE physics, coupled oscillators, normal modes, normal coordinates, mode shapes, eigenvalues, coupled springs, beat frequency, mass matrix, stiffness matrix

This object's parent.

Cross-references: velocity, mechanics, coupled oscillators, displacement, normal coordinate, force, zero modes, matrix, masses, frequencies, Normal, amplitude, angular frequency, mode shapes, generalized eigenvalue problem, normal modes, system

This is version 1 of GRE Physics Companion: Coupled Oscillators and Normal Modes, born on 2026-10-18.
Object id is 1495, canonical name is GREPhysicsCompanionCoupledOscillatorsAndNormalModes.
Accessed 3 times total.

Classification:
Physics Classification: 45.50.-j (Dynamics and kinematics of a particle and a system of particles)
 45.05.+x (General theory of classical mechanics of discrete systems)

Pending Errata and Addenda

None.

Discussion

No messages.

Interact