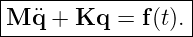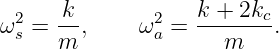|
|
|
|||||||
The examples are chosen to make coupling visible. Some systems are coupled through coordinates, some through derivatives, and some become uncoupled only after a change to modal coordinates. The two-mass oscillator provides the central mechanical example because a single scalar action generates the full matrix equation of motion and its normal modes [3, 4, 5].
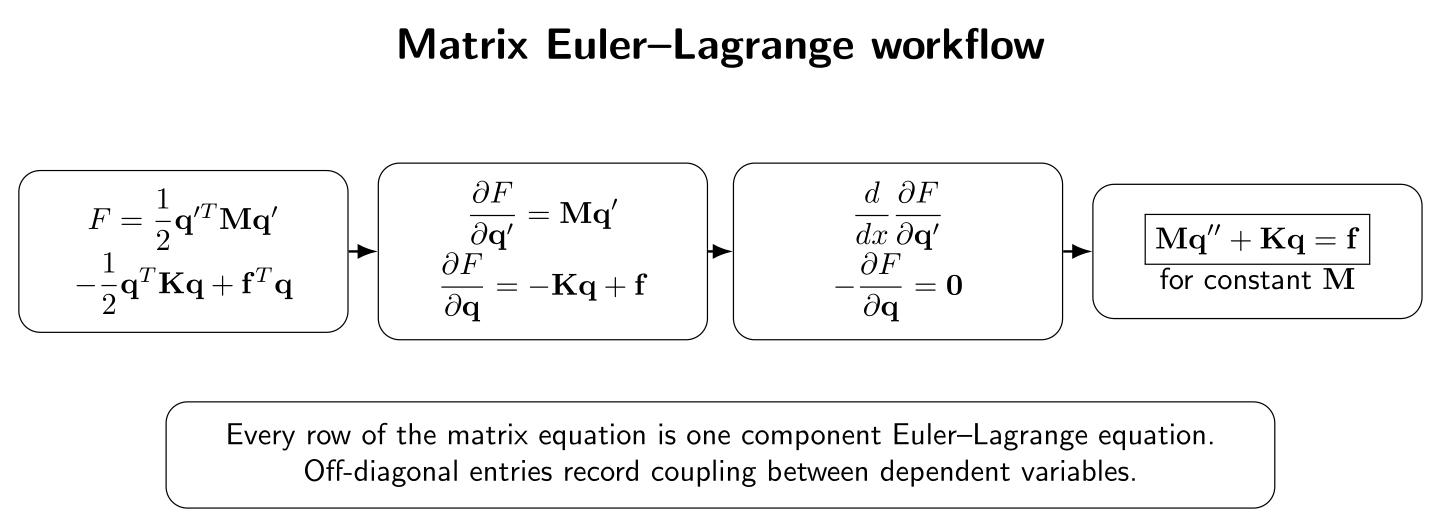
Figure. The matrix Euler–Lagrange workflow for a quadratic vector functional. The matrix notation is compact, but every step represents the same componentwise variational derivatives derived in CV07.
1 How to use this setAttempt the exercises before reading the worked solutions. For each problem, use the following checklist.
Part I: Exercises
Exercise 1: the constant-matrix Euler–Lagrange equationLet
where
Exercise 2: a variable matrix coefficientNow let
with
Exercise 3: derivative coupling and an off-diagonal mass matrixConsider two dependent variables with
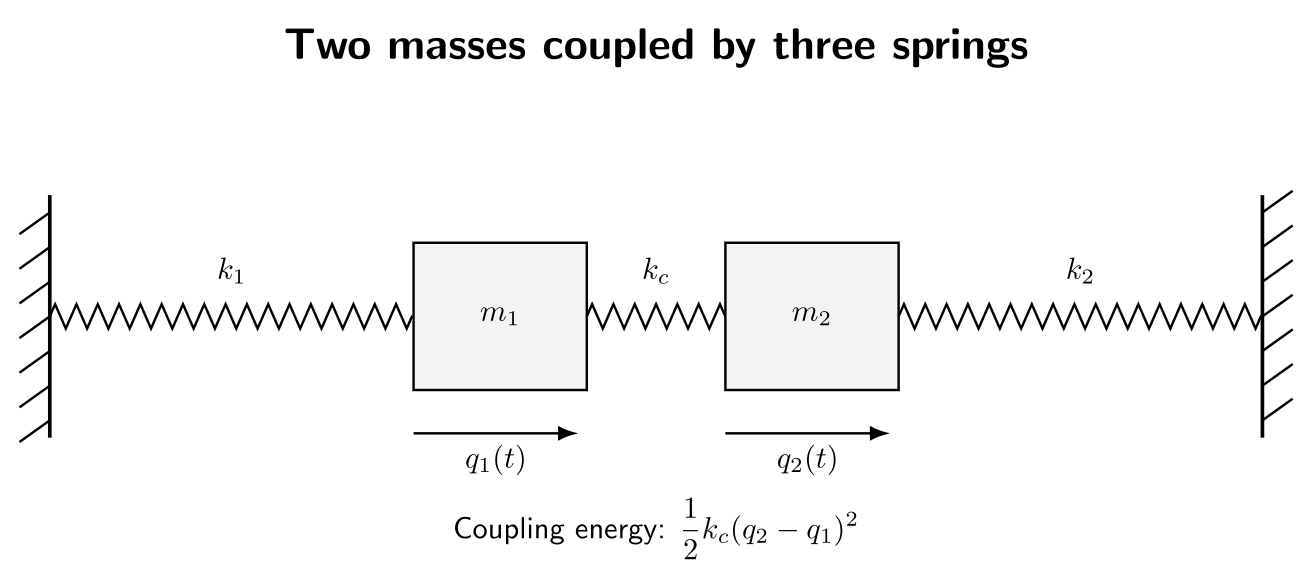
Exercise 4: two masses and three springsTwo masses
Figure. The two-degree-of-freedom oscillator used in Exercises 4–7. The middle spring
stores energy according to the relative displacement
Exercise 5: normal modes of the symmetric two-mass systemSpecialize Exercise 4 to
Seek a normal-mode solution
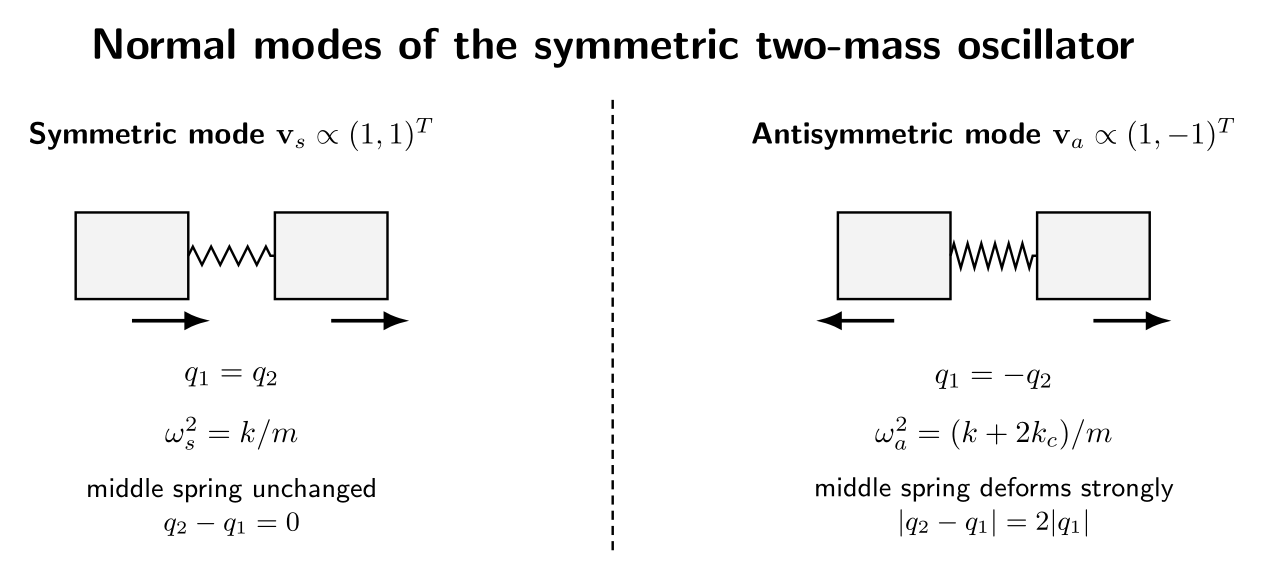
Figure. The two normal-mode shapes of the symmetric oscillator. In the in-phase mode the coupling spring does not change length; in the out-of-phase mode it is stretched or compressed strongly and raises the modal frequency.
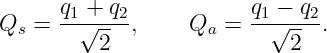
Exercise 6: diagonalization with modal coordinatesFor the same symmetric oscillator, define
Exercise 7: harmonic forcing in matrix formAdd an applied force to the symmetric two-mass system:
Assume an undamped steady harmonic response
Exercise 8: a coupled boundary-value problemConsider the static variational problem
with fixed endpoint data
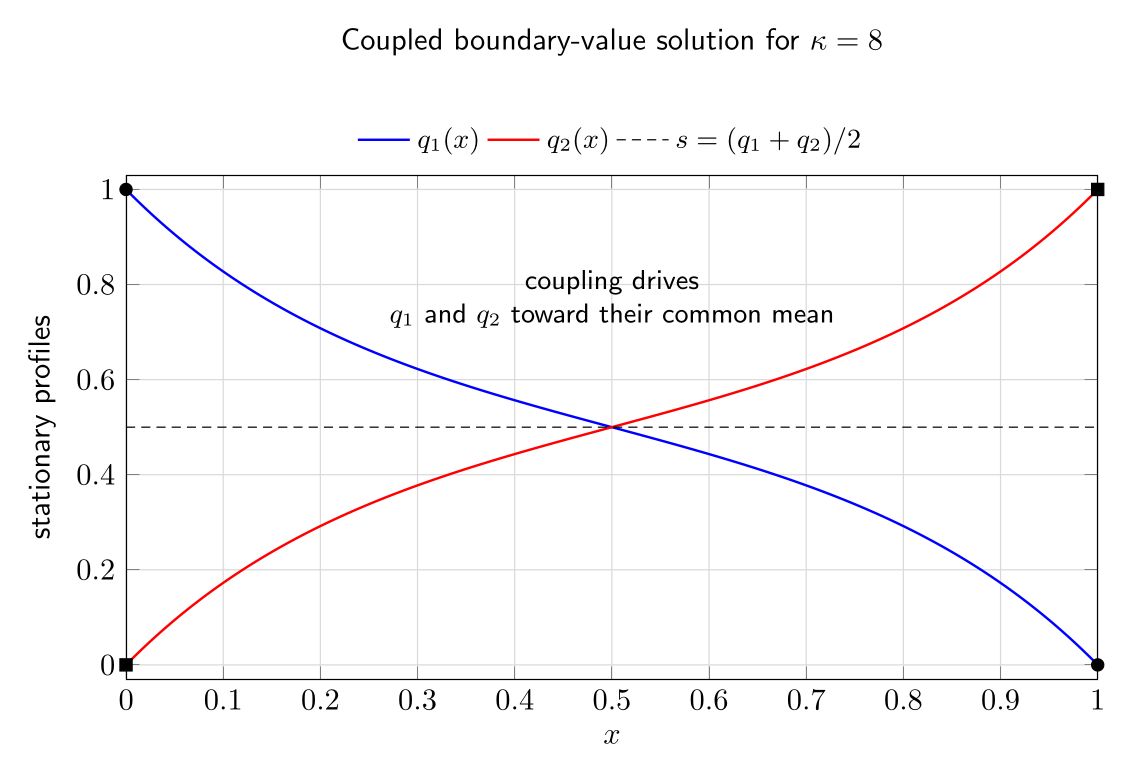
Figure. A representative stationary solution of the coupled boundary-value problem. The average coordinate remains linear, while the difference coordinate is suppressed in the interior by the coupling penalty.
Part II: Complete worked solutions
Solution 1: the constant-matrix Euler–Lagrange equationWrite
Because
One way to verify this without memorizing a matrix-calculus rule is to write
Differentiating with respect to
Symmetry Similarly,
The vector Euler–Lagrange equation is
Since
For
This is the matrix version of the scalar linear Euler–Lagrange equation. The matrix form is compact, but no new variational principle was introduced; it is just the collection of all component equations.
Solution 2: a variable matrix coefficientNow
and
Therefore the Euler–Lagrange equation is naturally written as
This divergence form is often the safest form because it preserves the exact result of integration by parts. Expanding with the matrix product rule,
Thus
The term
when
Solution 3: derivative coupling and an off-diagonal mass matrixThe integrand is
For
Therefore
Likewise,
Define
Then
The eigenvalues of
A real symmetric matrix is positive definite exactly when all its eigenvalues are positive. Therefore
which combine to give
Thus derivative coupling appears as an off-diagonal entry in the matrix multiplying the highest derivative. In mechanics that matrix is often the mass matrix.
Solution 4: two masses and three springsThe kinetic energy is
The three spring energies are
Hence
For
and
Thus
For
Define
and
Then
The off-diagonal terms
Solution 5: normal modes of the symmetric two-mass systemFor
and
Insert
Since
the equation of motion becomes
A nonzero mode shape exists only if
Therefore
The determinant gives
Factoring,
Thus
For
so one mode vector is
For
so
The physical interpretation is especially useful. In the symmetric mode,
so the coupling spring is neither stretched nor compressed. It contributes no restoring force and therefore does not change the frequency. In the antisymmetric mode,
so the coupling spring deforms strongly, increasing the restoring stiffness and raising the frequency [5, 6].
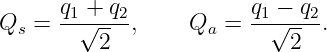
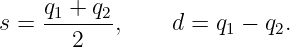
Solution 6: diagonalization with modal coordinatesThe coordinate transformation is
Solving for the original coordinates,
The same relations hold for the velocities. Therefore
Hence
For the wall springs,
The coupling displacement is
so
Therefore
The Lagrangian becomes
The two coordinates are now uncoupled. Their equations are
and
which immediately reproduce
This is the simplest example of modal diagonalization: a coupled coordinate system becomes two independent oscillators after changing basis to eigenvector coordinates.
Solution 7: harmonic forcing in matrix formThe forced equation is
Assume
Then
so cancellation of the common cosine factor yields
For the symmetric system, define
Then
The determinant is
Away from
The undamped response becomes singular when
which factors exactly as in Exercise 5:
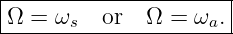
Thus resonance occurs at
This is not a new variational condition. The variational principle generated the matrix differential equation; ordinary linear-system analysis then reveals its resonant response.
Solution 8: a coupled boundary-value problemThe integrand is
For
Therefore
For
so
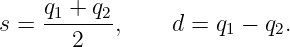
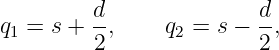
Introduce
Adding the two differential equations gives
hence
Subtracting them gives
so
The boundary data imply
so
For the difference,
Let
The antisymmetry of the boundary data about
Using
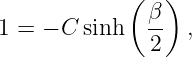
so
Finally,
which gives
and
Increasing
2 What these problems should teachThe most useful habit is to separate three layers of the calculation.
Confusing these layers can make the matrix notation look more mysterious than it is. The matrices do not replace the variational derivation; they organize its result.
3 Common mistakes
SummaryFor a quadratic vector functional with constant symmetric matrices,
the vector Euler–Lagrange equations reduce to
In mechanics,
For the symmetric two-mass oscillator, the coupled coordinate equations have normal modes
with
The modal coordinates diagonalize the same scalar action that originally produced the coupled equations. CV07E2 next applies vector variational methods to trajectory and geometry problems, while CV08 extends the theory to functionals involving higher derivatives.
References
[1] I. M. Gelfand and S. V. Fomin, Calculus of Variations, Dover Publications, 2000. [2] Bruce van Brunt, The Calculus of Variations, Springer, 2004. [3] Cornelius Lanczos, The Variational Principles of Mechanics, 4th ed., Dover Publications, 1986. [4] Herbert Goldstein, Charles Poole, and John Safko, Classical Mechanics, 3rd ed., Addison Wesley, 2002. [5] Leonard Meirovitch, Elements of Vibration Analysis, 2nd ed., McGraw-Hill, 1986. [6] S. S. Rao, Mechanical Vibrations, 5th ed., Prentice Hall, 2011. "Calculus of Variations: Coupled Systems and Matrix Euler--Lagrange Equations" is owned by bloftin.
This object's parent. Cross-references: CV08, CV07E2, boundary, differential equation, coordinate system, velocities, determinant, mechanics, matrix product, variational principle, static, algebraic, resonance, amplitude, force, relations, frequencies, energy, Lagrange equations, potential energy, kinetic energy, equilibrium, displacements, masses, divergence, symmetric matrices, dimensions, Lagrangian, vector, normal modes, matrix, oscillator, system, scalar, CV07 There are 2 references to this object. This is version 1 of Calculus of Variations: Coupled Systems and Matrix Euler--Lagrange Equations, born on 2026-10-11. Object id is 1470, canonical name is CalculusOfVariationsCoupledSystemsAndMatrixEulerLagrangeEquations. Accessed 9 times total. Classification:
|
|
|
|
Pending Errata and AddendaNone.
|
DiscussionNo messages.
|
Interact |

 . This
companion article develops the computational side of that extension. The main objective is to
become comfortable moving among three equivalent descriptions of the same stationary
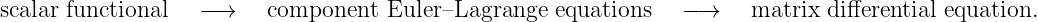
 .
 or
 .
 and
 component by component if there is any doubt about
the matrix derivative.
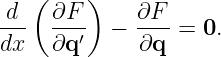
 or an equivalent sinusoidal
ansatz.
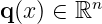 and consider
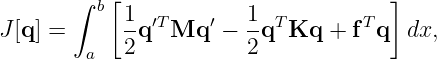
 and
 are constant
 is a constant vector.
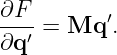
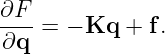
 .
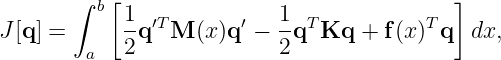
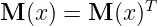 .
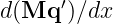 by
 is generally incorrect.
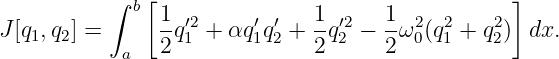
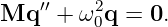
 .
 makes the derivative quadratic form positive
definite.
 and
 move horizontally. Mass 1 is attached to the left wall by spring
 ,
mass 2 is attached to the right wall by spring
 , and the masses are connected by spring
 .
Let
 and
 be
 .
 .
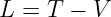 .
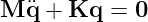
 and
 .
 , which is the source of
coordinate coupling.

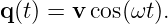
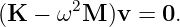
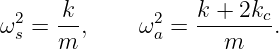
 in terms of
 .
 and
 directly from the separated Lagrangian.
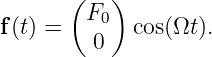
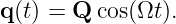
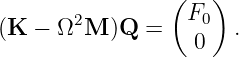
 and
 away from
 at which the undamped
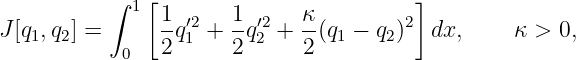

 and
 .
 and
 .
 does to the two profiles.
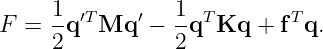
 is symmetric, differentiating the quadratic form with respect to
 gives
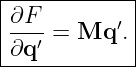
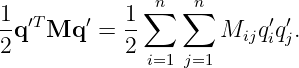
 produces
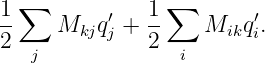
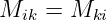 makes the two sums equal, giving the
 -th component of
 .
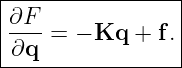
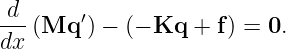
 is constant,
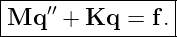
 ,
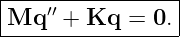
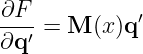
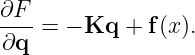
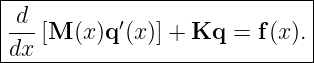
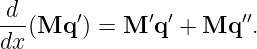
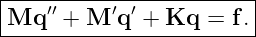
 disappears only when
 is constant. This is the matrix analogue of the scalar
warning
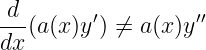
 .
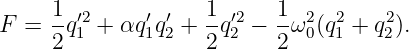
 ,

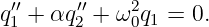
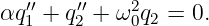
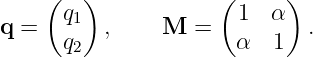
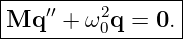
 are



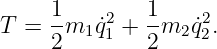
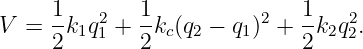
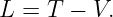
 ,
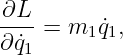


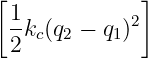
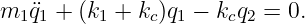
 ,
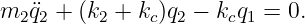
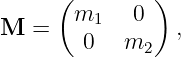
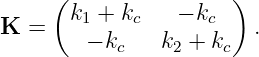
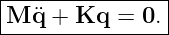
 encode the fact that the middle spring depends on relative
displacement. The matrix is symmetric because the spring stores a scalar potential energy and the
mixed second derivatives agree.
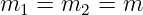 and
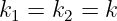 ,

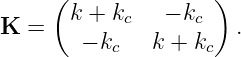
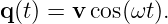
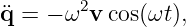
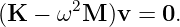
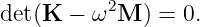
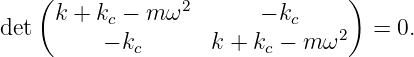
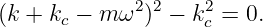
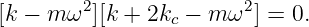
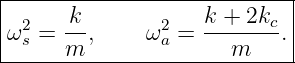
 , the matrix equation gives

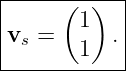
 ,

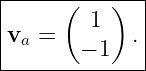
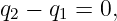
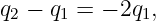
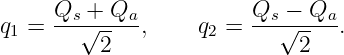
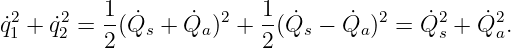
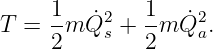
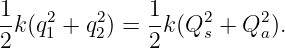
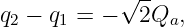
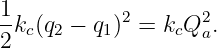
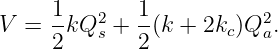
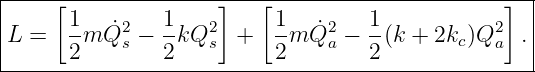
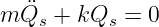
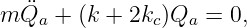
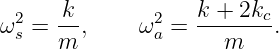
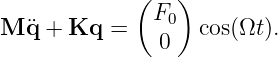
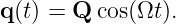
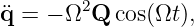
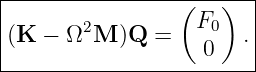
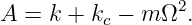
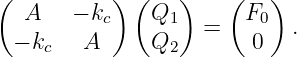
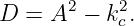
 , the inverse matrix gives
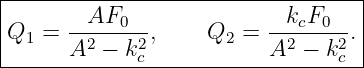
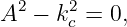
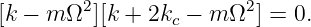
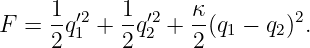
 ,
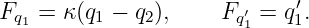
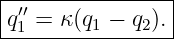
 ,
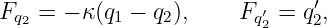
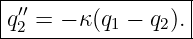
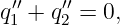

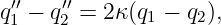
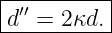
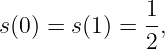
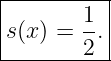


 suggests the centered form
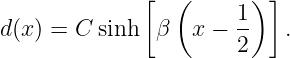
 ,
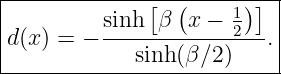
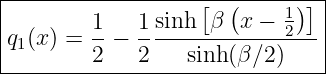
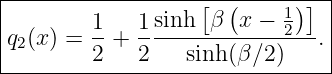
 increases
 . The functional penalizes differences between
 and
 more strongly, so the two stationary profiles are pulled closer to their common
mean
 through most of the interior while still satisfying their opposing endpoint
values.
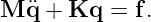
 , the derivative of
 involves the symmetric part
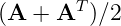 .
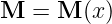 , then
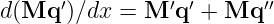 .
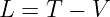 , while the final equation is normally
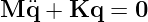 .
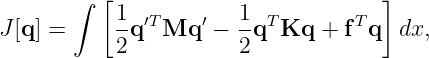
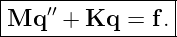
 becomes time and the same structure gives