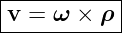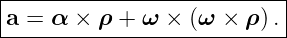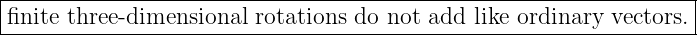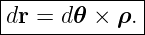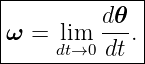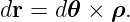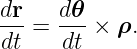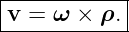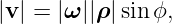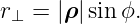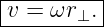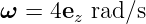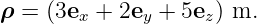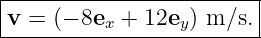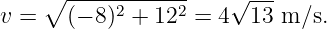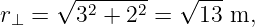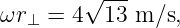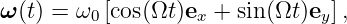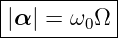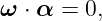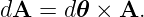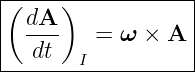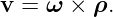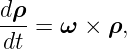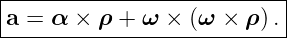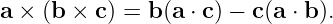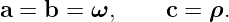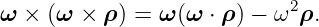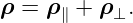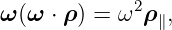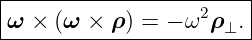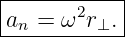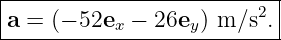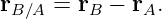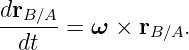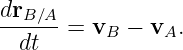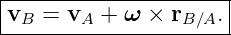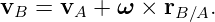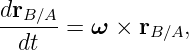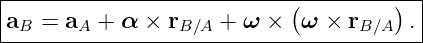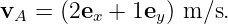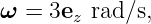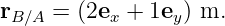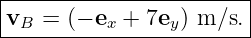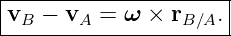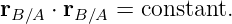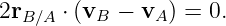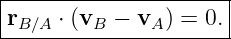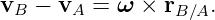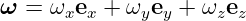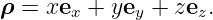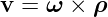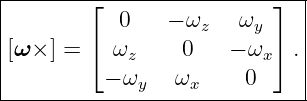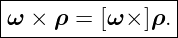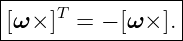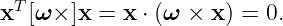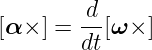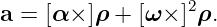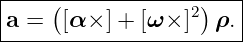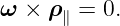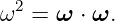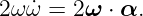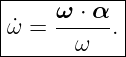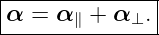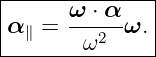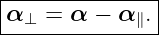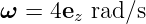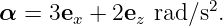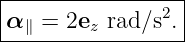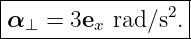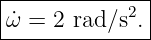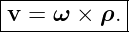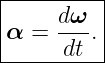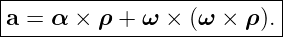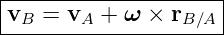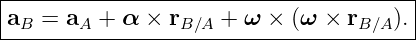Angular Velocity and Angular Acceleration as Vectors
M05-01 introduced angular position, angular velocity, and angular acceleration for fixed-axis
rotation. In that setting, a signed scalar ω was sufficient because the axis was fixed and only one
rotational degree of freedom was active.
Three-dimensional rigid body motion requires a more powerful description.
The instantaneous angular velocity is a vector
whose:
- direction gives the instantaneous axis of rotation,
- sense follows the right-hand rule,
- magnitude gives the instantaneous angular speed.
The angular acceleration vector is
when the derivative is taken in an inertial frame.
For a material point at position ρ from a point on a fixed rotation axis,
and
These vector equations are the foundation for rigid body kinematics in three dimensions.
1 Why angular velocity needs a direction
A scalar angular speed tells how rapidly orientation changes, but not the axis about which it
changes.
Consider two disks spinning at the same rate:
- one rotates counterclockwise when viewed from above,
- the other rotates clockwise.
Their angular speed magnitudes are the same, but their rotational senses are opposite.
The angular velocity vector resolves this ambiguity.
For rotation about a fixed axis with unit vector e, write
The direction of e is chosen by the right-hand rule.
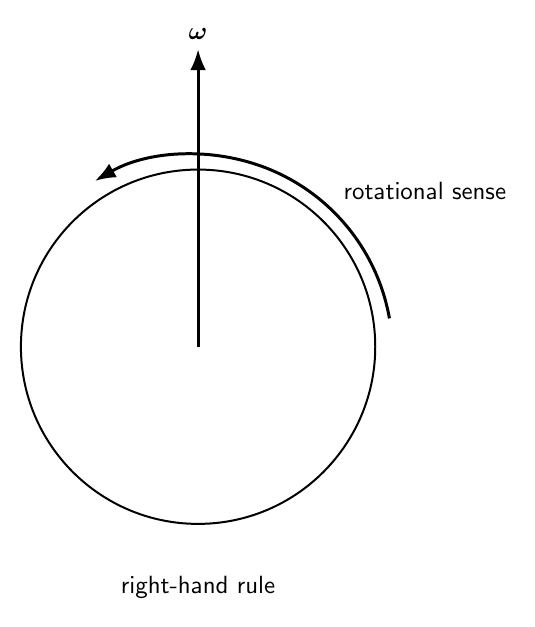
Figure 1. Curling the fingers of the right hand with the rotational sense makes the thumb point in
the direction of the angular velocity vector.
2 Angular velocity is an axial vector
Position, velocity, force, and acceleration are examples of polar vectors. Their directions correspond
directly to directed line segments in space.
Angular velocity is an axial vector, also called a pseudovector.
It is associated with an oriented axis rather than a displacement from one point to
another.
The distinction matters mainly under spatial reflection. Under ordinary proper rotations of the
coordinate system, axial vectors transform with the same component rules as familiar
vectors.
For standard mechanics calculations involving rotations of coordinate axes, ω can be manipulated
with the usual vector and cross-product operations.
3 Finite rotations are not ordinary vectors
It is tempting to treat a finite rotation angle as an ordinary vector.
That fails in three dimensions because finite rotations generally do not commute.
For example:
- rotate an object 90∘ about the x axis, then 90∘ about the y axis,
- reverse the order of those rotations.
The final orientations are different.
Therefore
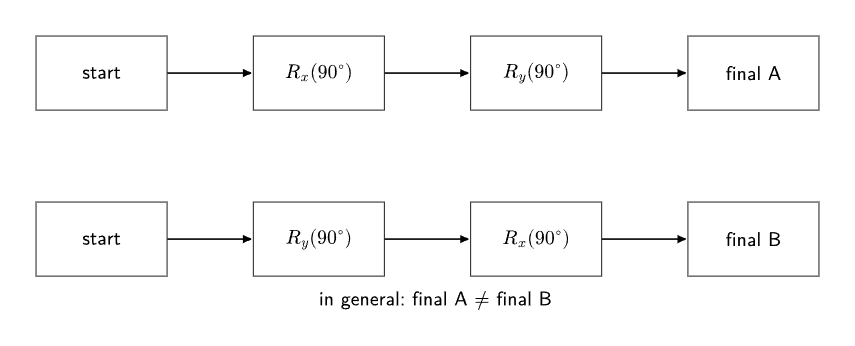
Figure 2. Two finite rotations about different axes generally produce different final orientations
when their order is reversed.
4 Infinitesimal rotations behave vectorially
The situation changes for an infinitesimal rotation.
Let
be a very small rotation vector whose magnitude is the small angle d𝜃 and whose direction follows
the right-hand rule.
For a point with position vector ρ from the instantaneous rotation axis, the first-order
displacement produced by the rotation is
Terms of order
and higher are neglected.
This is why the instantaneous angular velocity can be treated as a vector even though a finite
rotation cannot generally be represented by ordinary vector addition.
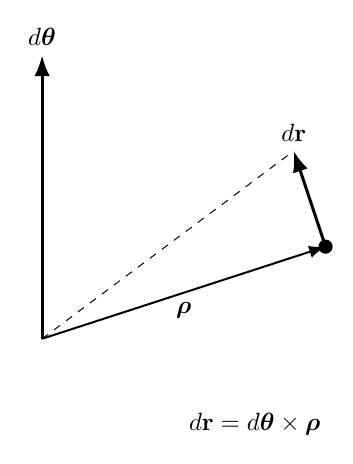
Figure 3. To first order, an infinitesimal rotation d𝜃 moves a point by dr = d𝜃 ×ρ.
5 Definition of angular velocity vector
Divide the infinitesimal rotation vector by the elapsed time:
Its magnitude is
and has SI units
For fixed-axis rotation,
where e is a constant axis direction.
In general three-dimensional motion, both the magnitude and direction of ω can vary with
time.
6 Deriving the point-velocity equation
Start with the infinitesimal displacement
Divide by dt:
Therefore
The cross product automatically enforces the correct geometry:
- v is perpendicular to ω,
- v is perpendicular to ρ’s component away from the axis,
- the direction is tangent to the circular path.
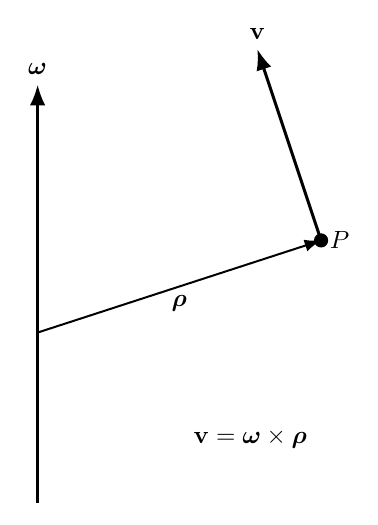
Figure 4. The velocity v = ω ×ρ is tangent to the instantaneous circle of motion and
perpendicular to the plane containing ω and ρ.
7 Recovering the scalar tangential-speed equation
Take the magnitude:
where ϕ is the angle between ω and ρ.
The perpendicular distance from the point to the rotation axis is
Therefore
Thus the familiar scalar equation is the magnitude of the vector cross-product relation.
8 Example 1: velocity from a cross product
Let
and
Then
| v | = ω ×ρ | (22)
|
| = 4ez × (3ex + 2ey + 5ez) | (23)
|
| = 12ey − 8ex. | (24) |
Therefore
The z component of ρ does not contribute because displacement along the rotation axis does not
increase the perpendicular radius.
The speed is
The perpendicular distance is
so
in agreement with the vector result.
9 Angular acceleration as a vector derivative
Angular acceleration is defined by
in an inertial frame.
This derivative can be nonzero for two distinct reasons:
- the magnitude of ω changes,
- the direction of ω changes.
Therefore a body can have constant angular speed while still having nonzero angular acceleration if
its instantaneous rotation axis changes direction.
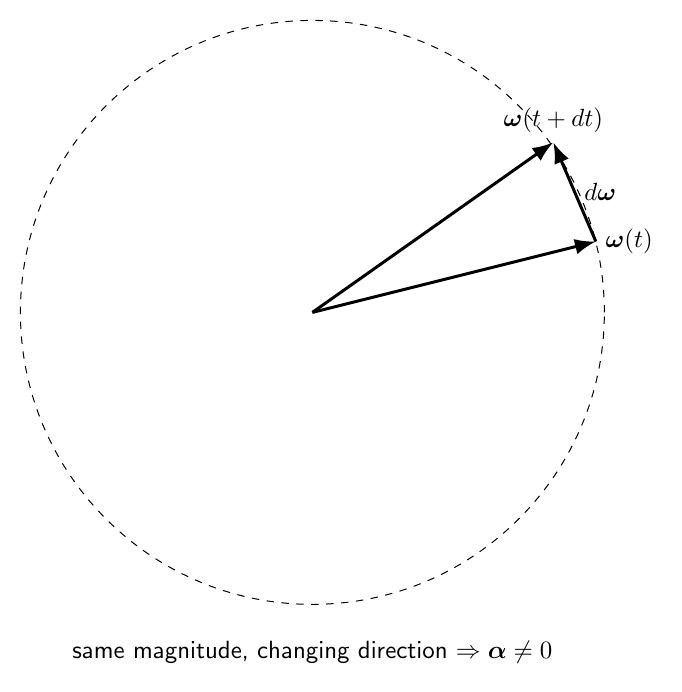
Figure 5. Angular acceleration measures the vector change in ω. A change in direction alone can
produce nonzero α even when |ω| remains constant.
10 Fixed-axis special case
If the axis direction e is constant,
Differentiate:
Thus
for fixed-axis rotation, except at instants when one of the vectors is zero.
In this special case, the signed scalar angular acceleration from M05-01 is simply the component of
α along the fixed axis.
11 Changing-axis example
Suppose
where ω0 and Ω are constants.
The angular speed is constant:
But
| α | =  | (35)
|
| = ω0Ω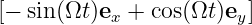 . | (36) |
Therefore
even though the angular speed never changes.
Also,
so α is perpendicular to ω in this example.
12 Derivative of a body-fixed vector
Let A be a vector fixed in a rotating rigid body. Its components in the body remain constant, but
its inertial direction changes.
During an infinitesimal rotation,
Divide by dt:
for a vector whose body-fixed components are constant.
This result is a special case of the rotating-frame transport theorem developed later in the
mechanics sequence.
13 Deriving the acceleration equation
For a material point rotating about a fixed point or fixed axis,
Differentiate in the inertial frame:
| a | =   | (42)
|
| =  ×ρ + ω ×  . | (43) |
Since
we obtain
The first term is associated with changing angular velocity.
The second term is the inward Normal acceleration.
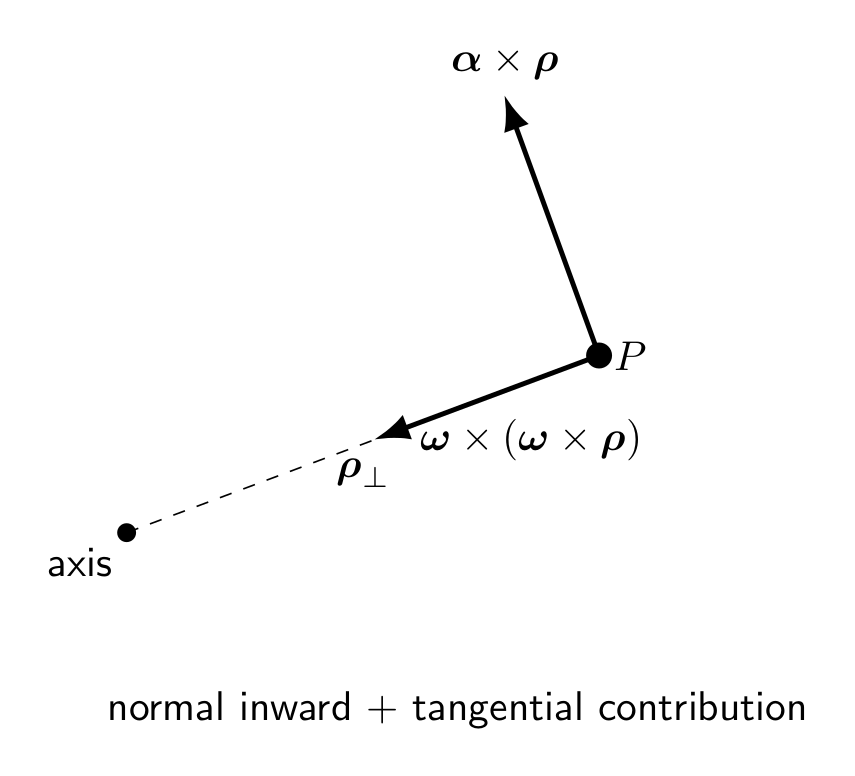
Figure 6. Point acceleration splits into a tangential contribution α×ρ and a normal contribution
ω × (ω ×ρ).
14 Why the double cross product points inward
Use the vector triple-product identity
Set
Then
Decompose ρ into components parallel and perpendicular to ω:
Because
we obtain
The term points directly toward the rotation axis.
Its magnitude is
15 Example 2: fixed-axis acceleration
Let
| ω | = 4ez rad∕s, | (53)
|
| α | = 2ez rad∕s2, | (54)
|
| ρ | = (3ex + 2ey + 5ez) m. | (55) |
Tangential contribution:
| α×ρ | = 2ez × (3ex + 2ey + 5ez) | (56)
|
| = −4ex + 6ey. | (57) |
Normal contribution:
| ω × (ω ×ρ) | = −ω2(3e
x + 2ey) | (58)
|
| = −48ex − 32ey. | (59) |
Therefore
No acceleration component arises from the point’s z coordinate because displacement along the
axis does not contribute to rotational motion around that axis.
16 Relative velocity of two points on a rigid body
Let A and B be two material points on the same rigid body.
Define
Because rB∕A is fixed in the body, its inertial derivative is
But
Therefore
This relation is valid even when the body is translating and rotating simultaneously.
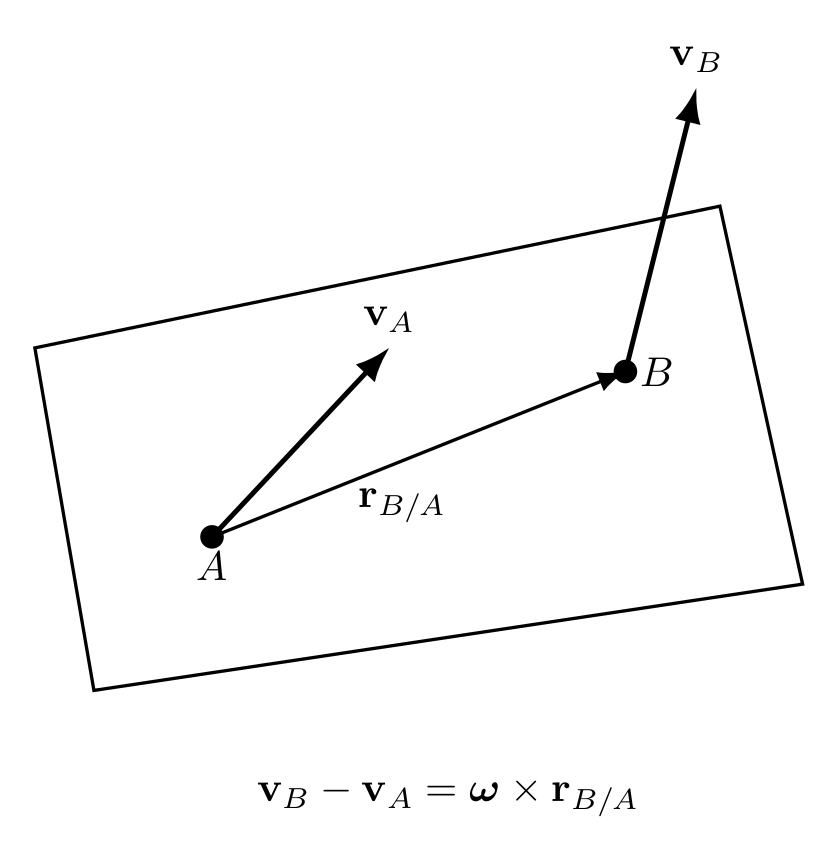
Figure 7. The velocity difference between any two points on a rigid body is determined by the
body’s angular velocity and their fixed separation vector.
17 Relative acceleration of two points on a rigid body
Differentiate the relative-velocity equation:
Then
| aB | = aA + α× rB∕A + ω × . | (66) |
Since
we obtain
This is one of the central equations of rigid body kinematics.
18 Example 3: translating and rotating rigid body
At one instant, point A has velocity
The body has
and
Then
| ω × rB∕A | = 3ez × (2ex + ey) | (72)
|
| = −3ex + 6ey. | (73) |
Therefore
| vB | = (2ex + ey) + (−3ex + 6ey) | (74)
|
| = −ex + 7ey. | (75) |
Thus
19 The angular velocity vector is common to the whole rigid body
Different material points have different linear velocities, but the same instantaneous angular
velocity describes the orientation change of the entire rigid body.
Thus ω is a property of the body’s instantaneous rotational motion, not of one particular
particle.
For any pair of body points A and B,
The same ω must satisfy this relation throughout the rigid body.
20 A useful rigidity check
Because the distance between material points is constant,
Differentiate:
Therefore
The relative velocity of two points on a rigid body is always perpendicular to their separation
vector.
This is consistent with
21 Component form of the velocity equation
Let
and
Then
gives
| vx | = ωyz − ωzy, | (85)
|
| vy | = ωzx − ωxz, | (86)
|
| vz | = ωxy − ωyx. | (87) |
These equations are often useful for direct component calculations.
22 Skew-symmetric cross-product matrix
The cross product with ω can be represented by a matrix:
Then
The matrix is skew-symmetric:
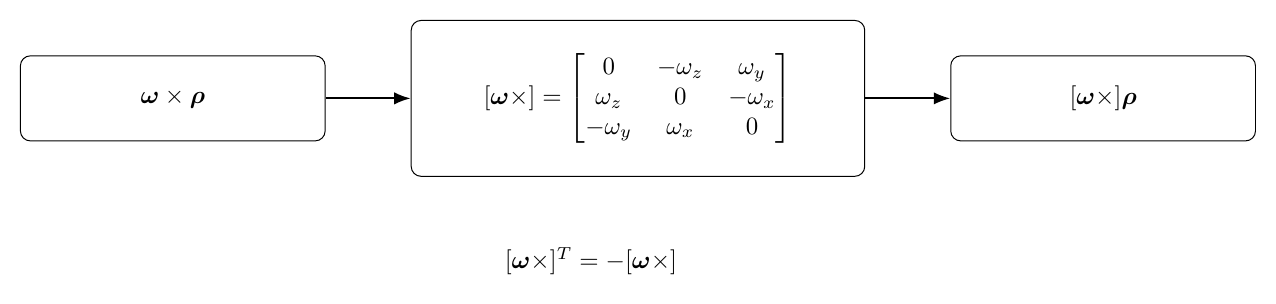
Figure 8. The angular velocity cross product can be represented by a skew-symmetric matrix.
This form becomes important in three-dimensional attitude and rigid body calculations.
23 Why the matrix is skew-symmetric
For any vector x,
The cross product is perpendicular to x, so the quadratic form vanishes.
Skew-symmetric matrices are the natural infinitesimal generators of three-dimensional
rotations.
This observation leads directly to rotation matrices and attitude kinematics in more advanced
treatments.
24 Angular acceleration in matrix form
Define
in an inertial basis.
For a point fixed relative to a rotation center,
Thus
This compact matrix form is especially useful in computation.
25 Instantaneous axis interpretation
At any instant for which
there is an instantaneous rotation axis parallel to ω.
Points lying on that axis have no velocity due to the instantaneous rotation about that axis
because
implies
For a translating and rotating body, however, points on the instantaneous rotational axis can still
have the translational velocity of the chosen reference point.
26 Angular speed versus angular velocity
Angular speed is the magnitude
Differentiate its square:
Then
For ω≠0,
Only the component of α parallel to ω changes the angular speed.
The perpendicular component changes the direction of the angular velocity vector.
27 Parallel and perpendicular components of angular acceleration
Write
The parallel component is
The perpendicular component is
Then:
- α∥ changes |ω|,
- α⊥ changes the direction of ω.
This decomposition is useful in gyroscope and precession problems later in the M05
sequence.
28 Example 4: separating magnitude and direction change
Suppose
and
The parallel component is
The perpendicular component is
The instantaneous rate of change of angular speed is
The 3ex component changes the axis direction but does not instantaneously change
|ω|.
29 Common mistakes
- Treating a finite three-dimensional rotation as an ordinary vector that can be freely
added in any order.
- Forgetting that angular velocity is associated with an axis and a rotational sense.
- Confusing angular speed ω with angular velocity ω.
- Assuming α must always be parallel to ω.
- Assuming constant angular speed implies α = 0 when the axis direction changes.
- Using v = ω ×ρ with the cross-product order reversed.
- Using the full distance |ρ| instead of the perpendicular radius when applying v = ωr⊥.
- Forgetting the double-cross-product normal-acceleration term.
- Assigning an outward sign to ω × (ω ×ρ).
- Using a different angular velocity vector for different points of the same rigid body.
- Applying the fixed-center equation v = ω × ρ to a translating body without adding
the reference-point velocity.
- Forgetting that vB − vA is perpendicular to rB∕A for a rigid body.
- Confusing the angular velocity cross-product matrix with an ordinary symmetric
transformation matrix.
- Using a body-frame derivative of ω when the definition of α requires an inertial
derivative.
30 Practice exercises
- Explain why finite rotations about different axes cannot generally be added as ordinary
vectors.
- Starting from an infinitesimal rotation, derive dr = d𝜃 ×ρ to first order.
- Derive v = ω ×ρ.
- Show that the magnitude of ω ×ρ is ωr⊥.
- Let ω = 2ez mrad∕s and ρ = 4ex + 3ey mm. Find v.
- A body has constant |ω| but its axis direction changes. Explain why α can be nonzero.
- For ω = ω0[cos(Ωt)ex + sin(Ωt)ey], derive α and show that ω ⋅α = 0.
- Derive a = α×ρ + ω × (ω ×ρ).
- Use the vector triple-product identity to show that the normal term is −ω2ρ
⊥.
- Derive the rigid body relative-velocity equation vB = vA + ω × rB∕A.
- Derive the corresponding relative-acceleration equation.
- Show directly from the rigid body distance constraint that rB∕A ⋅ (vB − vA) = 0.
- Construct [ω×] for ω = ωxex + ωyey + ωzez and verify it is skew-symmetric.
- Prove that ω = (ω ⋅α)∕ω for nonzero ω.
- Decompose an arbitrary α into components parallel and perpendicular to ω and explain
the physical meaning of each.
31 Summary
Angular velocity is the instantaneous axial vector describing the rotational motion of a rigid
body:
in the infinitesimal-rotation sense.
Finite three-dimensional rotations do not generally commute, but infinitesimal rotations do
combine vectorially to first order.
For a point fixed in the body relative to a rotation center,
Angular acceleration is
Point acceleration is
For any two points A and B on the same rigid body,
and
The cross-product matrix
provides a compact matrix representation of the same geometry and prepares the way for full
three-dimensional rigid body kinematics.
References
References
[1] J. R. Taylor, Classical Mechanics, University Science Books, 2005.
[2] D. Kleppner and R. Kolenkow, An Introduction to Mechanics, 2nd ed., Cambridge
University Press, 2014.
[3] K. R. Symon, Mechanics, 3rd ed., Addison-Wesley, 1971.
[4] H. Goldstein, C. Poole, and J. Safko, Classical Mechanics, 3rd ed., Addison-Wesley,
2002.
[5] OpenStax, University Physics, Volume 1, Rice University, 2016.