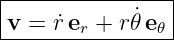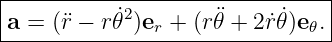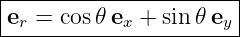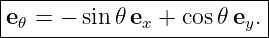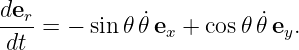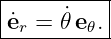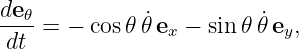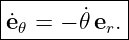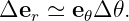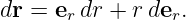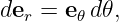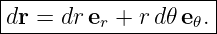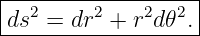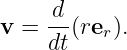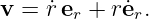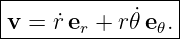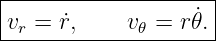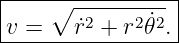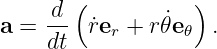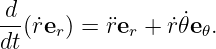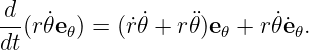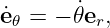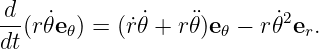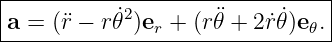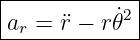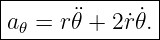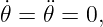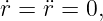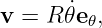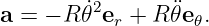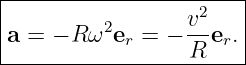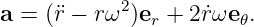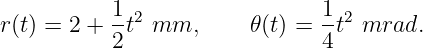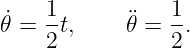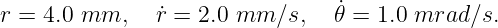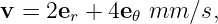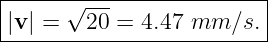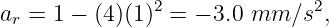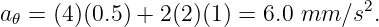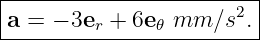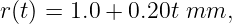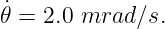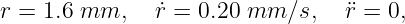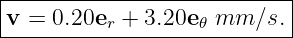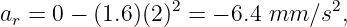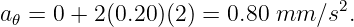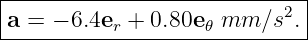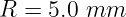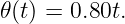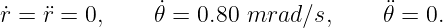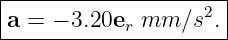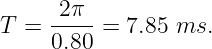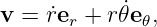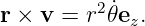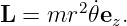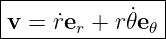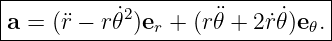Polar Coordinate Particle Kinematics
Cartesian coordinates are often the simplest language for particle motion, but many mechanical
systems have a natural center or axis. Orbital motion, particles moving on disks, sliders on rotating
arms, central force motion, and many planar mechanisms are described more directly by Plane
polar coordinates.
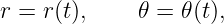
A particle in the plane is located by two coordinates,
where r is the distance from the origin and 𝜃 is the angular coordinate. The important
difference from Cartesian coordinates is that the polar unit vectors rotate as 𝜃 changes.
That moving basis is responsible for the extra terms in polar coordinate velocity and
acceleration.
The main results developed in this article are
and
These equations are kinematic identities. They follow from geometry and differentiation; no force
law has yet been used.
1 The polar basis
In a fixed Cartesian basis ex,ey, define the radial and transverse unit vectors by
and
The vector er points outward from the origin through the particle. The vector e𝜃 is perpendicular
to er and points in the direction of increasing 𝜃.
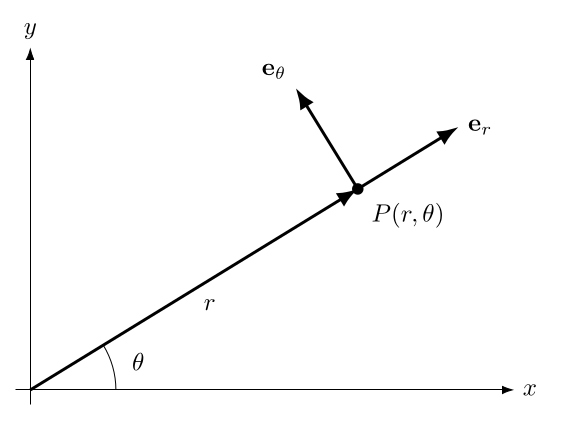
Figure 1. Plane polar coordinates and the local basis. The radial and transverse unit vectors are
attached to the particle and change direction as the angular coordinate changes.
The particle position vector has the particularly simple form
The simplicity of the position formula hides an important complication: er is generally time
dependent.
2 Why the unit vectors change
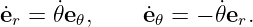
Differentiate the Cartesian expression for er:
The quantity in parentheses is exactly e𝜃, so
Similarly,
which gives
The same result has a geometric interpretation. During a small angular change Δ𝜃, the unit radial
vector rotates through the same angle. Its change is approximately transverse and has magnitude
Δ𝜃:
Dividing by Δt and taking the limit gives the radial basis derivative stated above.
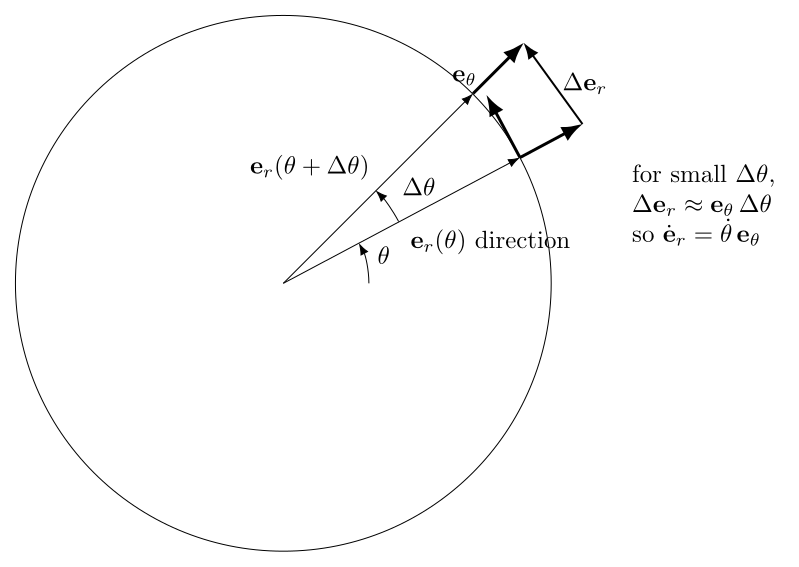
Figure 2. Geometric origin of the polar basis derivative. A small angular change rotates the radial
unit vector toward the transverse direction; dividing that change by time produces the basis
rotation term used in the velocity and acceleration derivations.
This basis rotation is a coordinate effect, not evidence that the physical reference frame itself
is rotating. Polar coordinates may be used perfectly well inside an inertial Cartesian
frame.
3 Differential displacement
Because
a differential change is
For a small angular change,
so
The two orthogonal displacement components therefore have magnitudes dr and r d𝜃. The
corresponding line element is
This already anticipates the two terms that appear in the velocity.
4 Velocity in polar coordinates
Differentiate the position vector directly:
By the product rule,
Using the radial basis derivative derived above,
Thus the radial and transverse velocity components are
The speed is
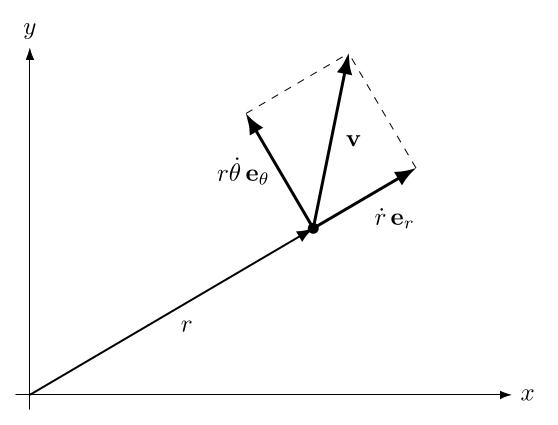
Figure 3. Polar velocity decomposes into a radial component and a transverse component, aligned
with the local polar basis directions.
The factor r multiplying the angular rate is essential. Angular speed has units of rad/s, while the
tangential velocity component must have units of m/s.
5 Acceleration in polar coordinates
Differentiate the velocity:
Differentiate the first term:
Differentiate the second term:
Since
we obtain
Collect the radial and transverse parts:
Therefore
and
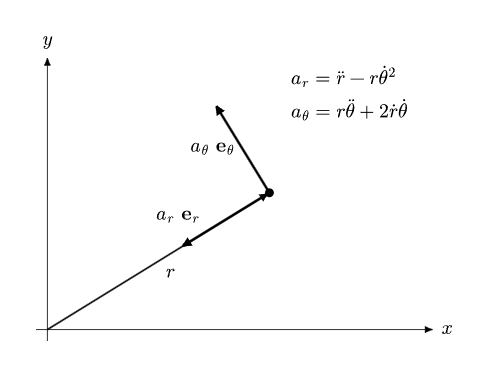
Figure 4. Radial and transverse acceleration components. Each component contains terms caused
by changes in coordinate magnitudes and by rotation of the local polar basis.
6 Physical meaning of the acceleration terms
The four pieces have distinct kinematic meanings.
The term
is the direct radial acceleration caused by changing radial speed.
The term
is inward and remains even when the radius and angular speed are constant. It is the familiar
centripetal acceleration.
The term
is the transverse acceleration associated with angular acceleration.
Finally,
appears when radial motion and angular motion occur simultaneously. It results from
differentiating both the transverse speed and the rotating basis. It is sometimes described as a
Coriolis like kinematic term. In the present derivation, however, we are simply using polar
coordinates in an inertial frame; no fictitious force has been introduced.
7 Important special cases
Pure radial motion
If 𝜃 is constant,
so
Circular motion
If r = R is constant,
and therefore
For uniform circular motion, the angular speed is the constant ω and the angular acceleration is
zero, giving
This recovers the result derived geometrically in M01-08.
Radial sliding on a uniformly rotating arm
If the angular speed ω is constant while r changes,
The transverse term is nonzero even though the angular speed is constant.
8 Worked example 1: a spiral trajectory
A particle moves according to
Find the velocity and acceleration at t = 2 s.
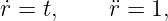
The required derivatives are
At t = 2 s,
Hence
and
The acceleration components are
Therefore
9 Worked example 2: slider on a rotating arm
A bead slides outward on a radial arm according to
while the arm rotates at constant angular speed
Find v and a at t = 3 s.
At that instant,
with 𝜃 = 0. Thus
For the acceleration,
and
Therefore
The transverse acceleration is present even though the angular speed is constant because the radial
distance is changing.
10 Worked example 3: uniform circular motion as a special case
A particle moves on a circle of radius
with
Then
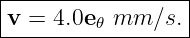
The velocity is
The acceleration is
The period is
Thus the general polar coordinate formula reduces exactly to uniform circular motion when the
radius and angular speed are constant.
11 Connection to angular momentum
Polar kinematics also prepares the geometry used in central force mechanics. Since
and
the specific angular momentum is
For a particle of mass m,
The conservation or evolution of this quantity is a dynamical question, but the r2 times angular
rate structure is already visible from kinematics.
12 Practice problems
- Starting from er = cos 𝜃ex + sin 𝜃ey, differentiate with respect to time and show that
the derivative of er points in the transverse direction with magnitude equal to the
angular rate.
- A particle has r = 3.0 m, radial speed 2.0 m/s, and angular speed 4.0 rad/s. Find vr,
v𝜃, and the speed.
- At one instant a particle has r = 3.0 m, radial speed 2.0 m/s, radial acceleration
contribution −1.0 m/s2, angular speed 4.0 rad/s, and angular acceleration 0.50 rad/s2.
Find ar and a𝜃.
- A particle moves with 𝜃 constant and r(t) = 1 + 3t − 0.5t2 m. Find its velocity and
acceleration at t = 2 s.
- A particle moves on a circle of radius 2.5 m with constant angular speed 3.0 rad/s.
Find its speed and acceleration vector in polar components.
- A bead moves on an arm rotating at constant ω = 5.0 rad/s. At an instant r = 0.80
m, the radial speed is −0.30 m/s, and the second time derivative of r is zero. Find ar
and a𝜃.
- For r(t) = 2t m and 𝜃(t) = 0.50t2 rad, find v and a at t = 1 s.
- Show directly from ds2 = dr2+r2d𝜃2 that dividing by dt2 produces the polar coordinate
speed formula derived in the text.
13 Answer check
- Differentiate term by term; the resulting direction is e𝜃, multiplied by the angular rate.
- vr = 2.0 m/s, v𝜃 = 12.0 m/s, v =
 = 12.17 m/s.
- ar = −49.0 m/s2; a
𝜃 = 17.5 m/s2.
- At t = 2 s the radial speed is 1.0 m/s and the radial acceleration is −1.0 m/s2, so
v = 1.0er m/s and a = −1.0er m/s2.
- v = 7.5 m/s; a = −22.5er m/s2.
- ar = −20.0 m/s2; a
𝜃 = −3.0 m/s2.
- At t = 1 s: r = 2 m, radial speed 2 m/s, radial second derivative zero, angular speed 1
rad/s, and angular acceleration 1 rad/s2; v = 2e
r +2e𝜃 m/s and a = −2er +6e𝜃 m/s2.
- Divide the line element relation by dt2 and take the positive square root.
14 Summary
For plane polar coordinates,
with rotating basis relations
These lead to
and
The additional terms compared with Cartesian formulas arise because the local polar basis changes
direction with time. This is the essential idea that generalizes to cylindrical, spherical, and other
curvilinear coordinate systems.
References
[1] J. R. Taylor, Classical Mechanics, University Science Books, 2005.
[2] J. B. Marion and S. T. Thornton, Classical Dynamics of Particles and Systems, 5th
ed., Brooks/Cole, 2004.
[3] H. Goldstein, C. Poole, and J. Safko, Classical Mechanics, 3rd ed., Addison-Wesley,
2002.
[4] PhysicsLibrary, M00-05, Coordinate Systems for Mechanics.
[5] PhysicsLibrary, M01-08, Uniform Circular Motion.