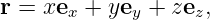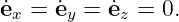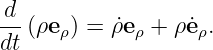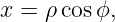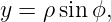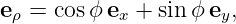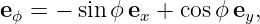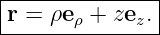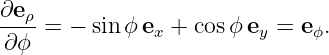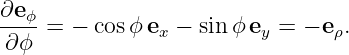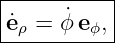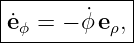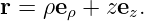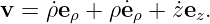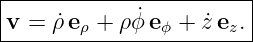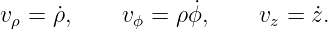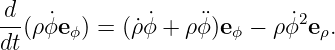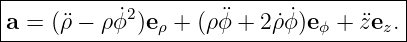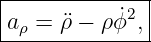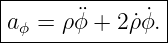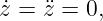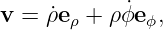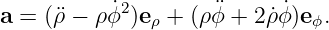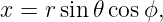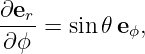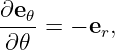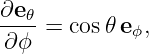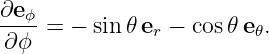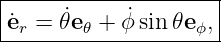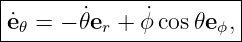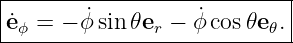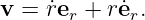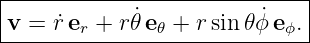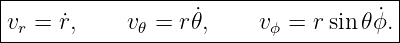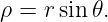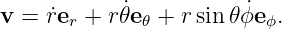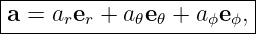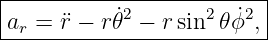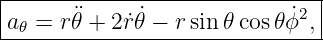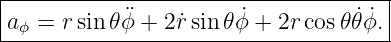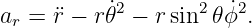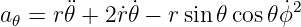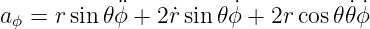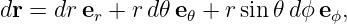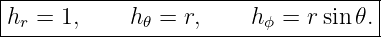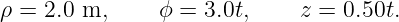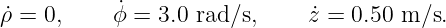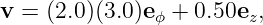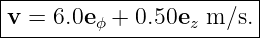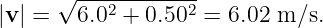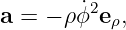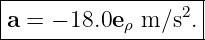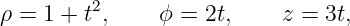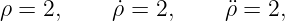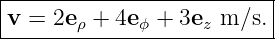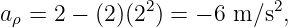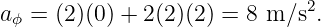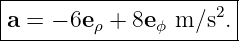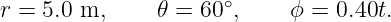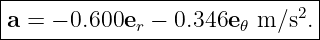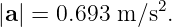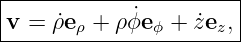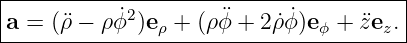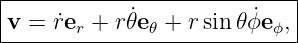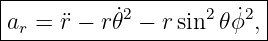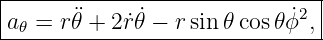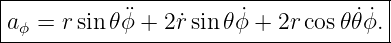Cylindrical and Spherical Particle Kinematics
Cartesian coordinates are often the simplest coordinates for mechanics because the basis vectors
are fixed. Many three-dimensional problems, however, possess axial or spherical geometry. In
those cases cylindrical or spherical coordinates can describe the motion much more
naturally.
The complication is that the curvilinear basis vectors generally move with the particle. Therefore
velocity and acceleration are not obtained by differentiating only the scalar coordinates. One must
also differentiate the basis vectors themselves.
This article derives the complete particle velocity and acceleration formulas for cylindrical
coordinates
and spherical coordinates
using the convention that 𝜃 is the polar angle measured from the positive z axis and ϕ is the
azimuth measured in the xy plane.
1 Why curvilinear basis vectors matter
In a Cartesian frame,
and the unit vectors satisfy
In cylindrical and spherical coordinates, some unit vectors point in directions defined by the
particle’s current angular coordinates. When those angles change, the basis rotates. Thus a
derivative such as
must be evaluated with the product rule:
The second term is the source of the angular pieces that distinguish curvilinear kinematics from
Cartesian kinematics.
2 Cylindrical coordinates
Cylindrical coordinates are related to Cartesian coordinates by
and
Here ρ is the perpendicular distance from the z axis, ϕ is the azimuthal angle in the xy plane, and
z is the ordinary vertical Cartesian coordinate.
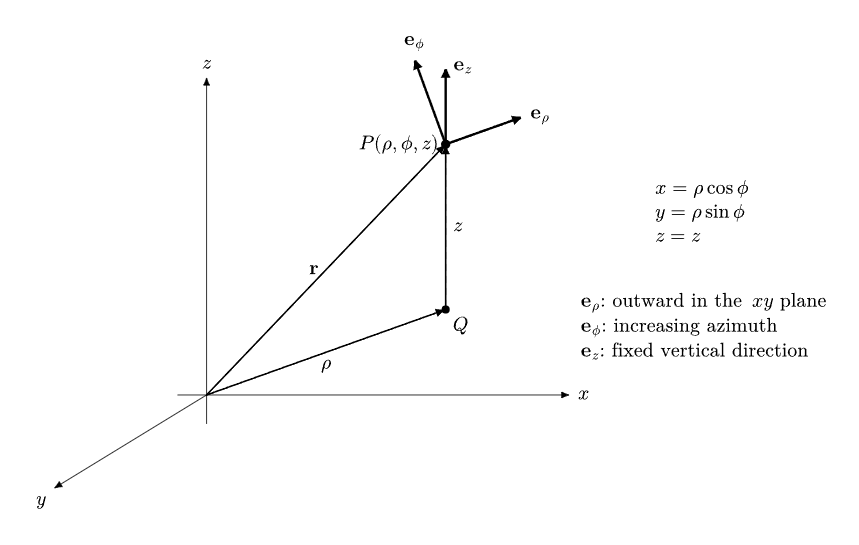
Figure 1. Cylindrical coordinates describe a point by distance ρ from the z axis, azimuth ϕ, and
height z. The local basis vectors eρ and eϕ rotate as ϕ changes, while ez remains fixed.
The cylindrical unit vectors can be written in the Cartesian basis as
and
The position vector is
3 Cylindrical basis-vector derivatives
Differentiate eρ with respect to ϕ:
Likewise,
Since the basis vectors depend on time only through ϕ(t),
and
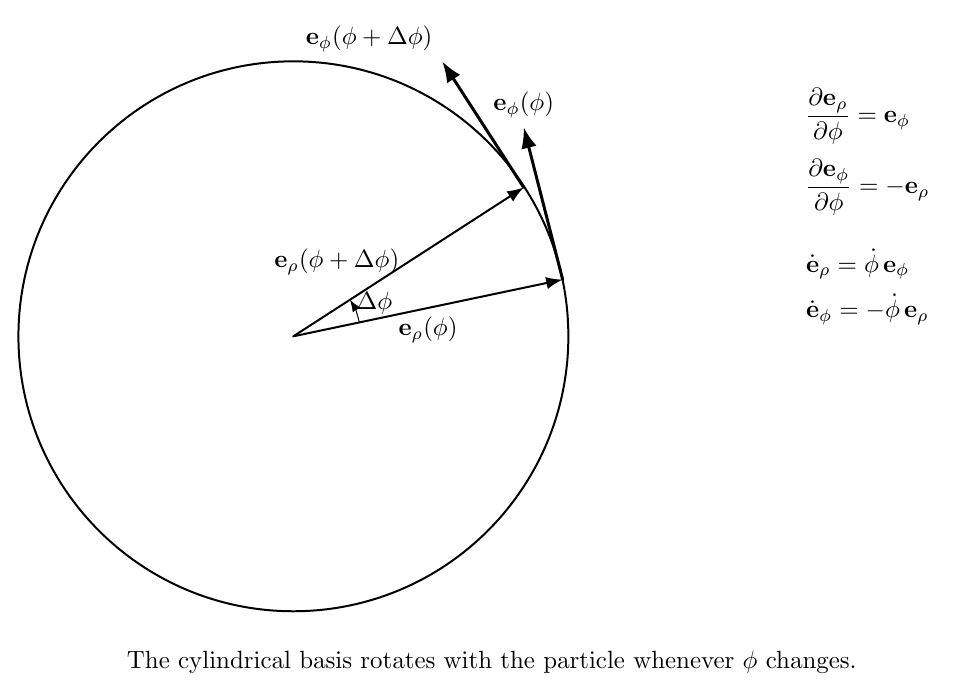
Figure 2. The cylindrical radial and azimuthal unit vectors rotate through the same small angle
as the particle’s azimuth. This rotating basis produces the additional terms that appear in
cylindrical velocity and acceleration.
4 Cylindrical velocity
Differentiate
Using the product rule,
Substitute
to obtain
Thus the physical velocity components are
Notice that 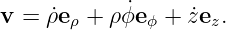 ∕
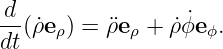 itself is an angular rate, not a linear speed. The azimuthal linear speed is
ρ
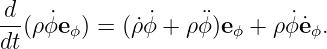 ∕
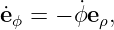 .
5 Cylindrical acceleration
Differentiate the cylindrical velocity:
The derivative of the first term is
The derivative of the azimuthal term is
Using
gives
Combining terms,
The radial component is
and the azimuthal component is
The term −ρ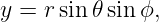 2 is the inward centripetal contribution. The term 2
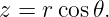 ∕
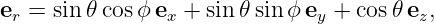
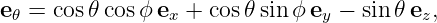 ∕
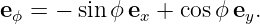 appears because the radial distance and the rotating basis change simultaneously.
6 Polar-coordinate motion as a cylindrical special case
If the motion remains in a plane of constant z, then
and cylindrical kinematics reduces directly to planar polar kinematics:
This is the direct three-dimensional extension of M01-10.
7 Spherical coordinates and convention
Spherical-coordinate notation is not universal, so the angular convention must be stated explicitly.
In this article,
- r is radial distance from the origin;
- 𝜃 is the polar angle measured downward from the positive z axis;
- ϕ is the azimuth measured in the xy plane from the positive x axis.
The Cartesian relations are
and
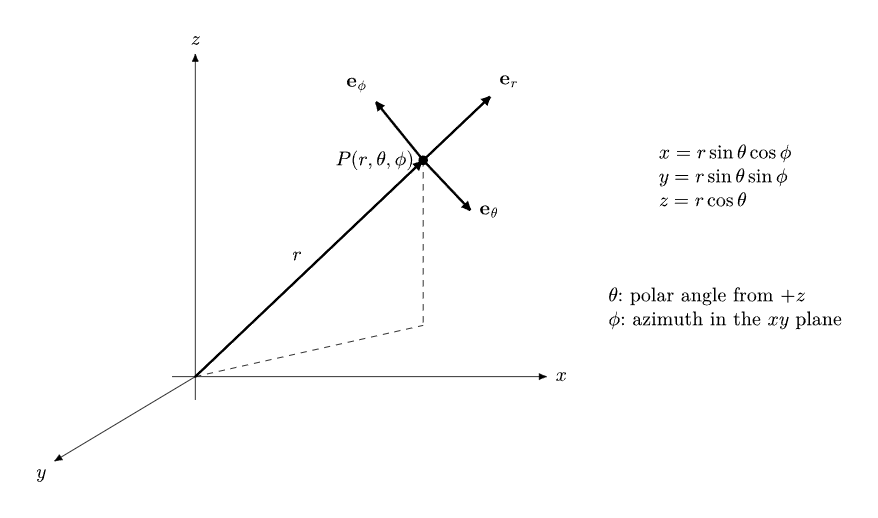
Figure 3. Spherical-coordinate convention used throughout this article. The polar angle 𝜃 is
measured from +z and the azimuth ϕ is measured in the xy plane. Stating this convention
prevents the common interchange of 𝜃 and ϕ.
The spherical basis vectors are
and
The position vector is especially simple:
8 Spherical basis-vector derivatives
Because the spherical basis depends on both 𝜃 and ϕ, its derivatives are richer than in cylindrical
coordinates.
The needed partial derivatives are
and
Applying the chain rule gives the time derivatives
and
9 Spherical velocity
Differentiate
Then
Substitute the derivative of er:
Thus the physical velocity components are
The factor r sin 𝜃 is the perpendicular distance from the particle to the z axis, so the azimuthal
speed is exactly the circular-motion form ρ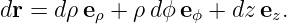 ∕
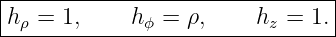 with
10 Spherical acceleration
Start from
Differentiate each term with the product rule and then substitute the three basis-vector
derivatives. Collecting coefficients of er, e𝜃, and eϕ gives
where
and
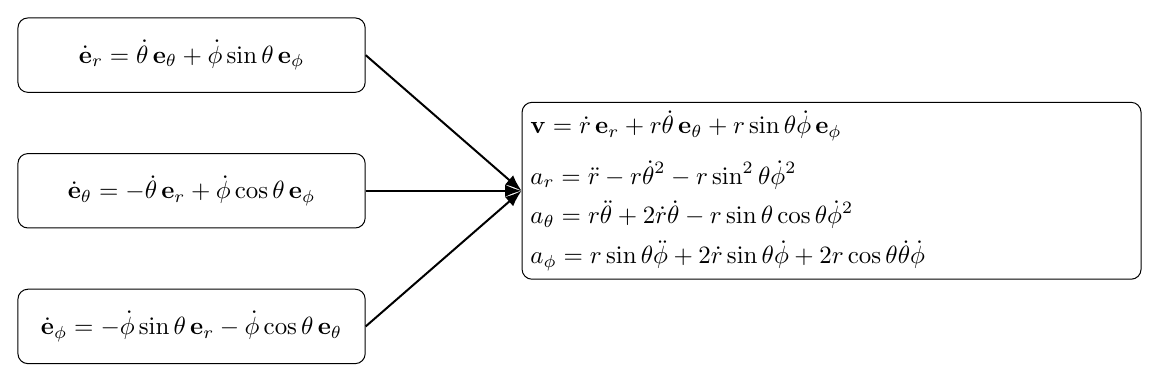
Figure 4. The spherical acceleration formula follows from differentiating the velocity while also
differentiating the moving spherical basis. Each coupling term has a geometric origin in a
changing scale factor or rotating unit vector.
11 Interpreting the spherical terms
The radial acceleration contains three contributions:
The first is ordinary radial acceleration. The other two are inward curvature terms associated with
angular motion.
The polar component
contains polar angular acceleration, radial-polar coupling, and a geometric contribution from
azimuthal motion.
The azimuthal component
contains azimuthal angular acceleration plus coupling terms from changing radial distance and
changing polar angle.
These are kinematic terms produced by coordinate geometry; they do not by themselves represent
new physical forces.
12 Scale factors
The physical differential displacement in cylindrical coordinates is
Therefore the cylindrical scale factors are
In spherical coordinates,
so
The velocity formulas can be read directly from these physical line elements.
13 Coordinate singularities
Curvilinear coordinates may become singular even when physical space is perfectly
regular.
In cylindrical coordinates, ϕ is undefined on the z axis where
In spherical coordinates, all angles are undefined at
and the azimuth ϕ is undefined on the polar axis where
These are coordinate singularities, not physical singularities. One should avoid interpreting
divergent coordinate rates near such locations without first checking the actual Cartesian
motion.
14 Worked example 1: uniform helical motion in cylindrical coordinates
A particle follows
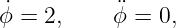
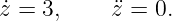
Then
The velocity is
so
Its speed is
Because 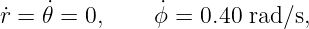 ∕
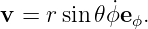 =
 ∕
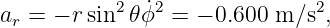 =
 ∕
 = 0,
so
The vertical motion does not contribute to acceleration because  ∕
 is constant.
15 Worked example 2: expanding spiral with vertical motion
A particle has
with SI units understood. Find v and a at t = 1 s.
At t = 1,
and
Therefore
For the acceleration,
and
Hence
The nonzero azimuthal acceleration occurs even though  ∕
 = 0 because ρ is increasing
while the basis rotates.
16 Worked example 3: constant-r, constant-𝜃 spherical motion
A particle moves with
Thus
and all second coordinate derivatives vanish.
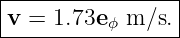
The velocity is purely azimuthal:
Therefore
The acceleration components are
and
Thus
Its magnitude is
This is exactly the centripetal acceleration for circular motion about the z axis. The circle has
cylindrical radius
so
17 Practice problems
- In cylindrical coordinates, a particle has ρ = 3.0 m,
 ∕
 = 1.0 m/s,
 ∕
 =
2.0 rad/s, and
 ∕
 = −0.50 m/s. Find its velocity vector in the cylindrical basis
and its speed.
- A particle moves on a cylinder of fixed radius ρ = 4.0 m with ϕ = 0.50t2 and z = 2.0t.
Find v and a at t = 2.0 s.
- Show that for ρ = R = constant, z = constant, and
 ∕
 = ω = constant, the
cylindrical acceleration reduces to a = −ω2Re
ρ.
- A particle has ρ = t2, ϕ = t, and z = 0. Evaluate a
ρ and aϕ at t = 2 s.
- In spherical coordinates, r = 4.0 m, 𝜃 = 45∘,
 ∕
 = 1.0 m/s,
 ∕
 = 0.20
rad/s, and
 ∕
 = 0.50 rad/s. Find vr, v𝜃, and vϕ.
- A particle moves radially outward with r = 2+t2, while 𝜃 and ϕ remain constant. Find
its velocity and acceleration in the spherical basis.
- A particle moves with r = 3.0 m, 𝜃 = 90∘, and ϕ = 2.0t. Use the spherical formulas
to find its speed and acceleration, and show that the result matches uniform circular
motion in the xy plane.
- Starting from the Cartesian expression for er, explicitly verify ∂er∕∂𝜃 = e𝜃 and
∂er∕∂ϕ = sin 𝜃 eϕ.
18 Answer check
- v = 1.0eρ + 6.0eϕ − 0.50ez m/s; |v| = 6.10 m/s.
- At t = 2 s,
 ∕
 = 2.0 rad/s and
 ∕
 = 1.0 rad/s2. Thus v =
8.0eϕ + 2.0ez m/s and a = −16.0eρ + 4.0eϕ m/s2.
- Direct substitution gives aρ = −Rω2, a
ϕ = 0, and az = 0.
- At t = 2: ρ = 4,
 ∕
 = 4,
 ∕
 = 2,
 ∕
 = 1,
 ∕
 = 0.
Hence aρ = −2 m/s2 and a
ϕ = 8 m/s2.
- vr = 1.0 m/s, v𝜃 = 0.80 m/s, vϕ = 1.41 m/s.
- v = 2ter and a = 2er.
- v = r
 ∕
 = 6.0 m/s and a = −r
 2e
r = −12.0er m/s2; at 𝜃 = 90∘,
er lies in the xy plane and points radially outward.
- Differentiation gives the stated basis identities exactly.
19 Summary
Cylindrical and spherical coordinates simplify problems with axial or radial geometry, but their
basis vectors move with the particle. The central cylindrical results are
For the stated spherical convention,
with acceleration components
and
The safest derivation strategy is always the same: write the position vector, determine how the
local basis vectors change, and then differentiate carefully with the product and chain
rules.
References
[1] PhysicsLibrary, M01-10, Polar-Coordinate Particle Kinematics.
[2] Wikibooks, Classical Mechanics, sections on generalized and curvilinear coordinate
descriptions, CC BY-SA.
[3] Wikipedia, articles on cylindrical coordinate systems, spherical coordinate systems,
and vector calculus in curvilinear coordinates, CC BY-SA.
[4] J. B. Marion and S. T. Thornton, Classical Dynamics of Particles and Systems, 5th
ed., Brooks/Cole, 2004. Used as a scope and notation reference.