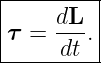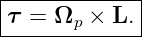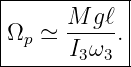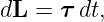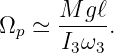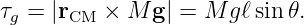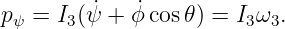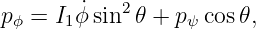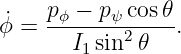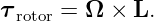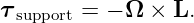|
|
|
|||||||
For steady precession of a fixed-magnitude angular-momentum vector,
For a rapidly spinning heavy top,
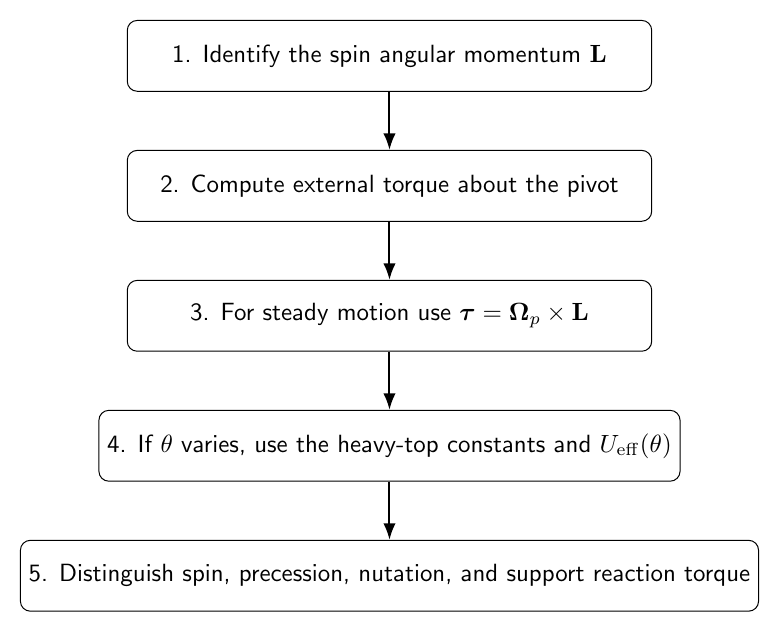
Figure 1. A compact strategy for gyroscope problems: identify the angular-momentum direction, compute the torque about the pivot, use the vector precession relation, and distinguish steady precession from nutation.
1 High-value GRE facts
Part I: Original GRE-style problems
Problem 1: perpendicular torqueA torque remains perpendicular to a constant-magnitude angular momentum vector. Its primary effect is to change
Problem 2: steady precession magnitudeIf the angle between Ωp and L is 𝜃, then
Problem 3: fast heavy topFor a rapidly spinning heavy top,
is approximately
Problem 4: effect of doubling spinWithin the fast-top approximation, doubling ω3 changes Ωp by a factor of
Problem 5: gravity torqueA top has center of mass distance ℓ from its pivot and inclination 𝜃 from vertical. The gravity torque magnitude is
Problem 6: nutationNutation refers to
Problem 7: cyclic spin coordinateFor the heavy symmetric top,
equals
Problem 8: precession rate from constantsFor the symmetric top,
equals
Problem 9: nutation turning pointAt a nutation turning point,
Problem 10: stable steady precessionIn the effective-potential picture, stable steady precession occurs at
Problem 11: reaction torqueA rotor is forced to precess with angular velocity Ω and angular momentum L. The torque exerted by the rotor on its support is
Problem 12: torque-free symmetric bodyFor an ideal torque-free symmetric body, the angle between its symmetry axis and the inertial angular-momentum vector is
Part II: Complete worked solutions
Solution 1From
a perpendicular torque produces a perpendicular increment in angular momentum. To first order the magnitude is unchanged and the direction turns. Answer: (B).
Solution 2The magnitude of
is
Answer: (B).
Solution 3For rapid spin,
and gravity gives
Answer: (B).
Solution 4The precession rate is inversely proportional to spin rate:
Doubling spin halves the precession rate. Answer: (B).
Solution 5
Answer: (C).
Solution 6Nutation is oscillation or variation of the inclination angle
Answer: (B).
Solution 7Because
is cyclic,
Answer: (A).
Solution 8From
Answer: (A).
Solution 9At a turning point of the effective one-dimensional inclination motion,
Answer: (A).
Solution 10Stable steady precession requires a stable equilibrium of the inclination coordinate:
Thus it occurs at a local minimum. Answer: (B).
Solution 11The torque on the rotor is
Newton’s third law gives the support torque:
Answer: (B).
Solution 12For a torque-free symmetric body,
is fixed in inertial space and the symmetry axis precesses around it with constant inclination. Answer: (A).
2 GRE checklist
References
References
[1] PhysicsLibrary, M05-11, Euler’s Equations for Rigid Body Rotation. [2] PhysicsLibrary, M05-10, Principal Axes and Principal Moments of Inertia. [3] J. R. Taylor, Classical Mechanics, University Science Books, 2005. [4] H. Goldstein, C. Poole, and J. Safko, Classical Mechanics, 3rd ed., Addison-Wesley, 2002. "GRE Physics Companion: Gyroscopes, Precession, and Nutation" is owned by bloftin.
This object's parent. Cross-references: forces, effective potential, formula, equilibrium, angular velocity, energy, heavy symmetric top, oscillation, magnitude, acceleration, position, center of mass, moment of inertia, mass, turning points, spin, angular momentum, nutation, precession, torque, gyroscope, vector, steady precession, relation This is version 1 of GRE Physics Companion: Gyroscopes, Precession, and Nutation, born on 2026-10-17. Object id is 1487, canonical name is GREPhysicsCompanionGyroscopesPrecessionAndNutation. Accessed 7 times total. Classification:
|
|
|
|
Pending Errata and AddendaNone.
|
DiscussionNo messages.
|
Interact |