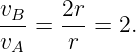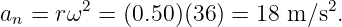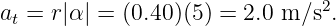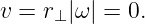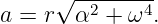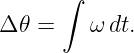|
|
|
|||||||
For a point at perpendicular radius r⊥,
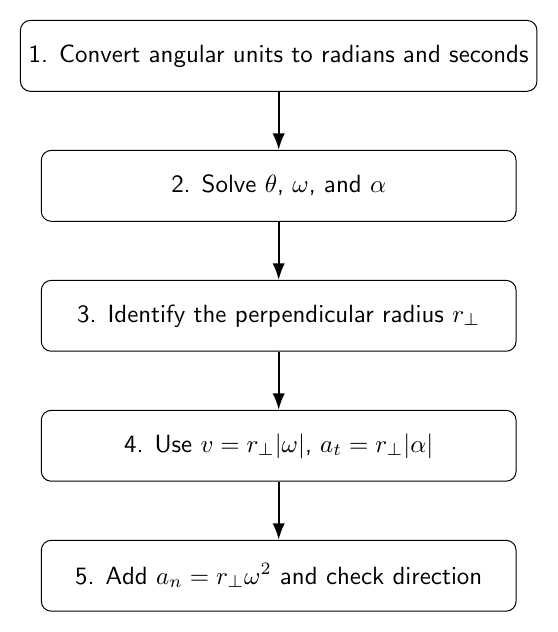
Figure 1. A compact strategy for fixed-axis rotational-kinematics problems. Work in radians, solve the angular motion first, then convert to point motion using the perpendicular radius.
1 High-value GRE facts
Part I: Original GRE-style problems
Problem 1: revolutions to radiansA wheel rotates through 3 complete revolutions. Its angular displacement is
Problem 2: frequency and angular speedA rotor spins at 10 Hz. Its angular speed is
Problem 3: constant angular accelerationA wheel starts from rest with constant angular acceleration 4 rad∕s2. After 3 s its angular speed is
Problem 4: angular displacementFor the wheel in Problem 3, the angular displacement after 3 s is
Problem 5: two radiiPoints A and B lie on the same rotating disk at radii r and 2r. The ratio of their speeds is
Problem 6: normal accelerationA point is 0.50 m from the axis of a wheel rotating at 6 rad∕s. Its normal acceleration is
Problem 7: tangential accelerationA point at radius 0.40 m has angular acceleration magnitude 5 rad∕s2. Its tangential acceleration magnitude is
Problem 8: constant angular speedA point away from the axis of a rigid body rotates with constant nonzero angular speed. Its acceleration is
Problem 9: sign of angular accelerationA wheel has ω = −8 rad∕s and α = −2 rad∕s2. Its angular speed is
Problem 10: point on axisA material point lies exactly on a fixed rotation axis. Its tangential speed is
Problem 11: radial scaling of accelerationTwo points on the same disk have radii r and 3r. At one instant the disk has the same ω and α for both points. The ratio of their total acceleration magnitudes is
Problem 12: angular graphThe area under an angular-velocity-versus-time graph equals
Part II: Complete worked solutions
Solution 1Each revolution is 2π radians:
Answer: (C).
Solution 2
Answer: (C).
Solution 3
Answer: (D).
Solution 4
Answer: (C).
Solution 5All points share the same angular speed:
Thus
Answer: (C).
Solution 6
Answer: (D).
Solution 7
Answer: (B).
Solution 8Constant angular speed means
so tangential acceleration is zero. Normal acceleration remains
Answer: (C).
Solution 9The signed angular velocity is negative and becomes more negative because α < 0. Therefore |ω| increases. Answer: (A).
Solution 10On the axis,
Hence
Answer: (D).
Solution 11At fixed ω and α,
Thus total acceleration magnitude is proportional to radius:
Answer: (C).
Solution 12Since
integration gives
Answer: (B).
2 GRE checklist
References
References
"GRE Physics Companion: Rotational Kinematics of Rigid Bodies" is owned by bloftin.
This object's parent. Cross-references: algebraic, angular velocity, graph, material point, velocity, magnitude, angular acceleration, spins, angular displacement, Normal, acceleration, speed, rigid body, kinematics, motion, work, fixed-axis rotation This is version 1 of GRE Physics Companion: Rotational Kinematics of Rigid Bodies, born on 2026-10-05. Object id is 1419, canonical name is GREPhysicsCompanionRotationalKinematicsOfRigidBodies. Accessed 3 times total. Classification:
|
|
|
|
Pending Errata and AddendaNone.
|
DiscussionNo messages.
|
Interact |

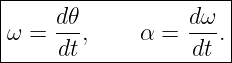
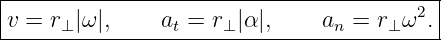
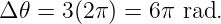
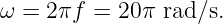
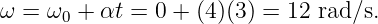

 (4)(9)