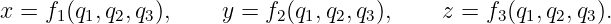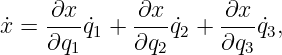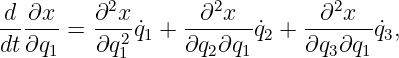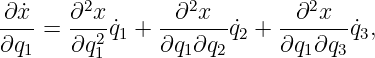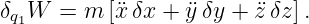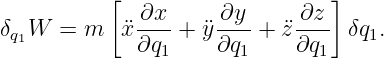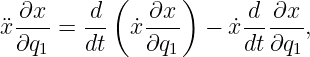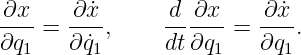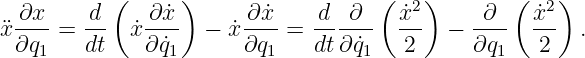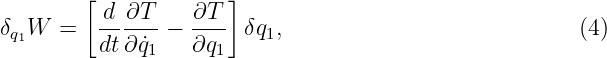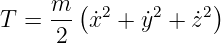Dynamics of a Particle: Free Motion
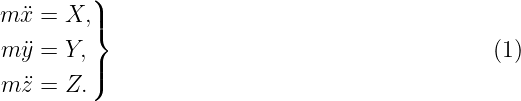
The differential equations for the motion of a particle under any forces when we use rectangular
coordinates are known to be
X,Y, and Z, the components of the actual forces on the particle resolved parallel to the fixed
rectangular axes, or rather their equivalents mẍ,mÿ,mz, are called the effective forces on the
particle. They are of course a set of forces mechanically equivalent to the actual forces acting on
the particle.
The equations of motion of the particle in terms of any other system of coordinates are easily
obtained.
Let q1,q2,q3 be the coordinates in question. The appropriate formulas for transformation of
coordinates express x,y, and z in terms of q1,q2, and q3:
For the component velocity ẋ we have
and ẋ,ẏ,ż are explicit functions of q1,q2,q3,q1,q2,q3, linear and homogeneous in terms of
q1,q2,q3.
We may note in passing that it follows from this fact that ẋ2,ẏ2, and ż2 are homogeneous
quadratic functions of q1,q2, and q3.
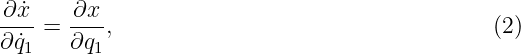
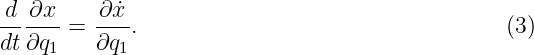
Obviously
and since
and
we have
Let us find now an expression for the work δq1W done by the effective forces when the coordinate
q1 is changed by an infinitesimal amount δq1 without changing q2 or q3. If δx,δy,δz are the
changes thus produced in x,y,z, obviously
If expressed in rectangular coordinates, we need, however, to express δq1W in terms of our
coordinates q1,q2,q3:
Now
but by (2) and (3),
Hence
Therefore
where
is the kinetic energy of the particle.
To get our differential equation we have only to write the second member of (4) equal to the work
done by the actual forces when q1 is changed by δq1.
If we represent the work in question by Q1δq1, our equation is
and of course we get such an equation for every coordinate.
It must be noted that usually equation (5) will contain q2 and q3 and their time derivatives as
well as q1, and therefore cannot be solved without the aid of the other equations of the
set.
In any concrete problem, T must be expressed in terms of q1,q2,q3 and their time derivatives
before we can form the expression for the work done by the effective forces. The work done by the
actual forces must be obtained from direct examination of the problem.
Source
William Elwood Byerly, An Introduction to the Use of Generalized Coördinates in mechanics and
Physics, Ginn and Company, 1916. Chapter I, “Introduction.”
The 1916 source work is in the public domain in the United States.