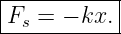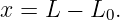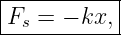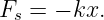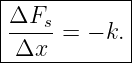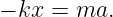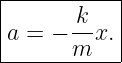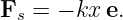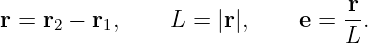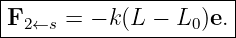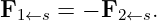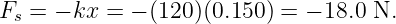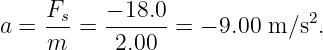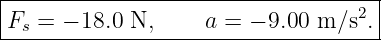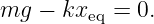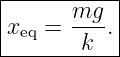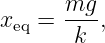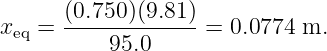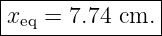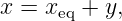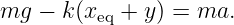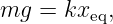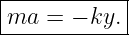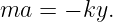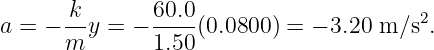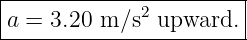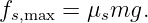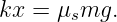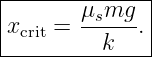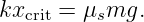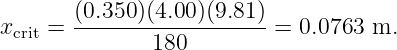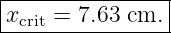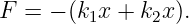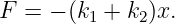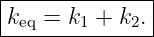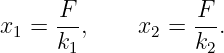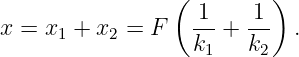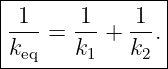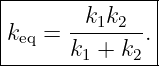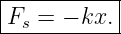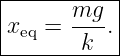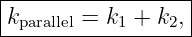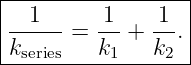Spring Force and Hooke’s Law
A spring is a useful model because its force depends on the spring’s deformation rather than simply
on where an object happens to be in space. Within the linear elastic range, the spring force is
proportional to the displacement from the spring’s undeformed configuration and points in the
direction that tends to restore the spring toward that configuration.
This article develops the one-dimensional spring-force law, its vector interpretation, the meaning
and units of the spring constant, static equilibrium with gravity, Friction thresholds, and
equivalent stiffness for simple combinations of ideal springs. The central modeling rule
is
The minus sign is not an extra force. It records direction: the spring force opposes the signed
deformation x.
1 Deformation is measured from a reference length
Let an ideal spring have natural length L0. If its instantaneous length is L, define the signed
deformation
Then
means the spring is stretched, while
means it is compressed.
The coordinate x here is a deformation coordinate. It need not be the same as the object’s
coordinate measured from an arbitrary laboratory origin.
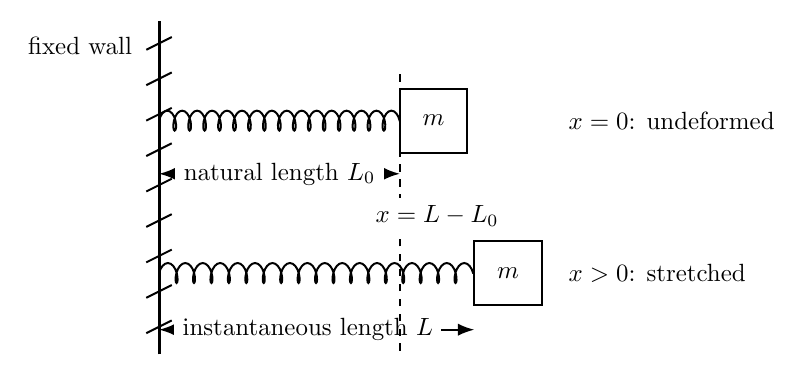
Figure 1. The spring deformation is measured relative to the natural length. Stretching gives
positive deformation in the convention shown; compression gives negative deformation.
2 Hooke’s law and the restoring direction
For an ideal linear spring,
where k is the spring constant. Since force has SI units of newtons and deformation has units of
metres,
The spring constant measures stiffness. A larger k means a larger force is required to produce the
same deformation.
If x > 0, the spring is stretched and
so the force points toward decreasing x. If x < 0, the spring is compressed and
so the force points toward increasing x.
In both cases, the force points toward x = 0.
3 Force-displacement graph
Hooke’s law is linear. A graph of spring force versus deformation is therefore a straight line
through the origin:
Its slope is
Thus the magnitude of the slope gives the spring constant.
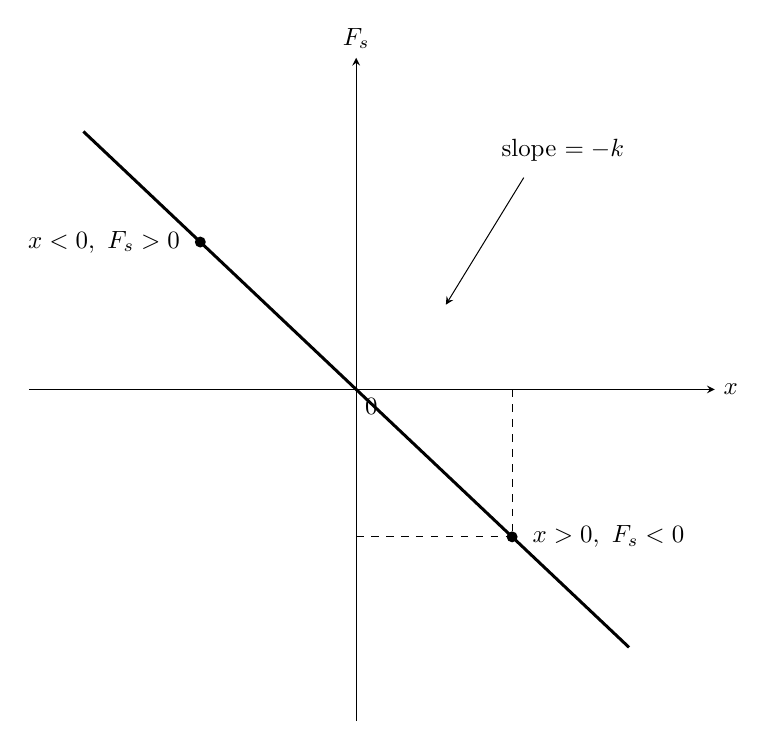
Figure 2. For an ideal Hooke-law spring, the force-displacement graph is linear with slope −k.
The opposite signs of Fs and x express the restoring character of the force.
The model is usually an approximation. Real springs are approximately linear only over a finite
range of deformation. If the spring is stretched or compressed far enough, the force-displacement
curve can become nonlinear, and sufficiently large deformation can produce permanent
changes.
4 Newton’s second law with a spring force
For a block of mass m moving along the spring axis, suppose x = 0 is the natural-length
configuration and the spring is the only horizontal force. Newton’s second law gives
Therefore
The acceleration points toward the undeformed configuration. At larger deformation, its magnitude
is larger.
This equation is the dynamical seed of simple harmonic motion, but the full time-dependent
solution is deferred to the oscillations sequence.
5 A useful vector form
For a spring constrained to act along a known axis with unit vector e, the force can be
written
For a spring joining two particles, a more geometric statement is useful. Let
If the natural length is L0, then the force on particle 2 due to the spring is
The force on particle 1 is equal and opposite:
This form makes clear that the spring force acts along the spring and satisfies Newton’s third
law.
6 Worked example 1: horizontal spring acceleration
A 2.00 kg block is attached to a horizontal spring with spring constant k = 120 N∕m. The spring
is stretched 0.150 m from its natural length. Neglect friction. Find the spring force and the block’s
instantaneous acceleration.
Using Hooke’s law,
Thus the force has magnitude 18.0 N and points toward the natural-length position.
Newton’s second law gives
Therefore
7 Vertical springs and equilibrium
Consider a mass hanging from a vertical spring. Let x be the downward extension from the spring’s
natural length. The forces on the mass are its Weight downward and the spring force
upward.
At static equilibrium,
Hence
The spring is still stretched at equilibrium. Equilibrium does not mean the spring force is zero; it
means the net force is zero.
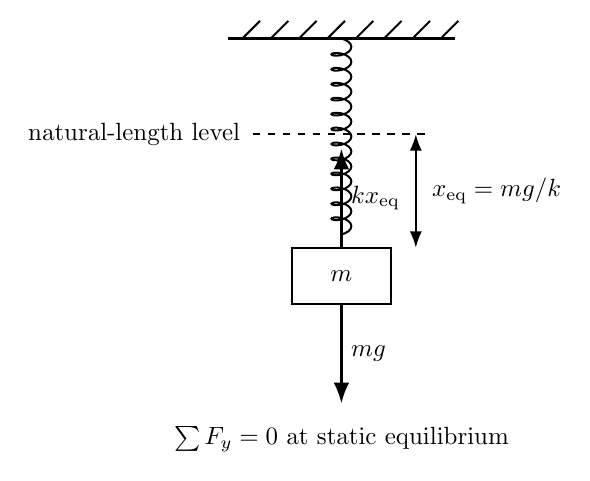
Figure 3. A hanging mass stretches a vertical spring until the upward spring force balances the
downward weight. The equilibrium extension is mg∕k.
8 Worked example 2: hanging mass equilibrium
A 0.750 kg mass hangs from a vertical spring with k = 95.0 N∕m. Find the equilibrium
extension.
From
we obtain
Thus
Notice that the mass changes the equilibrium position but does not change the spring
constant.
9 Displacement measured from equilibrium
For a vertical spring, it is often convenient to define a new coordinate y measured from the static
equilibrium position rather than from natural length.
If the downward extension from natural length is
then Newton’s second law gives
Because
the constant terms cancel:
Gravity shifts the equilibrium position. Once displacement is measured from that equilibrium, the
net restoring force has the same linear form as for a horizontal spring.
10 Worked example 3: instantaneous acceleration below equilibrium
A 1.50 kg mass hangs from a vertical spring with k = 60.0 N∕m. It is momentarily located 0.0800
m below its static equilibrium position. Find its instantaneous acceleration.
Using displacement y from equilibrium,
Therefore
Thus
The weight need not be inserted again after the coordinate has been shifted to equilibrium; its
effect has already been absorbed into the equilibrium extension.
11 Spring force and static friction
A spring can gradually increase the tangential force on a body resting on a rough surface. Static
friction adjusts as needed until its maximum magnitude is reached.
For a horizontal surface,
so the limiting static friction is
If a spring pulls horizontally, impending slip occurs when
Therefore the threshold deformation is
12 Worked example 4: spring extension required to start sliding
A 4.00 kg block rests on a horizontal surface with coefficient of static friction μs = 0.350. It is
attached to a horizontal spring with k = 180 N∕m. How far must the spring be stretched before
the block is on the verge of sliding?
At impending motion,
Hence
Therefore
For smaller extensions, the static friction force is simply equal in magnitude to kx; it is not yet at
its maximum value.
13 Springs in parallel
Suppose two ideal springs with constants k1 and k2 are attached in parallel so that each
experiences the same deformation x.
Their restoring forces add:
Thus
The equivalent spring constant is
Parallel springs are stiffer than either spring alone.
14 Springs in series
For two ideal massless springs in series under a static load, the force magnitude is the same
through both springs. Let that magnitude be F. Their extensions are
The total extension is
Defining F = keqx gives
For two springs,
Series springs are less stiff than either spring alone.
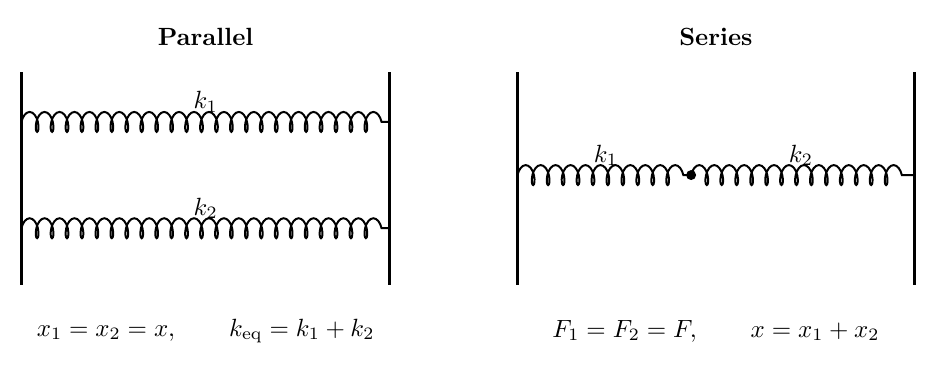
Figure 4. Parallel springs share the same deformation and their forces add. Series springs carry
the same force in the ideal static model and their deformations add.
15 Limits of the ideal spring model
Hooke’s law is a constitutive model, not a universal law valid for every deformation. Important
limitations include the following:
- The relation Fs = −kx is usually accurate only over a finite linear elastic range.
- The spring constant can depend on geometry and material.
- Real springs have mass; when their inertia matters, the force need not be identical at
every point along the spring.
- Real systems can dissipate mechanical energy through internal damping and friction.
- A coil spring may have geometric limits that prevent unlimited compression or
extension.
The ideal model is powerful because it isolates the leading linear behavior near an equilibrium
configuration.
16 Common mistakes
- Using the object’s coordinate from an arbitrary origin as though it were automatically
the spring deformation.
- Dropping the minus sign without separately tracking the force direction.
- Assuming a spring always pulls. An ideal compression spring can push when
compressed.
- Assuming static equilibrium means the spring force is zero.
- Setting static friction equal to μsN before checking whether the limiting value is
actually required.
- Adding spring constants for springs in series. Direct addition applies to the parallel
case.
17 Practice problems
Use g = 9.81 m∕s2 unless otherwise stated.
- A spring with k = 250 N∕m is stretched 0.0400 m. Find the magnitude and direction
of the spring force.
- A 3.00 kg block is attached to a horizontal spring with k = 150 N∕m. At an instant
when the spring is compressed 0.120 m, find the block’s acceleration if friction is
negligible.
- A spring requires a 24.0 N force to hold it stretched 0.0800 m from natural length.
Find k.
- A graph of Fs versus x is a straight line through the origin with slope −420 N∕m.
What is the spring constant?
- A 1.20 kg mass hangs at rest from a vertical spring with k = 75.0 N∕m. Find the
equilibrium extension.
- The mass in Problem 5 is displaced 0.0500 m downward from its static equilibrium
position. Find its instantaneous acceleration.
- A 5.00 kg block rests on a horizontal surface with μs = 0.300 and is attached to a
horizontal spring with k = 200 N∕m. Find the largest extension that can be maintained
without slipping.
- Two springs with constants 120 N∕m and 180 N∕m are connected in parallel. Find
the equivalent spring constant.
- The same two springs are connected in series. Find the equivalent spring constant.
- Two springs in series have k1 = 100 N∕m and k2 = 300 N∕m. A static force of 12.0 N
is applied. Find the extension of each spring and the total extension.
18 Answers
- 10.0 N, toward the natural-length position.
- 6.00 m∕s2 toward the natural-length position.
- 300 N∕m.
- 420 N∕m.
- 0.157 m.
- 3.13 m∕s2 upward.
- 0.0736 m.
- 300 N∕m.
- 72.0 N∕m.
- x1 = 0.120 m, x2 = 0.0400 m, total 0.160 m.
19 Summary
For an ideal linear spring,
The force is proportional to deformation and points toward the undeformed configuration. The
spring constant is the magnitude of the slope of the force-displacement graph. For a vertical
hanging mass,
When displacement is measured from that equilibrium position, gravity cancels from the net
restoring-force equation.
For simple ideal spring combinations,
and
These results provide the force-law foundation for later work on elastic potential energy and
oscillations.
References
[1] PhysicsLibrary, M02-01, Newton’s Laws of Motion.
[2] PhysicsLibrary, M02-03, Common Forces in Mechanics.
[3] PhysicsLibrary, M02-07, Friction.
[4] OpenStax, University Physics, Volume 1, sections on Newton’s laws, elastic forces,
and simple harmonic motion, CC BY 4.0.
[5] J. Moore et al., Mechanics Map, sections on springs and force models, CC BY-SA
4.0.