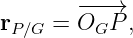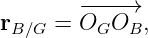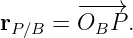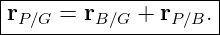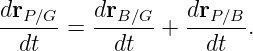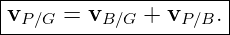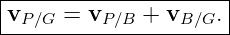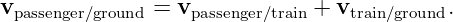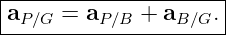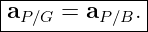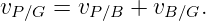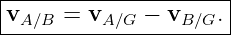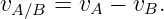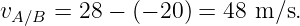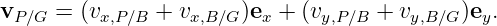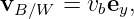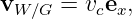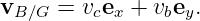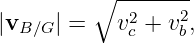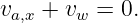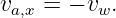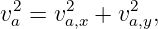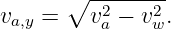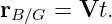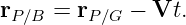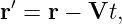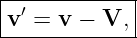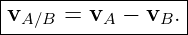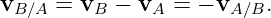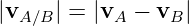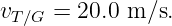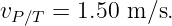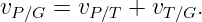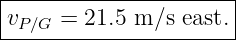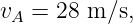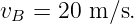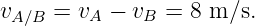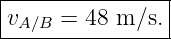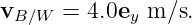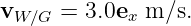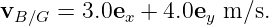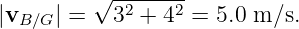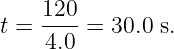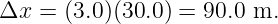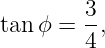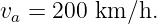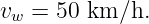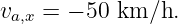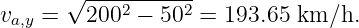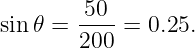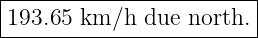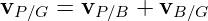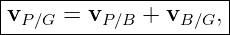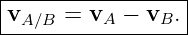Relative Motion
Motion is always described relative to a chosen observer or reference frame. A passenger can
move forward relative to a train while the train moves forward relative to the ground; a
boat can move north relative to the water while the water itself flows east relative to
the riverbank. Relative motion kinematics provides a systematic way to combine these
descriptions.
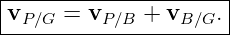
The central idea is vector addition. If object P is observed from frame B, and frame B moves
relative to frame G, then the velocity of P relative to G is
The notation P∕G means “P relative to G.” Keeping the order of the labels explicit is one of the
best ways to avoid sign errors.
1 Relative position
Let OG be the origin of frame G, let OB be the origin of a second frame B, and let P be a particle.
Define
and
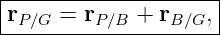
The position vectors form a head-to-tail triangle:
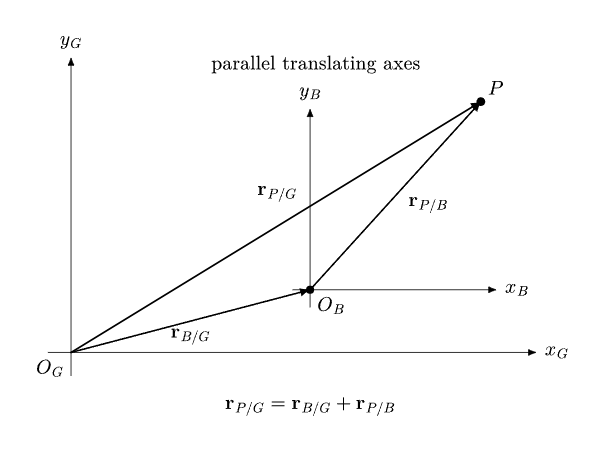
Figure 1. Relative position geometry for two translating frames with parallel axes. The position of
particle P relative to G is the vector sum of the origin displacement of frame B and the position
of P measured from B.
This relation is purely geometric. The corresponding velocity and acceleration equations follow by
differentiation.
2 Relative velocity for translating frames
Differentiate the relative position equation with respect to time. If the axes of B remain parallel to
the axes of G, so that the two frames differ only by translation, then
Therefore
Because vector addition is commutative, this is often written in the visually convenient
order
The quantities must still refer to a consistent chain of frames. For example,
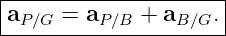
3 Relative acceleration
Differentiating again gives
If frame B moves with constant velocity relative to G, then
so
This is the Newtonian acceleration invariance used in Galilean inertial frames. It does not hold for
an accelerating origin, and additional terms appear if the axes rotate.
4 One-dimensional relative motion
In one dimension, the vector equation reduces to signed scalar addition. Suppose the positive x
direction is east. Then
The signs carry the directional information. A train moving west has negative velocity if east is
chosen positive.
For two objects A and B measured in the same frame G, the velocity of A relative to B
is
In one dimension,
If both objects move east at 28 m/s and 20 m/s, then object A moves east relative to B at 8 m/s.
If B instead moves west at 20 m/s, then vB = −20 m/s and
The familiar “closing speed” in a straight line approach is therefore just a relative velocity
calculation with a sign convention.
5 Two-dimensional relative motion
In two dimensions, the relative motion relation must be applied component by component:
A classic example is a boat crossing a river. The boat has a velocity relative to the water, the
water has a velocity relative to the ground, and the ground observer sees their vector
sum.
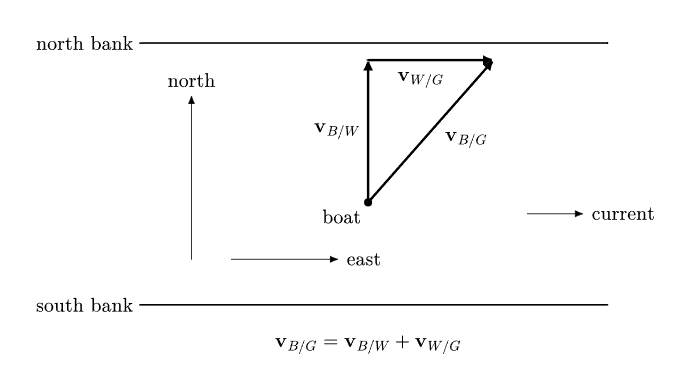
Figure 2. River crossing velocity triangle. The boat’s velocity relative to the ground is the vector
sum of its velocity relative to the water and the water’s velocity relative to the ground.
If
and the current is
then
The magnitude is
and the direction follows from the component ratio.
6 Aiming to cancel a cross flow
Sometimes the desired ground track is specified instead of the heading relative to the moving
medium. In that case, the unknown relative velocity must be chosen so that one component of the
vector sum has the required value.
For example, if an aircraft must travel due north while a wind blows east, the aircraft must point
somewhat west of north so that the westward air relative component cancels the eastward wind
component.
If the airspeed is va, the eastward wind speed is vw, and the desired east-west ground component is
zero, then
Therefore
If the aircraft’s airspeed magnitude is fixed,
so
This is the same vector addition problem as the river crossing example, but solved for a different
unknown.
7 Galilean transformation
Let frame B move at constant velocity V relative to frame G. If their origins coincide at t = 0,
then
From the relative position equation,
Using the conventional notation
we obtain the Galilean position transformation. Differentiation gives
and, for constant V,
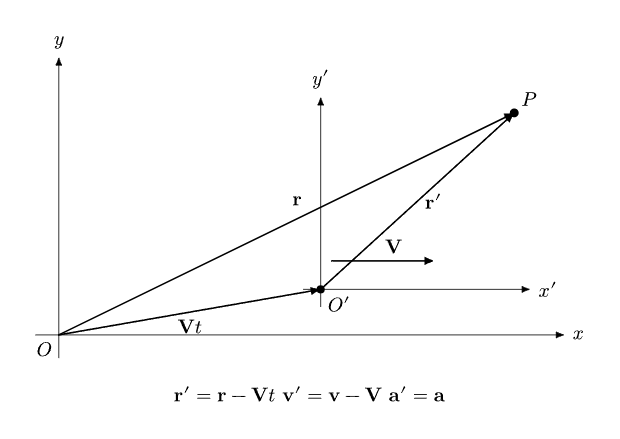
Figure 3. Two Galilean frames with parallel axes and constant relative velocity V. The moving
frame coordinates satisfy r′ = r − Vt, while velocity differs by V and acceleration is unchanged.
In Newtonian mechanics the time coordinate is also taken to be common:
At speeds comparable with the speed of light, Galilean transformations must be replaced by
Lorentz transformations; that subject belongs to special relativity rather than classical
kinematics.
8 Relative velocity between two particles
Suppose particles A and B have velocities vA and vB in the same inertial frame. The velocity of A
relative to B is
Likewise,
Thus the two relative velocities have equal magnitudes and opposite directions.
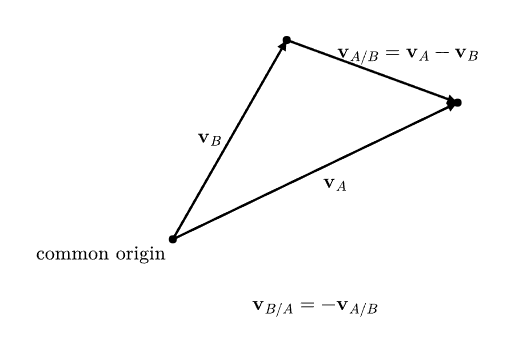
Figure 4. Relative velocity of two particles. Subtracting vB from vA gives the velocity of A as
observed from B.
The magnitude
is the instantaneous rate at which their separation vector changes in magnitude only when the
relative velocity happens to lie along the line joining them. In general, relative velocity changes
both the separation magnitude and its direction.
9 Worked example 1: walking inside a moving train
A train moves east at
A passenger walks east inside the train at
The passenger’s ground velocity is
Therefore
If the passenger instead walks west at 1.50 m/s relative to the train, then vP∕T = −1.50 m/s and
the ground speed is 18.5 m/s east.
10 Worked example 2: relative speed of two cars
Car A travels east at
while car B travels east at
The velocity of A relative to B is
Thus an observer in car B sees car A move east at
If car B reverses direction and travels west at 20 m/s, then vB = −20 m/s and
The same subtraction rule handles both cases; only the signed velocity changes.
11 Worked example 3: boat crossing a river
A river is 120 m wide. A boat is pointed straight north and moves relative to the water
at
The river current is
The boat’s ground velocity is
Its ground speed is
The northward component determines the crossing time:
During that time the eastward current produces a drift
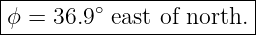
The ground track direction is
so
12 Worked example 4: aircraft correcting for a crosswind
An aircraft has airspeed
A wind blows due east at
The pilot wants the ground track to be due north. The aircraft must therefore have a westward
air-relative component of 50 km/h:
The northward component is
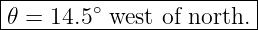
The required heading angle west of north satisfies
Thus
Because the east-west components cancel, the ground speed is
13 Limits of the simple addition law
The formula
in the form used here assumes that the two coordinate bases remain parallel. If frame B rotates
relative to G, differentiating a vector expressed in the rotating basis produces additional terms
involving the angular velocity of the frame. Those terms lead to Coriolis, centrifugal, and Euler
contributions and are treated later in non inertial frame mechanics.
The Galilean law is also a low speed approximation. At relativistic speeds, velocity addition is
governed by special relativity.
14 Practice problems
- A train moves east at 18 m/s. A passenger walks west at 2.0 m/s relative to the train.
Find the passenger’s velocity relative to the ground.
- Car A moves east at 25 m/s and car B moves east at 17 m/s. Find vA∕B and vB∕A.
- Car A moves east at 22 m/s while car B moves west at 15 m/s. Find the magnitude
and direction of vA∕B.
- A boat moves north at 5.0 m/s relative to the water while a current flows east at 2.0
m/s. Find the boat’s ground velocity magnitude and direction east of north.
- The river in Problem 4 is 150 m wide. If the boat is pointed straight north, find the
crossing time and downstream drift.
- An aircraft has airspeed 250 km/h and encounters a 60 km/h wind blowing east. What
heading west of north produces a due north ground track? What is the resulting ground
speed?
- Frame B moves at constant velocity 8ex m/s relative to frame G. A particle has velocity
(3ex + 4ey) m/s in B. Find its velocity in G.
- A particle has acceleration (2ex − 3ey) m/s2 in one inertial frame. What acceleration
is measured in another frame moving at constant velocity relative to the first?
- Two particles have velocities vA = (6ex + 2ey) m/s and vB = (1ex + 5ey) m/s. Find
vA∕B and its magnitude.
- Explain why the simple relation a′ = a is valid between Galilean inertial frames but
not between frames whose origins accelerate relative to one another.
15 Answer check
- 16 m/s east.
- vA∕B = +8 m/s east; vB∕A = −8 m/s, or 8 m/s west.
- 37 m/s east relative to B.
- |v| =
 = 5.39 m/s; ϕ = tan −1(2∕5) = 21.8∘ east of north.
- t = 30.0 s; drift = 60.0 m east.
- 𝜃 = sin −1(60∕250) = 13.9∘ west of north; ground speed =
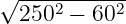 = 242.7 km/h
north.
- vP∕G = 11ex + 4ey m/s.
- The same acceleration: (2ex − 3ey) m/s2.
- vA∕B = 5ex − 3ey m/s; magnitude
 = 5.83 m/s.
- Constant relative frame velocity has zero relative acceleration, so differentiating
v′ = v−V gives a′ = a; an accelerating origin contributes a nonzero subtraction term.
16 Summary
Relative motion is vector bookkeeping tied to clearly identified observers. For translating frames
with parallel axes,
and
For two objects measured in the same frame,
When the relative frame velocity is constant, the acceleration is the same in both Galilean inertial
frames.
References
[1] S. J. Ling, J. Sanny, and W. Moebs, University Physics, Volume 1, OpenStax, 2016.
[2] University of California, Davis, Physics 9A mechanics instructional materials, relative
motion and vector kinematics.
[3] J. R. Taylor, Classical Mechanics, University Science Books, 2005.
[4] PhysicsLibrary, M00-06, Reference Frames in Newtonian Mechanics.