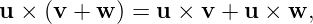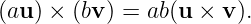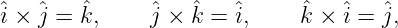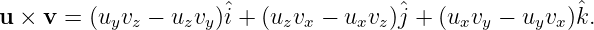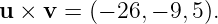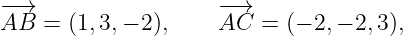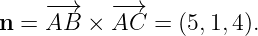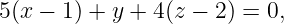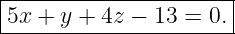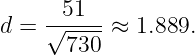cross product algebra and applications
(Example)
Cross Product Algebra and Applications
The cross product is bilinear:
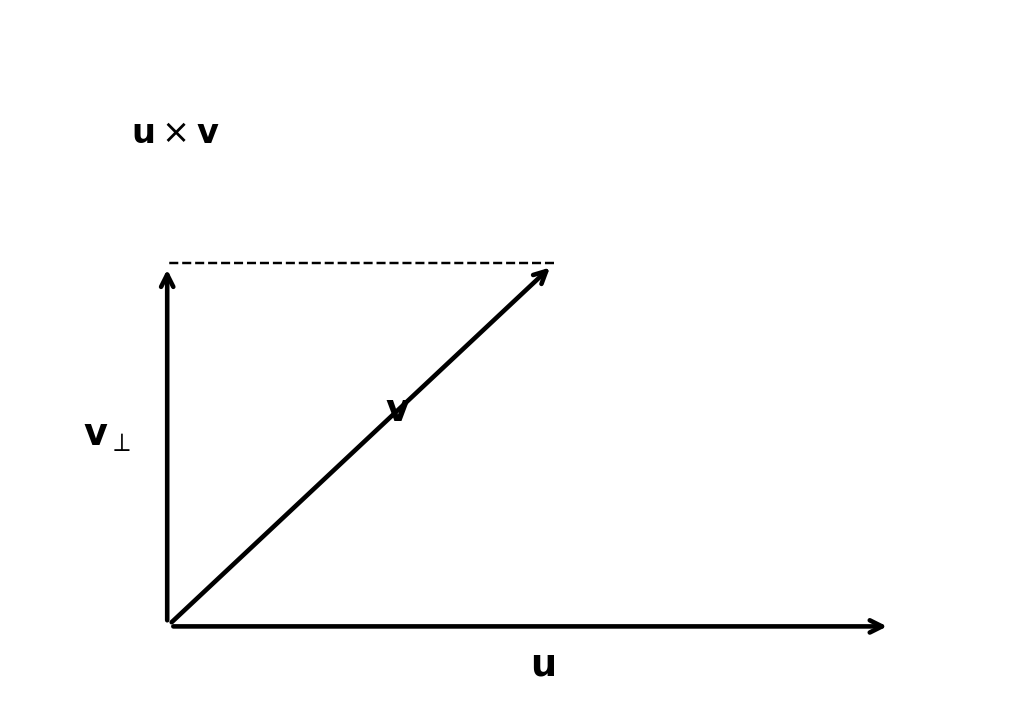
Figure 17a, modernized: geometric interpretation behind bilinearity of the cross product.
For a right-handed Cartesian basis,
with reversal of order changing the sign.
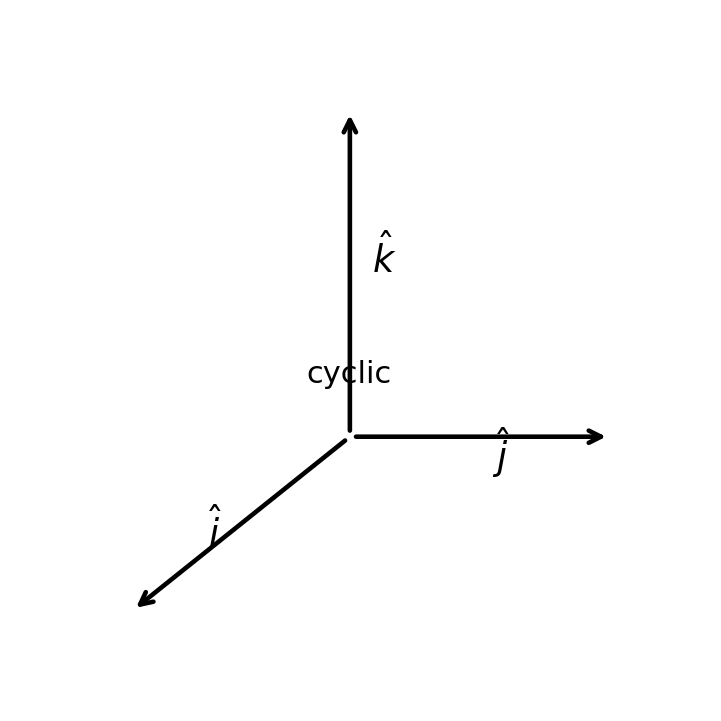
Figure 17b, modernized: cyclic order of the right-handed Cartesian basis.
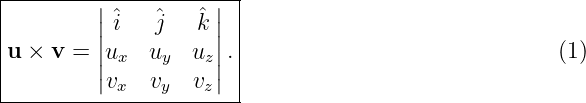
For components,
Thus
Example 1
For u = (2,−3, 5) and v = (−1, 4, 2),
The result is orthogonal to both inputs, providing a direct check.
Example 2: plane through three points
For A = (1, 0, 2), B = (2, 3, 0), C = (−1,−2, 5),
so a Normal is
Hence the plane is
or
Example 3: shortest distance between skew lines
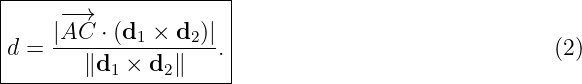
If line directions are d1,d2, then n = d1 × d2 is normal to both. For points A on the first line and
C on the second,
Brand’s numerical example uses A = (2,−3, 1), B = (1, 0,−2), C = (4, 2, 1), D = (−1,−2, 1) and
gives
Source problems
- Find the plane through A = (1, 0, 2), B = (2, 3, 0), C = (−1,−2, 5).
- Find a vector of length 39 perpendicular to (4,−3, 0) and (−4, 6, 1).
- Find the plane through A = (1, 2, 3), B = (2,−3, 4) perpendicular to 3x+2y−z+7 = 0.
- Find the plane through A = (−1, 2, 1) perpendicular to both x + 3y − 2z + 7 = 0 and
3x − 2y − 5z + 6 = 0.
- Find the shortest distance from P = (1, 1,−3) to the plane through A = (1,−1, 2),
B = (3, 2, 4), C = (6, 2,−2).
- Find the shortest distance between lines AB and CD for:
- A = (−2, 4, 3), B = (2,−8, 0), C = (1,−3, 5), D = (4, 1,−7);
- A = (2, 3, 1), B = (0,−1, 2), C = (1, 2, 5), D = (−3, 1, 0).
Modern notation references
The notation and terminology in this modernized article follow standard present-day mechanics
and vector-analysis usage, particularly:
- J. R. Taylor, Classical Mechanics, University Science Books, 2005.
- D. Kleppner and R. Kolenkow, An Introduction to Mechanics, 2nd ed., Cambridge
University Press, 2014.
- H. Goldstein, C. Poole, and J. Safko, Classical Mechanics, 3rd ed., Addison–Wesley,
2002.
Source
This article is a modernized restatement of the corresponding article in Louis Brand, Vectorial
Mechanics, John Wiley & Sons, New York, 1930, Chapter I, “Vector Algebra.” The original 1930
edition is the source basis.
"cross product algebra and applications" is owned by bloftin.(view preamble)
See Also: cross product, dot product algebra and geometric applications, dot product, vector product, centroids and weighted position vectors, Cartesian components and direction cosines, scalar component and vector projection on an Axis, vectors in space, vectors in a plane, vector subtraction and position vectors, negative of a vector, equality of vectors, vector, vector algebra, vector addition, point division and position vectors, scalar triple product, summary of vector algebra
This object's parent.
Cross-references: mechanics, vector, Normal, cross product
This is version 1 of cross product algebra and applications, born on 2026-08-21.
Object id is 1080, canonical name is CrossProductAlgebraAndApplications.
Accessed 239 times total.
Classification:
|