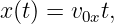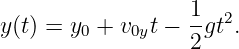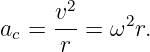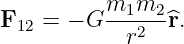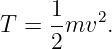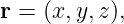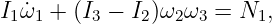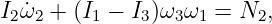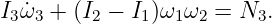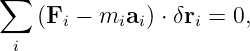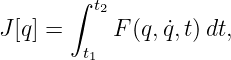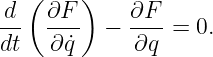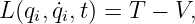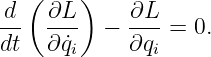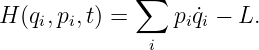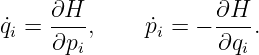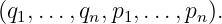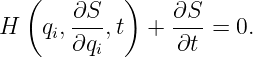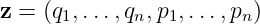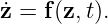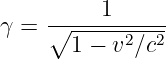History of Classical Mechanics: From Galileo to Hamilton and Beyond
Classical Mechanics did not appear all at once as a finished system. It developed through a
sequence of changes in what physicists and mathematicians considered the right questions to ask
about motion. Ancient and medieval mechanics emphasized geometry, equilibrium, and qualitative
causes. Galileo and Kepler helped make motion quantitative. Newton unified terrestrial and
celestial dynamics under mathematical laws of motion and gravitation. Euler, d’Alembert,
Lagrange, Hamilton, Jacobi, and others then transformed Newtonian mechanics into increasingly
general analytical form. Finally, nineteenth-century celestial mechanics and the work of Poincaré
exposed the nonlinear structure of dynamics and opened the route to modern dynamical-systems
theory.
This article is a historical companion to the PhysicsLibrary entry on Classical Mechanics. Its
emphasis is therefore not on re-deriving every theorem, but on showing how the central ideas
emerged, why new formulations were introduced, and how the language of mechanics changed over
time. Short excerpts from historical texts are included where they help reveal how the authors
themselves framed their work [1, 2, 5, 6, 9].
1 Before classical mechanics
The roots of mechanics are ancient. Greek mathematics developed sophisticated geometry, while
practical studies of levers, centers of gravity, hydrostatics, and machines produced results that we
would now classify as mechanics. Archimedes’ work on equilibrium and the lever was
especially important because it expressed physical balance through quantitative geometric
relations.
Ancient dynamics, however, was not organized around differential equations of motion. Aristotelian
natural philosophy treated terrestrial motion largely in terms of natural and forced tendencies.
Motion was discussed through categories of cause, medium, and natural place rather than through
a universal law relating acceleration to force.
During the medieval period, scholars developed increasingly sophisticated ideas about motion,
including forms of impetus theory. These ideas did not yet constitute Newtonian mechanics, but
they weakened the notion that continuous motion always required a continuously acting mover and
helped prepare the conceptual ground for inertia.
The transition to classical mechanics therefore involved more than discovering a new equation. It
required a new mathematical picture of motion itself.
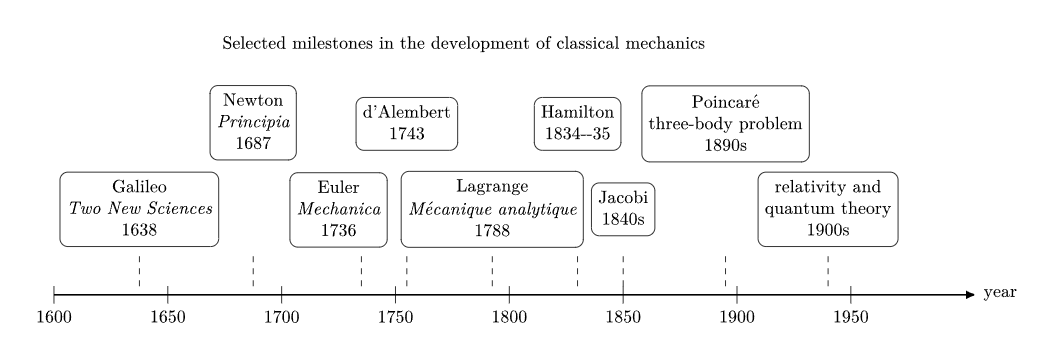
Figure 1. A selective timeline of the development of classical mechanics. The boundaries are
deliberately porous: mechanics developed through overlapping work in astronomy, mathematics,
geometry, and experiment.
2 Kepler and the mathematical description of the heavens
Johannes Kepler’s laws of planetary motion were not yet a force theory, but they transformed
celestial astronomy by replacing combinations of uniform circles with precise mathematical
relations extracted from observation. The three laws may be summarized as:
- planets move in ellipses with the Sun at one focus;
- the radius vector sweeps out equal areas in equal times;
- orbital period and semimajor axis satisfy T2 ∝ a3.
These were empirical laws of motion rather than explanations of why planets moved that way.
Their importance for mechanics is that they created a sharply defined target for a dynamical
theory. Newton would later show that an inverse-square central force explains Keplerian orbital
motion.
Kepler therefore stands at an important historical boundary: astronomical observation had become
mathematically precise enough that a universal theory of force could be tested against
it.
3 Galileo: motion becomes a mathematical science
Galileo Galilei’s work in the early seventeenth century changed the study of terrestrial motion. He
idealized away friction and resistance, emphasized measurable relations among distance, time,
velocity, and acceleration, and treated projectile motion as the composition of simpler
motions.
In Two New Sciences, Galileo described projectile motion by combining uniform horizontal motion
with vertical accelerated motion. One short passage captures the idea:
“This is the kind of motion seen in a moving projectile.” [1]
The underlying construction leads, in modern notation, to
Eliminating t produces a parabola in the ideal constant-g, no-drag approximation.
Galileo’s importance was not merely the particular formula. Several habits that became central to
classical mechanics are already visible:
- idealize the physical system;
- separate independent components of motion;
- express motion mathematically;
- test idealized laws against observation and experiment;
- distinguish uniform motion from accelerated motion.
Galileo also articulated a form of relativity for uniform motion: mechanical experiments performed
inside a uniformly moving system do not reveal that uniform translational motion. This idea later
became part of the Newtonian concept of inertial frames.
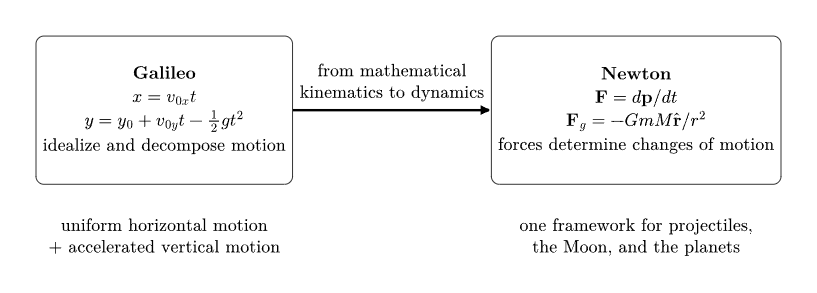
Figure 2. The conceptual shift from Galileo to Newton. Galileo decomposed motion into
mathematically simple parts; Newton supplied a general dynamical law that related changes of
motion to impressed force.
4 Descartes, Huygens, and the seventeenth-century problem of motion
The path from Galileo to Newton was not direct. René Descartes attempted to formulate broad
laws of motion and collision, while Christiaan Huygens made decisive advances in collision theory,
circular motion, pendulums, and centripetal acceleration. The seventeenth century was a period in
which the concepts of inertia, momentum, centrifugal and centripetal effects, and conservation were
still being separated from one another.
Huygens’ analysis of circular motion was particularly important for Newton’s later treatment of
orbital dynamics. For uniform circular motion,
This gave a quantitative measure of the acceleration required to continually bend an otherwise
inertial trajectory.
The emerging picture was increasingly kinematic and mathematical: straight uniform
motion required no explanation by a sustaining force, while deviations from that motion
did.
5 Newton’s synthesis
Isaac Newton’s Philosophiæ Naturalis Principia Mathematica, first published in 1687, unified
several threads that had previously been separate: inertial motion, force, terrestrial
falling bodies, projectile motion, circular motion, tides, lunar motion, and planetary
orbits.
Newton began the Principia with definitions and axioms or laws of motion. Motte’s later English
translation renders the first law in the familiar form:
“Every body perseveres in its state of rest, or of uniform motion in a right line”
unless acted upon by impressed forces. [2]
The second law was expressed in terms of change of “motion,” Newton’s quantity of motion
corresponding to momentum. In modern vector notation the general form is
For constant mass,
Newton’s third law established the reciprocal structure of interactions. Together, the laws provided
a framework in which a mechanical problem became: specify forces, initial conditions, and
constraints, then determine the resulting motion.
5.1 Universal gravitation
Newton’s law of gravitation introduced a universal inverse-square force,
The same law that described falling objects could also describe lunar and planetary motion. This
unification is one of the defining achievements of classical mechanics.
The conceptual structure can be written schematically as
force law + initial conditions → equations of motion → trajectory
5.2 Geometry rather than modern vector calculus
Newton’s own presentation was largely geometric. The familiar differential-equation form of
mechanics emerged more explicitly through eighteenth-century mathematical analysis. It is
therefore historically misleading to imagine the Principia as a modern textbook simply written
with old notation. Newton’s conceptual mechanics was foundational, but the analytical language in
which we commonly teach it was developed later.
6 Leibniz and the language of energy
Gottfried Wilhelm Leibniz developed a different mathematical and conceptual tradition alongside
Newtonian mechanics. One important quantity in the eighteenth-century debate over motion was
vis viva, proportional to mv2. In modern mechanics this is closely related to kinetic
energy,
The historical debates over momentum, “living force,” and conservation were partly disputes over
which quantity remained invariant in which type of interaction. Modern mechanics recognizes that
momentum and energy are distinct conserved quantities associated with different structures and
symmetries.
Leibniz’s development of differential calculus also contributed to the mathematical language
eventually used throughout mechanics. The Newton–Leibniz priority controversy should not
obscure the broader fact that differential and integral calculus became essential tools for
eighteenth-century dynamics.
7 Euler: mechanics becomes differential equations
Leonhard Euler was central to transforming Newtonian mechanics into a systematic analytical
discipline. His Mechanica of 1736 presented mechanics using differential equations and helped
establish the modern analytical treatment of particle dynamics.
For a particle with Cartesian coordinates,
Newton’s law becomes the system
This form now looks elementary, but historically it represented a major change: motion became a
problem in solving differential equations.
Euler also made foundational contributions to rigid-body mechanics. The Euler equations for a
rotating rigid body, expressed in principal axes, are
Classical mechanics was therefore expanding beyond point particles into rotational dynamics and
systems with many coupled degrees of freedom.
8 d’Alembert and constrained motion
Jean le Rond d’Alembert’s Traité de dynamique appeared in 1743. Its title announced an
ambitious goal: to reduce the laws of equilibrium and motion to as few principles as possible and to
provide a general principle for interacting bodies [4].
The modern form of d’Alembert’s principle is often written
for virtual displacements compatible with the constraints.
This was historically important because it converted a dynamics problem into a form resembling
statics. Constraint forces that do no virtual work can disappear from the equations, making
constrained systems much easier to formulate.
The route from Newton to d’Alembert can be summarized schematically as
Fi = miai → (Fi − miai) ⋅ δri → constraint-compatible equations.
9 Variational ideas: Maupertuis and Euler
A second eighteenth-century stream approached mechanics through extremum principles. Pierre
Louis Maupertuis promoted a principle of least action, while Euler developed the mathematical
calculus of variations needed to treat extremum problems systematically.
These ideas were not identical to the modern Hamilton principle in their original forms, but
they introduced a powerful new question: instead of asking only for the instantaneous
force at every moment, can an entire physical path be characterized by a stationary
integral?
For a functional
the stationary condition
leads to the Euler–Lagrange equation
The development of variational calculus was therefore not merely a mathematical side story. It
created the machinery through which Lagrange would reorganize mechanics.
10 Lagrange and analytical mechanics
Joseph-Louis Lagrange’s Mécanique analytique, published in 1788, represented a major change in
style and abstraction. Lagrange sought general formulas that could generate the equations
appropriate to large classes of mechanical systems.
His famous preface declares:
“On ne trouvera point de Figures dans cet Ouvrage.” [5]
That sentence—“One will find no figures in this work”—was more than a stylistic boast. Lagrange
was deliberately moving mechanics away from case-by-case geometric constructions and toward a
systematic analytical language.
For generalized coordinates qi, the Lagrangian is commonly
and the equations of motion become
The importance of generalized coordinates is difficult to overstate. Coordinates could now be
selected to fit the geometry and constraints of the problem rather than being restricted to
Cartesian components of every force.
10.1 A change in what counts as a solution method
In Newtonian mechanics, one naturally thinks in terms of forces and acceleration. In Lagrangian
mechanics, one can often bypass individual constraint forces and work directly with kinetic and
potential energies. The physical predictions are equivalent when both formulations apply, but the
organization of the problem is radically different.
This is one of the recurring themes in the history of mechanics: progress often came not from
changing the physical phenomena, but from changing the mathematical variables and structures
used to describe them.
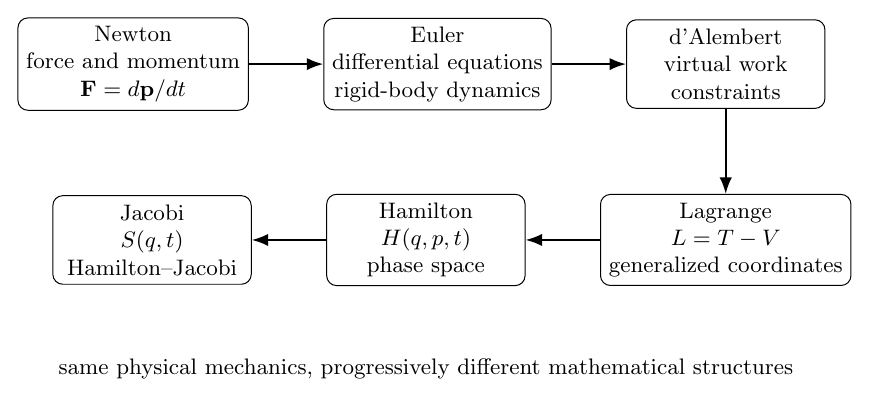
Figure 3. A conceptual genealogy of classical mechanics. Newtonian force laws remain the
physical foundation for many problems, while d’Alembert, Lagrange, Hamilton, and Jacobi
progressively reorganized dynamics around constraints, generalized coordinates, action,
momentum, and canonical structure.
11 Hamilton: dynamics in phase space
William Rowan Hamilton’s papers of 1834 and 1835 recast analytical mechanics yet again.
The title of his 1834 paper states the program directly: the motions of systems could
be
“reduced to the search and differentiation of one central relation, or characteristic
function.” [6]
The canonical momenta are
and the hamiltonian is formed by a Legendre transformation,
Hamilton’s equations are
Instead of one second-order equation for each generalized coordinate, Hamiltonian mechanics uses
two coupled first-order equations for coordinate and momentum. The natural arena becomes phase
space, with state
This formulation later became central not only to classical mechanics but also to statistical
mechanics, symplectic geometry, canonical perturbation theory, and quantum mechanics.
12 Jacobi and the Hamilton–Jacobi equation
Carl Gustav Jacob Jacobi extended Hamilton’s ideas into a powerful partial-differential-equation
formulation. Hamilton’s principal function S(qi,t) satisfies
The Hamilton–Jacobi equation makes the analogy between mechanics and geometrical optics
especially clear. Hamilton himself had been led to dynamics partly through earlier work on optical
characteristic functions.
This connection is historically significant because it foreshadowed later links among classical
mechanics, wave optics, and quantum mechanics. The action function S would reappear in the
semiclassical limit of quantum theory.
13 Celestial mechanics after Newton
Newton’s gravitational theory created an enormous mathematical program: if every body attracts
every other body, what follows for a solar system containing many mutually interacting
bodies?
Euler, Clairaut, d’Alembert, Lagrange, Laplace, Gauss, and others developed perturbation
methods to calculate deviations from simple two-body Keplerian motion. The problem of planetary
stability became a central testing ground for analytical mechanics.
For the two-body problem, the relative motion is integrable and can be reduced to an effective
one-dimensional radial problem. For three or more gravitating bodies, however, no comparable
general closed-form solution exists. This drove the development of approximation methods,
perturbation theory, canonical transformations, and qualitative dynamics.
Classical mechanics was therefore becoming not only a theory of exact trajectories but also a
theory of approximation, stability, resonance, and long-term behavior.
14 Poincaré and the qualitative study of dynamics
Henri Poincaré’s work on the three-body problem at the end of the nineteenth century changed
the character of celestial mechanics. Instead of assuming that better algebra would always yield a
closed-form orbit, Poincaré studied the geometry of trajectories in phase space, stability, periodic
orbits, and the intersections of invariant structures.
A Poincaré section replaces a continuous trajectory by the sequence of points where that
trajectory intersects a chosen lower-dimensional surface. This can reveal ordered invariant
curves, resonance islands, or irregular structures that are difficult to see directly in
q(t).
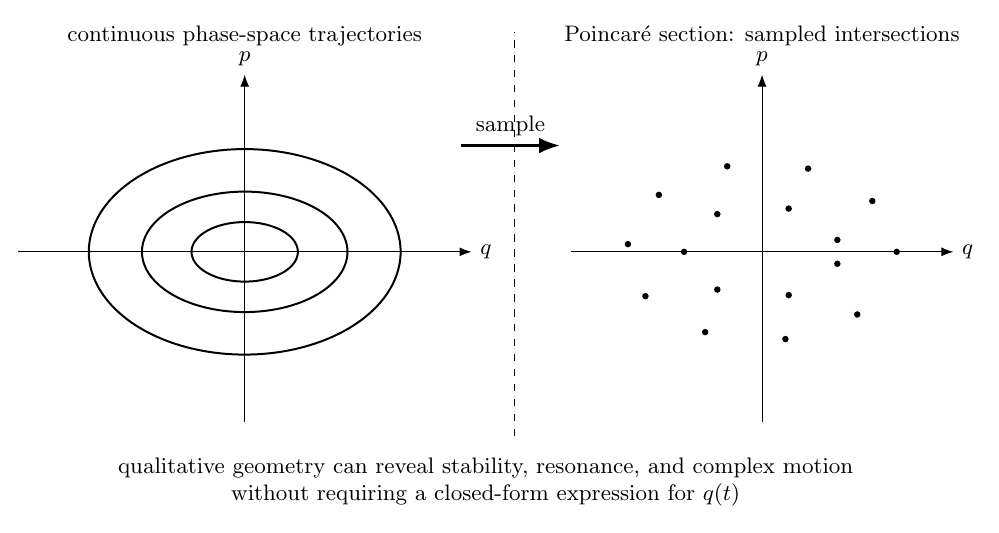
Figure 4. Schematic phase-space viewpoint. The Hamiltonian trajectory evolves continuously,
while a Poincaré section records repeated intersections and exposes qualitative structure.
By the early twentieth century Poincaré could write:
“Mechanics seem to be on the point of undergoing a complete revolution.” [9]
He was writing as relativity, electrodynamics, and new conceptions of matter were challenging
classical assumptions. Yet Poincaré’s own qualitative methods became part of the modern
classical theory of nonlinear dynamical systems and chaos.
15 From trajectories to dynamical systems
The nineteenth-century analytical formulations gradually shifted the conceptual center of
mechanics. A mechanical system was no longer viewed only as a particle following a visible
trajectory through ordinary space. It could instead be represented as a point moving through a
high-dimensional state space.
For a Hamiltonian system with n degrees of freedom,
evolves according to
This viewpoint made stability theory, phase portraits, canonical transformations, perturbation
theory, and later chaos theory natural extensions of mechanics rather than separate
subjects.
The modern language of dynamical systems owes much to this historical shift.
16 The boundaries of classical mechanics become visible
By the late nineteenth century classical mechanics was mathematically mature, but its domain of
validity was beginning to be tested by new phenomena.
16.1 Relativity
Newtonian mechanics assumes a universal time and Galilean transformation between inertial
frames. Electromagnetic theory and experiments at high speed led to special relativity,
where
replaces the low-speed approximation γ ≈ 1. Newtonian mechanics remains extraordinarily
accurate when
16.2 Quantum mechanics
Atomic and microscopic phenomena revealed limits to the classical idea of particles possessing
simultaneously definite trajectories governed solely by classical phase-space equations. Quantum
mechanics replaced that picture at sufficiently small action scales.
Importantly, neither relativity nor quantum theory made classical mechanics useless. They clarified
when it is an approximation. Classical mechanics remains the correct practical language for an
immense range of engineering, astronomy, spacecraft dynamics, robotics, structures, and
macroscopic motion.
17 A compact chronology
|
|
|
Date | Figure or work | Historical significance |
|
|
|
1638 | Galileo, Two New Sciences | acceleration and projectile motion |
1687 | Newton, Principia | laws of motion and universal gravitation |
1736 | Euler, Mechanica | differential-equation mechanics |
1743 | d’Alembert, Traité de
dynamique | constraints and virtual-work formulation |
1740s | Maupertuis and Euler | variational principles and calculus of
variations |
1788 | Lagrange, Mécanique
analytique | generalized analytical mechanics |
1834–35 | Hamilton, general method
in dynamics | canonical mechanics and characteristic
functions |
1830s | Jacobi | Hamilton–Jacobi theory |
1800s | Laplace, Gauss, others | perturbative celestial mechanics |
1890s | Poincaré | qualitative dynamics and three-body
problem |
20th c. | relativity and quantum
theory | domain of classical mechanics clarified |
|
|
|
18 How the mathematical object changed
One way to understand the history is to notice what mathematical object became central in each
stage:
- Galileo: x(t), v(t), and a(t);
- Newton: F, p, and r(t);
- Euler and d’Alembert: differential equations and constrained variations;
- Lagrange: L(q,q,t);
- Hamilton: H(q,p,t);
- Jacobi: S(q,t);
- Poincaré: phase-space geometry and qualitative structure.
The physical world did not change when the notation changed. What changed was the ability to
recognize structure, exploit constraints, generalize methods, and solve new classes of
problems.
19 Historical texts as physics lessons
Reading original mechanics texts is useful because modern notation can hide the conceptual
difficulty of ideas that now seem obvious. Galileo’s decomposition of projectile motion,
Newton’s definition of inertial motion, Lagrange’s insistence on analytical methods, and
Hamilton’s characteristic function all represent changes in what counted as an acceptable
explanation.
Several cautions help when reading primary texts:
- notation may differ radically from modern notation;
- words such as motion, force, action, and energy did not always carry their modern
technical meanings;
- modern equations are often retrospective translations of ideas originally presented
geometrically or verbally;
- historical priority can be complicated because related ideas often developed
independently or incrementally;
- later textbook formulations may be cleaner than the original theory but can obscure
how the theory developed.
Primary texts are therefore best read alongside modern explanations rather than as replacements
for them.
20 Legacy
Classical mechanics today contains several layers of history that remain simultaneously useful. A
spacecraft trajectory may be described with Newton’s force law, reformulated through a
Lagrangian, propagated with Hamiltonian methods, analyzed for stability using Poincaré
techniques, and numerically integrated on a computer. These are not disconnected subjects; they
are historical layers of one evolving theory of dynamics.
The history can be summarized as a progression in abstraction:
measured motion → force laws → differential equations → variational mechanics
→ phase space → stability and nonlinear dynamics
The remarkable feature is that the earlier layers were not discarded. Galileo’s projectile equations,
Newton’s laws, Euler’s rigid-body equations, Lagrange’s generalized coordinates, Hamilton’s
canonical variables, and Poincaré’s phase-space methods are all still active tools in modern
physics and engineering.
References
[1] G. Galilei, Dialogues Concerning Two New Sciences, translated by H. Crew and A.
de Salvio, Macmillan, 1914; original Italian edition 1638.
[2] I. Newton, The Mathematical Principles of Natural Philosophy, translated by A.
Motte, first American edition revised by N. W. Chittenden, Daniel Adee, New York,
1846; original Latin edition 1687.
[3] L. Euler, Mechanica sive motus scientia analytice exposita, St. Petersburg Academy,
1736.
[4] J. le R. d’Alembert, Traité de dynamique, Paris, 1743.
[5] J.-L. Lagrange, Mécanique analytique, Paris, 1788.
[6] W. R. Hamilton, “On a General Method in Dynamics; by which the Study of the
Motions of all free Systems of attracting or repelling Points is reduced to the Search
and Differentiation of one central Relation, or characteristic Function,” Philosophical
Transactions of the Royal Society of London, vol. 124, pp. 247–308, 1834.
[7] C. G. J. Jacobi, Vorlesungen über Dynamik, A. Clebsch, editor, Berlin, 1866; based
on Jacobi’s lectures of the 1840s.
[8] H. Poincaré, Les méthodes nouvelles de la mécanique céleste, Gauthier-Villars,
Paris, 1892–1899.
[9] H. Poincaré, Science and Method, translated by F. Maitland, Thomas Nelson and
Sons, 1914.
[10] E. T. Whittaker, A Treatise on the Analytical Dynamics of Particles and Rigid
Bodies, 2nd ed., Cambridge University Press, 1917.
[11] R. Dugas, A History of Mechanics, translated by J. R. Maddox, Routledge and
Kegan Paul, 1955.
[12] J. R. Taylor, Classical Mechanics, University Science Books, 2005.
[13] H. Goldstein, C. Poole, and J. Safko, Classical Mechanics, 3rd ed., Addison-Wesley,
2002.