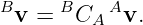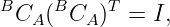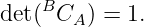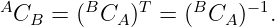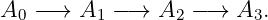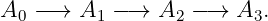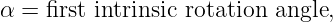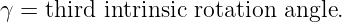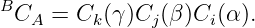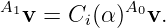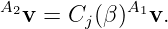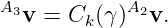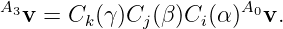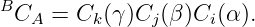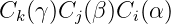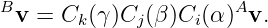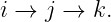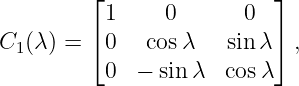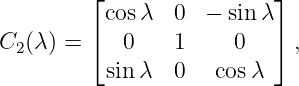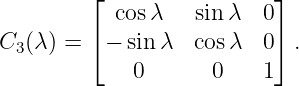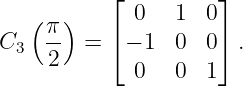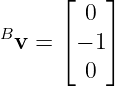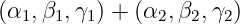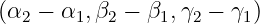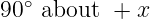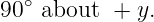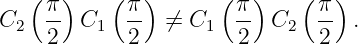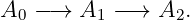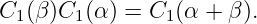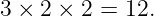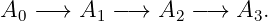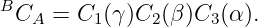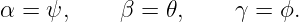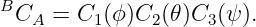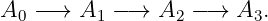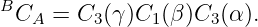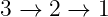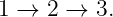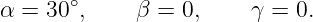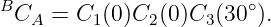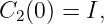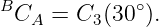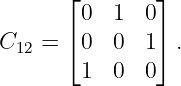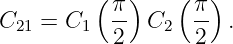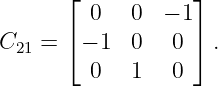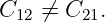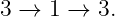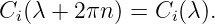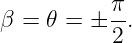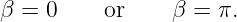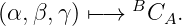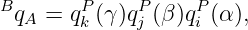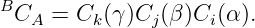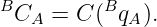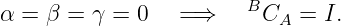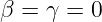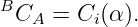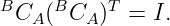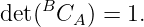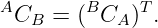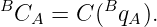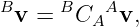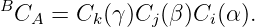Euler Angles: Definition and Basic Geometry
Euler angles describe the orientation of one three dimensional coordinate frame relative to another
by means of three successive one axis rotations.
The phrase “Euler angles” is often used loosely. In precise engineering and mathematical work,
however, an Euler angle triple is not defined by three numbers alone. Its meaning also depends
on:
- the coordinate frames being related;
- whether the rotations are intrinsic or extrinsic;
- the three rotation axes;
- the order in which the rotations occur;
- the sign convention for positive rotation;
- whether the matrices act actively on physical vectors or passively on coordinate
representations.
This article develops the geometry behind Euler angles before specializing to individual sequences
such as 3-2-1 yaw pitch roll or 3-1-3 proper Euler angles.
The PhysicsLibrary convention is passive and intrinsic.
1 Orientation of two coordinate frames
Let A and B be right handed orthonormal frames.
A physical vector v may be represented by coordinate columns
and
The passive direction cosine matrix from frame A coordinates to frame B coordinates is defined
by
The matrix
therefore describes the orientation of frame B relative to frame A while mapping coordinate
descriptions from A into B.
Because both frames are orthonormal,
and
Thus
The two matrices represent opposite coordinate map directions for the same relative physical
orientation.
2 The basic Euler construction
An Euler angle construction introduces two intermediate frames between the initial and final
frames.
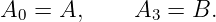
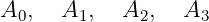
Let
The sequence is
Each arrow represents one rotation about one coordinate axis.
For a generic intrinsic sequence i-j-k,
The first step is a rotation through α about axis i of A0. The second is a rotation through β about
axis j of the moving frame A1. The third is a rotation through γ about axis k of the moving frame
A2.
The three angles are therefore:
and
The intermediate frames are not optional bookkeeping devices. They are part of the geometric
meaning of an intrinsic Euler sequence.
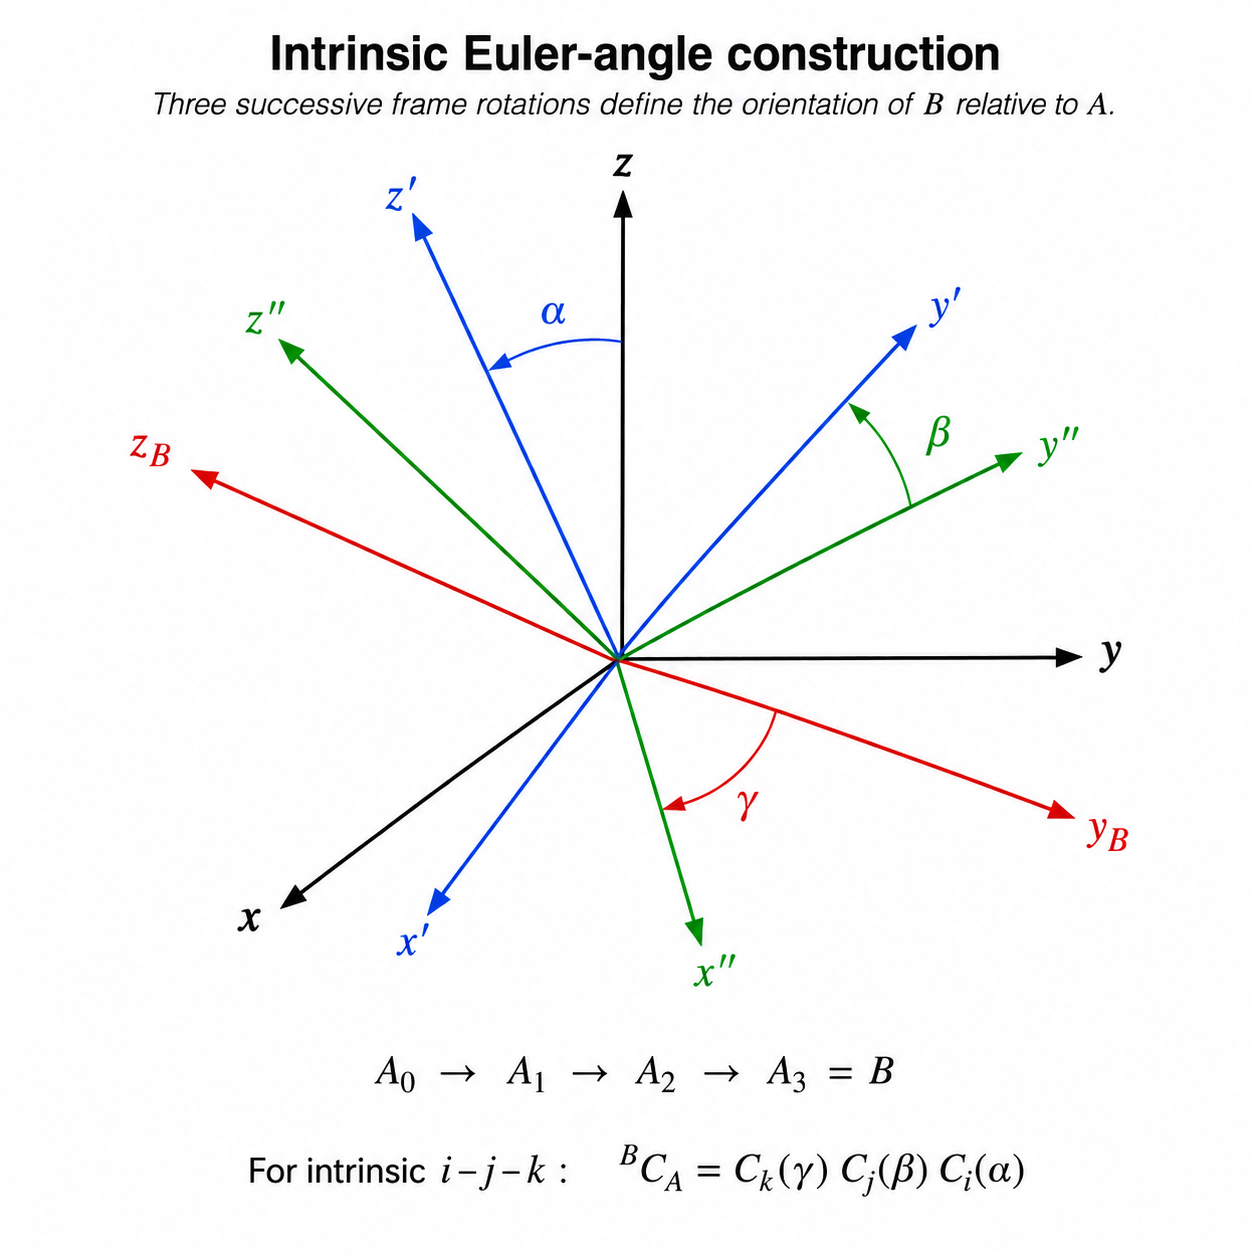
Figure. Intrinsic Euler angle construction. Frame A0 = A is rotated through three
successive intrinsic rotations to produce A1, then A2, and finally A3 = B. The angles α, β,
and γ are applied in that chronological order, while the passive coordinate transformation
is written as
The second and third rotations are taken about axes of the intermediate moving frames,
which is why intrinsic Euler angles are sequence dependent and should not be treated as
components of an ordinary vector.
3 Intrinsic means moving axis
In an intrinsic sequence, each rotation after the first is performed about an axis of the frame
produced by the previous rotation.
For intrinsic i-j-k:
- rotate frame A0 through α about axis i of A0;
- rotate the resulting frame A1 through β about axis j of A1;
- rotate the resulting frame A2 through γ about axis k of A2.
The second and third axes have therefore generally moved in physical space.
This is the reason finite Euler angle rotations cannot be interpreted as three independent rotations
about the original frame axes.
4 Passive coordinate maps for the intermediate frames
Let
be the passive elementary coordinate transformation associated with the first intrinsic frame
rotation.
Then
The second step is
The third step is
Substitute successively:
Since
and
the complete intrinsic Euler coordinate transformation is
This is the central composition rule for the PhysicsLibrary Euler angle series.
5 Why the rightmost matrix acts first
The product
is sometimes misread as though the k rotation happened first.
That is not what the matrix equation means.
Coordinate columns are multiplied from the left:
The first operation applied to the column is therefore
The chronological intrinsic sequence is still
The matrix product writes the composed maps in the usual function composition order.
6 Elementary passive frame rotations
For completeness, the three elementary passive transformations are
and
Each matrix describes the change in coordinates caused by a positive rotation of the coordinate
frame.
For example,
Thus a fixed physical vector having coordinates
has coordinates
after the frame is rotated positively by 90∘ about +z.
7 Euler angles are not components of a vector
An Euler angle triple is often written as
This notation resembles a vector, but its geometric meaning is completely different.
In general,
does not represent the composition of two orientations.
Likewise,
is not generally the exact relative orientation between two finite Euler attitudes.
The reason is that the meaning of the second and third Euler angles depends on the intermediate
moving frames.
Euler angles are nonlinear coordinates on the orientation manifold, not components of an ordinary
geometric vector.
8 Noncommutativity appears immediately
Consider two positive frame rotations:
and
The corresponding passive matrices are
and
In general,
Thus changing the sequence changes the final orientation.
This is not a numerical artifact. Noncommutativity is a fundamental property of finite rotations in
three dimensions.
9 Why three rotations are used
The orientation of one rigid orthonormal frame relative to another has three independent degrees
of freedom.
Euler angles provide three scalar coordinates for those three degrees of freedom.
The construction uses three successive rotations because two rotations are not sufficient to
generate every possible orientation, while three properly chosen rotations are sufficient
locally.
The use of three parameters is minimal.
A direction cosine matrix uses nine stored numbers subject to six independent orthonormality
constraints.
A unit quaternion uses four stored numbers subject to one unit norm constraint.
Euler angles use exactly three scalar coordinates, but that minimality requires coordinate
singularities somewhere in the representation.
10 Why adjacent axes cannot repeat
Suppose two consecutive intrinsic rotations are both about the same current axis.
For example,
Here both consecutive steps are rotations about the current axis 1, with angles α and β
respectively.
Because the first rotation leaves its own rotation axis unchanged in the current frame, the second
rotation is about the same physical axis.
The two rotations combine:
Thus two adjacent rotations about the same axis do not provide two independent orientation
coordinates.
A valid standard three angle sequence therefore requires
and
The first and third axes may either differ or coincide.
11 Why there are twelve standard sequences
There are three choices for the first axis.
Once the first axis is chosen, there are two choices for the second axis because the second axis must
differ from the first.
For the third axis, there are two admissible choices:
- use the remaining third axis;
- return to the first axis.
Therefore the number of standard sequences is
These divide naturally into two families.
12 Tait Bryan sequences
A Tait Bryan sequence uses three distinct axes.
The six intrinsic Tait Bryan sequences are
Because all three axes differ, these are also called Cardan sequences in some literature.
Aerospace yaw pitch roll is normally represented by the intrinsic 3-2-1 Tait Bryan sequence.
13 Proper Euler sequences
A proper Euler sequence returns to the first axis on the third rotation.
The six intrinsic proper Euler sequences are
These sequences are common in classical rigid body mechanics, orbital orientation, and historical
treatments of Euler’s rotational coordinates.
14 A generic Tait Bryan example
Consider intrinsic 3-2-1.
The frame chain is
The three intrinsic rotations are α about axis 3 of A0, then β about axis 2 of A1, then γ about axis
1 of A2.
The passive coordinate transformation is
In aerospace notation,
Therefore
This is the standard PhysicsLibrary yaw pitch roll specialization.
15 A generic proper Euler example
Consider intrinsic 3-1-3.
The frame chain is
The three intrinsic rotations are α about axis 3 of A0, then β about axis 1 of A1, then γ about axis
3 of A2.
The passive transformation is
Although the first and third axis labels are both 3, they refer to axis 3 of different intermediate
frames.
That moving axis distinction is essential.
16 Intrinsic and extrinsic are related but not identical descriptions
An intrinsic sequence uses moving axes.
An extrinsic sequence uses axes fixed in the original reference frame.
A given physical orientation can often be described either way.
An intrinsic i-j-k sequence can be reinterpreted as a corresponding extrinsic sequence with reverse
axis order, provided the angle association is handled consistently.
For example, an intrinsic
description corresponds to a fixed axis description involving
This equivalence does not mean the words “intrinsic” and “extrinsic” may be omitted. They
describe different geometric constructions that happen to produce the same final orientation under
the corresponding reversal rule.
17 Active and passive are independent of intrinsic and extrinsic
The distinction between intrinsic and extrinsic concerns which axes are used.
The distinction between active and passive concerns what is being rotated.
An active transformation rotates a physical vector while holding the coordinate frame
fixed.
A passive transformation rotates the coordinate frame while holding the physical vector
fixed.
These are independent choices.
The PhysicsLibrary Euler series uses passive coordinate transformations and intrinsic moving axis
sequence names.
18 Worked example 1: a single intrinsic rotation
Suppose the sequence is intrinsic 3-2-1, but only the first angle is nonzero:
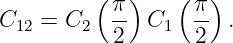
Then
Since
and
the complete transformation reduces to
Thus the generic sequence correctly reduces to the expected single elementary frame
rotation.
19 Worked example 2: two sequences with the same angles
Compare
with
using positive 90∘ angles.
For the first chronological order,
Using the elementary matrices,
For the reversed chronological order,
This gives
Therefore
The same two angle magnitudes give different final orientations when the sequence is
changed.
20 Worked example 3: why the first and third axes may repeat
Consider the proper Euler sequence
At first glance it may appear that the first and third rotations are about the same axis and could
be combined.
That is generally false.
The first rotation is about axis 3 of frame A0.
The third rotation is about axis 3 of frame A2.
After the intermediate rotation about axis 1 of A1, axis 3 of A2 is generally not aligned with axis 3
of A0.
Therefore the first and third rotations are generally about different physical directions even though
the sequence labels both axes with the number 3.
This is exactly why proper Euler sequences remain three parameter representations.
21 Nonuniqueness of Euler angle coordinates
A given physical orientation may have multiple Euler angle descriptions.
The simplest source of nonuniqueness is periodicity.
For any integer n,
Thus adding full turns to sequence angles can leave the final orientation unchanged.
More subtle alternate branches occur when extracting angles from a DCM.
At singular configurations, the first and third Euler angles may no longer be independently
identifiable.
Therefore Euler angles require declared principal ranges when used as a unique coordinate
output.
22 Coordinate singularities
Minimal three parameter orientation coordinates cannot cover all of three dimensional orientation
space with one globally nonsingular chart.
For a Tait Bryan sequence, the middle angle becomes singular when the first and third axes align
after the middle rotation.
The generic condition is
For 3-2-1,
For a proper Euler sequence, the singularity occurs when
On the usual principal interval,
The physical orientation is not singular at these configurations.
Only the Euler coordinate chart is singular.
23 Euler angles and the orientation manifold
The set of all proper three dimensional rotations is the rotation group
Euler angles provide local coordinates on SO(3).
A local coordinate map may be written schematically as
The map is smooth away from singular configurations.
At a gimbal lock configuration, the local coordinate Jacobian loses rank.
This geometric viewpoint explains several practical facts at once:
- Euler angles are not vectors;
- finite angle differences are not exact relative rotations;
- coordinate singularities are unavoidable;
- several triples may represent the same orientation;
- alternative attitude representations can remain regular when a chosen Euler chart
becomes singular.
24 Relationship to the quaternion series
The migrated PhysicsLibrary quaternion series uses the same passive frame map direction.
For intrinsic i-j-k,
while
The representations are connected by
This agreement is a useful convention check.
Euler angles supply a minimal human interpretable coordinate chart.
A unit quaternion supplies a four component nonsingular attitude representation subject to a unit
norm constraint.
Neither representation changes the underlying physical orientation.
25 What Euler angles are good for
Euler angles are especially useful when:
- the orientation naturally has physically meaningful yaw, pitch, and roll coordinates;
- the system remains well away from the sequence singularity;
- human readability is important;
- limits are naturally expressed in angular coordinates;
- initial or final boundary conditions are specified in a particular sequence;
- visualization or operator displays require intuitive attitude angles.
26 When another representation may be preferable
A DCM or quaternion may be preferable when:
- the motion can pass through an Euler singularity;
- the attitude must be propagated numerically for long intervals;
- angular velocity measurements drive the attitude state;
- repeated composition is central;
- derivatives and optimization must remain smooth over large orientation ranges;
- a global orientation representation is required.
Euler angles are still useful in such systems as display coordinates even when the internal state is
represented by a quaternion or DCM.
27 Common conceptual mistakes
- Treating (α,β,γ) as a geometric vector.
- Forgetting that the second and third intrinsic axes move.
- Reading the matrix product from left to right as chronological order.
- Assuming a 3-2-1 sequence is automatically yaw pitch roll without declaring intrinsic
or extrinsic.
- Using ϕ,𝜃,ψ as generic first, second, and third angles while also calling them roll, pitch,
and yaw.
- Assuming active versus passive is determined by whether a sequence is intrinsic or
extrinsic.
- Assuming the first and third axes of a proper Euler sequence are the same physical
axis.
- Subtracting two finite Euler triples to obtain an exact relative orientation.
- Ignoring alternate angle branches.
- Treating gimbal lock as a physical loss of orientation rather than a coordinate
singularity.
28 Checks every Euler sequence should satisfy
Any derived sequence formula should pass the following tests.
Identity
Single angle reductions
For example,
must give
Likewise for the second and third rotations.
Orthogonality
Proper determinant
Reverse map
Quaternion agreement
These checks catch many sign and sequence mistakes before a formula is used in software.
29 Summary
Euler angles describe orientation through three ordered one axis frame rotations.
In the PhysicsLibrary convention:
and intrinsic i-j-k means
The intermediate frames
are part of the definition.
There are twelve standard sequences:
- six Tait Bryan sequences with three distinct axes;
- six proper Euler sequences with first and third axes equal by label.
Euler angles are minimal and interpretable, but they are nonlinear local coordinates rather than
vector components. Their sequence dependence, noncommutativity, nonuniqueness, and
singularities are fundamental geometric features, not implementation defects.
The next article in the series, Elementary Axis Rotations and Passive Rotation Matrices, derives
the three elementary matrices used throughout all twelve Euler sequences.
30 References and further reading
Henderson provides a classic engineering tabulation of Euler sequences, quaternions, and
transformation matrices.
Diebel presents a modern unified treatment of attitude representations.
Moore develops frame orientation from basis vectors and direction cosine matrices in a form
especially useful for passive coordinate transformations.
Goldstein, Poole, and Safko provide the classical mechanics context for proper Euler angles and
rigid body orientation.
References
[1] D. M. Henderson, Euler Angles, Quaternions, and Transformation Matrices: Working
Relationships, JSC-12960, NASA Johnson Space Center, 1977. NASA Technical Reports
Server
[2] J. Diebel, “Representing Attitude: Euler Angles, Unit Quaternions, and Rotation
Vectors,” Stanford University, 2006. Online PDF
[3] J. K. Moore, Learn Multibody Dynamics, chapter “Orientation of Reference Frames,”
2026 edition. Licensed CC BY 4.0. Orientation of Reference Frames
[4] H. Goldstein, C. Poole, and J. Safko, Classical Mechanics, 3rd ed., Addison Wesley,
2002. Publisher search
License
Unless otherwise noted, this PhysicsLibrary entry is intended for release under the Creative
Commons Attribution ShareAlike 4.0 International license.