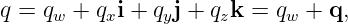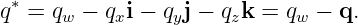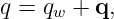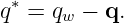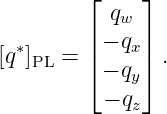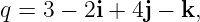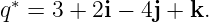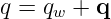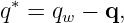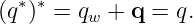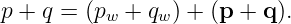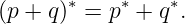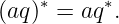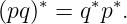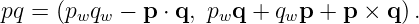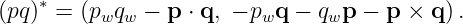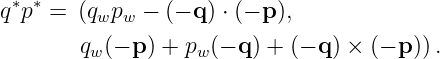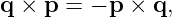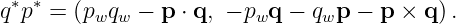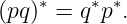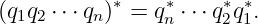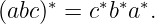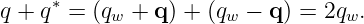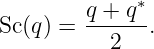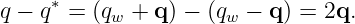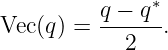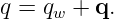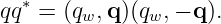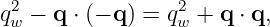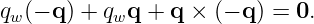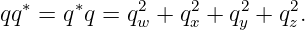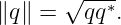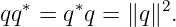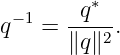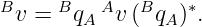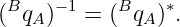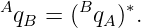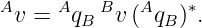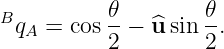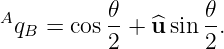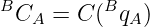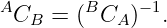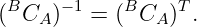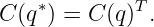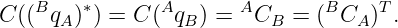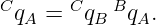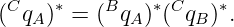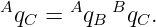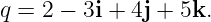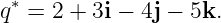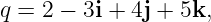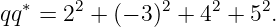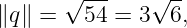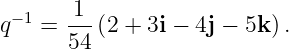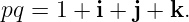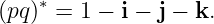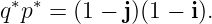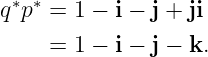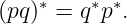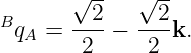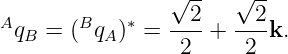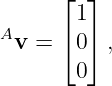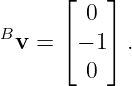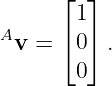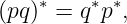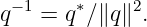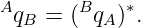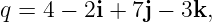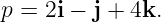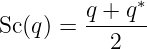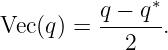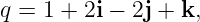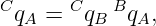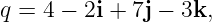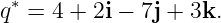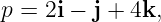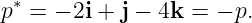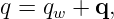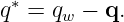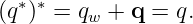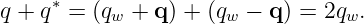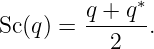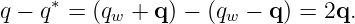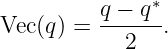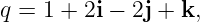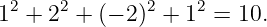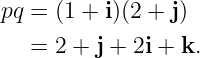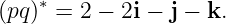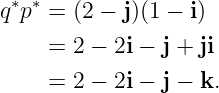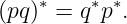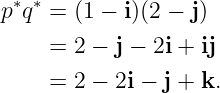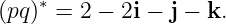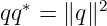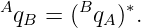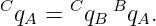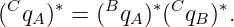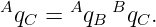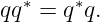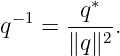Quaternion Conjugate
Quaternion conjugation reverses the sign of the vector part of a quaternion while leaving the scalar
part unchanged. If
then the quaternion conjugate is
Conjugation is one of the central operations in quaternion algebra. It separates scalar and vector
parts, produces a real quantity when a quaternion is multiplied by its conjugate, reverses the
order of a product, and becomes the multiplicative inverse when the quaternion has unit
norm.
In the later PhysicsLibrary attitude articles, unit quaternions represent passive coordinate
transformations. Under that convention, conjugation has a direct frame meaning: it reverses the
direction of the coordinate map.
1 Definition
For
define
In scalar first component form,
Thus conjugation changes the sign of the three imaginary coefficients and leaves the real coefficient
unchanged.
The notation q∗ is used throughout the PhysicsLibrary quaternion series. Other sources may use q,
q†, or another symbol. A dagger is also widely used for conjugate transpose of matrices, so an
unfamiliar source should always be checked before importing formulas.
2 Basic examples
If
then
If q is real,
then
If q is pure,
then
The real quaternions are therefore exactly the quaternions fixed by conjugation, while pure
quaternions reverse sign.
3 Conjugation is an involution
Applying conjugation twice returns the original quaternion:
Indeed,
gives
and a second conjugation gives
An operation that is its own inverse is called an involution.
4 Conjugation and addition
Let
Then
Conjugating gives
Similarly, for a real scalar a,
Thus conjugation is linear over real scalars.
5 Conjugation reverses the order of multiplication
The most important structural identity is
The factor order reverses. This is essential because quaternion multiplication is not
commutative.
To derive the result, write
The Hamilton scalar vector product is
Conjugating this product changes the sign of its vector part:
Now
Their product is
Because the dot product is symmetric and
this becomes exactly
Therefore
Conjugation is consequently an anti homomorphism of quaternion multiplication: it preserves
multiplication only after reversing factor order.
6 Conjugating a product of many factors
Repeated use of equation (10) gives
Every factor is conjugated and the entire order is reversed.
For three factors,
This identity becomes especially useful in frame composition and in simplifying quaternion
coordinate transformation expressions.
7 Scalar and vector parts from conjugation
Conjugation gives convenient formulas for extracting the scalar and vector parts of a
quaternion.
Add q and q∗:
Therefore
Subtract:
Therefore
These formulas characterize the decomposition of a quaternion into parts that are unchanged and
sign reversed by conjugation.
8 Product with the conjugate
Let
Using the scalar vector product,
The scalar part is
and the vector part is
Hence
The result is always a nonnegative real number.
This identity is the basis for the quaternion norm. It also leads directly to the inverse of every
nonzero quaternion.
9 Relation to norm and inverse
The quaternion norm is defined by
Therefore
If q≠0, divide by ∥q∥2 to obtain
For a unit quaternion,
so
This special case is fundamental in attitude mechanics because orientation quaternions are
maintained at unit norm.
10 Conjugation of a passive frame quaternion
The algebraic operation above does not depend on any rotation convention. Its physical
interpretation does.
PhysicsLibrary uses a unit quaternion
to map coordinates from frame A into frame B:
Because the quaternion is unit,
Therefore the inverse coordinate map is
It follows that
Conjugating a unit frame quaternion therefore reverses the map direction:
becomes
This is the quaternion counterpart of transposing a passive direction cosine matrix.
11 Passive axis angle interpretation
Suppose frame B is obtained from frame A by a positive right hand rule frame rotation through
angle 𝜃 about unit axis u. Under the PhysicsLibrary passive convention,
Conjugation gives
Thus conjugation reverses the passive frame transformation. The same numerical quaternion on
the right side of equation (23) is also the familiar positive active rotor for the corresponding
physical vector rotation in a fixed frame.
This distinction is why a sign change in the vector part must not be described without also stating
the intended frame map.
12 Relationship to direction cosine matrices
Let
be the passive direction cosine matrix corresponding to the unit quaternion Bq
A.
The inverse frame map satisfies
Since a direction cosine matrix is orthogonal,
Quaternion conjugation gives the same result:
Thus, for unit frame quaternions,
This provides a useful implementation check between quaternion and matrix orientation
code.
13 Conjugation and frame composition
Suppose
maps A coordinates into B, and
maps B coordinates into C.
The direct passive frame map is
Conjugate both sides:
Using the inverse frame labels,
The reversed product order produced by conjugation is exactly what is required when the entire
frame chain is traversed in the opposite direction.
14 Worked example 1: numerical conjugate
Let
Then
Applying conjugation again returns
15 Worked example 2: product with the conjugate
For
equation (15) gives
Therefore
The result is purely real.
The norm is consequently
and the inverse is
16 Worked example 3: order reversal
Let
First,
Therefore
Now compute the reversed conjugate product:
Expanding,
Hence
If one incorrectly used p∗q∗, the sign of the k term would be wrong.
17 Worked example 4: reversing a passive frame rotation
Let frame B be obtained from frame A by a positive 90∘ rotation about +z. The PhysicsLibrary
passive quaternion is
Its conjugate is
The first quaternion maps coordinate components from A to B. The conjugate maps them from B
back to A.
If a fixed physical vector has
then the positive frame rotation produces
Applying the conjugate frame map returns
18 Common pitfalls
- Changing the scalar part. Quaternion conjugation leaves qw unchanged and reverses
only the vector part.
- Forgetting product order reversal. The correct identity is
not p∗q∗.
- Assuming q∗ = q−1 for every quaternion. This is true only for unit quaternions.
In general,
- Confusing quaternion conjugation with component storage order. Scalar first
versus scalar last storage does not change the definition of the conjugate.
- Confusing quaternion conjugation with complex conjugation of a matrix.
The operations are related in some representations but are not the same object.
- Conjugating a passive frame quaternion without reversing its frame
meaning. For unit frame quaternions,
- Changing Hamilton multiplication because the attitude interpretation is
passive. Conjugation and passive frame interpretation do not change the Hamilton
product.
19 Exercises
The exercises are stated first so the article can be used for self study. Complete solutions follow
afterward.
- Direct conjugation. For
find q∗.
- Pure and real cases. Find the conjugate of
and of
- Double conjugation. Prove directly that
- Scalar and vector extraction. Starting from q = qw + q, derive
and
- Product with the conjugate. For
compute qq∗.
- Order reversal. Let
Compute (pq)∗ and q∗p∗ and verify that they agree.
- Incorrect order. For the same p and q, compute p∗q∗ and show that it differs from
(pq)∗.
- Unit quaternion inverse. If ∥q∥ = 1, prove that q∗ = q−1.
- Passive frame inverse. If Bq
A is a unit quaternion mapping A coordinates into B,
write the quaternion that maps B coordinates back into A.
- Frame chain reversal. Given
conjugate the equation and derive the inverse frame chain.
20 Solutions
1. Direct conjugation
Starting from
reverse all three imaginary coefficients:
2. Pure and real cases
A real quaternion is unchanged:
For the pure quaternion
the conjugate is
3. Double conjugation
If
then
Conjugating again gives
4. Scalar and vector extraction
Add:
Therefore
Subtract:
Therefore
5. Product with the conjugate
For
the squared norm is
Hence
6. Order reversal
First,
Thus
Now
Then
Therefore
7. Incorrect order
Compute
This differs from
The factor order must reverse.
8. Unit quaternion inverse
From
and ∥q∥ = 1,
Similarly,
Therefore q∗ is both the left and right inverse of q:
9. Passive frame inverse
The inverse coordinate map is represented by the conjugate:
10. Frame chain reversal
Begin with
Conjugating gives
Relabeling each conjugate as the inverse frame map,
Thus the conjugated chain traverses the same sequence of frames in the reverse direction.
21 What comes next
Quaternion conjugation immediately produces the real quantity
The next PhysicsLibrary article develops the quaternion norm from this identity and proves its
important multiplicative properties. The following inverse article then uses conjugation and norm
together to obtain
Later orientation articles use the unit quaternion specialization q−1 = q∗ to reverse passive frame
transformations, invert direction cosine matrices, and derive coordinate transformation and
attitude kinematic formulas.
22 Sources and historical notes
Quaternion conjugation appears naturally in Hamilton’s algebra and in later quaternion texts
under several historical notations. Modern engineering notation often writes q∗ or q and interprets
conjugation as reversing the vector part.
Hamilton’s Elements of Quaternions and Joly’s A Manual of Quaternions provide public domain
historical treatments. The modern PhysicsLibrary presentation emphasizes the anti order property,
the relationship to norm and inverse, and the passive frame interpretation needed in mechanics and
navigation.
References
[1] W. R. Hamilton, Elements of Quaternions, 2nd ed., edited by C. J. Joly, Longmans,
Green, and Co., 1899. Public domain historical source. Internet Archive scan
[2] C. J. Joly, A Manual of Quaternions, Macmillan and Co., London, 1905. Public
domain historical source. Internet Archive scan
[3] A. S. Hathaway, A Primer of Quaternions, 1896. Public domain historical source.
Project Gutenberg edition
[4] Wikibooks contributors, “Abstract Algebra/Quaternions.” Openly licensed
instructional source. Wikibooks quaternion article
License
Unless otherwise noted, this PhysicsLibrary entry is intended for release under the Creative
Commons Attribution ShareAlike 4.0 International license.