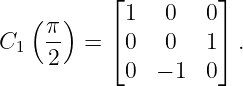|
|
|
|||||||
The elementary passive matrices are
and
For a generic intrinsic i-j-k Euler sequence,
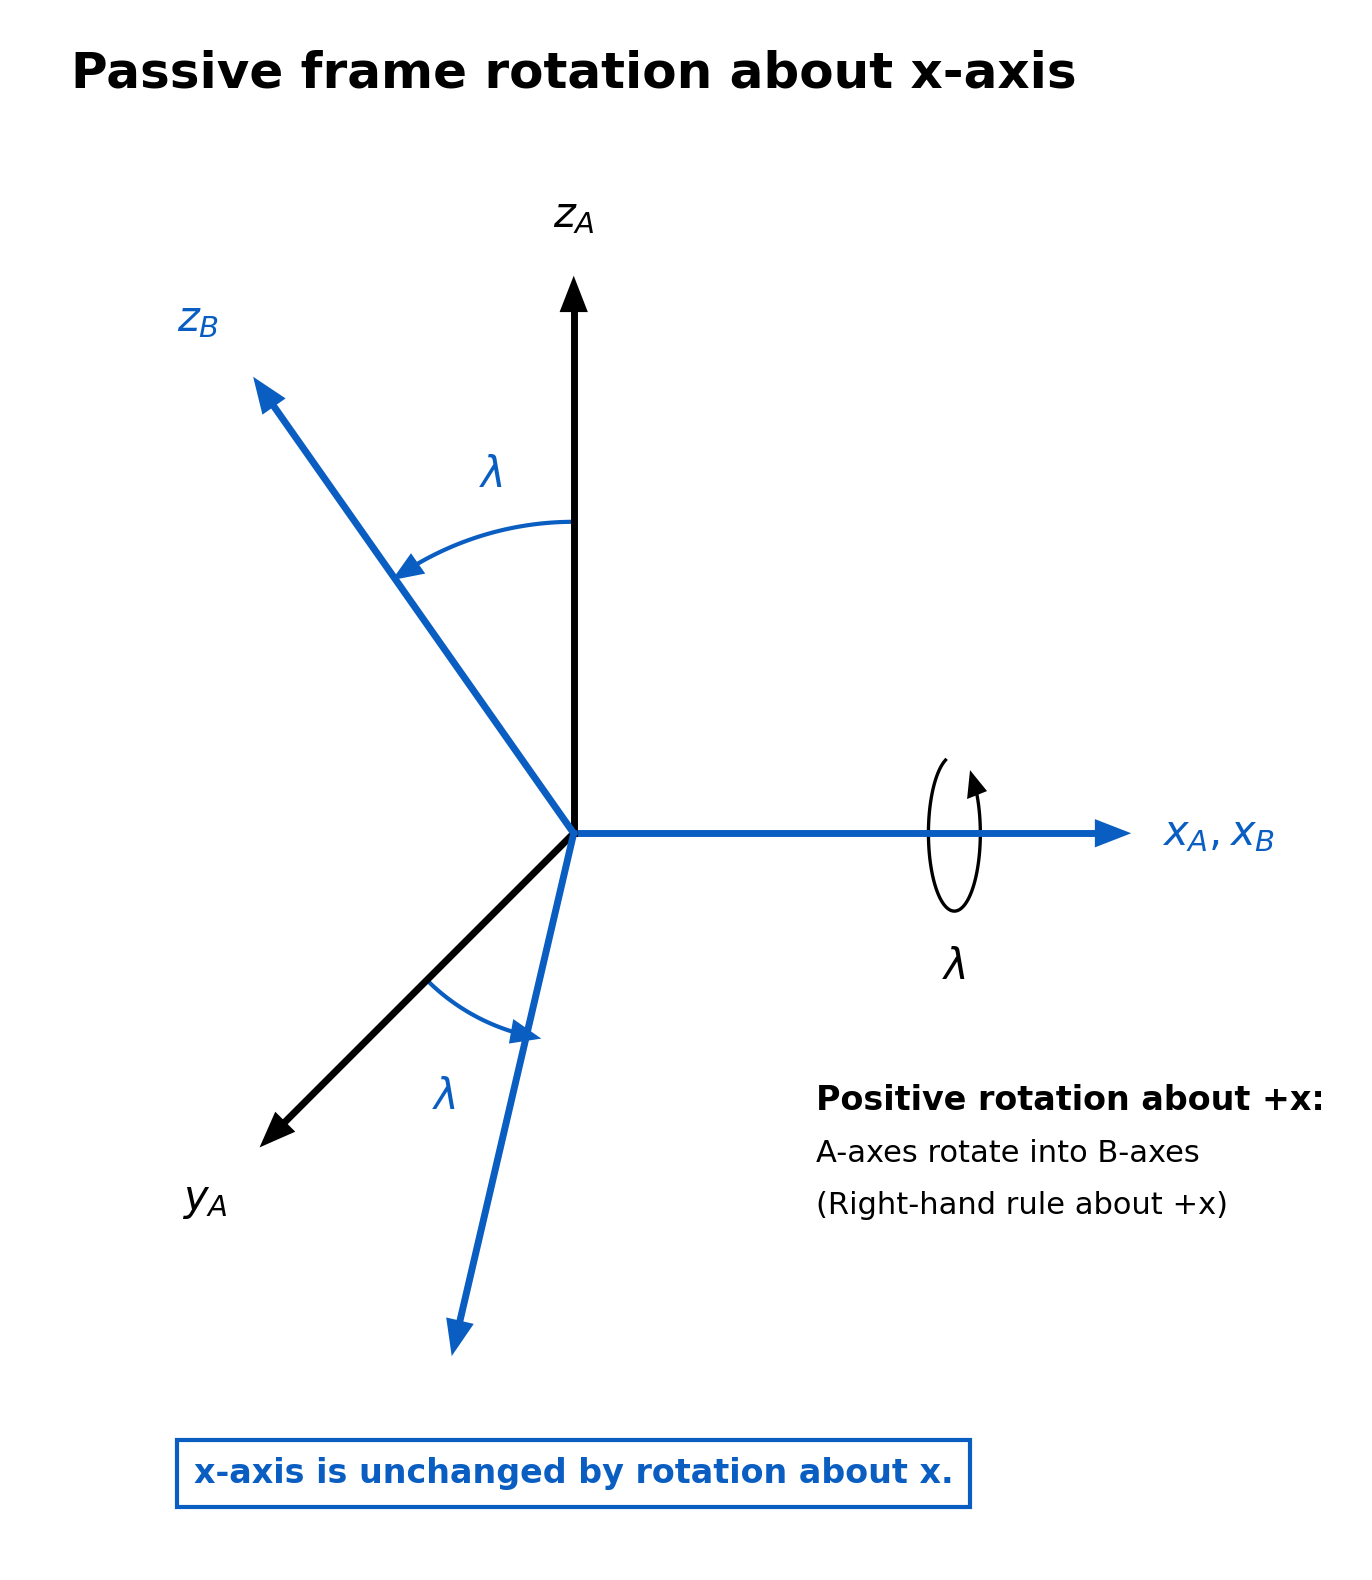
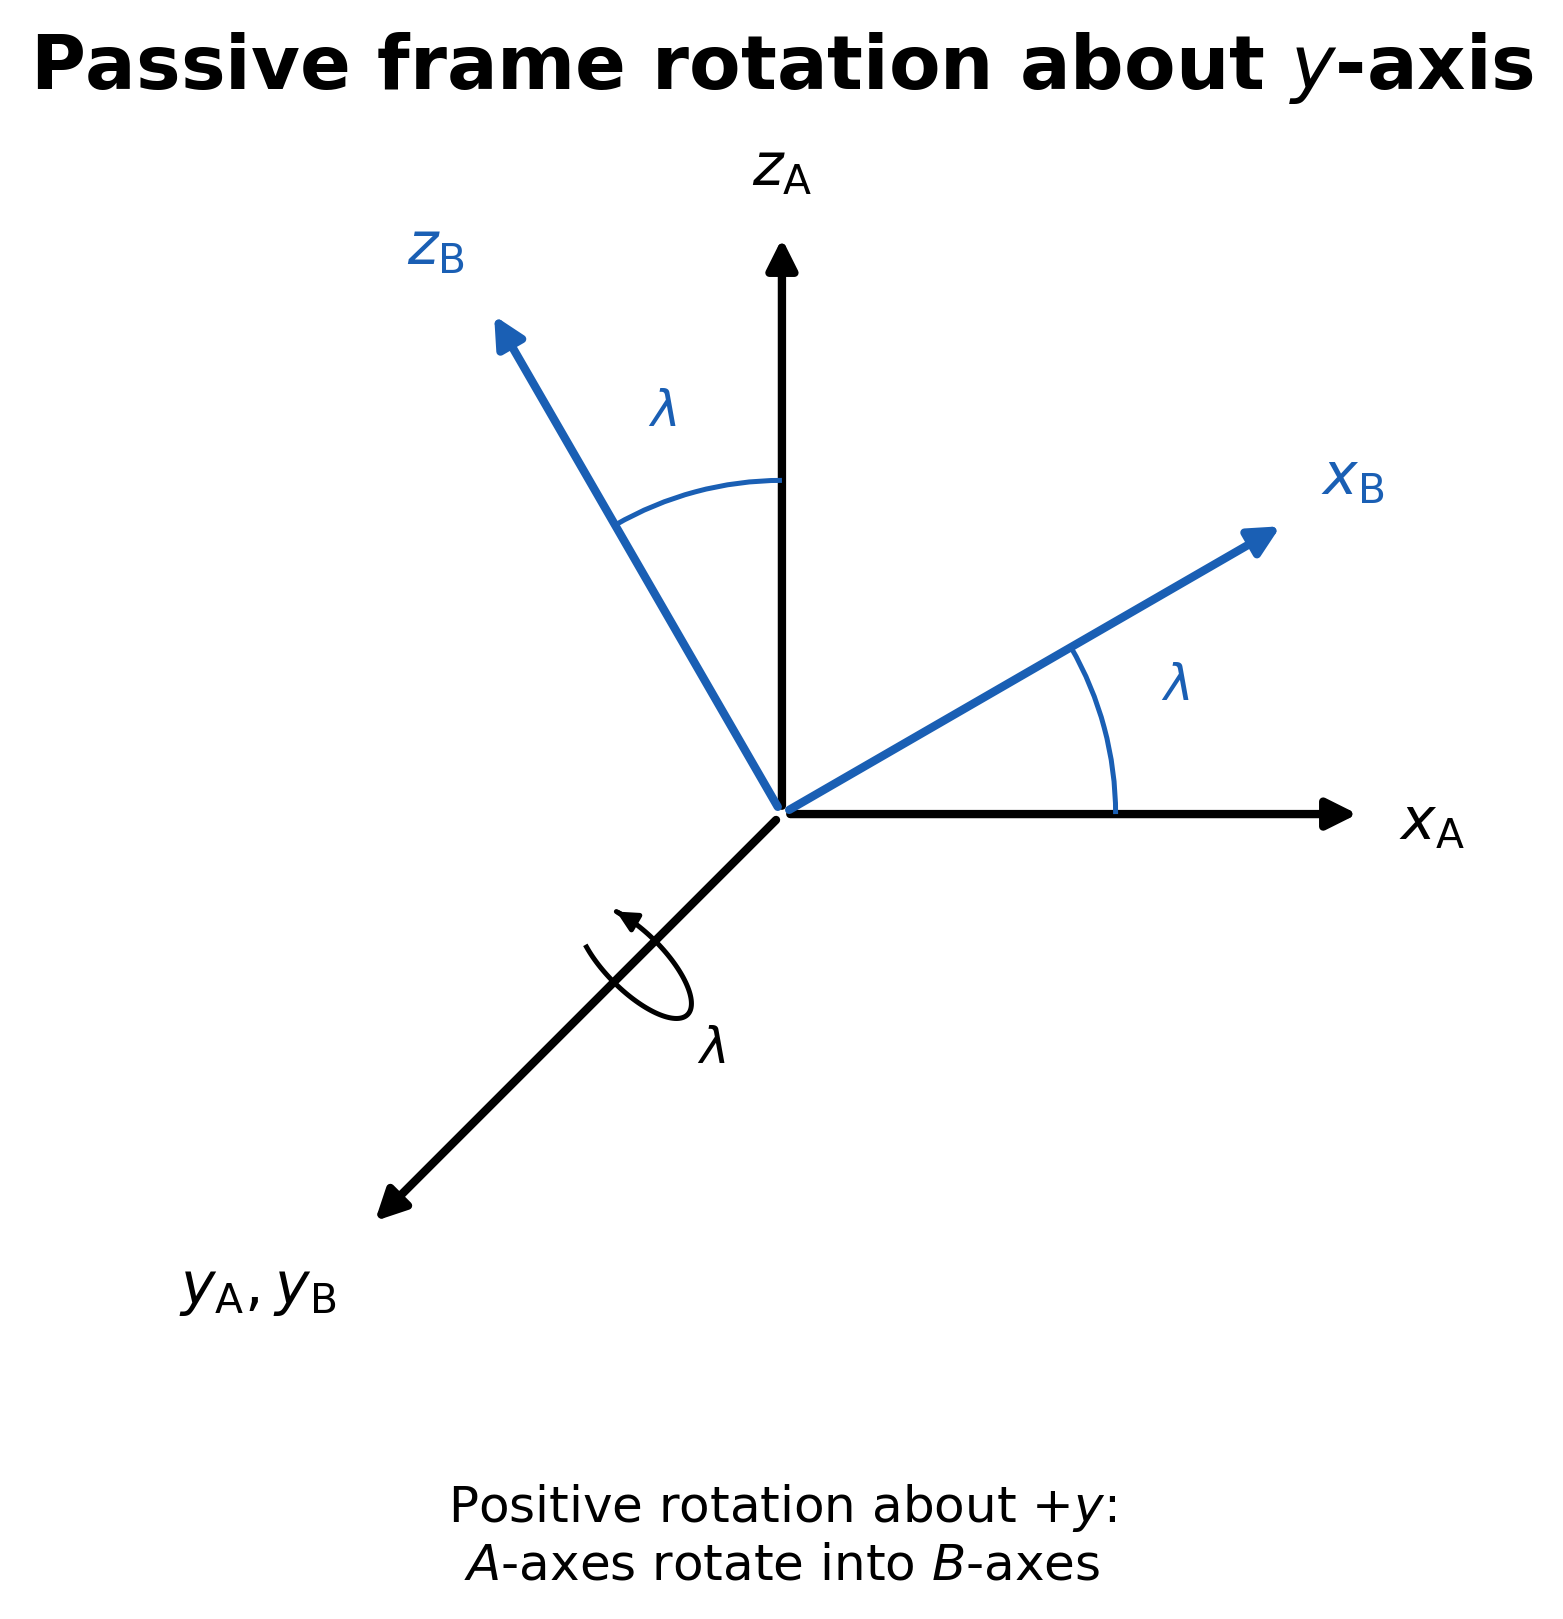
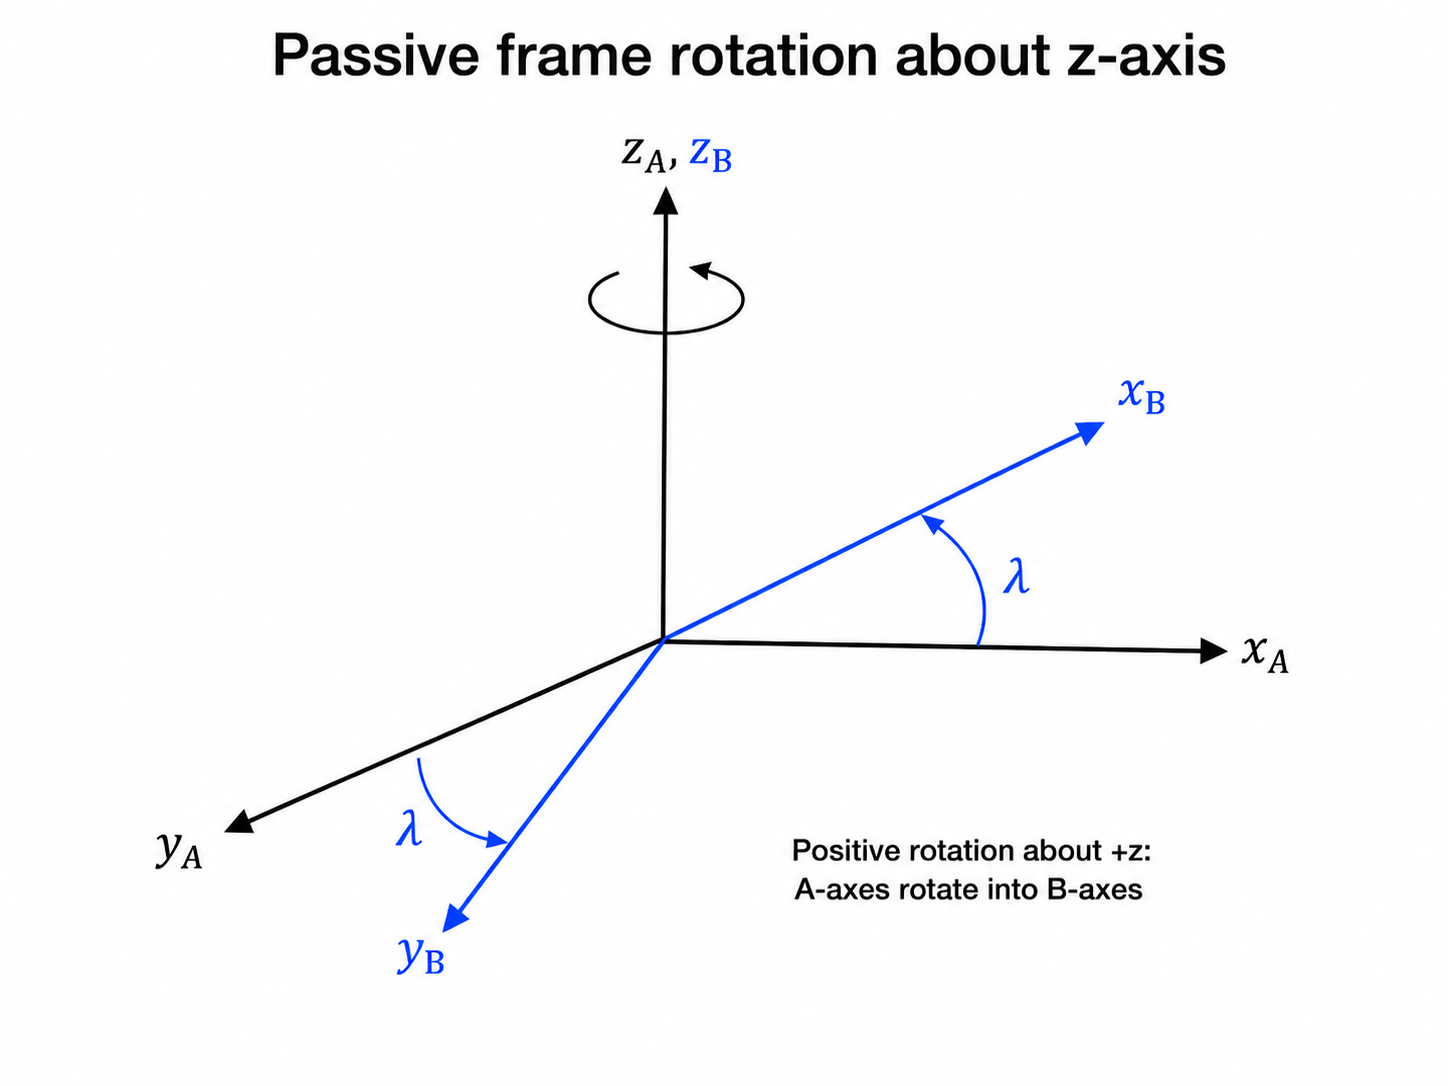
2 Visual reference sheetThe three figures from the parent article are included here as quick visual reference.
Figure. Passive frame rotation about axis 1, the x axis.
Figure. Passive frame rotation about axis 2, the y axis.
Figure. Passive frame rotation about axis 3, the z axis.
3 Exercises
4 Solutions
Solution 1: interpret the mapThe equation
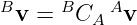 means that the physical vector is the same geometric object in space, but its coordinate description changes when we switch from frame A to frame B. Under a passive transformation, the vector stays fixed and the coordinate frame changes.
Solution 2: identify the unchanged coordinateFor rotation about axis 1, the first coordinate is unchanged. For rotation about axis 2, the second coordinate is unchanged. For rotation about axis 3, the third coordinate is unchanged. This is visible directly in the matrices and geometrically because the rotation axis itself is common to both frames.
Solution 3: write the three elementary matricesThe three elementary passive matrices are
and
Solution 4: a
|
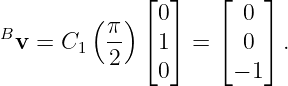 | (9) |
 check for

At λ = π∕2,
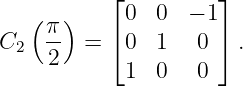
Therefore
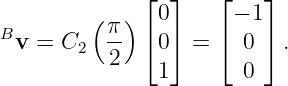 | (10) |
 check for

At λ = π∕2,
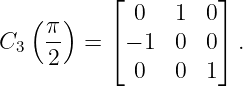
Hence
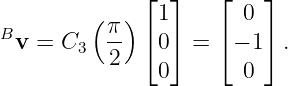 | (11) |
Because
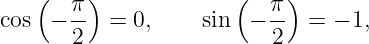
we obtain
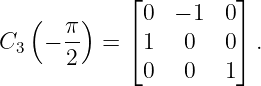
Applying it to the same vector gives
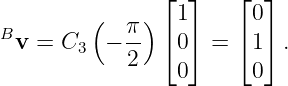 | (12) |
This is the opposite coordinate change from the positive angle case in Exercise 6.
We have
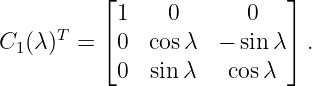
Multiplying gives
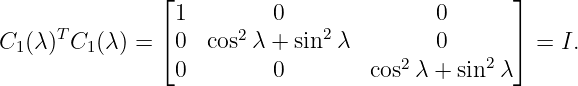 | (13) |
The analogous results are
 | (14) |
For every orthogonal matrix,
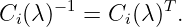
Also, replacing λ by −λ reverses the signs of the sine terms but leaves the cosine terms unchanged. That is exactly what the transpose does for these matrices. Hence
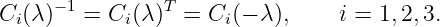 | (15) |
Expanding det C2(λ) along the second row gives
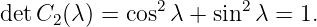 | (16) |
Each elementary passive rotation matrix should have determinant +1 because it is a proper orthogonal matrix.
If Ri(λ) is the active vector rotation matrix for the same positive geometric angle, then
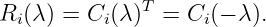 | (17) |
The passive map changes coordinates by the inverse of the active vector rotation.
The columns of BC A are the coordinates of the basis vectors of frame A expressed in frame B.
Therefore the columns of C3(λ) are
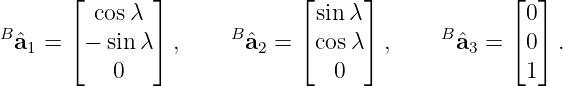
So the old x and y basis vectors are expressed in the new rotated frame by the first two columns, while the z basis vector is unchanged.
For small |λ|,

Thus
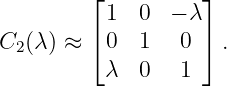 | (18) |
For the PhysicsLibrary passive intrinsic 3-2-1 sequence,
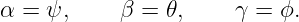
Therefore
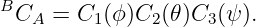 | (19) |
The rightmost factor acts first on a coordinate column.
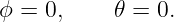
Starting from
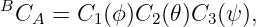
set ϕ = 0 and 𝜃 = 0. Since

the product reduces to
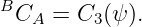 | (20) |
So only the yaw transformation remains.
If
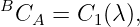
then
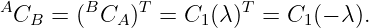 | (21) |
Explicitly,
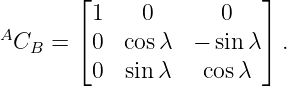 | (22) |
A quick test is to evaluate the student’s matrix at λ = π∕2.
This gives
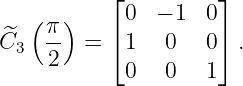
Applying it to

produces

whereas the correct PhysicsLibrary passive matrix should send that vector to

for positive frame rotation about +z.
So the student’s matrix is the active rotation matrix or, equivalently, the passive matrix with the angle sign reversed.
A coordinate column is multiplied from the right.
Thus in
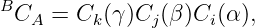
the first factor acting on Av is C i(α).
The result is then acted on by Cj(β), and finally by Ck(γ).
So the matrix product still represents the chronological intrinsic sequence i → j → k.
The essential formulas reinforced in this exercise companion are
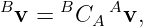 | (23) |
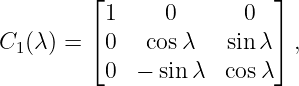 | (24) |
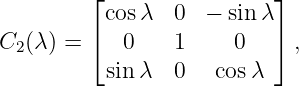 | (25) |
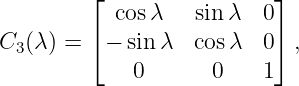 | (26) |
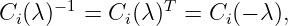 | (27) |
and
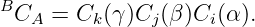 | (28) |
These formulas are the building blocks for all later Euler Angle matrix derivations.
Henderson provides a classic engineering presentation of Euler angles, quaternions, and transformation matrices.
Moore gives a modern passive reference frame treatment.
Diebel provides a compact comparison of attitude representations.
[1] D. M. Henderson, Euler Angles, Quaternions, and Transformation Matrices: Working Relationships, JSC-12960, NASA Johnson Space Center, 1977. NASA Technical Reports Server
[2] J. K. Moore, Learn Multibody Dynamics, chapter “Orientation of Reference Frames,” 2026 edition. Licensed CC BY 4.0. Orientation of Reference Frames
[3] J. Diebel, “Representing Attitude: Euler Angles, Unit Quaternions, and Rotation Vectors,” Stanford University, 2006. Online PDF
Unless otherwise noted, this PhysicsLibrary entry is intended for release under the Creative Commons Attribution ShareAlike 4.0 International license.
| Keywords: | Euler angles, passive rotation matrix, direction cosine, matrix, elementary rotations, coordinate transformation, exercises |
| Physics Classification: | 02.40.Yy (Geometric mechanics ) |
| 45.40.-f (Dynamics and kinematics of rigid bodies) | |
| 02.10.Ud (Linear algebra) |
None.
No messages.

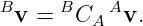
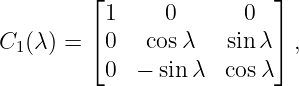
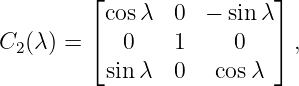
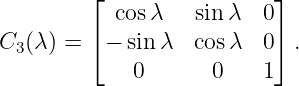
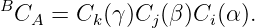
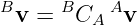


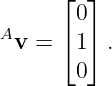


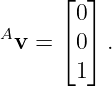


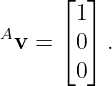
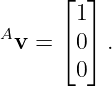
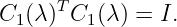
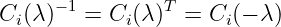
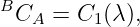
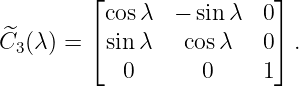
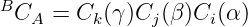
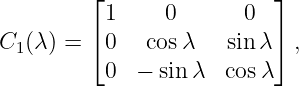
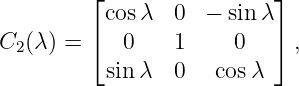
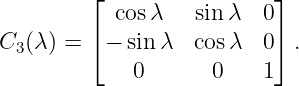
 check for