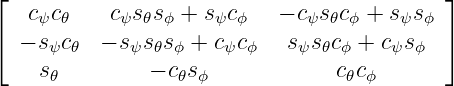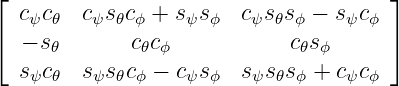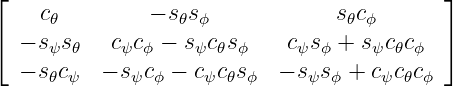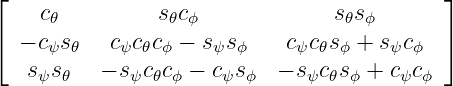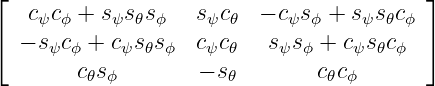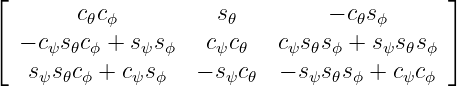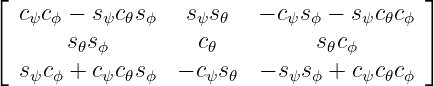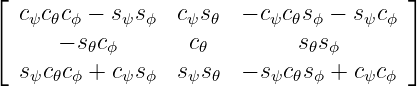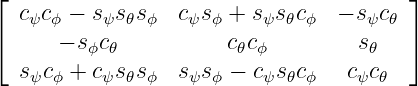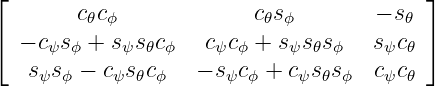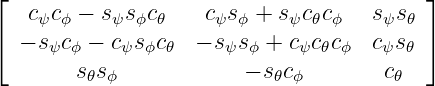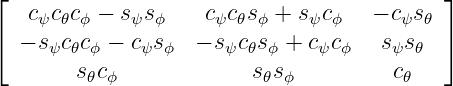An Euler angle sequence is a rotation matrix that is completely determined by three parameters,
called Euler Angles. These Euler angles are represented by the ϕ , 𝜃 and ψ variables with each
corresponding to a rotation about an axis. There are several different conventions. Only
one will be shown here, since it is more important to understand the underlying math
thoroughly.
A list of the Euler Angle rotation matrices for different sequences
This is version 6 of Euler angle sequences, born on 2005-08-19, modified 2026-02-16.
Object id is 71, canonical name is EulerAngles.
Accessed 1202 times total.