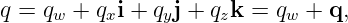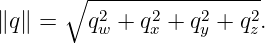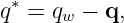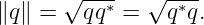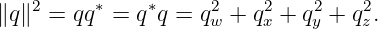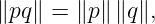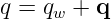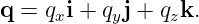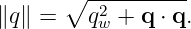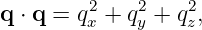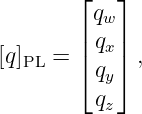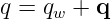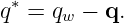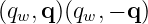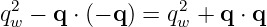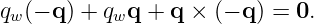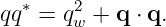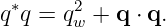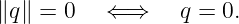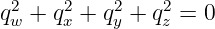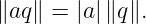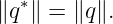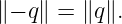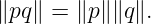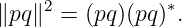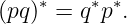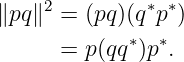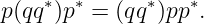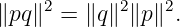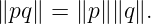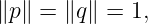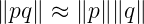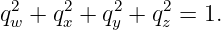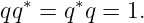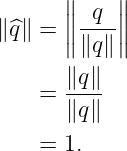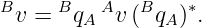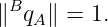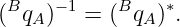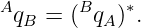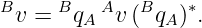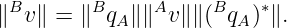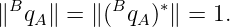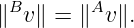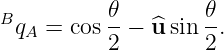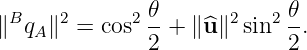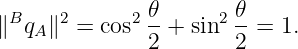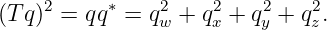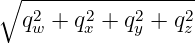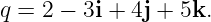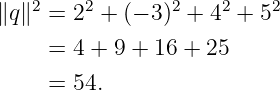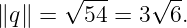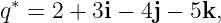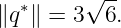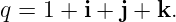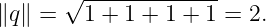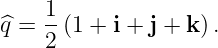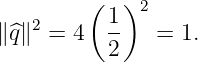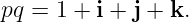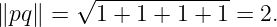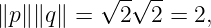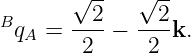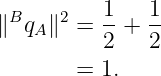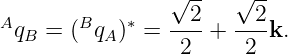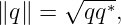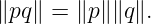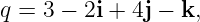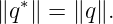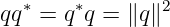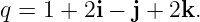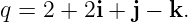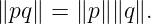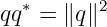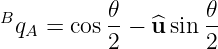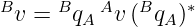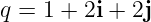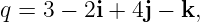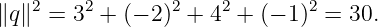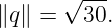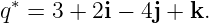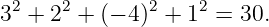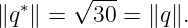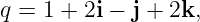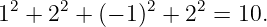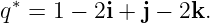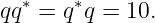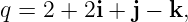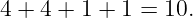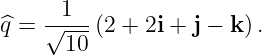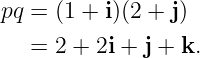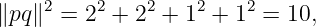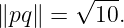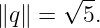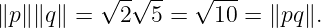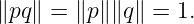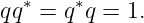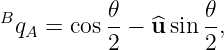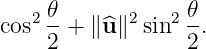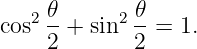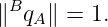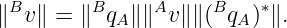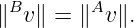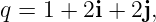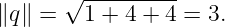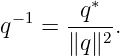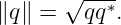Quaternion Norm
The quaternion norm measures the magnitude of a quaternion in the same way that the Euclidean
norm measures the length of a real vector.
For
the PhysicsLibrary quaternion norm is
Using the quaternion conjugate,
the same quantity can be written
The squared norm is therefore
The norm is always a nonnegative real number. It is zero only for the zero quaternion.
The norm is fundamental because it is multiplicative,
and because a quaternion with norm one is a unit quaternion. Unit quaternions are the objects
used in later PhysicsLibrary articles to represent passive frame orientation.
1 Definition
Let
with
The quaternion norm is defined by
Since
equation (5) is the ordinary Euclidean norm of the four real quaternion components.
In scalar first component notation,
so
is exactly the Euclidean length of this four component coefficient vector.
This observation concerns the magnitude of the coefficient array. It does not imply that quaternion
multiplication is ordinary four dimensional vector multiplication.
2 Derivation from the conjugate
The conjugate of
is
Using the Hamilton scalar vector product,
has scalar part
and vector part
Therefore
The same calculation gives
Hence
even though quaternion multiplication is not generally commutative.
Taking the nonnegative square root gives equation (2).
3 Basic properties
The quaternion norm has the standard properties expected of a norm.
Nonnegativity
For every quaternion q,
This follows because the squared norm is a sum of squares.
Definiteness
The norm vanishes only for the zero quaternion:
Indeed,
with real components requires every component to be zero.
Real scalar scaling
For a real scalar a,
Conjugation preserves norm
Since conjugation changes only the signs of the vector components,
Sign reversal preserves norm
Similarly,
This property later helps explain why q and −q can represent the same physical orientation when q
is a unit quaternion.
4 Multiplicative property
One of the most important facts about the quaternion norm is
A clean proof uses conjugation.
Start with
Quaternion conjugation reverses product order:
Therefore
The quantity qq∗ is real, so it commutes with every quaternion:
Thus
Both norms are nonnegative, so taking square roots gives
The order on the right is irrelevant because the norms are ordinary real numbers.
5 Why multiplicativity matters
The multiplicative norm has several immediate consequences.
First, if p and q are both unit quaternions,
then
Therefore unit quaternions are closed under quaternion multiplication.
Second, if q≠0, then
so the expression
is well defined. The next PhysicsLibrary article shows that this is precisely q−1.
Third, norm multiplicativity is a strong implementation check. A software routine intended to
compute Hamilton products should satisfy
up to numerical roundoff.
6 Unit quaternions
A quaternion is called a unit quaternion when
Equivalently,
Thus unit quaternions lie on the unit sphere in four dimensional real coefficient space.
For a unit quaternion,
Therefore
This relation is the key reason unit quaternions are so convenient for orientation calculations.
7 Normalization
Any nonzero quaternion can be converted into a unit quaternion by dividing by its
norm:
Then
Normalization changes the quaternion magnitude while preserving its direction in four dimensional
coefficient space.
When a quaternion is intended to represent orientation, normalization is often used to remove
small numerical drift from floating point propagation.
Normalization should not be used blindly to hide a serious integration or convention error. Large
norm drift is a diagnostic that the underlying algorithm should be checked.
8 Norm and passive frame orientation
The definition of quaternion norm is algebraic and does not depend on active or passive rotation
interpretation.
PhysicsLibrary uses a unit quaternion
to map coordinate components from frame A into frame B:
The frame quaternion must satisfy
Because of unit norm,
Thus the inverse frame map is represented by the conjugate,
The unit norm constraint is therefore what turns the simple conjugate into the exact inverse
needed for a reversible frame coordinate transformation.
9 Norm preservation under passive coordinate mapping
Let v be represented as a pure quaternion. Under the passive coordinate map,
Using norm multiplicativity,
For a unit frame quaternion,
Therefore
This is exactly what a change of orthonormal coordinates should do: the physical vector is
unchanged, so its Euclidean magnitude is unchanged.
10 Norm and the axis angle form
For a positive frame rotation through angle 𝜃 about unit axis u, the PhysicsLibrary passive
quaternion is
Its squared norm is
Since
we obtain
Thus the axis angle construction automatically produces a unit quaternion.
11 Historical terminology: tensor and norm
Historical quaternion texts do not always use the modern words norm and squared norm in the
same way as current engineering literature.
In much classical quaternion notation, the quantity now written
was called the tensor of the quaternion and written Tq.
Some historical sources then used the word norm for
Modern engineering and applied mathematics usually call
the quaternion norm and call its square the squared norm.
PhysicsLibrary follows this modern convention. When reading Hamilton, Tait, Joly, or other
historical sources, one should check whether the author’s “norm” means the modern norm or the
modern squared norm.
12 Worked example 1: computing a norm
Let
Then
Therefore
The conjugate has the same norm:
and
13 Worked example 2: normalization
Let
Its norm is
Therefore the normalized quaternion is
A direct check gives
14 Worked example 3: multiplicative norm
Take
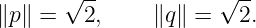
Their norms are
Their product is
Hence
The multiplicative property predicts
which agrees.
15 Worked example 4: passive frame quaternion
Consider a positive 90∘ frame rotation about +z. The passive PhysicsLibrary quaternion
is
Its norm is
Therefore its conjugate is also its inverse:
16 Numerical considerations
In exact mathematics, a properly constructed orientation quaternion has norm one. In numerical
simulation, finite precision integration may slowly move the stored quaternion away from unit
norm.
A common numerical correction is
For small numerical drift this keeps the state on the unit quaternion constraint.
Several practical cautions are important:
- Check for a norm near zero before dividing.
- Do not use normalization to compensate for a wrong propagation equation or a frame
convention error.
- If norm drift is unexpectedly large, inspect time step size, integration method, angular
rate units, multiplication order, and frame definitions.
- When comparing two orientation quaternions, remember that q and −q have the same
norm and later will be shown to represent the same orientation.
17 Common pitfalls
- Confusing norm with squared norm. PhysicsLibrary uses
not qq∗ itself.
- Importing historical terminology without checking definitions. Some classical
sources use “norm” for what PhysicsLibrary calls the squared norm.
- Assuming every quaternion used in algebra has unit norm. Only unit
quaternions satisfy ∥q∥ = 1.
- Assuming conjugation changes the norm. Conjugation preserves norm exactly.
- Forgetting norm multiplicativity. Quaternion multiplication is not commutative,
but the norm still satisfies
- Normalizing the zero quaternion. The expression q∕∥q∥ is undefined for q = 0.
- Changing the norm formula because an attitude convention is passive. The
norm is algebraic and is unchanged by active or passive interpretation.
- Treating normalization as a substitute for correct dynamics. Small numerical
drift may be corrected by normalization; large drift should be investigated.
18 Exercises
The exercises are stated first so the article can be used for self study. Complete solutions follow
afterward.
- Direct norm. For
compute ∥q∥2 and ∥q∥.
- Conjugate invariance. For the quaternion in Exercise 1, compute q∗ and verify
- Product with conjugate. Show directly that
for
- Normalization. Normalize
- Multiplicative norm. Let
Compute pq and verify
- Unit quaternion product. Prove that the product of two unit quaternions is a unit
quaternion.
- Inverse of a unit quaternion. Use
to prove that q−1 = q∗ when ∥q∥ = 1.
- Passive frame norm. Show that
has unit norm when u is a unit vector.
- Vector magnitude preservation. Using multiplicativity of the quaternion norm,
prove that the passive map
preserves vector magnitude when Bq
A is unit.
- Historical terminology. A nineteenth century source states that the “norm” of
is 9. Is this necessarily inconsistent with the PhysicsLibrary definition? Explain.
19 Solutions
1. Direct norm
For
the squared norm is
Therefore
2. Conjugate invariance
The conjugate is
Its squared norm is
Hence
3. Product with conjugate
For
the squared norm is
The conjugate is
By the conjugate product identity,
4. Normalization
For
the squared norm is
Therefore
5. Multiplicative norm
First,
Therefore
so
Also,
and
Hence
6. Unit quaternion product
If
and
then multiplicativity gives
Thus pq is unit.
7. Inverse of a unit quaternion
For a unit quaternion,
Therefore
By definition of multiplicative inverse,
8. Passive frame norm
For
the squared norm is
Since
this becomes
Therefore
9. Vector magnitude preservation
Using multiplicativity,
A unit quaternion and its conjugate both have norm one. Therefore
10. Historical terminology
For
PhysicsLibrary gives
Its squared norm is
A historical source may call this squared quantity the “norm” and call the modern norm the
“tensor.” Therefore the value 9 is not necessarily an error; the terminology must be
checked.
20 What comes next
The norm and conjugate together give the inverse of every nonzero quaternion:
The next PhysicsLibrary quaternion article derives this formula, explains why left and right
division must be treated carefully in a noncommutative algebra, and specializes the result to unit
and pure quaternions.
Later orientation articles use unit norm as the defining constraint that makes quaternion frame
maps invertible by simple conjugation and makes quaternion coordinate transformations preserve
physical vector length.
21 Sources and historical notes
Classical quaternion authors often distinguished the tensor from the norm. In Tait’s terminology,
the tensor corresponds to the modern quaternion norm, while the historical norm is
its square. Modern engineering literature normally uses “norm” for the square root
quantity.
The PhysicsLibrary convention follows modern Euclidean norm terminology and uses
The historical distinction is retained here because it is important when reading older quaternion
literature.
References
[1] W. R. Hamilton, Elements of Quaternions, 2nd ed., edited by C. J. Joly, Longmans,
Green, and Co., 1899. Public domain historical source. Internet Archive scan
[2] P. G. Tait, An Elementary Treatise on Quaternions, 3rd ed., Cambridge University
Press, 1890. Public domain historical source. Internet Archive search
[3] C. J. Joly, A Manual of Quaternions, Macmillan and Co., London, 1905. Public
domain historical source. Internet Archive scan
[4] A. S. Hathaway, A Primer of Quaternions, 1896. Public domain historical source.
Project Gutenberg edition
License
Unless otherwise noted, this PhysicsLibrary entry is intended for release under the Creative
Commons Attribution ShareAlike 4.0 International license.