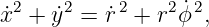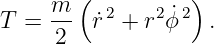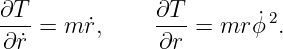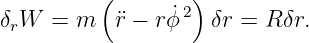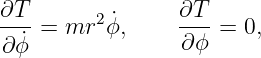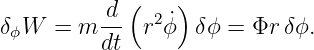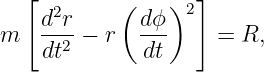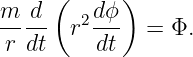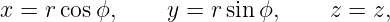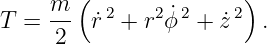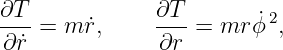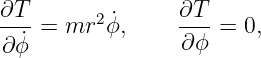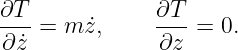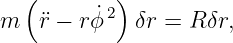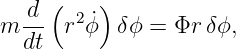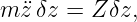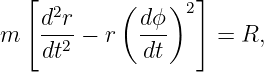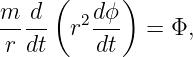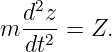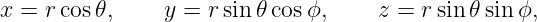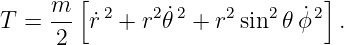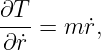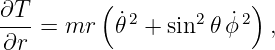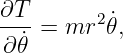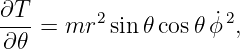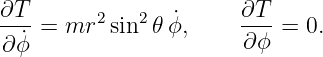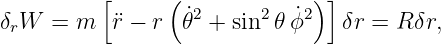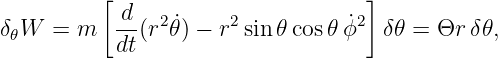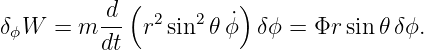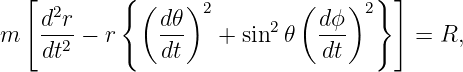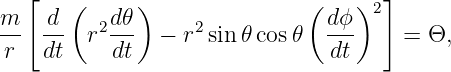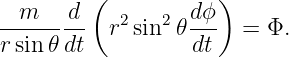Physics Library
 An open source physics library
Encyclopedia | Forums | Docs | Random  

[parent] example of dynamics of a particle: free_motion

(Example)

Examples for Free Motion

(a) Polar Coordinates in a Plane

Let us get the equations in polar coordinates for motion in a plane. Here

x =  rcosϕ,     y = r sin ϕ,

˙x2 + y˙2 = ˙r2 + r2 ˙ϕ2,

and

        (          )
T  = m-  ˙r2 + r2ϕ˙2 .
      2

Then

∂T- = m r˙,     ∂T- = mr ϕ˙2.
∂ ˙r            ∂r

If R is the impressed force resolved along the radius vector,

         (       2)
δrW  = m   ¨r − r ˙ϕ  δr = R δr.

Also

∂T-      2 ˙     ∂T-
  ˙ = mr  ϕ,     ∂ ϕ =  0,
∂ ϕ

and, if Φ is the impressed force resolved perpendicular to the radius vector,

          d ( 2 )
δϕW  = m --  r ϕ˙ δϕ =  Φr δϕ.
         dt

In more familiar form,

  [                ]
    d2r    ( dϕ )2
m   --2-− r  ---     = R,
    dt        dt

     (      )
m  d    2d ϕ
-r dt  r -dt  =  Φ.

(b) Cylindrical Coordinates

In cylindrical coordinates, where

x = r cosϕ,     y = rsin ϕ,    z =  z,

     m (  2    2 2    2)
T =  --  ˙r +  r ˙ϕ  + ˙z   .
     2

We have

∂T- = m r˙,     ∂T- = mr ϕ˙2,
∂ ˙r            ∂r

∂T- = mr2 ϕ˙,     ∂T- =  0,
∂ ˙ϕ              ∂ ϕ

∂T- = m z˙,     ∂T- = 0.
 ∂ ˙z           ∂z

Hence

   (        )
m   ¨r − rϕ˙2 δr = R δr,

     (    )
m -d  r2ϕ˙ δ ϕ = Φr δϕ,
  dt

m ¨zδz =  Zδz,

or

  [  2     (    )2 ]
m   d-r-− r  dϕ-     = R,
    dt2       dt

     (      )
m- d-   2d-ϕ
 r dt  r  dt  =  Φ,

  d2z
m ---2 = Z.
   dt

(c) Spherical Coordinates

In spherical coordinates where

x = r cos𝜃,     y = rsin𝜃 cosϕ,     z = r sin 𝜃sinϕ,

        [                      ]
     m-   2    2 ˙2   2   2  ˙2
T =  2   ˙r +  r 𝜃 +  r sin 𝜃 ϕ  .

Then

∂T- = m ˙r,
∂r˙

∂T       (  2     2    2)
---=  mr  𝜃˙ +  sin  𝜃ϕ˙  ,
∂r

∂T-      2 ˙
  ˙ = mr  𝜃,
∂𝜃

∂T-      2           ˙2
∂ 𝜃 = mr   sin 𝜃cos 𝜃ϕ  ,

∂T- = mr2  sin2 𝜃ϕ˙,     ∂T- = 0.
∂ ˙ϕ                    ∂ ϕ

Thus

          [      (            ) ]
δ W  =  m  ¨r − r  ˙𝜃2 + sin2 𝜃ϕ˙2   δr = R δr,
 r

         [                         ]
δ𝜃W  = m   d-(r2 ˙𝜃) − r2sin𝜃 cos𝜃ϕ˙2 δ𝜃 = Θr  δ𝜃,
           dt

and

             (         )
δϕW  =  m d-  r2sin2𝜃 ˙ϕ  δϕ = Φr sin𝜃 δϕ.
          dt

Or

   [        { (   )          (    ) } ]
    d2r         d𝜃  2     2    dϕ  2
m   --2-− r     ---  +  sin  𝜃  ---      = R,
    dt          dt             dt

   [   (     )               (    )2 ]
m-  -d    2d𝜃-     2           d-ϕ
 r  dt  r  dt  −  r sin 𝜃 cos𝜃   dt     = Θ,

  m   d  (        dϕ )
--------  r2 sin2 𝜃---  = Φ.
rsin𝜃 dt          dt

Source

William Elwood Byerly, An Introduction to the Use of Generalized Coördinates in mechanics and Physics, Ginn and Company, 1916. Chapter I, “Introduction.”

The 1916 source work is in the public domain in the United States.


"example of dynamics of a particle: free_motion" is owned by bloftin.
(view preamble)
View style:
See Also: coordinates of a point


This object's parent.

Cross-references: domain, work, mechanics, radius vector, force, motion

This is version 1 of example of dynamics of a particle: free_motion, born on 2026-08-19.
Object id is 1062, canonical name is ExampleOfDynamicsOfAParticleFree_motion.
Accessed 182 times total.

Classification:
Physics Classification: 45. (Classical mechanics of discrete systems)

Pending Errata and Addenda

None.

Discussion

No messages.

Interact