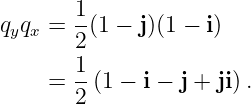|
|
|
|||||||
The corresponding passive direction cosine matrix rule is
Reading the quaternion chain from right to left gives the coordinate map
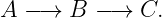 Quaternion multiplication is associative but generally not commutative:
but
in general.
1 Convention summaryPhysicsLibrary uses Hamilton multiplication,
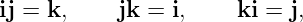 with reversed products changing sign. For a positive frame rotation through angle 𝜃 about unit axis u, the elementary passive quaternion is
For a unit frame quaternion,
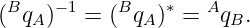 For an intrinsic moving axis i-j-k sequence with angles α,β,γ,
2 Exercises
3 Solutions
Solution 1: reading a frame chainThe first coordinate map is
 and the second is
 Therefore the direct quaternion is
The matching passive DCM chain is
The written factor order is the same for quaternions and DCMs.
Solution 2: two passive
|
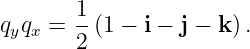 | (9) |
Now reverse the order:
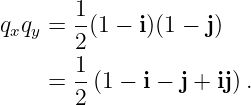
Since

we obtain
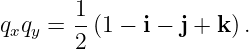 | (10) |
The k component changes sign, so
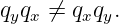
Consider first

The first passive x map sends

The second passive y map leaves j unchanged because the vector is parallel to the y rotation axis.
Therefore
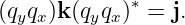 | (11) |
Now reverse the order.
The passive y map first sends

The following passive x map leaves i unchanged because it lies on the x rotation axis.
Hence
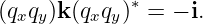 | (12) |
Thus changing the order changes the final coordinate vector from

to

Start with
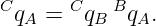
Invert both sides:
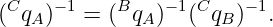
Using the reverse frame labels,
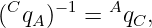
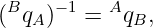
and
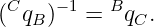
Therefore
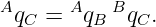 | (13) |
Because the frame quaternions are unit, each inverse may also be replaced by a conjugate.
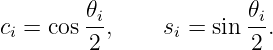
Let
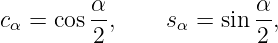
and similarly for β.
Then
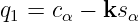
and
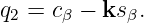
Their product is
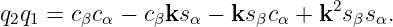
Since

we obtain
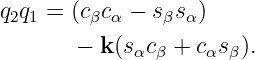
Using angle addition identities,
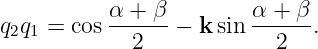 | (14) |
Thus the two frame rotation angles add.
Both quaternions lie in the same subalgebra generated by 1 and k, so
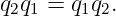 | (15) |
Rotations about the same axis are a special commuting case.
Because q is unit,

Therefore
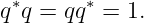 | (16) |
Geometrically, the second frame transformation reverses the first exactly, so the net coordinate map is the identity.
The full chain is
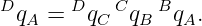
Hamilton multiplication is associative, so
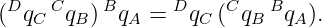 | (17) |
Both groupings represent the same map
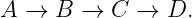
Associativity permits moving parentheses. It does not permit exchanging factors. In general,
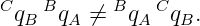
The positive active rotors are the conjugates:
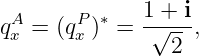
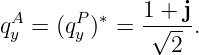
Now consider the active product

Conjugating gives
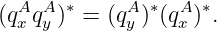
Since
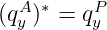
and
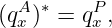
we obtain
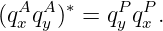 | (18) |
Thus a passive frame composition is the inverse of the corresponding active composition describing the opposite geometric action.
The reversal arises from conjugating a product, not from changing Hamilton multiplication.
For an intrinsic moving axis
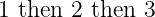
sequence, PhysicsLibrary writes
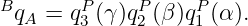 | (19) |
The same final orientation can be described extrinsically about fixed axes in the reversed axis order:
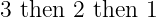 | (20) |
with angles
 | (21) |
The equivalence concerns two descriptions of the same final orientation. It does not say that finite rotations may be reordered arbitrarily.
 -
 -

For intrinsic yaw, pitch, roll,
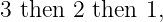
the passive quaternion is
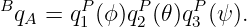 | (22) |
The matching passive DCM is
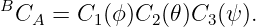 | (23) |
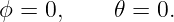
If
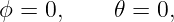
then

and
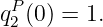
Therefore
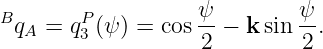 | (24) |
Likewise,
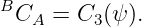 | (25) |
The sequence reduces to a single passive yaw frame rotation.
The quaternion chain is
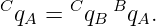
Apply the quaternion to DCM mapping:
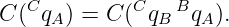
Under the PhysicsLibrary passive convention,
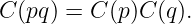
Therefore
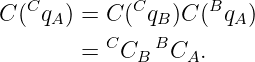
Hence
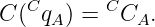 | (26) |
The homomorphism identity is
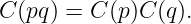 | (27) |
Write
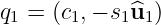
and
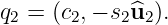
The scalar vector Hamilton product gives
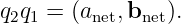
The scalar part is
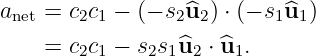
Therefore
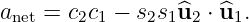 | (28) |
The vector part is
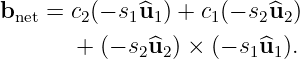
Thus
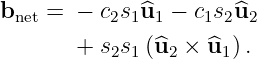 | (29) |
The cross product term is where the order sensitivity appears explicitly.
Use
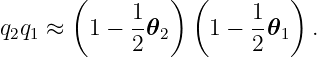
Retaining terms through second order gives
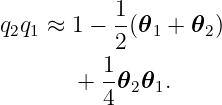
Similarly,
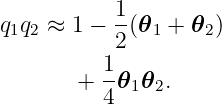
Subtract:
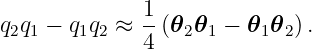
For pure quaternions a and b,
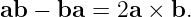
Therefore
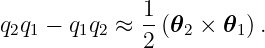 | (30) |
The difference is second order in the small rotation magnitudes. If only first order terms are retained, it disappears, so the rotations appear to commute.
The correct direct map is
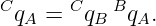
The program computes

which reverses the required order.
For

and

the correct quaternion is
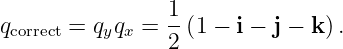 | (31) |
The incorrect product is
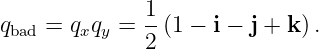 | (32) |
The changed sign of the k component represents a genuinely different orientation.
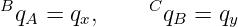
The known maps are

and

Therefore
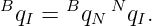 | (33) |
The reverse quaternion is
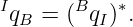
Using product conjugation,
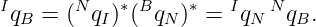 | (34) |
The corresponding passive DCM chain is
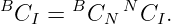 | (35) |
Finally, if Iv is known directly, then
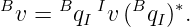 | (36) |
Substituting the chain explicitly gives
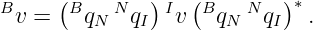 | (37) |
This is the same composition pattern used in inertial navigation and rigid body attitude transformations.
The following identities provide useful self checks:
| Situation | PhysicsLibrary result |
Frame chain 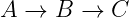 | Cq A = Cq B Bq A |
| Reverse chain | Aq C = Aq B Bq C |
| Same axis | angles add and products commute |
| Inverse pair | q∗q = qq∗ = 1 |
Passive  then  ,  | k → j |
Passive  then  ,  | k →−i |
| Quaternion to DCM map | C(pq) = C(p)C(q) |
The exercises and solutions in this companion are newly written or rewritten for PhysicsLibrary under the passive frame convention.
Classical quaternion texts by Hamilton, Joly, and Hathaway discuss products of versors and successive rotations. Sommer and coauthors provide a modern discussion of Hamilton versus flipped multiplication and the interaction between active and passive attitude conventions.
[1] W. R. Hamilton, Elements of Quaternions, 2nd ed., edited by C. J. Joly, Longmans, Green, and Co., 1899. Public domain historical source. Internet Archive scan
[2] C. J. Joly, A Manual of Quaternions, Macmillan and Co., London, 1905. Public domain historical source. Internet Archive scan
[3] A. S. Hathaway, A Primer of Quaternions, 1896. Public domain historical source. Project Gutenberg edition
[4] H. Sommer, I. Gilitschenski, M. Bloesch, S. Weiss, R. Siegwart, and J. Nieto, “Why and How to Avoid the Flipped Quaternion Multiplication,” Aerospace, vol. 5, no. 3, article 72, 2018. Published under CC BY 4.0. Publisher article
Unless otherwise noted, this PhysicsLibrary entry is intended for release under the Creative Commons Attribution ShareAlike 4.0 International license.
| Physics Classification: | 02.40.Yy (Geometric mechanics ) |
| 02.10.Hh (Rings and algebras) | |
| 45.40.-f (Dynamics and kinematics of rigid bodies) |
None.
No messages.

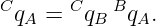
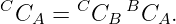
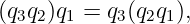
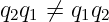
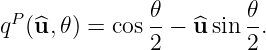
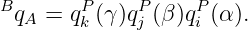


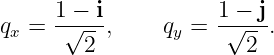


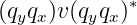
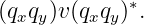
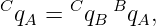
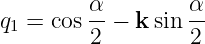
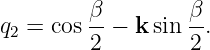
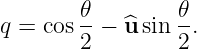
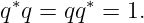
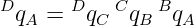
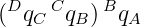
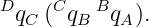
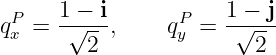


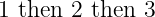


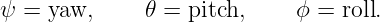
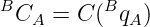
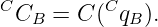
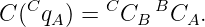
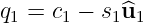
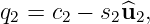
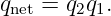
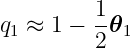
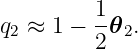
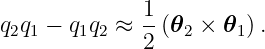


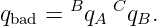


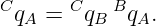
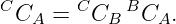
 frame rotations