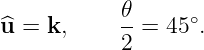|
|
|
|||||||
The canonical PhysicsLibrary orientation quaternion is the passive coordinate map Bq A. If frame B is obtained from frame A by a positive frame rotation through angle 𝜃 about the unit axis u, then
It maps vector coordinates from frame A into frame B according to
For a unit quaternion written
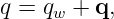 define
 When s≠0, the corresponding passive axis angle pair can be extracted as
For a principal frame rotation with 𝜃 ∈ [0,π], one normally chooses the equivalent quaternion sign so that qw ≥ 0 before applying the extraction.
2 Exercises
Foundational exercises
Convention and interpretation exercises
Engineering and derivation exercises
3 Solutions
Solution 1:
|
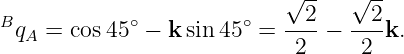 | (13) |
Thus
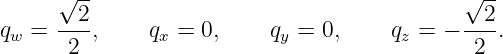
In scalar first column form,
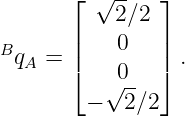 | (14) |
The negative vector component is the expected passive sign for a positive frame rotation about +z.
 about

The half angle is

Therefore
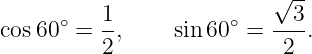
Multiplying the sine by the unit axis gives
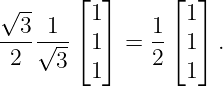
The passive quaternion is therefore
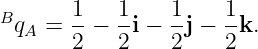 | (15) |
Its squared norm is
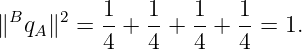
Hence the quaternion is unit.
 about

First verify the axis normalization:
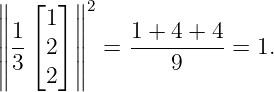
The half angle is

so
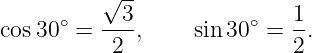
Therefore
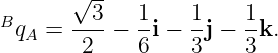 | (16) |
In scalar first column form,
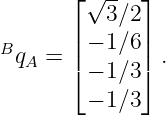 | (17) |
The quaternion is
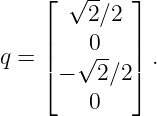
Its scalar part is

and the vector magnitude is

Therefore
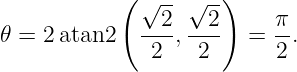 | (18) |
For the passive convention,

Since
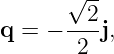
we obtain
 | (19) |
Thus the quaternion represents a positive 90∘ frame rotation about +y.
 quaternion
For
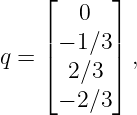
the vector part has unit magnitude:
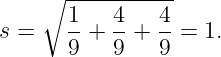
Because qw = 0,
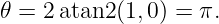 | (20) |
The passive axis is

because s = 1. Hence
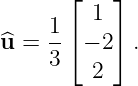 | (21) |
Replacing q by −q reverses the displayed vector part and therefore reverses the extracted axis. At exactly 180∘,

and

describe the same frame orientation. This is a special case of the general q versus −q ambiguity.
 versus

The supplied quaternion is
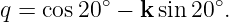
Comparing with
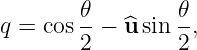
gives
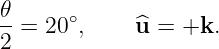
Therefore
 | (22) |
about +z.
Now
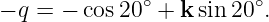
Use
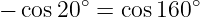
and
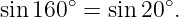
Then
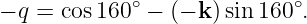
Therefore −q may be written as the passive axis angle pair
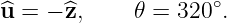 | (23) |
A 320∘ frame rotation about −z is equivalent to a 40∘ frame rotation about +z, so q and −q represent the same orientation.
 , and

The passive quaternion is
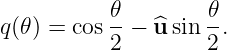
For 𝜃 = 0,
 | (24) |
For 𝜃 = 2π,

so
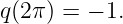 | (25) |
For 𝜃 = 4π,

so
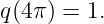 | (26) |
Thus
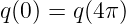
as quaternions, while
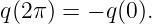
All three represent the same frame orientation because q and −q produce the same orientation map.
This illustrates the two to one relationship between unit quaternions and proper three dimensional orientations.
For a positive 30∘ frame rotation about +z,

Therefore
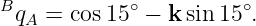 | (27) |
Because it is unit,
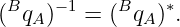
Hence
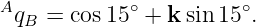 | (28) |
As a passive quaternion, Aq B maps coordinate components from frame B back into frame A.
The same numerical quaternion
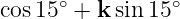
is also the familiar Hamilton active rotor for a positive 30∘ physical vector rotation about +z in a fixed coordinate frame.
The same numbers therefore admit different physical interpretations depending on whether the quaternion represents active vector motion or a passive frame map. The frame labels remove that ambiguity.
The programmer uses

without normalization. For 𝜃 = 90∘,

The incorrect quaternion becomes
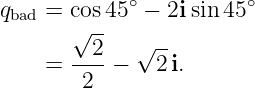
Its squared norm is
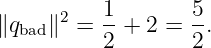
Therefore
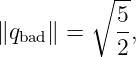 | (29) |
which is not one.
The mistake is that the axis in the axis angle formula must be a unit vector. The correct axis is

Therefore the correct passive unit quaternion is
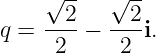 | (30) |
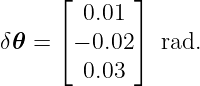
The passive first order approximation is
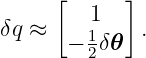
For
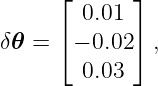
we obtain
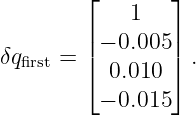 | (31) |
Its squared norm is
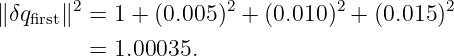
Therefore
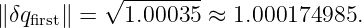 | (32) |
The first order approximation is therefore slightly longer than a unit quaternion.
Normalizing gives approximately
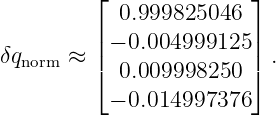 | (33) |
The normalization correction is second order in the small rotation magnitude.
The axis
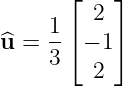
is unit because
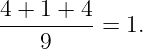
The frame rotation angle is

so the half angle is

Thus
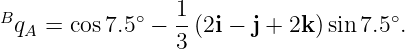 | (34) |
Using
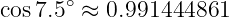
and
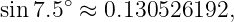
the scalar first components are
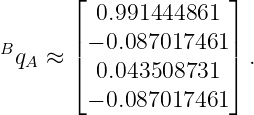 | (35) |
The vector part is opposite the positive frame rotation axis, as required by the passive convention.
Let

so that
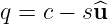
and
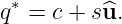
Because u and v are perpendicular unit pure quaternions,
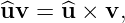
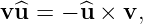
and

Now expand:
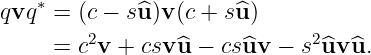
Substituting the perpendicular Vector Identities gives
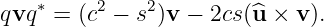
Using the double angle identities,
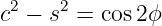
and
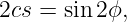
we obtain
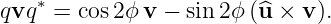 | (36) |
The coordinate vector therefore undergoes a rotation of −2ϕ about u.
That is exactly the coordinate motion expected when the coordinate frame itself is rotated positively through +2ϕ. Therefore a positive frame rotation through angle 𝜃 requires
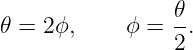 | (37) |
This proves both the half angle and the passive minus sign.
Start with the power series
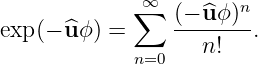
Since

the even powers are
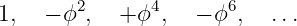
while the odd powers contain −u times
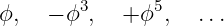
Therefore
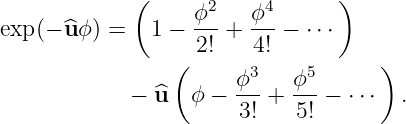
Recognizing the cosine and sine series gives
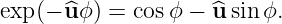 | (38) |
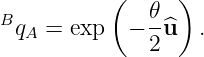
Setting

gives the passive axis angle quaternion
 | (39) |
The supplied quaternion is approximately
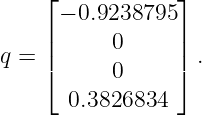
Its vector magnitude is
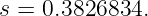
Using the quaternion exactly as supplied,
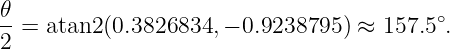
Therefore
 | (40) |
The passive axis is
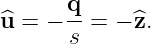
Thus the supplied quaternion can be interpreted as
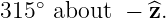 | (41) |
Now choose the equivalent quaternion with nonnegative scalar part:
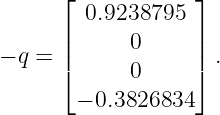
Then
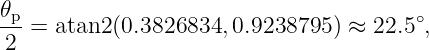
so
 | (42) |
The passive principal axis is
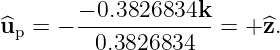
Therefore the principal representative is
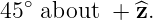 | (43) |
The two axis angle descriptions are equivalent because
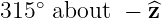
and
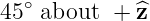
produce the same frame orientation, and the unit quaternions q and −q always represent the same orientation map.
The exercises above provide several quick checks for the PhysicsLibrary convention.
For a positive frame rotation about a unit axis u,
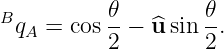 | (44) |
For principal positive frame angles, the recovered axis is
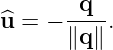 | (45) |
For a small frame rotation vector,
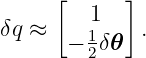 | (46) |
The inverse passive map and the corresponding positive active rotor use the conjugate sign:
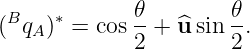 | (47) |
These checks make it possible to detect an accidental return to the previous active sign convention immediately.
The problems and solutions above are newly written or rewritten for PhysicsLibrary under the passive quaternion convention. Their subject matter is cross checked against public domain quaternion texts by Hamilton, Hathaway, Joly, and Macfarlane.
Joly discusses the relation between quaternion phase and twice angle rotation, while Hathaway and Macfarlane provide historical treatments of finite rotation and quaternion geometry. No historical exercise is transcribed verbatim.
[1] W. R. Hamilton, Elements of Quaternions, 2nd ed., edited by C. J. Joly, Longmans, Green, and Co., 1899. Public domain historical source. Internet Archive scan
[2] C. J. Joly, A Manual of Quaternions, Macmillan and Co., London, 1905. Public domain historical source. Internet Archive scan
[3] A. S. Hathaway, A Primer of Quaternions, 1896. Public domain historical source. Project Gutenberg edition
[4] A. Macfarlane, Vector Analysis and Quaternions, John Wiley and Sons, New York, 1906. Public domain historical source. Project Gutenberg edition
Unless otherwise noted, this PhysicsLibrary entry is intended for release under the Creative Commons Attribution ShareAlike 4.0 International license.
| Physics Classification: | 02.40.Yy (Geometric mechanics ) |
| 02.10.Hh (Rings and algebras) |
None.
No messages.

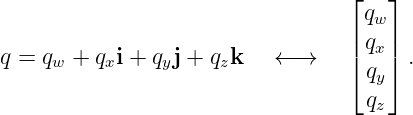
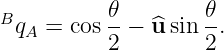
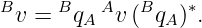
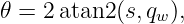


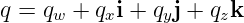


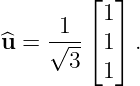
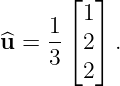
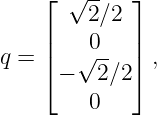

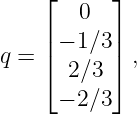


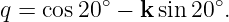


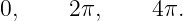
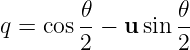
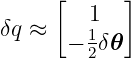
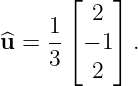
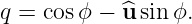


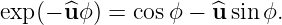
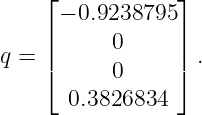
 about the
 axis