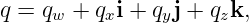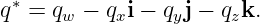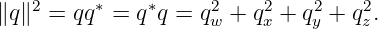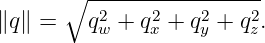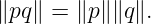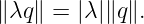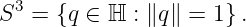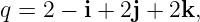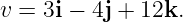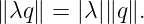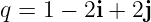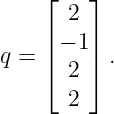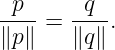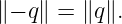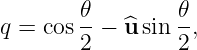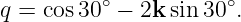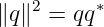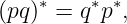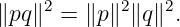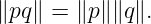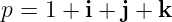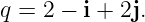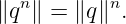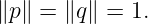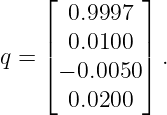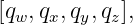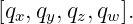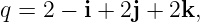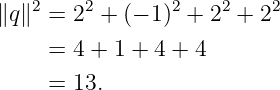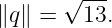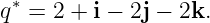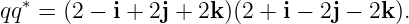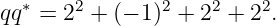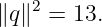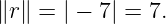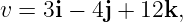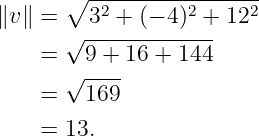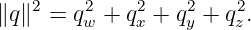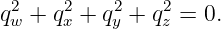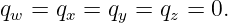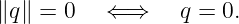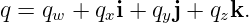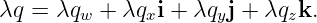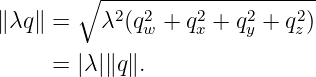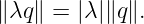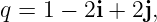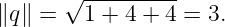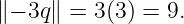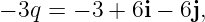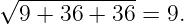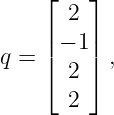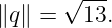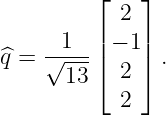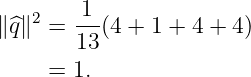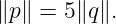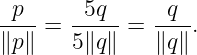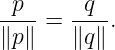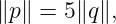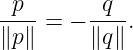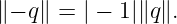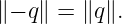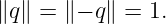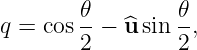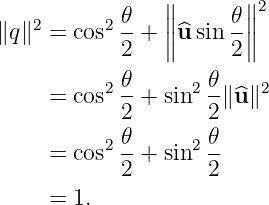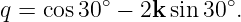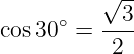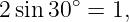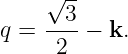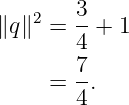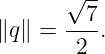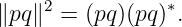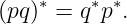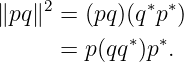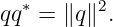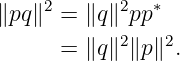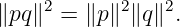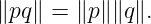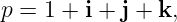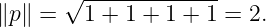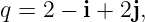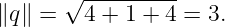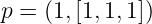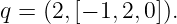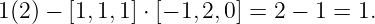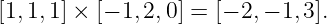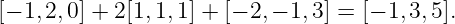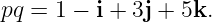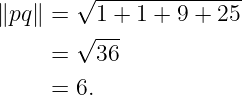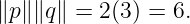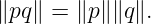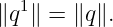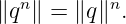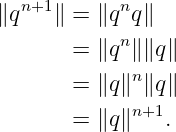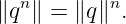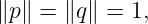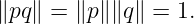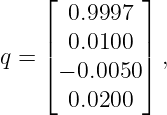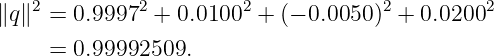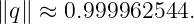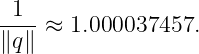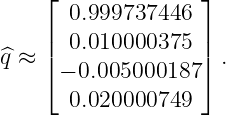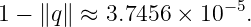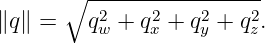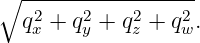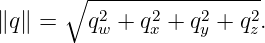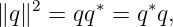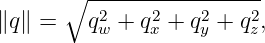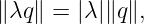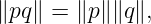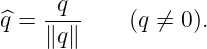Quaternion Norm: Examples, Exercises, and Solutions
This entry is the self study companion to quaternion norm.
The quaternion norm is the Euclidean length of the four real quaternion components. It is also the
square root of the real quaternion product qq∗. The norm is positive, multiplicative,
and central to normalization and to the use of unit quaternions for three dimensional
orientation.
All exercises are stated first. Complete worked solutions follow afterward.
1 Formula summary
For
the conjugate is
The squared norm is
Therefore
A unit quaternion satisfies
For nonzero q, its normalized quaternion is
The quaternion norm is multiplicative:
For a real scalar λ,
The set of unit quaternions is the unit three sphere
2 Exercises
- Direct norm calculation.
For
compute
and
- Norm from
 .
Using the same quaternion as Exercise 1, compute q∗ and evaluate qq∗ directly.
Verify that the result equals ∥q∥2.
- Real and pure quaternion norms.
Compute the norms of
and
Relate the pure quaternion norm to the ordinary three dimensional Euclidean vector
magnitude.
- Positive definiteness.
Prove that
for every quaternion and that
if and only if
- Scaling law.
For real λ, prove
Then use
and
as a numerical check.
- Normalize a quaternion.
Normalize
Verify explicitly that the normalized quaternion has unit norm.
- Normalization removes positive scale.
Let
for a nonzero quaternion q.
Prove that
What changes if
 and
 have the same norm.
Prove
For unit attitude quaternions, explain why this fact is compatible with the usual double
representation of physical orientation.
- Unit axis angle quaternion.
Let
where u is a unit pure quaternion.
Prove that
for every real 𝜃.
- A nonunit axis angle lookalike.
Suppose
Compute ∥q∥.
Explain why merely resembling an axis angle formula does not guarantee unit
norm.
- Prove multiplicativity.
Using
and
prove
Then conclude
- Numerical multiplicativity check.
Let
and
Compute ∥p∥, ∥q∥, pq, and ∥pq∥.
Verify multiplicativity numerically.
- Norm of a power.
Using multiplicativity, prove that for every positive integer n,
What follows when q is unit?
- Unit quaternions are closed under multiplication.
Let p and q both satisfy
Prove that
Explain why this closure property is important for composing orientation quaternions.
- Normalization and numerical drift.
A computed quaternion state is
Compute its norm to at least six significant digits and normalize it.
How large is the norm correction?
- Norm, storage order, and attitude convention.
Package A stores a quaternion scalar first,
while Package B stores the same semantic quaternion scalar last,
Show that both packages must compute the same Euclidean norm.
Then explain why changing from an active attitude convention to the PhysicsLibrary passive
convention does not change the definition of quaternion norm.
3 Solutions
Solution 1: direct norm calculation
For
the squared norm is
Therefore
and
Solution 2: norm from 
The conjugate is
The product is
The vector terms cancel, leaving
Hence
This agrees with
Solution 3: real and pure quaternion norms
For
the norm is
For
we have
Therefore
A pure quaternion has zero scalar component, so its quaternion norm is exactly the ordinary
Euclidean magnitude of its three vector components.
Solution 4: positive definiteness
The squared norm is
Every squared real number is nonnegative, so
Taking the principal square root gives
If
then every component vanishes, so clearly
Conversely, if
then
A sum of nonnegative real numbers can equal zero only when every term is zero. Thus
Hence
Solution 5: scaling law
Let
Then
Therefore
Thus
For
With λ = −3,
Directly,
whose norm is
Solution 6: normalize a quaternion
For
the norm is
Therefore
Its squared norm is
Thus
Solution 7: normalization removes positive scale
Let
By the scaling law,
Therefore
Hence
If
then
so
Thus a negative real scale produces the negative normalized quaternion.
For unit attitude quaternions, that negative quaternion represents the same physical orientation,
although it is a different point on S3.
Solution 8:  and
 have the same norm
Use the scaling law with λ = −1:
Therefore
For unit attitude quaternions,
The two antipodal points q and −q on S3 represent the same physical orientation.
Thus equal norm is consistent with the usual double representation of the rotation group.
Solution 9: unit axis angle quaternion
Let
where
The squared norm is
Therefore
The negative vector sign required by the passive convention has no effect on the norm because the
vector components are squared.
Solution 10: a nonunit axis angle lookalike
We have
Since
and
the quaternion is
Thus
Therefore
The axis coefficient has magnitude 2 rather than 1, so the pure direction being used is not a unit
axis. The trigonometric appearance alone does not guarantee unit norm.
Solution 11: prove multiplicativity
Start with
Use product reversal under conjugation:
Then
The quantity qq∗ is real:
Real scalars commute with every quaternion, so
Therefore
All norms are nonnegative, so taking square roots yields
Solution 12: numerical multiplicativity check
For
For
Now compute the Hamilton product.
Write
and
The scalar part is
The cross product is
The vector part is
Thus
Its norm is
Meanwhile,
Therefore
Solution 13: norm of a power
For n = 1,
Assume
Then by multiplicativity,
Therefore by induction,
If q is unit,
so
for every positive integer n.
Solution 14: unit quaternions are closed under multiplication
If
then multiplicativity gives
Therefore
Thus the product of unit quaternions is again a unit quaternion.
This is essential for orientation composition: multiplying two exact unit attitude quaternions
produces another exact unit attitude quaternion without leaving S3.
Solution 15: normalization and numerical drift
For
the squared norm is
Thus
The normalization scale factor is approximately
Therefore
The norm correction magnitude is
Thus the state was already close to unit, but normalization removes the small radial
error.
Solution 16: norm, storage order, and attitude convention
Package A computes
Package B stores the same four numbers in a different order but computes
Real addition is commutative, so these are exactly equal.
Thus storage order does not alter quaternion norm.
Likewise, active and passive attitude conventions change how a unit quaternion is interpreted
geometrically. They do not change the underlying four real components as an element of ℍ or the
Euclidean formula
Therefore the definition of quaternion norm is independent of active versus passive attitude
semantics.
4 Compact review
The central norm identities reinforced by this companion are
and
Unit quaternions form S3, and multiplicativity guarantees that products of unit quaternions
remain on S3.
5 Sources and exercise provenance
The exercises and solutions in this companion are newly written or expanded for PhysicsLibrary
from the algebra developed in Quaternion Norm.
Hamilton is the foundational source for quaternion norm related quantities. Joly and Kelland–Tait
provide classical systematic treatments. Sommer and coauthors provide a modern engineering
discussion of unit quaternions and convention management.
References
[1] W. R. Hamilton, Elements of Quaternions, 2nd ed., edited by C. J. Joly, Longmans,
Green, and Co., 1899. Public domain historical source. Internet Archive scan
[2] C. J. Joly, A Manual of Quaternions, Macmillan and Co., London, 1905. Public
domain historical source. Internet Archive search
[3] P. Kelland and P. G. Tait, Introduction to Quaternions, with Numerous Examples,
2nd ed., Macmillan and Co., London, 1882. Public domain historical source. Internet
Archive search
[4] H. Sommer, I. Gilitschenski, M. Bloesch, S. Weiss, R. Siegwart, and J. Nieto, “Why
and How to Avoid the Flipped Quaternion Multiplication,” Aerospace, vol. 5, no. 3,
article 72, 2018. Published under CC BY 4.0. Publisher article
License
Unless otherwise noted, this PhysicsLibrary entry is intended for release under the Creative
Commons Attribution ShareAlike 4.0 International license.