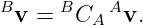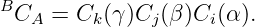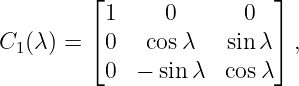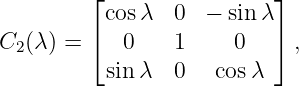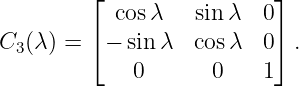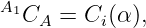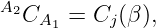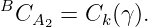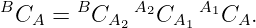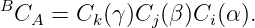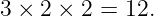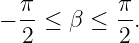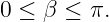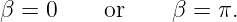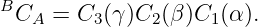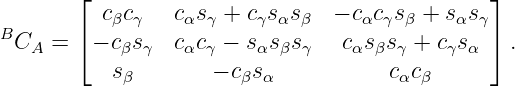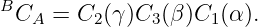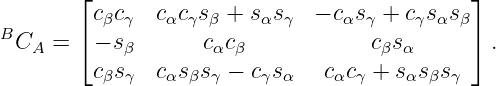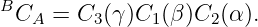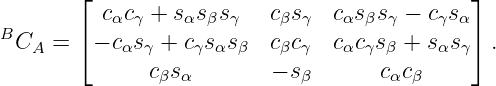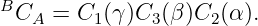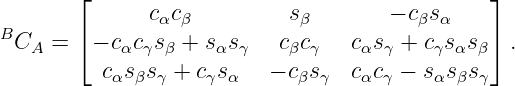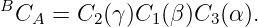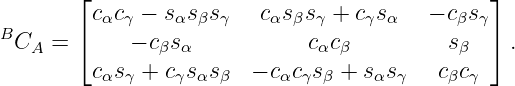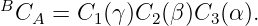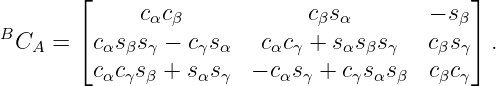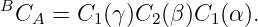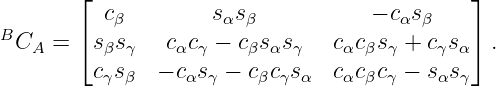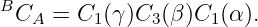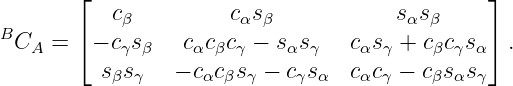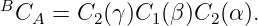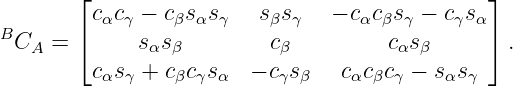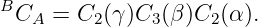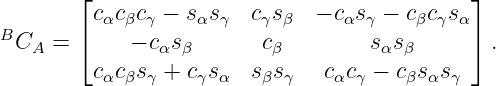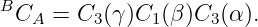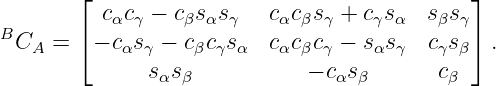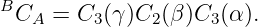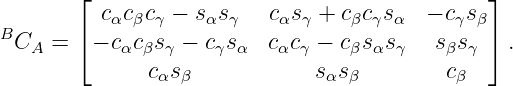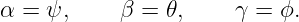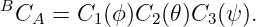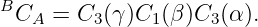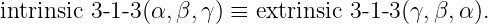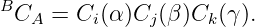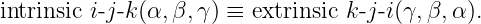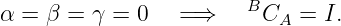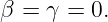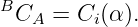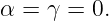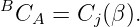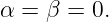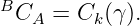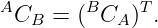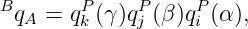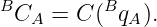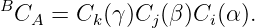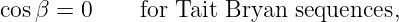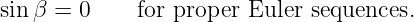Euler Angles: Sequence Composition and the Twelve Standard Sequences
Once the elementary axis rotations and the intrinsic/extrinsic distinction are understood, all
standard Euler sequences can be organized by one composition rule.
There are exactly twelve standard three angle sequences:
- six Tait Bryan sequences, in which all three axis labels are different;
- six proper Euler sequences, in which the first and third axis labels are the same.
This article derives the counting argument, gives the passive intrinsic product for every sequence,
records the expanded direction cosine matrices, and shows how the two sequence families differ in
their middle angle singularity.
It is intended to serve as the main sequence reference for the remaining Euler Angle
articles.
1 Convention recap
PhysicsLibrary uses passive coordinate maps between right handed orthonormal frames:
For a generic intrinsic i-j-k sequence with first, second, and third angles (α,β,γ),
The elementary passive matrices are
and
2 Deriving the intrinsic composition rule
Let the intermediate frames be
For intrinsic i-j-k,
and
Coordinate maps compose by matching adjacent frame labels:
Therefore
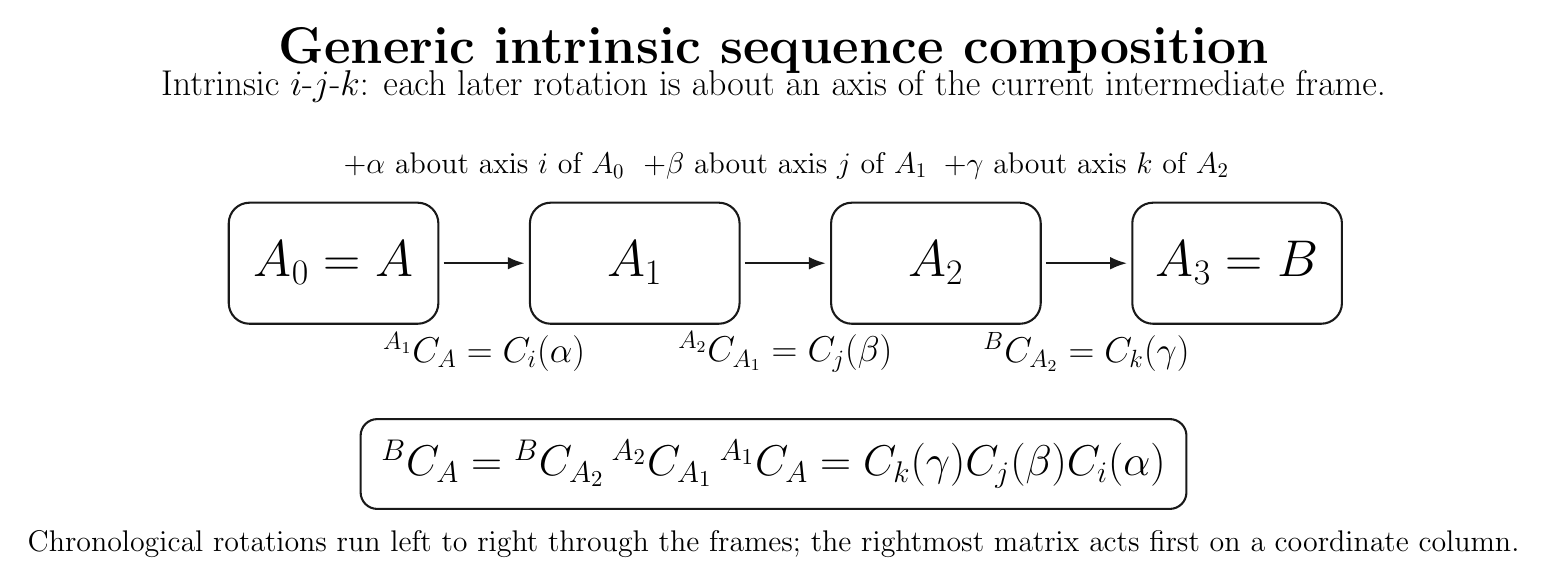
Figure. Generic intrinsic sequence composition. The chronological frame rotations progress
from A0 to A3, while the corresponding passive coordinate maps multiply in the
frame-chain order shown.
The rightmost matrix acts first on a coordinate column.
3 Why there are exactly twelve standard sequences
The first rotation axis has three possible choices.
The second axis must differ from the first, leaving two choices.
The third axis must differ from the second. There are then two standard possibilities:
- use the remaining axis, producing a Tait Bryan sequence;
- return to the first axis, producing a proper Euler sequence.
Therefore
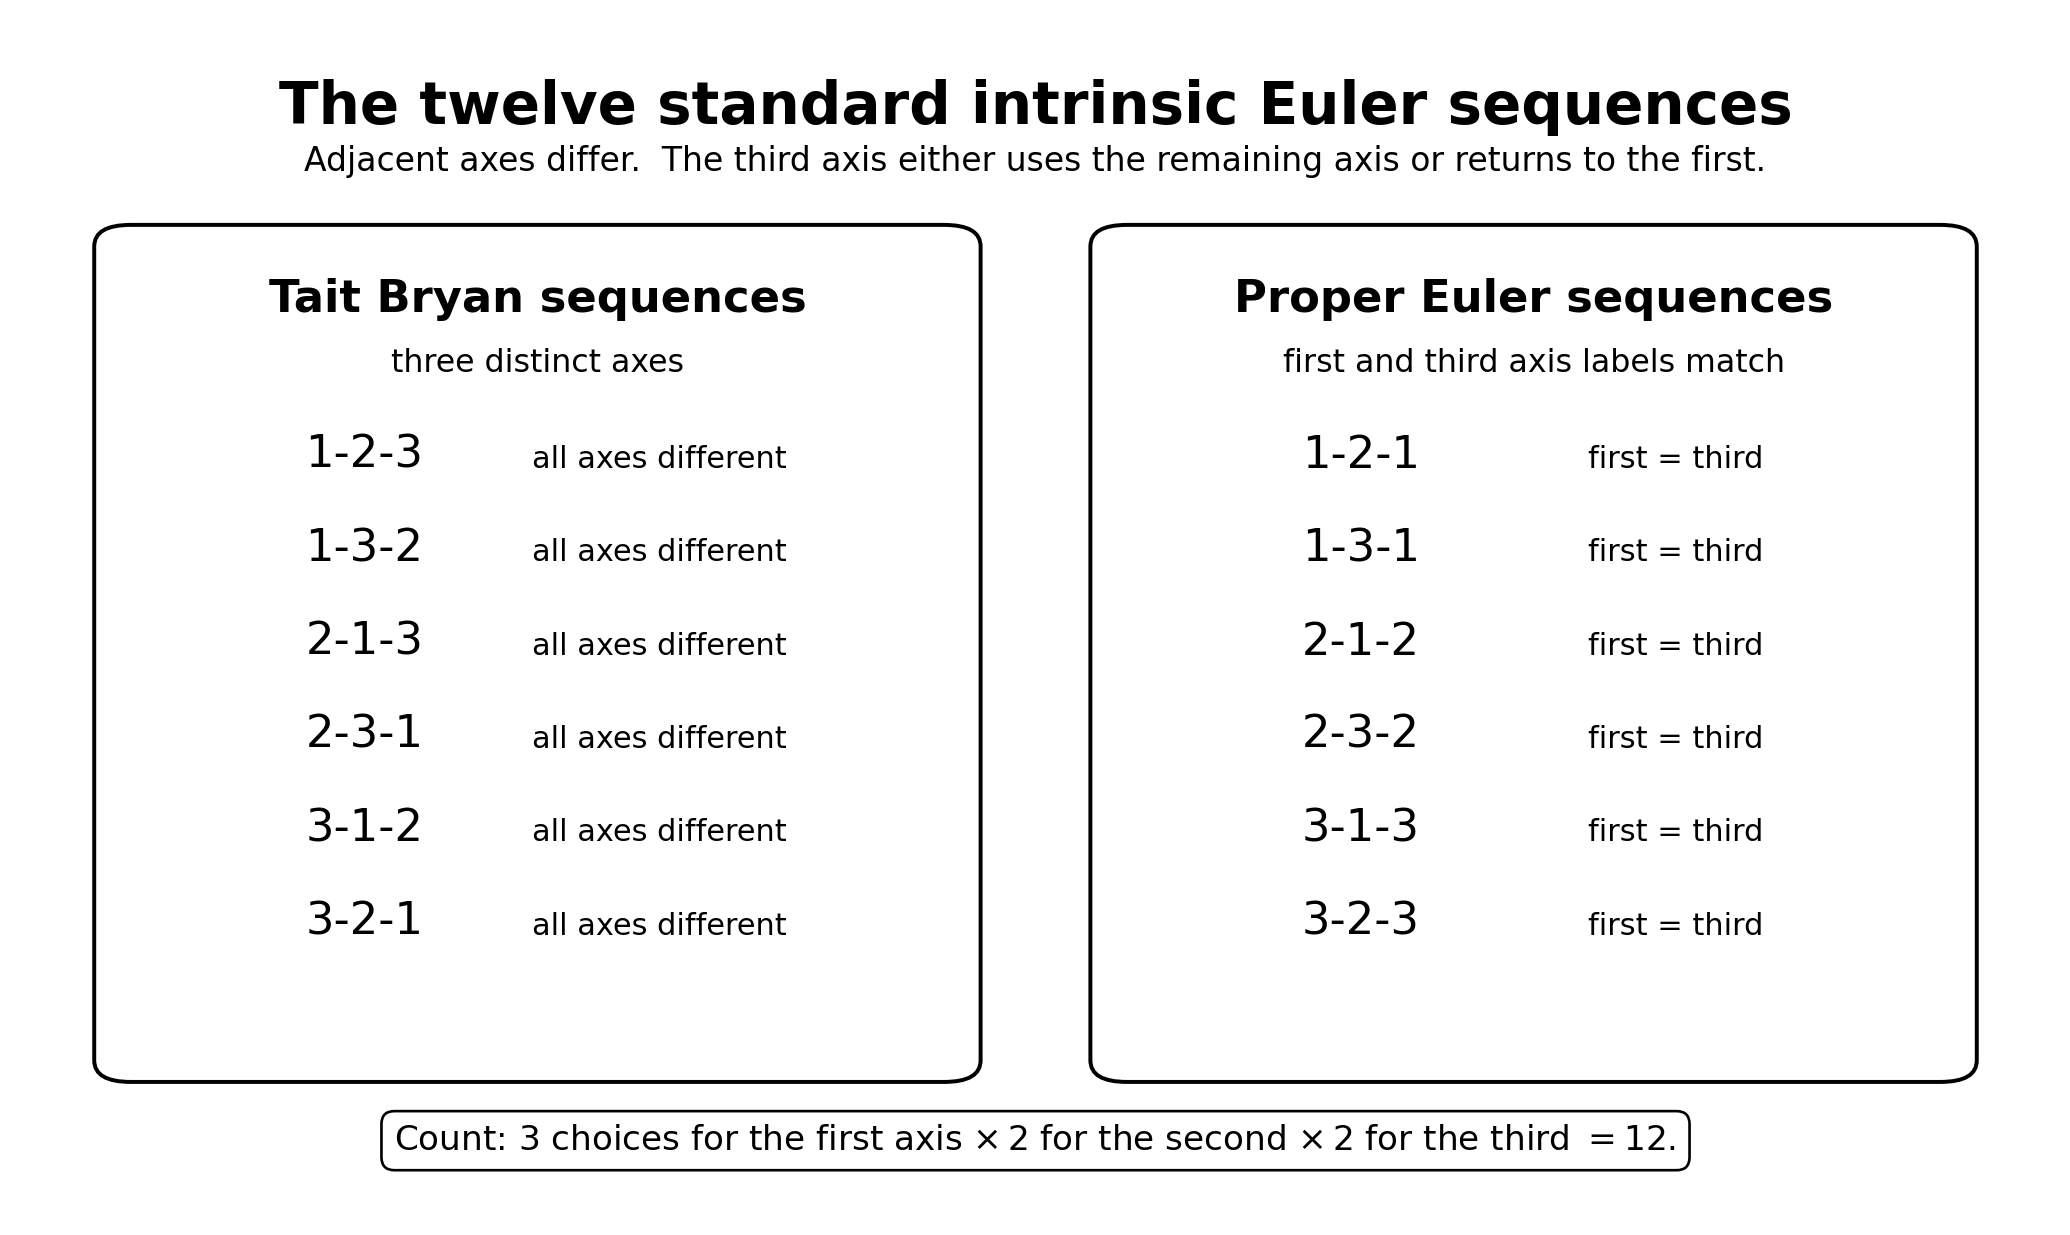
Figure. Classification of the twelve standard intrinsic Euler sequences. Six use three
distinct axes; six repeat the first axis label as the third.
4 The six Tait Bryan sequences
The Tait Bryan sequences are
Their intrinsic passive products are:
|
|
| Sequence | Passive intrinsic product |
|
|
| 1-2-3 | C3(γ)C2(β)C1(α) |
|
|
| 1-3-2 | C2(γ)C3(β)C1(α) |
|
|
| 2-1-3 | C3(γ)C1(β)C2(α) |
|
|
| 2-3-1 | C1(γ)C3(β)C2(α) |
|
|
| 3-1-2 | C2(γ)C1(β)C3(α) |
|
|
| 3-2-1 | C1(γ)C2(β)C3(α) |
|
|
For a common principal branch,
The generic Tait Bryan singularity occurs when
or
At that configuration the first and third rotation axes become aligned and the outer angles lose
independent meaning.
5 The six proper Euler sequences
The proper Euler sequences are
Their intrinsic passive products are:
|
|
| Sequence | Passive intrinsic product |
|
|
| 1-2-1 | C1(γ)C2(β)C1(α) |
|
|
| 1-3-1 | C1(γ)C3(β)C1(α) |
|
|
| 2-1-2 | C2(γ)C1(β)C2(α) |
|
|
| 2-3-2 | C2(γ)C3(β)C2(α) |
|
|
| 3-1-3 | C3(γ)C1(β)C3(α) |
|
|
| 3-2-3 | C3(γ)C2(β)C3(α) |
|
|
A common proper Euler principal choice is
The generic proper Euler singularity occurs when
that is,
Again, the physical orientation remains valid. Only the Euler coordinate chart becomes
singular.
6 Notation for expanded matrices
For compactness, define
and
The following matrices all map coordinates from the initial frame A into the final frame B under
the PhysicsLibrary passive intrinsic convention.
7 Expanded Tait Bryan reference matrices
Intrinsic 1 − 2 − 3
This is a Tait Bryan sequence. Its passive intrinsic product is
With the shorthand introduced above, the expanded matrix is
Intrinsic 1 − 3 − 2
This is a Tait Bryan sequence. Its passive intrinsic product is
With the shorthand introduced above, the expanded matrix is
Intrinsic 2 − 1 − 3
This is a Tait Bryan sequence. Its passive intrinsic product is
With the shorthand introduced above, the expanded matrix is
Intrinsic 2 − 3 − 1
This is a Tait Bryan sequence. Its passive intrinsic product is
With the shorthand introduced above, the expanded matrix is
Intrinsic 3 − 1 − 2
This is a Tait Bryan sequence. Its passive intrinsic product is
With the shorthand introduced above, the expanded matrix is
Intrinsic 3 − 2 − 1
This is a Tait Bryan sequence. Its passive intrinsic product is
With the shorthand introduced above, the expanded matrix is
8 Expanded proper Euler reference matrices
Intrinsic 1 − 2 − 1
This is a proper Euler sequence. Its passive intrinsic product is
With the shorthand introduced above, the expanded matrix is
Intrinsic 1 − 3 − 1
This is a proper Euler sequence. Its passive intrinsic product is
With the shorthand introduced above, the expanded matrix is
Intrinsic 2 − 1 − 2
This is a proper Euler sequence. Its passive intrinsic product is
With the shorthand introduced above, the expanded matrix is
Intrinsic 2 − 3 − 2
This is a proper Euler sequence. Its passive intrinsic product is
With the shorthand introduced above, the expanded matrix is
Intrinsic 3 − 1 − 3
This is a proper Euler sequence. Its passive intrinsic product is
With the shorthand introduced above, the expanded matrix is
Intrinsic 3 − 2 − 3
This is a proper Euler sequence. Its passive intrinsic product is
With the shorthand introduced above, the expanded matrix is
9 Aerospace  -
 -
 specialization
For intrinsic 3-2-1 yaw pitch roll,
Therefore
This is the flagship Tait Bryan sequence used throughout the PhysicsLibrary Euler and quaternion
series.
10 The flagship proper Euler  -
 -
 sequence
For intrinsic 3-1-3,
This sequence is used as the flagship proper Euler example later in the series.
Because its sequence label is a palindrome, its equivalent extrinsic sequence also has the label
3-1-3, but the chronological angle association reverses:
11 Intrinsic and extrinsic reference rule
For completeness, the passive extrinsic i-j-k rule is
Therefore
This equivalence should be used when translating sequence descriptions between moving-axis and
fixed-axis sources.
12 Symmetry across the twelve sequences
The twelve expanded matrices are not twelve unrelated formulas.
They are generated from the same three elementary matrices and the same composition
rule.
Several useful symmetry observations follow:
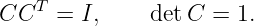
- Every matrix is proper orthogonal:
- Every Tait Bryan sequence has the same generic middle-angle singularity condition:
- Every proper Euler sequence has the same generic middle-angle singularity condition:
- Relabeling the coordinate axes maps one member of a sequence family into another.
- Reversing the intrinsic sequence produces the equivalent extrinsic description when the angle
association is reversed as well.
These symmetries are more useful than memorizing twelve independent matrices.
13 Verification tests for every sequence
Each sequence matrix should pass the following tests.
Identity
First-angle reduction
Set
Then
Second-angle reduction
Set
Then
Third-angle reduction
Set
Then
Reverse coordinate map
Quaternion agreement
For the migrated passive PhysicsLibrary quaternion convention,
and therefore
14 Why the twelve legacy sequence pages remain useful
PhysicsLibrary already has canonical entries for the individual sequences:
- Euler 121 sequence;
- Euler 123 sequence;
- Euler 131 sequence;
- Euler 132 sequence;
- Euler 212 sequence;
- Euler 213 sequence;
- Euler 231 sequence;
- Euler 232 sequence;
- Euler 312 Sequence;
- Euler 313 sequence;
- Euler 321 sequence;
- Euler 323 sequence.
Those pages remain valuable as sequence-specific reference entries.
This EA04 article supplies the common convention and composition framework so that each
legacy sequence page can be modernized without repeating the full twelve-sequence
theory.
15 Common mistakes
- Treating all twelve sequences as unrelated formulas instead of products of three
elementary matrices.
- Mixing generic first-second-third angles with aerospace roll-pitch-yaw names.
- Forgetting that the rightmost matrix acts first on a coordinate column.
- Using an extrinsic product while calling the sequence intrinsic.
- Assuming a repeated first and third axis in a proper Euler sequence means the two
rotations occur about the same physical axis.
- Using the Tait Bryan singular condition for a proper Euler sequence, or vice versa.
- Comparing two expanded matrices before confirming active/passive and map-direction
conventions.
16 Summary
There are exactly twelve standard Euler sequences.
The six Tait Bryan sequences are
The six proper Euler sequences are
For every intrinsic i-j-k sequence,
The two sequence families differ in their generic middle-angle singularity:
and
The expanded matrices in this article form the common passive intrinsic reference set for the
remainder of the PhysicsLibrary Euler angle series.
17 References and further reading
Henderson provides the classic NASA engineering tabulation of the twelve Euler sequences and
transformation-matrix relationships.
Diebel gives a compact unified treatment of Euler sequences, DCMs, quaternions, and rotation
vectors.
Moore develops orientation through successive reference-frame transformations and is especially
useful for interpreting the frame-chain composition rule.
SciPy and SymPy provide modern software examples in which intrinsic and extrinsic sequence
conventions are explicitly distinguished.
References
[1] D. M. Henderson, Euler Angles, Quaternions, and Transformation Matrices: Working
Relationships, JSC-12960, NASA Johnson Space Center, 1977. NASA Technical Reports
Server
[2] J. Diebel, “Representing Attitude: Euler Angles, Unit Quaternions, and Rotation
Vectors,” Stanford University, 2006. Online PDF
[3] J. K. Moore, Learn Multibody Dynamics, chapter “Orientation of Reference Frames,”
2026 edition. Licensed CC BY 4.0. Orientation of Reference Frames
[4] SciPy Developers, “Rotation.from_euler,” SciPy documentation. SciPy Euler rotation
documentation
[5] SymPy Development Team, “ReferenceFrame orientation methods,” SymPy
documentation. SymPy ReferenceFrame documentation
License
Unless otherwise noted, this PhysicsLibrary entry is intended for release under the Creative
Commons Attribution ShareAlike 4.0 International license.