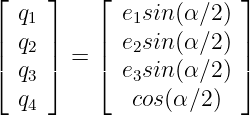An open source physics library
Encyclopedia
|
Forums
|
Docs
|
Random
axis angle of rotation to quaternions
(Definition)
Quaternions
can be defined from the
axis angle of rotation
by
(1)
"axis angle of rotation to quaternions" is owned by
bloftin
.
(
view preamble
)
View style:
HTML
PDF
page images
TeX source
Legacy HTML with images
See Also:
axis angle of rotation to direction cosine matrix
,
axis angle of rotation
Cross-references:
axis angle of rotation
,
quaternions
This is
version 3
of
axis angle of rotation to quaternions
, born on 2005-08-28, modified 2008-09-24.
Object id is 90, canonical name is AxisAngleOfRotationToQuaternions.
Accessed 3021 times total.
Classification:
Physics Classification
:
45.40.-f
(Dynamics and kinematics of rigid bodies)
Pending Errata and Addenda
None.
Discussion
Style
Flat
Threaded
Expand
all
none
1
2
3
4
5
6
7
8
9
Order
Oldest First
Newest first
Reload
No messages.
Interact
Rate
Post
Correct
Update request
Add derivation
Add example
Add (any)