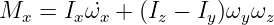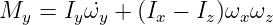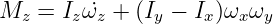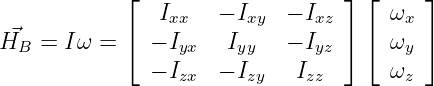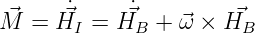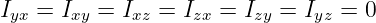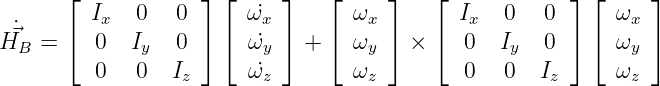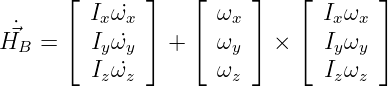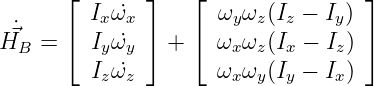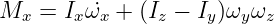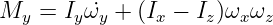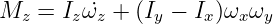Physics Library
 An open source physics library
Encyclopedia | Forums | Docs | Random  

Euler's moment equations

(Definition)

Euler’s Moment Equations in terms of the principle axes is given by

M   =  I ˙ω  + (I − I )ω ω
   x    x x     z   y   y z

My  =  Iy ˙ωy + (Ix − Iz)ωxωz

Mz  =  Izω ˙z + (Iy − Ix)ωxωy

In order to derive these equations, we start with the angular momentum of a rigid body

            ⌊                    ⌋ ⌊     ⌋
                Ixx  − Ixy  − Ixz     ωx
H⃗B  =  Iω = ⌈  − Iyx   Iyy   − Iyz⌉ ⌈  ωy ⌉
               − Izx  − Izy   Izz      ωz

Since the vector is in the body frame and we want the Moment in an inertial frame we need to use the transport theorem since our body is in a non-inertial reference frame to express the derivative of the angular momentum vector in this frame. So the Moment is given by

M⃗ =  ⃗H˙I = H⃗B˙ + ⃗ω ×  H⃗B

Since we are assuming the inertia tensor is expressed using the principal axes of the body the products of inertia are zero

Iyx = Ixy = Ixz = Izx = Izy = Iyz = 0

and using the shorter notation

Ixx = Ix

Iyy = Iy

Izz = Iz

Also since the moments of inertia are constant, when we take the derivative of the Inertia Tenser it is zero, so

      ⌊            ⌋ ⌊     ⌋   ⌊     ⌋   ⌊            ⌋ ⌊     ⌋
        Ix   0   0     ω˙x         ωx        Ix  0   0      ωx
 ˙⃗    ⌈  0  I    0 ⌉ ⌈ ω˙  ⌉   ⌈  ω  ⌉   ⌈  0   I   0 ⌉ ⌈  ω  ⌉
HB  =        y           y   +     y   ×         y          y
         0   0  Iz     ω˙z         ωz        0   0  Iz      ωz

Carrying out the matrix multiplication

      ⌊       ⌋   ⌊     ⌋   ⌊       ⌋
 ˙      Ixω˙x         ωx        Ixωx
H⃗B  = ⌈ Iyω˙y  ⌉ + ⌈  ωy ⌉ × ⌈  Iyωy ⌉
         Izω˙z         ωz        Izωz

after evaluating the cross product, we are left with adding the vectors

       ⌊ Ixω˙x ⌋    ⌊ ωy ωz(Iz − Iy) ⌋
 ⃗˙    ⌈      ⌉    ⌈               ⌉
HB  =    Iyω˙y   +    ωx ωz(Ix − Iz)
         Izω˙z        ωx ωy(Iy − Ix)

Once we add these vectors we are left with Euler’s Moment Equations
Mx  =  Ix ˙ωx + (Iz − Iy)ωyωz

My  =  Iy ˙ωy + (Ix − Iz)ωxωz

Mz  =  Izω ˙z + (Iy − Ix)ωxωy

"Euler's moment equations" is owned by bloftin.
(view preamble)
View style:

Cross-references: vectors, cross product, matrix multiplication, moments of inertia, products of inertia, inertia tensor, theorem, vector, rigid body, angular momentum
There is 1 reference to this object.

This is version 4 of Euler's moment equations, born on 2005-03-10, modified 2006-03-28.
Object id is 36, canonical name is EulersMomentEquations.
Accessed 3267 times total.

Classification:
Physics Classification: 45.40.-f (Dynamics and kinematics of rigid bodies)

Pending Errata and Addenda

None.

View all 1

Discussion

No messages.

Interact