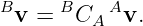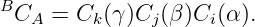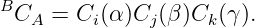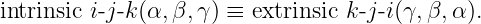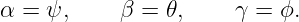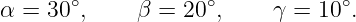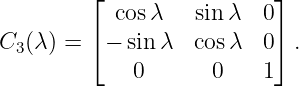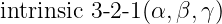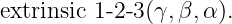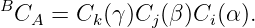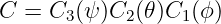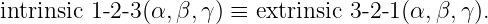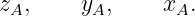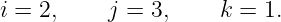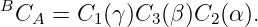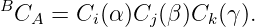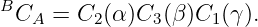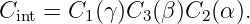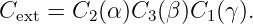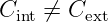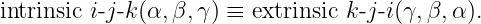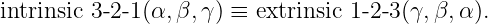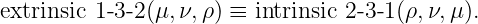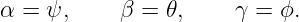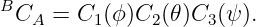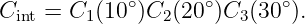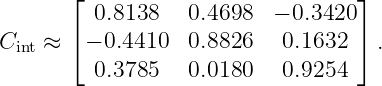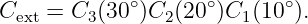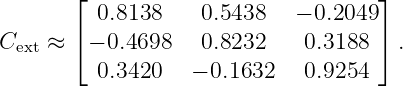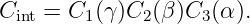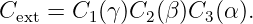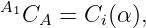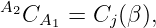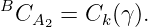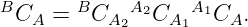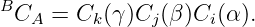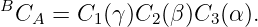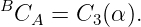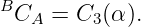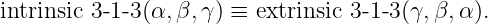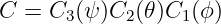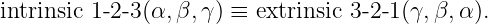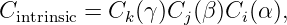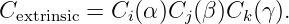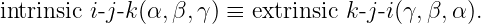Euler Angles: Intrinsic and Extrinsic Rotations Examples, Exercises, and Solutions
This entry is the self study companion to Euler Angles: intrinsic and extrinsic rotations.
The exercises are designed to make the axis geometry and matrix ordering automatic rather than
memorized.
All exercises are stated first. Complete worked solutions follow afterward.
1 Convention summary
PhysicsLibrary uses passive coordinate maps:
For an intrinsic i-j-k sequence,
For an extrinsic i-j-k sequence,
Therefore
Intrinsic means that later rotations use axes of the current intermediate frame.
Extrinsic means that every rotation axis remains attached to the original reference frame.
2 Visual reference
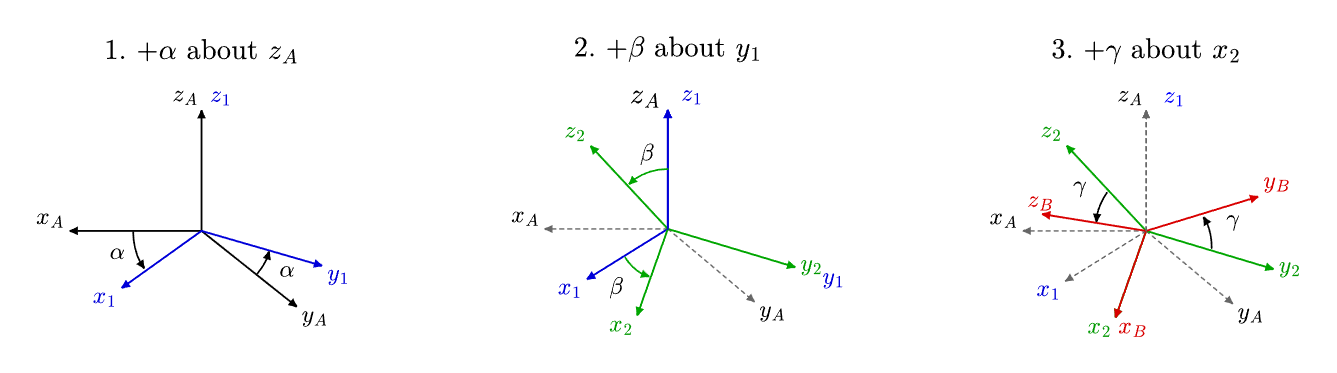
Figure. Intrinsic construction: the second rotation uses the moved axis of the intermediate
frame.
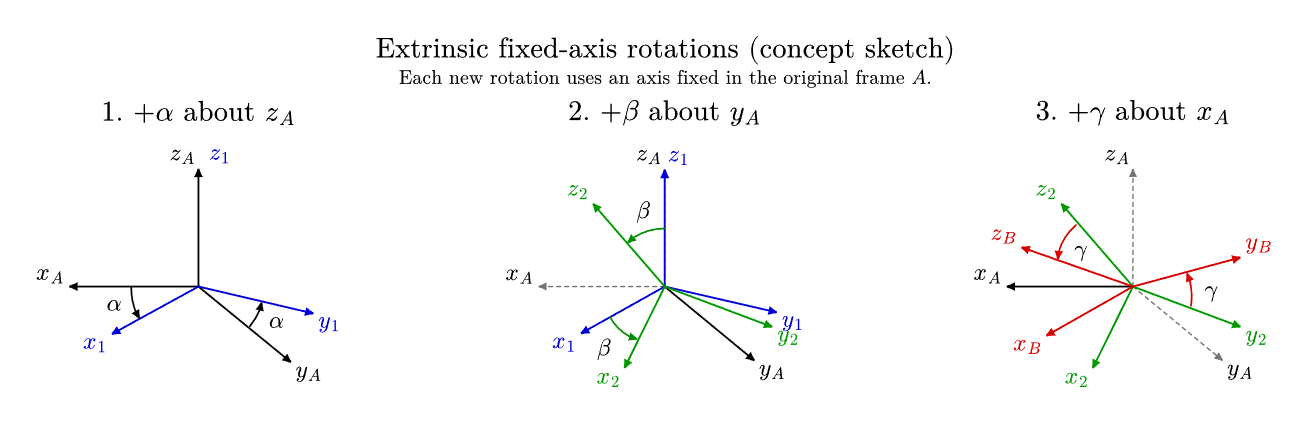
Figure. Extrinsic construction: the second rotation uses an axis fixed in the original
reference frame.
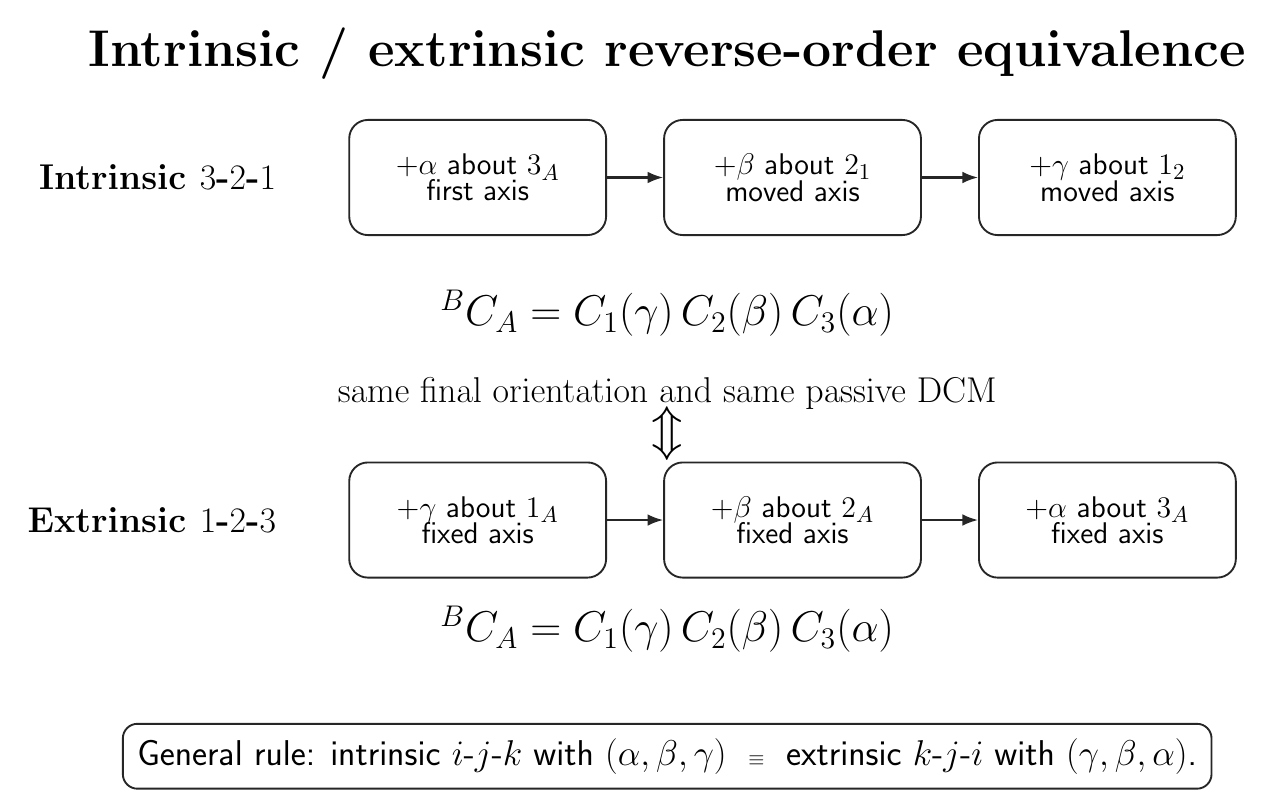
Figure. Reverse-order equivalence between intrinsic and extrinsic sequence descriptions.
3 Exercises
- Intrinsic or extrinsic?
A rotation description says:
Rotate by α about zA. Then rotate by β about the new y axis. Finally rotate
by γ about the newest x axis.
Is the sequence intrinsic or extrinsic?
What is its axis sequence?
- Fixed-axis interpretation.
A second description says:
Rotate by α about zA. Then rotate by β about yA. Finally rotate by γ about
xA.
Is the sequence intrinsic or extrinsic?
What is its axis sequence?
- Intrinsic matrix product.
Write the passive DCM for intrinsic 2-3-1 with angles (α,β,γ).
- Extrinsic matrix product.
Write the passive DCM for extrinsic 2-3-1 with angles (α,β,γ).
- Same labels, different interpretation.
Explain why intrinsic 2-3-1 and extrinsic 2-3-1 with the same angles are generally different
rotations.
Write both matrix products side by side.
- Reverse-order equivalent sequence.
Find the extrinsic sequence and angle order equivalent to intrinsic
with angles
- Reverse the other direction.
Find the intrinsic sequence equivalent to extrinsic
with chronological angles
State the corresponding intrinsic angle order.
- Aerospace yaw pitch roll.
PhysicsLibrary uses intrinsic 3-2-1 with
Write the passive DCM product.
Then give the equivalent extrinsic axis sequence and chronological angle list.
- Numerical difference for the same sequence labels.
Let
Compute the passive intrinsic 3-2-1 matrix and the passive extrinsic 3-2-1 matrix.
Verify that they are not equal.
Use
and
- Numerical reverse-order equivalence.
Using the same angles as Exercise 9, compare:
with
Verify that their passive DCMs are identical.
- Frame-label derivation.
For intrinsic i-j-k, let the intermediate frames be
Write the three elementary frame-labeled coordinate maps and derive
- Single-angle diagnostic.
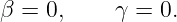
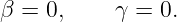
For intrinsic 3-2-1, set
What remains?
Do the same for the equivalent extrinsic 1-2-3 representation.
Explain why the two reductions agree.
- Proper Euler subtlety.
Consider intrinsic 3-1-3 with angles (α,β,γ).
What extrinsic sequence is equivalent?
What are its chronological angles?
Why is this case potentially confusing even though the reversed sequence still has the label
3-1-3?
- Body fixed and space fixed terminology.
Match each phrase to intrinsic or extrinsic:
- body fixed;
- space fixed.
Explain what the word “fixed” refers to in each case.
- Active/passive independence.
A student says:
Intrinsic means passive and extrinsic means active.
Explain why this statement is incorrect.
List the four logical combinations of axis convention and transformation type.
- Convention audit.
A textbook gives the formula
and calls it “3-2-1 yaw pitch roll.”
Give at least four questions that must be answered before deciding whether this formula
agrees with the PhysicsLibrary convention.
- Software interface audit.
A software interface documents uppercase sequence strings as intrinsic and lowercase strings
as extrinsic.
Which sequence strings would you expect to use for:
- intrinsic 3-2-1;
- extrinsic 3-2-1;
- the extrinsic sequence equivalent to intrinsic 3-2-1?
Why must you still check the software’s active/passive and map-direction semantics?
- Correct an incorrect equivalence statement.
A student writes
Identify the error and write the correct equivalence.
4 Solutions
Solution 1: intrinsic or extrinsic?
The second rotation is about the new y axis, and the third is about the newest x axis.
Therefore the axes move with the intermediate frame.
The sequence is intrinsic
Solution 2: fixed axis interpretation
Every rotation is explicitly about an axis of the original frame A:
Therefore the construction is extrinsic
Solution 3: intrinsic matrix product
For intrinsic 2-3-1,
Hence
Solution 4: extrinsic matrix product
For extrinsic 2-3-1, the generic passive rule is
Therefore
Solution 5: same labels, different interpretation
Intrinsic 2-3-1 gives
Extrinsic 2-3-1 gives
The products have different factor order.
Since finite rotations about different axes generally do not commute,
in general.
Solution 6: reverse-order equivalent sequence
The general equivalence is
Thus
Solution 7: reverse the other direction
The extrinsic sequence is
with chronological angles
Reverse the axis order and reverse the associated angle order.
Therefore
Solution 8: aerospace yaw pitch roll
For PhysicsLibrary intrinsic 3-2-1,
Hence
The equivalent extrinsic sequence is
with chronological angle list
Thus the equivalent fixed axis description is roll about 1A, then pitch about 2A, then yaw about
3A.
Solution 9: numerical difference for the same sequence labels
For intrinsic 3-2-1,
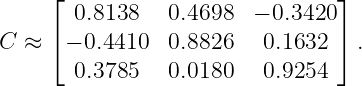
Numerically,
For extrinsic 3-2-1,
Numerically,
The matrices are not equal.
Thus identical sequence labels do not imply identical orientation when one description is intrinsic
and the other extrinsic.
Solution 10: numerical reverse-order equivalence
Intrinsic 3-2-1 with (α,β,γ) gives
Extrinsic 1-2-3 with (γ,β,α) gives
The products are symbolically identical.
For the numerical angles of Exercise 9, both give
Solution 11: frame-label derivation
The three intrinsic coordinate maps are
and
Compose the maps by matching adjacent frame labels:
Therefore
Solution 12: single-angle diagnostic
For intrinsic 3-2-1,
Set
Then
The equivalent extrinsic representation is 1-2-3 with angle list (γ,β,α).
Setting γ = β = 0 leaves the final chronological extrinsic rotation about fixed axis 3A through α,
whose passive product is also
Thus the single-angle reduction agrees.
Solution 13: proper Euler subtlety
Intrinsic 3-1-3 with angles (α,β,γ) is equivalent to extrinsic
with chronological angles
So
The sequence label is a palindrome, so reversing the axis order does not visibly change the
digits.
The angle association still reverses.
That is why proper Euler sequences such as 3-1-3 can be especially easy to misinterpret.
Solution 14: body fixed and space fixed terminology
Body fixed corresponds to intrinsic.
Each new rotation axis belongs to the current intermediate frame and therefore moves with the
body or moving frame.
Space fixed corresponds to extrinsic.
Each rotation axis remains attached to the original reference frame.
The word “fixed” therefore refers to which frame owns the successive rotation axes, not to whether
the mathematical transformation is active or passive.
Solution 15: active/passive independence
The statement is incorrect because two independent choices are being mixed.
Intrinsic versus extrinsic specifies the axis behavior.
Active versus passive specifies whether the physical vector or coordinate frame is being
transformed.
The four logical combinations are:
- intrinsic passive;
- extrinsic passive;
- intrinsic active;
- extrinsic active.
PhysicsLibrary uses intrinsic passive as its default Euler convention, but the other three
combinations are mathematically valid.
Solution 16: convention audit
Before comparing
with PhysicsLibrary, one should ask at least:
- Is the transformation active or passive?
- What coordinate map direction is represented?
- Is the sequence intrinsic or extrinsic?
- Does “3-2-1” describe chronological axis order or written matrix order?
- Are ϕ,𝜃,ψ roll, pitch, and yaw, or merely first, second, and third sequence angles?
- Does the source use the same right hand positive-angle convention?
Without these answers, matrix order alone is not enough to compare conventions.
Solution 17: software interface audit
Under the stated software convention:
- intrinsic 3-2-1 would use uppercase
- extrinsic 3-2-1 would use lowercase
- the extrinsic sequence equivalent to intrinsic 3-2-1 is 1-2-3, so it would use
One must still verify whether the software rotation object represents an active vector
rotation or a passive coordinate transformation, and which frame-map direction its matrix
represents.
Intrinsic/extrinsic notation alone does not determine those choices.
Solution 18: correct an incorrect equivalence statement
The student’s axis reversal is correct, but the angle order was not reversed.
The correct statement is
The axes and their associated angles must be reversed together.
5 Compact review
The two passive sequence rules are
and
The reverse-order equivalence is
The words intrinsic and extrinsic describe the axes used for successive rotations.
They do not, by themselves, specify active versus passive transformation.
6 Sources and exercise provenance
The exercises and worked solutions in this companion are newly written for PhysicsLibrary to
reinforce the convention and frame geometry developed in Euler angles: intrinsic and extrinsic
rotations.
Henderson provides the classic NASA engineering background for Euler sequence relationships.
Moore develops successive reference-frame orientation with explicit intermediate frames.
SymPy distinguishes body fixed and space fixed reference-frame sequences in its mechanics
API.
SciPy explicitly distinguishes intrinsic and extrinsic Euler sequence strings.
References
[1] D. M. Henderson, Euler Angles, Quaternions, and Transformation Matrices: Working
Relationships, JSC-12960, NASA Johnson Space Center, 1977. NASA Technical Reports
Server
[2] J. K. Moore, Learn Multibody Dynamics, chapter “Orientation of Reference Frames,”
2026 edition. Licensed CC BY 4.0. Orientation of Reference Frames
[3] SymPy Development Team, “ReferenceFrame orientation methods,” SymPy
documentation. SymPy ReferenceFrame documentation
[4] SciPy Developers, “Rotation.from_euler,” SciPy documentation. SciPy Euler rotation
documentation
License
Unless otherwise noted, this PhysicsLibrary entry is intended for release under the Creative
Commons Attribution ShareAlike 4.0 International license.