Physics Library
 An open source physics library
Encyclopedia | Forums | Docs | Random |  
Login
create new user
Username:
Password:
forget your password?
Main Menu
Sections

Meta

Talkback

Downloads

Information
axis angle of rotation to direction cosine matrix (Definition)

For now, without proof you can get the direction cosine matrix (DCM) from the axis angle of rotation by

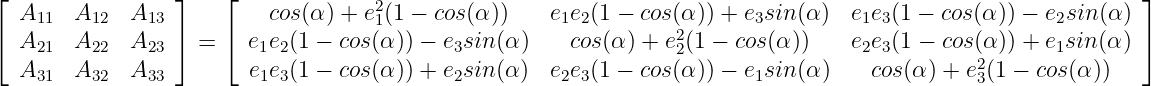
⌊ A11   A12  A13 ⌋    ⌊   cos(α ) + e2(1 − cos(α))   e1e2(1 − cos(α)) + e3sin (α)  e1e3(1 − cos (α )) − e2sin (α ) ⌋
⌈                ⌉    ⌈             1                            2                                            ⌉
  A21   A22  A23   =    e1e2(1 − cos(α)) − e3sin(α)    cos(α) + e2(1 − cos(α))    e2e3(1 − cos(2α)) + e1sin (α )
  A31   A32  A33        e1e3(1 − cos(α)) + e2sin(α)  e2e3(1 − cos(α)) − e1sin (α)    cos(α) + e3(1 − cos(α))
(1)


"axis angle of rotation to direction cosine matrix" is owned by bloftin.
(view preamble)
View style:
See Also: axis angle of rotation, axis angle of rotation to quaternions


Cross-references: axis angle of rotation, direction cosine matrix

This is version 4 of axis angle of rotation to direction cosine matrix, born on 2005-08-28, modified 2008-09-24.
Object id is 88, canonical name is AxisAngleOfRotationToDirectionCosineMatrix.
Accessed 3240 times total.

Classification:
Physics Classification45.40.-f (Dynamics and kinematics of rigid bodies)
Pending Errata and Addenda
None.
Discussion
Style: Expand: Order:

No messages.

Interact
rate | post | correct | update request | add derivation | add example | add (any)